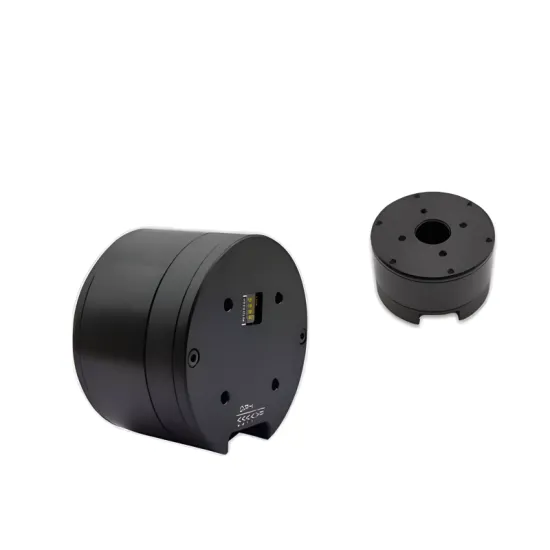
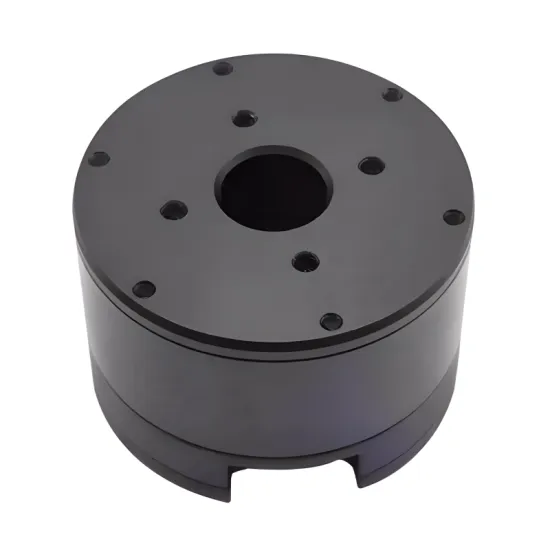
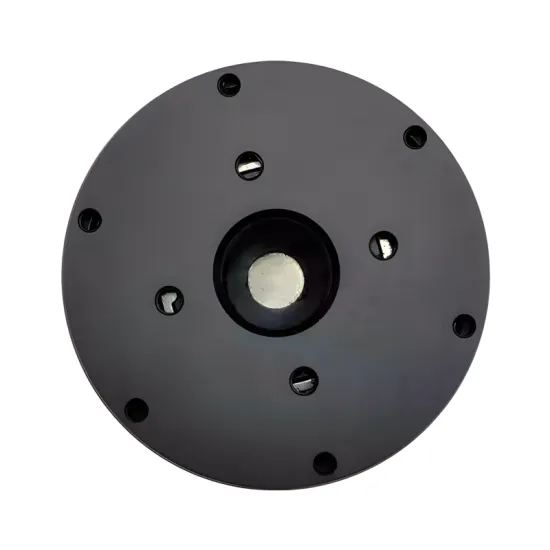


Multiple K-series models
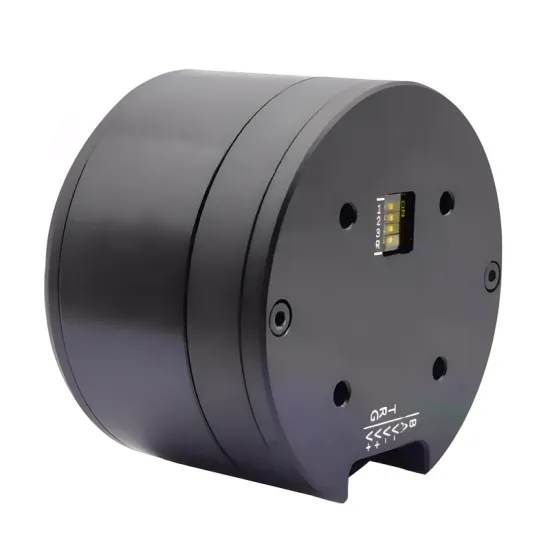
Integrated motor and drive design; 18-bit absolute magnetic encoder
Low-profile design featuring an aviation-grade aluminum outer rotor and NdFeB magnets
| Motor Model | K4020 | K4028 | K4030 | K5020 |
| Rated Voltage (V) | 12 | 12 | 16 | 16 |
| Range Voltage (V) | 7.4-32 | 7.4-32 | 7.4-32 | 7.4-32 |
| Number of Turns (T) | 25 | 27 | 20 | 35 |
| Maximum Speed (rpm) | 2390 | 1120 | 1350 | 1700 |
| Rated Torque (N.m) | 0.07 | 0.15 | 0.25 | 0.12 |
| Rated Speed (rpm) | 1600 | 560 | 750 | 1100 |
| Maximum Torque (N.m) | 0.25 | 0.33 | 0.65 | 0.4 |
| Motor Weight (g) | 65 | 94 | 116 | 104 |
| Maximum Dimensions (mm) | Φ39.6*23 | Φ39.6*28 | Φ39.6*33 | Φ49*23.9 |
| Motor Model | K5028 | K5030 | K6020 | K6030 |
| Rated Voltage (V) | 16 | 16 | 24 | 12 |
| Range Voltage (V) | 7.4-32 | 7.4-32 | 7.4-32 | 7.4-32 |
| Number of Turns (T) | 10 / 35 | 10 / 35 | 15 / 25 | 25 |
| Maximum Speed (rpm) | 3050 / 870 | 2040 / 580 | 2200 / 1280 | 2390 |
| Rated Torque (N.m) | 0.26 / 0.24 | 0.38 / 0.32 | 0.55 / 0.55 | 0.07 |
| Rated Speed (rpm) | 2400 / 440 | 1550 / 250 | 1700 / 990 | 1600 |
| Maximum Torque (N.m) | 0.4 / 0.53 | 0.7 / 0.82 | 4 / 2.7 | 0.25 |
| Motor Weight (g) | 137 | 175 | 193 | 65 |
| Maximum Dimensions (mm) | Φ49*28.9 | Φ49*33.9 | Φ58*29 | Φ39.6*23 |
| Motor Model | K9030 | K9040 | K9050 | K12060 |
| Rated Voltage (V) | 24 | 24 | 24 | 24 |
| Range Voltage (V) | 7.4-32 | 7.4-32 | 7.4-32 | 7.4-32 |
| Number of Turns (T) | 17 / 35 | 16 / 35 | 16 / 35 | 20 |
| Maximum Speed (rpm) | 1465 / 2390 | 1085 / 500 | 710 / 280 | 250 |
| Rated Torque (N.m) | 1.09 / 1.07 | 1.63 / 1.67 | 2.42 / 2.79 | 5 |
| Rated Speed (rpm) | 1080 / 450 | 780 / 290 | 490 / 130 | 115 |
| Maximum Torque (N.m) | 2.2 / 4.1 | 3.4 / 5 | 4.5 / 5.8 | 10 |
| Motor Weight (g) | 525 | 660 | 963 | 1147 |
| Maximum Dimensions (mm) | Φ89*37 | Φ89*42 | Φ89*53 | Φ120*63.2 |
| Motor Model | K7028 | K7030 | K7050 |
| Rated Voltage (V) | 24 | 24 | 24 |
| Range Voltage (V) | 7.4-32 | 7.4-32 | 7.4-32 |
| Maximum Speed (rpm) | 23 / 45 | 10 / 23 / 45 | 10 / 28 / 45 |
| Rated Speed (rpm) | 1230 / 620 | 1890 / 805 / 410 | 1350 / 462 / 285 |
| Rated Torque (N.m) | 0.61 / 0.63 | 1 / 1 / 0.99 | 1.6 / 1.6 / 1.5 |
| Maximum Torque (N.m) | 2 / 2.1 | 2 / 3.8 / 2.42 | 2.1 / 2.9 / 2.7 |
| Motor Weight (g) | 278 | 352 | 526 |
| Maximum Dimensions (mm) | Φ69*28.9 | Φ69*33.9 | Φ69*46 |
K-Series Medium-to-High-Speed BLDC Motors
High-Performance FOC Servo Motors
Integrated, lightweight, high-precision, and high-torque design
Encoder resolution upgraded from 14-bit to 18-bit
Optimized cogging torque Supports PWM input
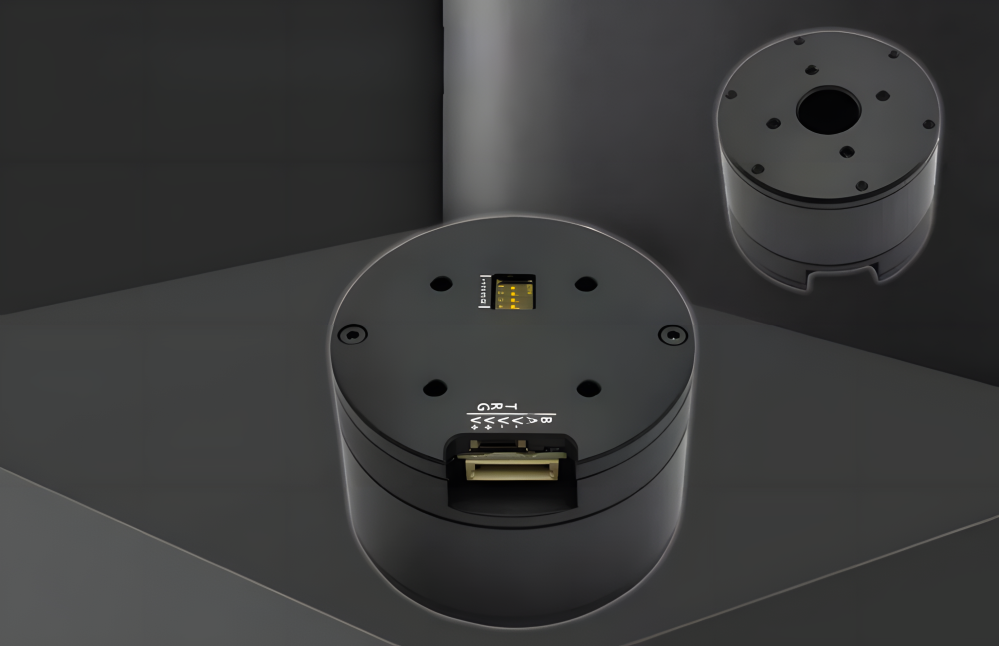
| Ultra-high standard product design |
Integrated electric drive design
Built-in drive and magnetic encoder
Integration Integrated motor and drive design |
| High precision 14-bit absolute magnetic encode |
Lightweighting Low-profile design combined with aerospace-grade aluminum | High torque Outer-rotor design with NdFeB magnets |
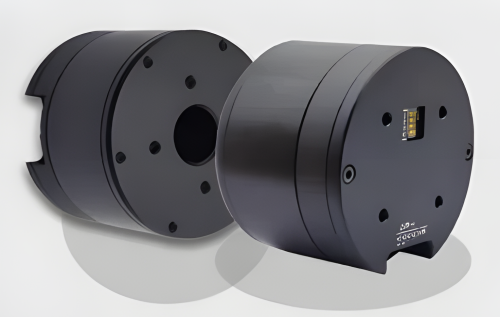
Actual photos of motor products — Quality guaranteed
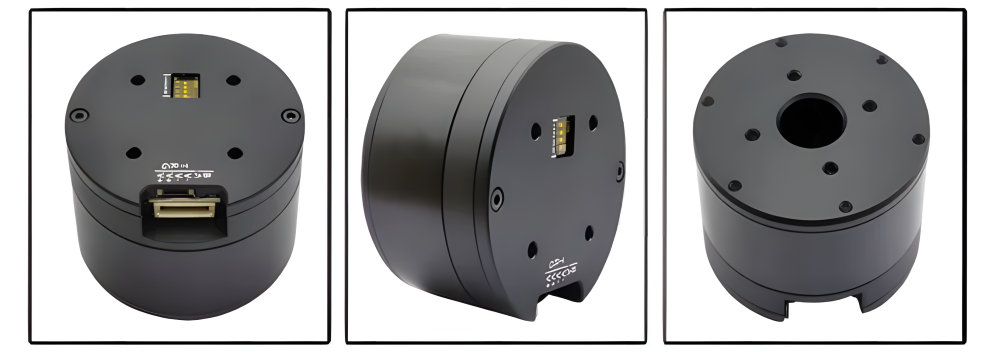
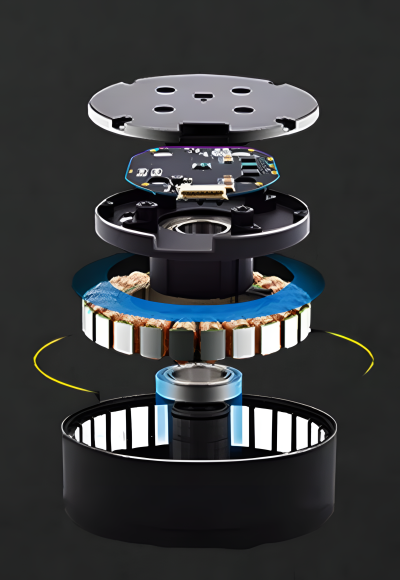
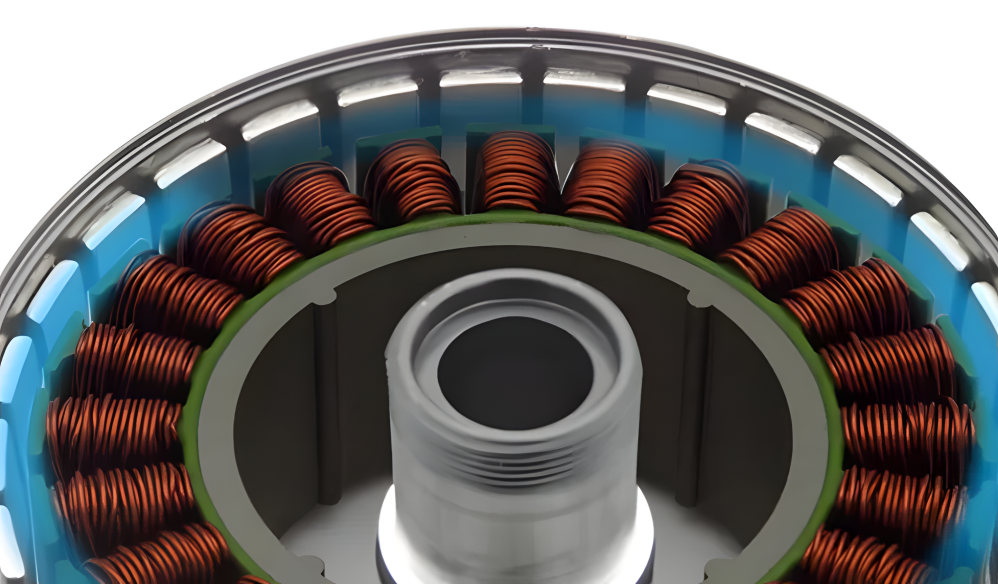
| Outer rotor | Low air gap |
| Multi-stage arc-shaped permanent magnets | Radially magnetized |
| Customizable winding | 0.2mm imported silicon steel laminations |
| SH-grade NdFeB | H-class high-temperature resistant copper wire |
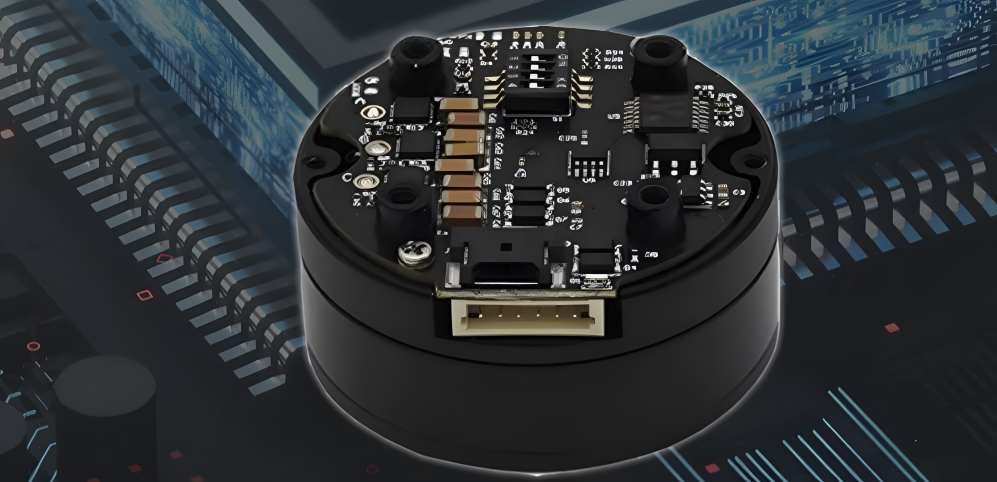
High-performance MCUs Factory Direct | Built-in driver board customization available |
Servo motors / Servo drives
Seamless switching between torque, speed, and position control modes
CAN or RS485 bus communication; supports direct control via PC, MCU, PLC, industrial PC, Raspberry Pi, or Arduino
High-performance 32-bit ARM Cortex-M4 core controller
Real-time monitoring of motor stator temperature
Three-phase full-bridge driver using all N-channel MOSFETs; features low internal resistance and high current capability
Precision current control using low-temperature-drift alloy resistors for accurate sensing
18-bit single-turn absolute magnetic encoder with factory calibration; zero-point position is permanently retained
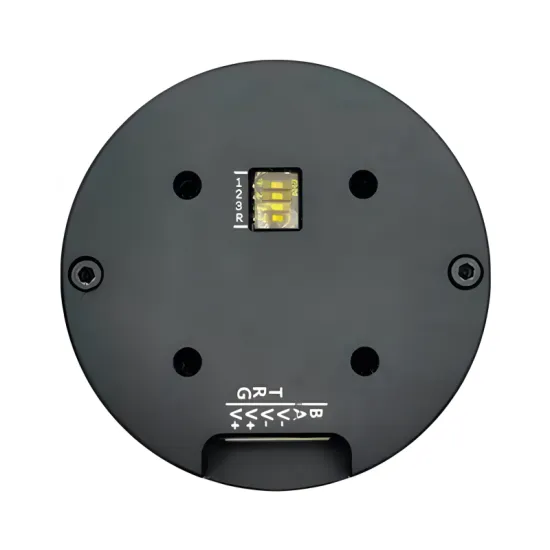
API Definition Description
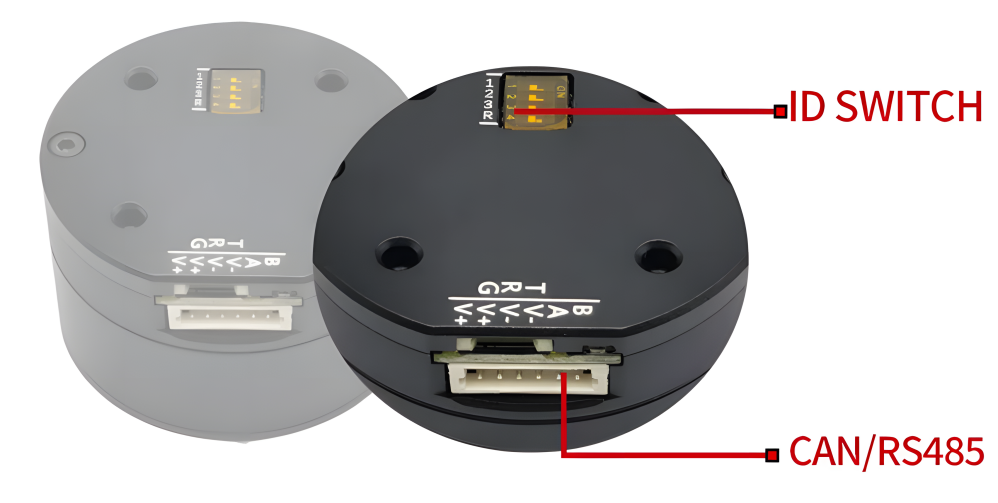
| Interface | Note |
| B/L | RS485-B or CAN-L |
| A/H | RS485-A or CAN-H |
| V- | Negative Power Supply |
| V- | Negative Power Supply |
| V+ | Positive Power Supply |
| V+ | Positive Power Supply |
| I | UART Transmitter |
| R | UART Receiver |
| G | Signal GND |
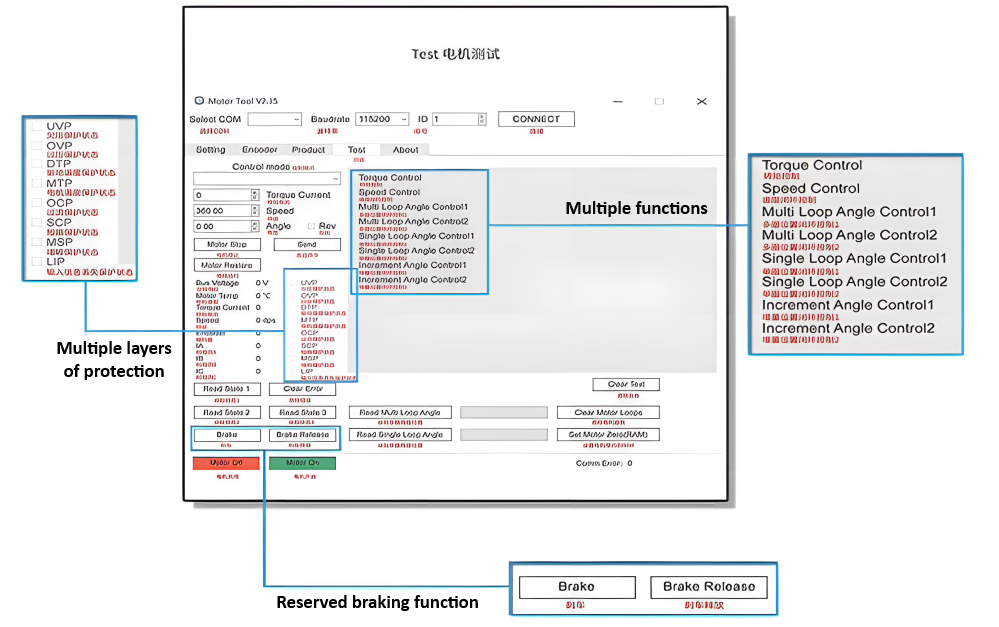
Supports host-side parameter tuning, testing, and firmware upgrades.
Compatible with open-source development platforms such as PC, MCU, PLC, industrial PCs, and Raspberry Pi.
Torque mode | Speed mode | Single-turn position + direction mode | Incremental position mode |
Multi-turn control mode (with speed limit) | Multi-turn control mode | Single-turn position + direction mode (with speed limit) | Incremental position mode (with speed limit) |
Multiple control modes
Application Scenarios
|
|
|
|
| 360° Camera | Handheld Camera | LiDAR | Gimbal Pod |