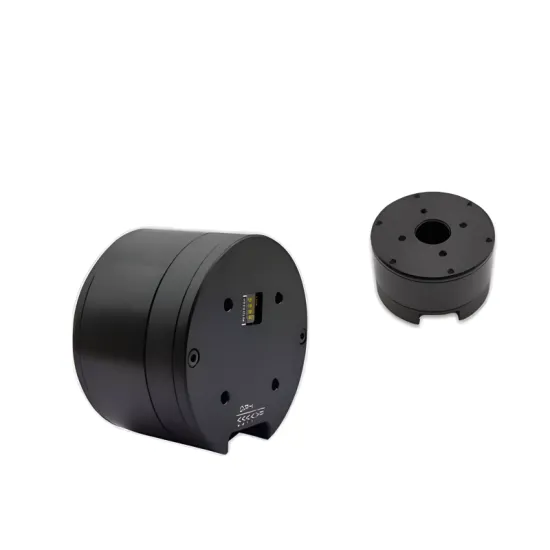
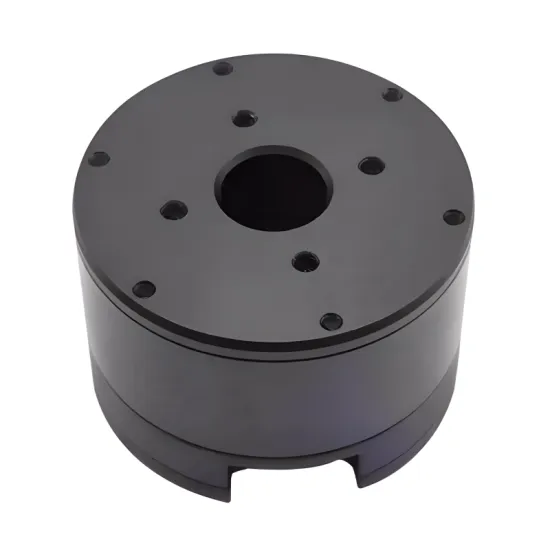
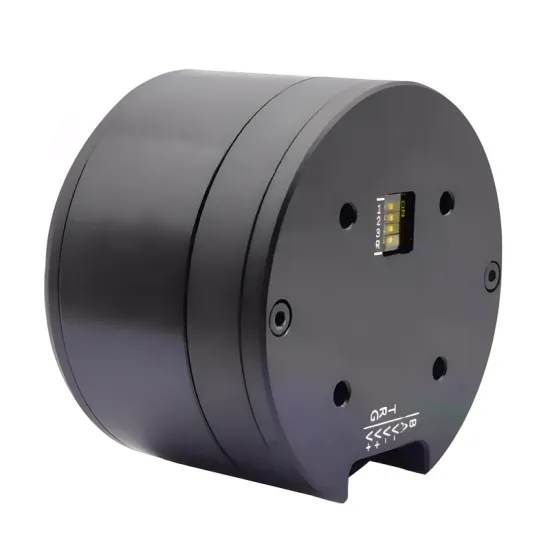
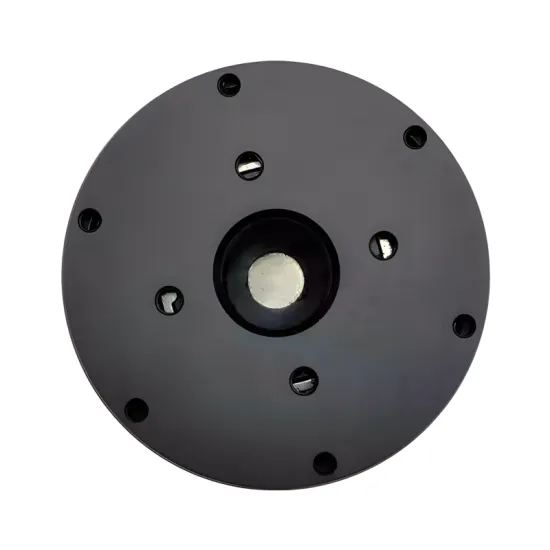
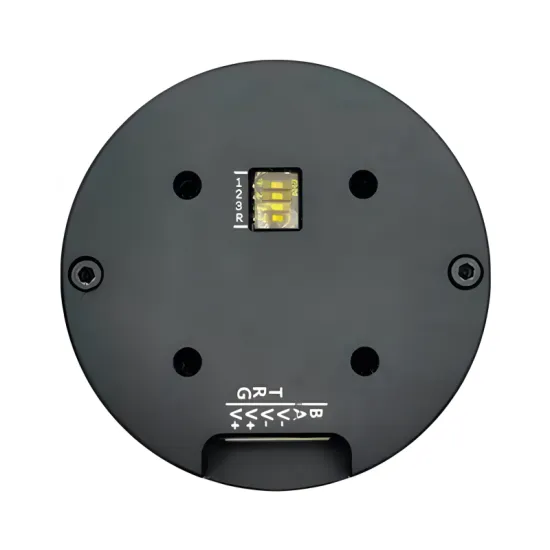


Multiple K-series models
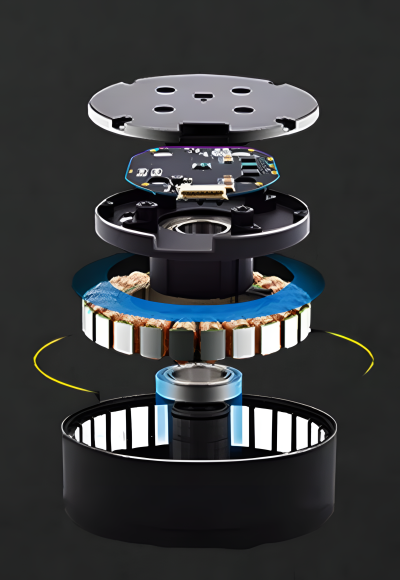
Integrated motor and drive design; 18-bit absolute magnetic encoder
Low-profile design featuring an aviation-grade aluminum outer rotor and NdFeB magnets
| Motor Model | K4020 | K4028 | K4030 | K5020 |
| Rated Voltage (V) | 12 | 12 | 16 | 16 |
| Range Voltage (V) | 7.4-32 | 7.4-32 | 7.4-32 | 7.4-32 |
| Number of Turns (T) | 25 | 27 | 20 | 35 |
| Maximum Speed (rpm) | 2390 | 1120 | 1350 | 1700 |
| Rated Torque (N.m) | 0.07 | 0.15 | 0.25 | 0.12 |
| Rated Speed (rpm) | 1600 | 560 | 750 | 1100 |
| Maximum Torque (N.m) | 0.25 | 0.33 | 0.65 | 0.4 |
| Motor Weight (g) | 65 | 94 | 116 | 104 |
| Maximum Dimensions (mm) | Φ39.6*23 | Φ39.6*28 | Φ39.6*33 | Φ49*23.9 |
| Motor Model | K5028 | K5030 | K6020 | K6030 |
| Rated Voltage (V) | 16 | 16 | 24 | 12 |
| Range Voltage (V) | 7.4-32 | 7.4-32 | 7.4-32 | 7.4-32 |
| Number of Turns (T) | 10 / 35 | 10 / 35 | 15 / 25 | 25 |
| Maximum Speed (rpm) | 3050 / 870 | 2040 / 580 | 2200 / 1280 | 2390 |
| Rated Torque (N.m) | 0.26 / 0.24 | 0.38 / 0.32 | 0.55 / 0.55 | 0.07 |
| Rated Speed (rpm) | 2400 / 440 | 1550 / 250 | 1700 / 990 | 1600 |
| Maximum Torque (N.m) | 0.4 / 0.53 | 0.7 / 0.82 | 4 / 2.7 | 0.25 |
| Motor Weight (g) | 137 | 175 | 193 | 65 |
| Maximum Dimensions (mm) | Φ49*28.9 | Φ49*33.9 | Φ58*29 | Φ39.6*23 |
| Motor Model | K9030 | K9040 | K9050 | K12060 |
| Rated Voltage (V) | 24 | 24 | 24 | 24 |
| Range Voltage (V) | 7.4-32 | 7.4-32 | 7.4-32 | 7.4-32 |
| Number of Turns (T) | 17 / 35 | 16 / 35 | 16 / 35 | 20 |
| Maximum Speed (rpm) | 1465 / 2390 | 1085 / 500 | 710 / 280 | 250 |
| Rated Torque (N.m) | 1.09 / 1.07 | 1.63 / 1.67 | 2.42 / 2.79 | 5 |
| Rated Speed (rpm) | 1080 / 450 | 780 / 290 | 490 / 130 | 115 |
| Maximum Torque (N.m) | 2.2 / 4.1 | 3.4 / 5 | 4.5 / 5.8 | 10 |
| Motor Weight (g) | 525 | 660 | 963 | 1147 |
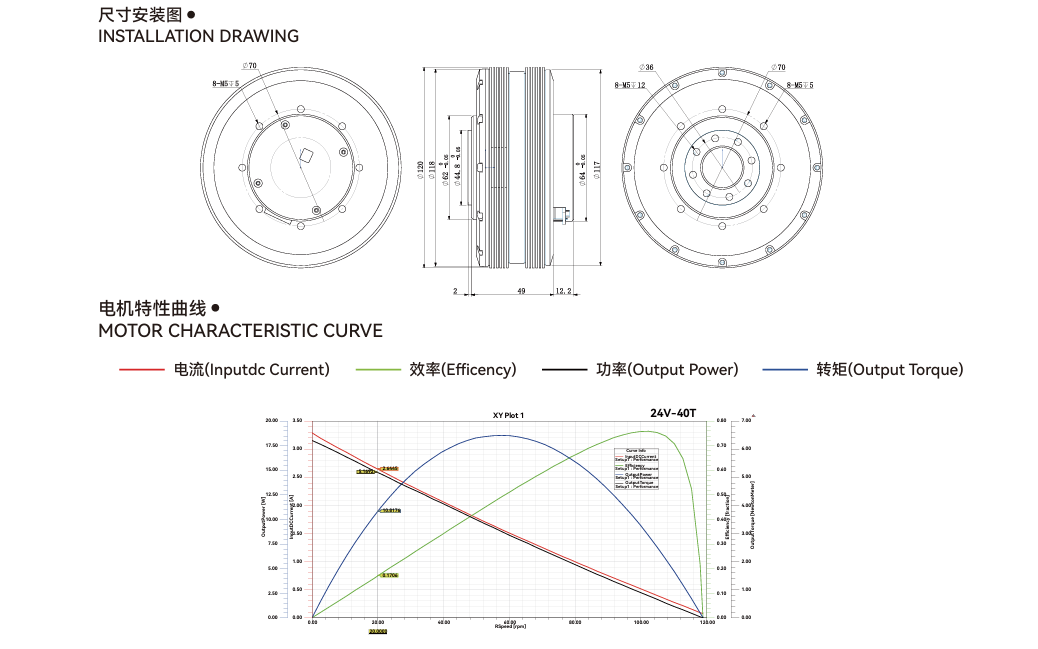
| Maximum Dimensions (mm) | Φ89*37 | Φ89*42 | Φ89*53 | Φ120*63.2 |
| Motor Model | K7028 | K7030 | K7050 |
| Rated Voltage (V) | 24 | 24 | 24 |
| Range Voltage (V) | 7.4-32 | 7.4-32 | 7.4-32 |
| Maximum Speed (rpm) | 23 / 45 | 10 / 23 / 45 | 10 / 28 / 45 |
| Rated Speed (rpm) | 1230 / 620 | 1890 / 805 / 410 | 1350 / 462 / 285 |
| Rated Torque (N.m) | 0.61 / 0.63 | 1 / 1 / 0.99 | 1.6 / 1.6 / 1.5 |
| Maximum Torque (N.m) | 2 / 2.1 | 2 / 3.8 / 2.42 | 2.1 / 2.9 / 2.7 |
| Motor Weight (g) | 278 | 352 | 526 |
| Maximum Dimensions (mm) | Φ69*28.9 | Φ69*33.9 | Φ69*46 |
K-Series Medium-to-High-Speed BLDC Motors
High-Performance FOC Servo Motors
Integrated, lightweight, high-precision, and high-torque design
Encoder resolution upgraded from 14-bit to 18-bit
Optimized cogging torque Supports PWM input
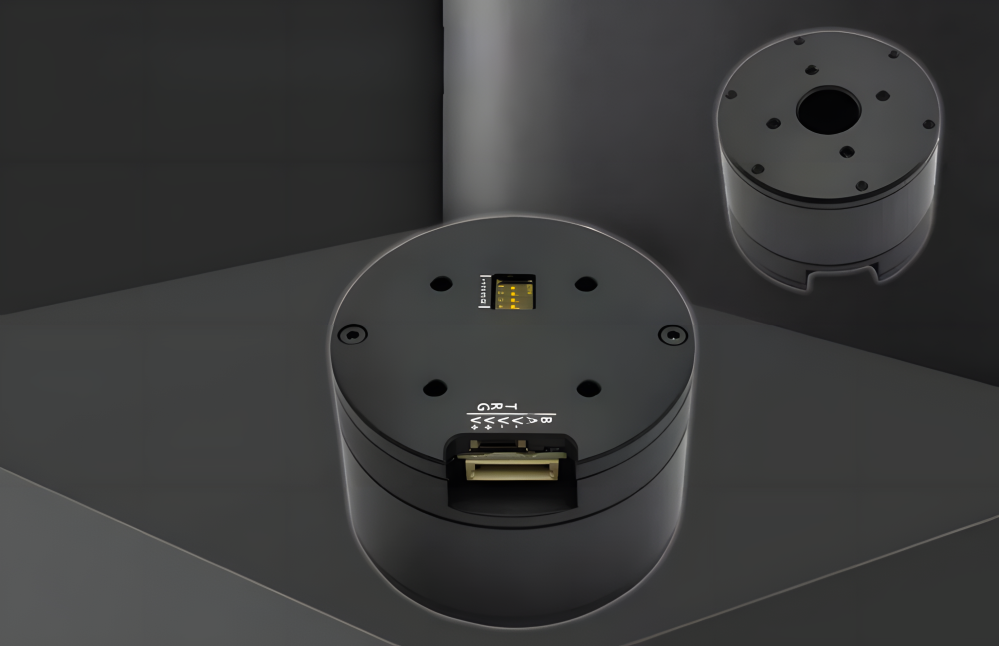
| Ultra-high standard product design |
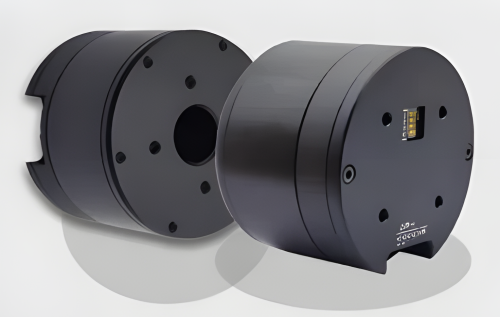
Integrated electric drive design
Built-in drive and magnetic encoder
Integration Integrated motor and drive design |
| High precision 14-bit absolute magnetic encode |
Lightweighting Low-profile design combined with aerospace-grade aluminum | High torque Outer-rotor design with NdFeB magnets |
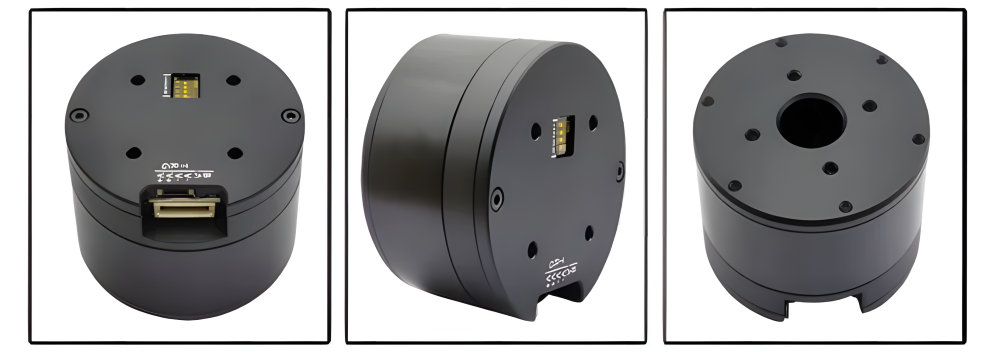
Actual photos of motor products — Quality guaranteed
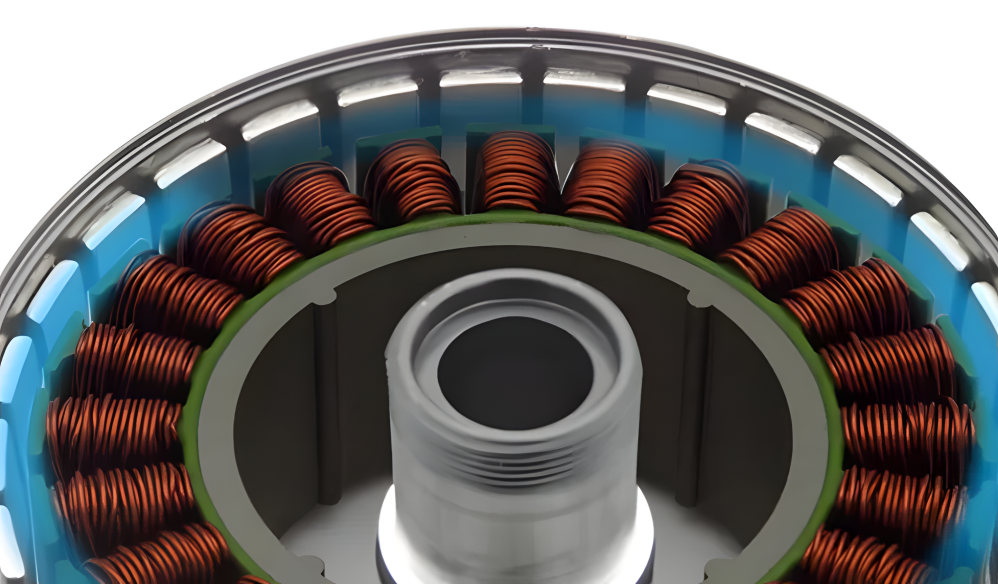
| Outer rotor | Low air gap |
| Multi-stage arc-shaped permanent magnets | Radially magnetized |
| Customizable winding | 0.2mm imported silicon steel laminations |
| SH-grade NdFeB | H-class high-temperature resistant copper wire |
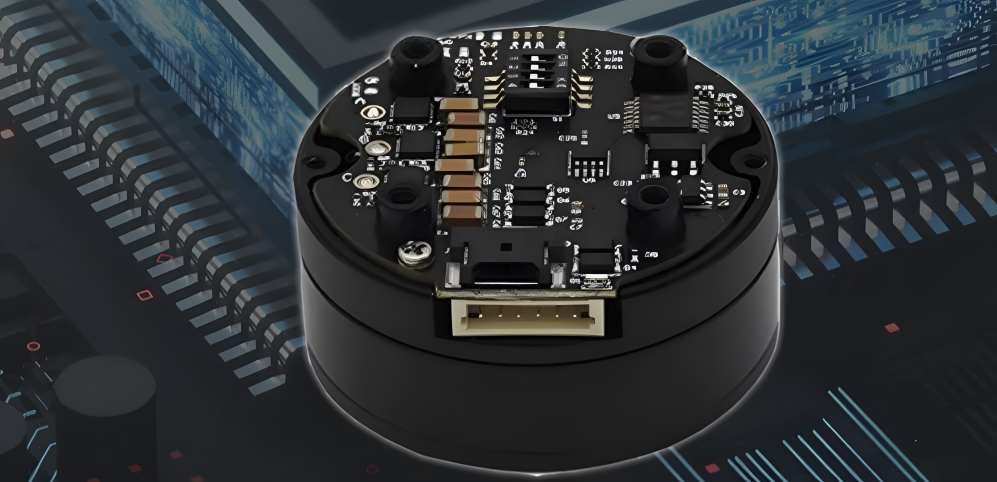
High-performance MCUs Factory Direct | Built-in driver board customization available |
Servo motors / Servo drives
Seamless switching between torque, speed, and position control modes
CAN or RS485 bus communication; supports direct control via PC, MCU, PLC, industrial PC, Raspberry Pi, or Arduino
High-performance 32-bit ARM Cortex-M4 core controller
Real-time monitoring of motor stator temperature
Three-phase full-bridge driver using all N-channel MOSFETs; features low internal resistance and high current capability
Precision current control using low-temperature-drift alloy resistors for accurate sensing
18-bit single-turn absolute magnetic encoder with factory calibration; zero-point position is permanently retained
API Definition Description
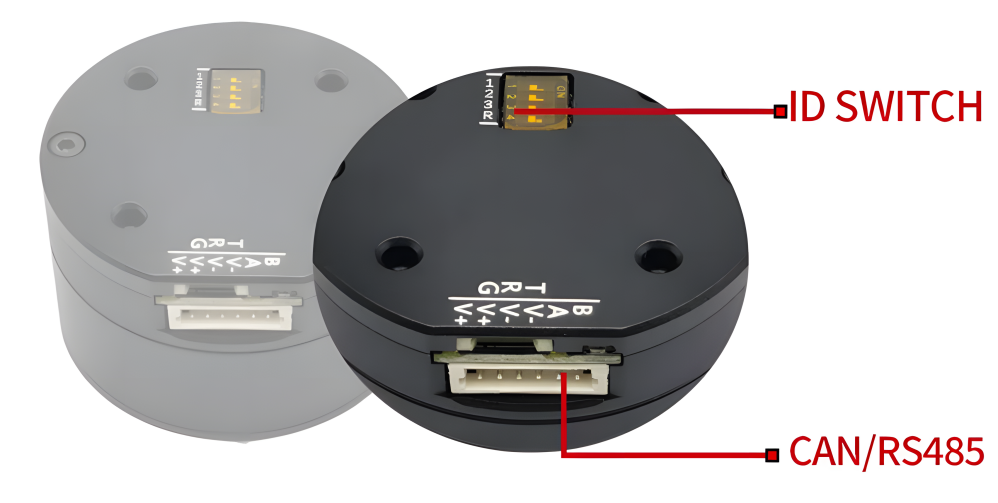
| Interface | Note |
| B/L | RS485-B or CAN-L |
| A/H | RS485-A or CAN-H |
| V- | Negative Power Supply |
| V- | Negative Power Supply |
| V+ | Positive Power Supply |
| V+ | Positive Power Supply |
| I | UART Transmitter |
| R | UART Receiver |
| G | Signal GND |
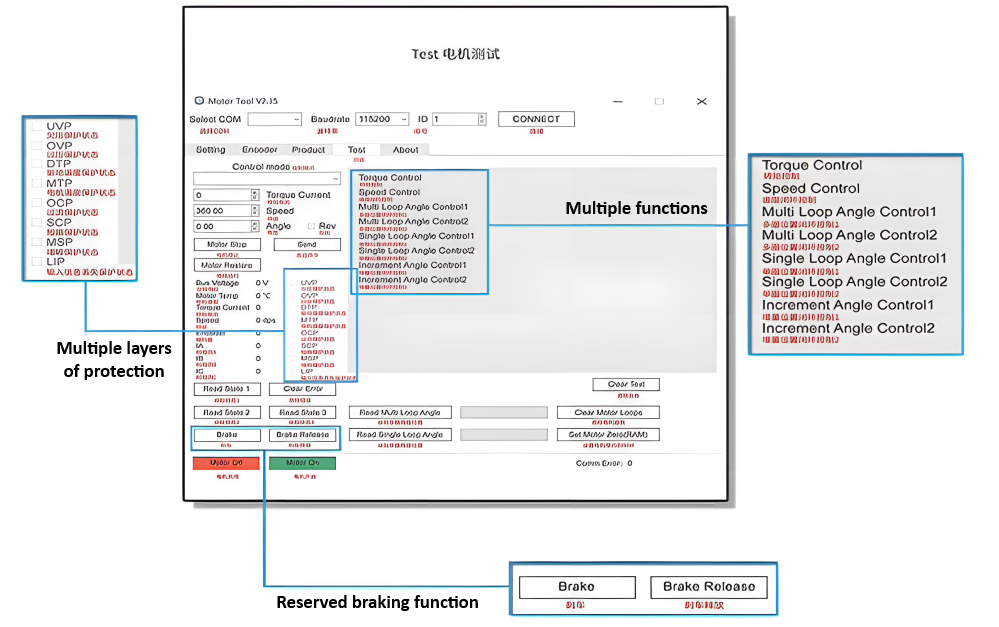
Supports host-side parameter tuning, testing, and firmware upgrades.
Compatible with open-source development platforms such as PC, MCU, PLC, industrial PCs, and Raspberry Pi.
Torque mode | Speed mode | Single-turn position + direction mode | Incremental position mode |
Multi-turn control mode (with speed limit) | Multi-turn control mode | Single-turn position + direction mode (with speed limit) | Incremental position mode (with speed limit) |
Multiple control modes
Application Scenarios
|
|
|
|
| 360° Camera | Handheld Camera | LiDAR | Gimbal Pod |
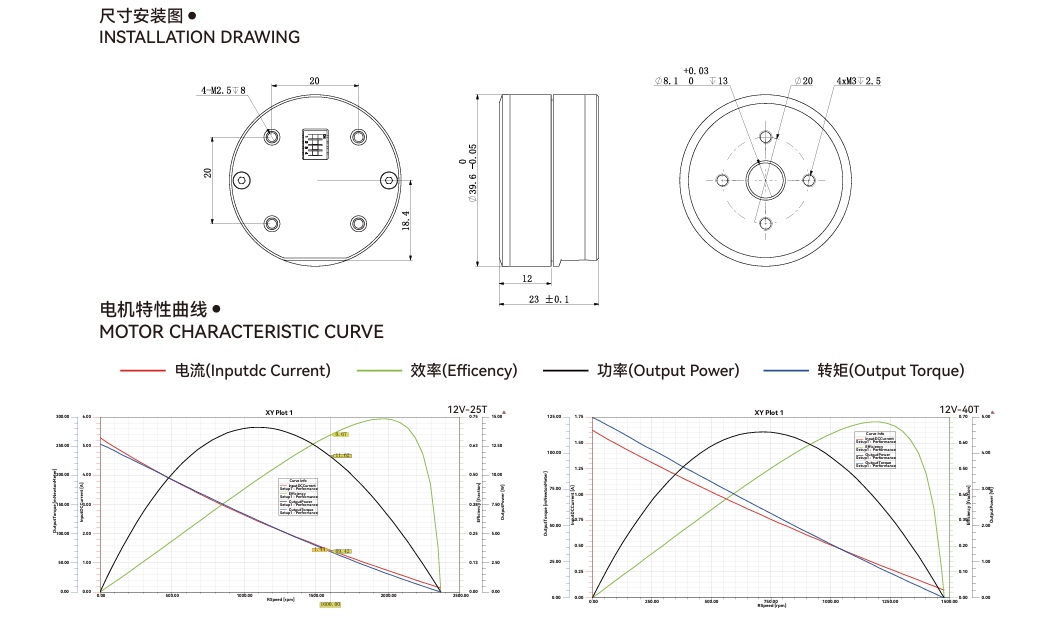
Parameter
Item Name | K4020 |
Turns | 25 / 40 |
Rated Voltage (V) | 12 / 12 |
Max Speed (rpm) | 2390 / 1300 |
Rated Torque (N.m) | 0.07 / 0.06 |
Rated Speed (rpm) | 1600 / 700 |
Rated Current (A) | 1.44 / 0.81 |
Max Power(W) | 14 / 4.6 |
Max Torque (N.m) | 0.25 / 0.12 |
Speed Constant (rpm/V) | 133 / 58 |
Torque Constant (N.m/A) | 0.05 / 0.07 |
Winding Type | Y / Y |
Line Resistance (Q) | 1.9 / 4.3 |
Phase Inductance (mH) | 0.5 / 1.2 |
Motor Poles | 26 |
Rotor Inertia (gcm²) | 56 |
Motor Temperature | YES |
Bearing Rated Load (N) | 140 |
Motor Weight (g) | 65 |
Recommand Drive | DF40V2 |
Drive Input Voltage (V) | 7.4~32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps) / CAN:2KHz(1Mbps) |
Encoder | 18 bit Magnetic Encoder |
Baudrate (RS485)(bps) | 9600, 19200, 57600, 115200, 230400, 406800, 1M, 2M |
Baudrate (CAN) (bps) | 100K, 125K, 250K, 500K, 1M |
Control Mode | Open Loop(24KHz) /Speed Loop(8KHz) /Position Loop(8KHz) |
Acceleration Curve | Trapeziod acceleration |
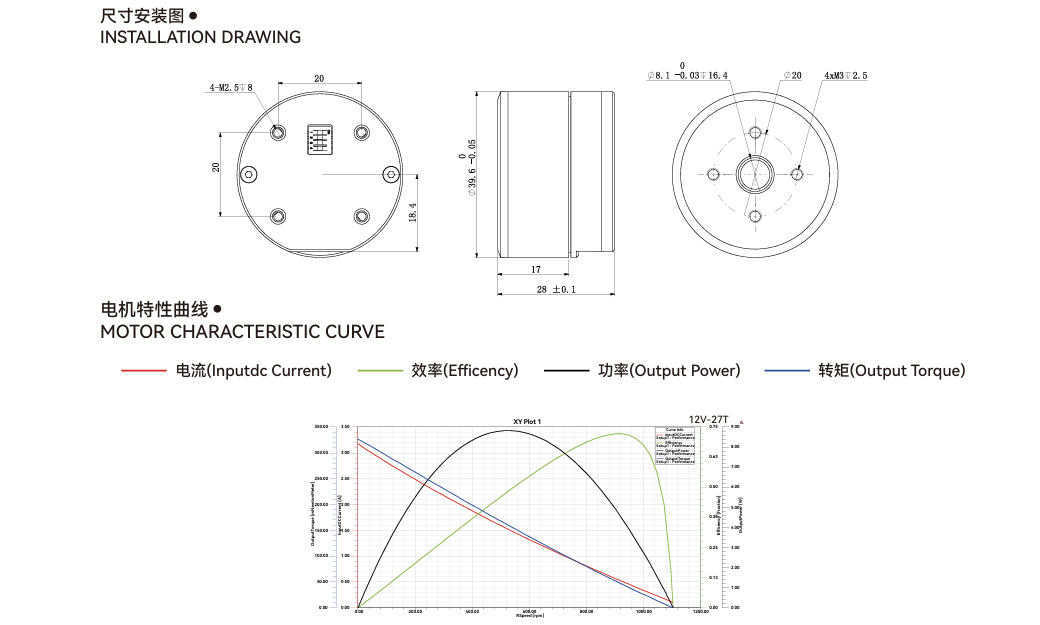
Item Name | K4030 |
Turns | 20 |
Rated Voltage (V) | 16 |
Max Speed (rpm) | 1350 |
Rated Torque (N.m) | 0.25 |
Rated Speed (rpm) | 750 |
Rated Current (A) | 2.2 |
Max Power(W) | 22 |
Max Torque (N.m) | 0.65 |
Speed Constant (rpm/V) | 46.9 |
Torque Constant (N.m/A) | 0.11 |
Winding Type | Y |
Line Resistance (Q) | 3 |
Phase Inductance (mH) | 1 |
Motor Poles | 26 |
Rotor Inertia (gcm²) | 81 |
Motor Temperature | YES |
Bearing Rated Load (N) | 140 |
Motor Weight (g) | 116 |
Recommand Drive | DF40V2 |
Drive Input Voltage (V) | 7.4~32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps) / CAN:2KHz(1Mbps) |
Encoder | 18 bit Magnetic Encoder |
Baudrate (RS485)(bps) | 9600, 19200, 57600, 115200, 230400, 406800, 1M, 2M |
Baudrate (CAN) (bps) | 100K, 125K, 250K, 500K, 1M |
Control Mode | Open Loop(24KHz) /Speed Loop(8KHz) /Position Loop(8KHz) |
Acceleration Curve | Trapeziod acceleration |
Item Name | K5020 |
Turns | 35 |
Rated Voltage (V) | 16 |
Max Speed (rpm) | 1700 |
Rated Torque (N.m) | 0.12 |
Rated Speed (rpm) | 1100 |
Rated Current (A) | 1.3 |
Max Power(W) | 15 |
Max Torque (N.m) | 0.4 |
Speed Constant (rpm/V) | 85 |
Torque Constant (N.m/A) | 0.08 |
Winding Type | Y |
Line Resistance (Q) | 3 |
Phase Inductance (mH) | 0.65 |
Motor Poles | 28 |
Rotor Inertia (gcm²) | 136 |
Motor Temperature | YES |
Bearing Rated Load (N) | 153 |
Motor Weight (g) | 104 |
Recommand Drive | DF40V2 |
Drive Input Voltage (V) | 7.4~32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps) / CAN:2KHz(1Mbps) |
Encoder | 18 bit Magnetic Encoder |
Baudrate (RS485)(bps) | 9600, 19200, 57600, 115200, 230400, 406800, 1M, 2M |
Baudrate (CAN) (bps) | 100K, 125K, 250K, 500K, 1M |
Control Mode | Open Loop(24KHz) /Speed Loop(8KHz) /Position Loop(8KHz) |
Acceleration Curve | Trapeziod acceleration |
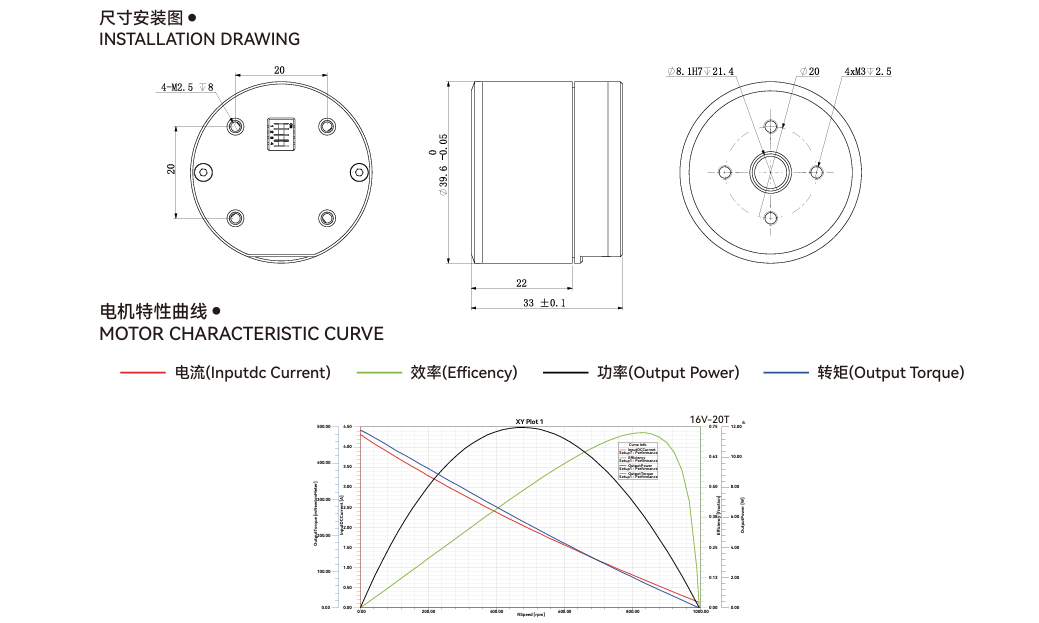
Item Name | K5028 |
Turns | 10 / 35 |
Rated Voltage (V) | 16 / 16 |
Max Speed (rpm) | 3050 / 870 |
Rated Torque (N.m) | 0.26 / 0.24 |
Rated Speed (rpm) | 2400 / 440 |
Rated Current (A) | 5.06 / 1.35 |
Max Power(W) | 128 / 12 |
Max Torque (N.m) | 0.4 / 0.53 |
Speed Constant (rpm/V) | 150 / 27.5 |
Torque Constant (N.m/A) | 0.05 / 0.18 |
Winding Type | Y / Y |
Line Resistance (Q) | 0.33 / 3.2 |
Phase Inductance (mH) | 0.13 / 1.2 |
Motor Poles | 28 |
Rotor Inertia (gcm²) | 202 |
Motor Temperature | YES |
Bearing Rated Load (N) | 153 |
Motor Weight (g) | 137 |
Recommand Drive | DF40V2 |
Drive Input Voltage (V) | 7.4~32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps) / CAN:2KHz(1Mbps) |
Encoder | 18 bit Magnetic Encoder |
Baudrate (RS485)(bps) | 9600, 19200, 57600, 115200, 230400, 406800, 1M, 2M |
Baudrate (CAN) (bps) | 100K, 125K, 250K, 500K, 1M |
Control Mode | Open Loop(24KHz) /Speed Loop(8KHz) /Position Loop(8KHz) |
Acceleration Curve | Trapeziod acceleration |
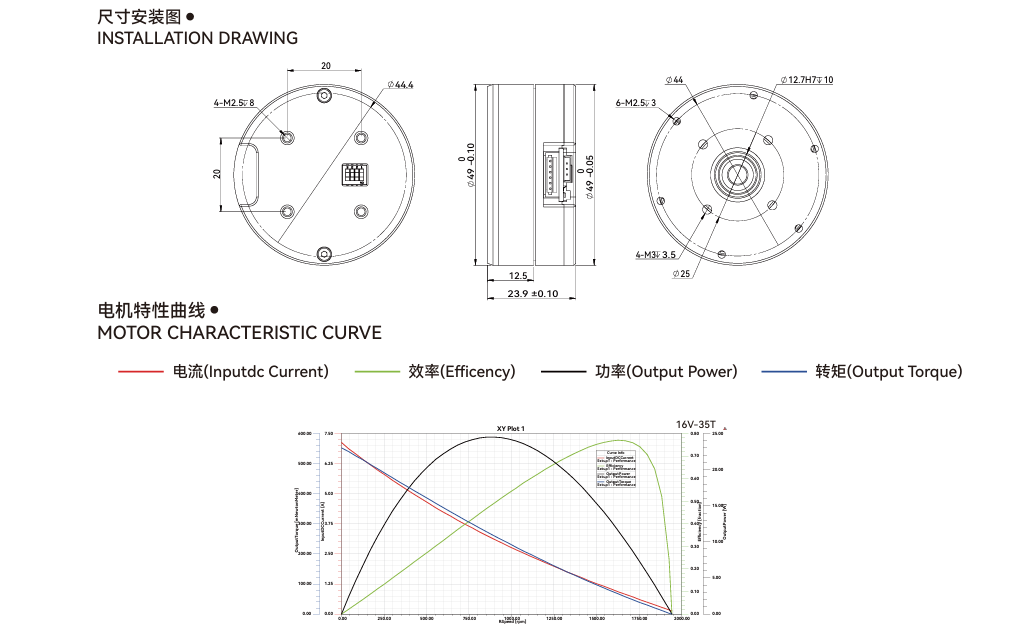
Item Name | K5030 |
Turns | 10 / 35 |
Rated Voltage (V) | 16 / 16 |
Max Speed (rpm) | 2040 / 580 |
Rated Torque (N.m) | 0.38 / 0.32 |
Rated Speed (rpm) | 1550 / 250 |
Rated Current (A) | 4.9 / 1.22 |
Max Power(W) | 104 / 8.8 |
Max Torque (N.m) | 0.7 / 0.82 |
Speed Constant (rpm/V) | 97 / 15.6 |
Torque Constant (N.m/A) | 0.08 / 0.26 |
Winding Type | Y / Y |
Line Resistance (Q) | 0.48 / 4 |
Phase Inductance (mH) | 0.19 / 1.76 |
Motor Poles | 28 |
Rotor Inertia (gcm²) | 202 |
Motor Temperature | YES |
Bearing Rated Load (N) | 153 |
Motor Weight (g) | 175 |
Recommand Drive | DF40V2 |
Drive Input Voltage (V) | 7.4~32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps) / CAN:2KHz(1Mbps) |
Encoder | 18 bit Magnetic Encoder |
Baudrate (RS485)(bps) | 9600, 19200, 57600, 115200, 230400, 406800, 1M, 2M |
Baudrate (CAN) (bps) | 100K, 125K, 250K, 500K, 1M |
Control Mode | Open Loop(24KHz) /Speed Loop(8KHz) /Position Loop(8KHz) |
Acceleration Curve | Trapeziod acceleration |
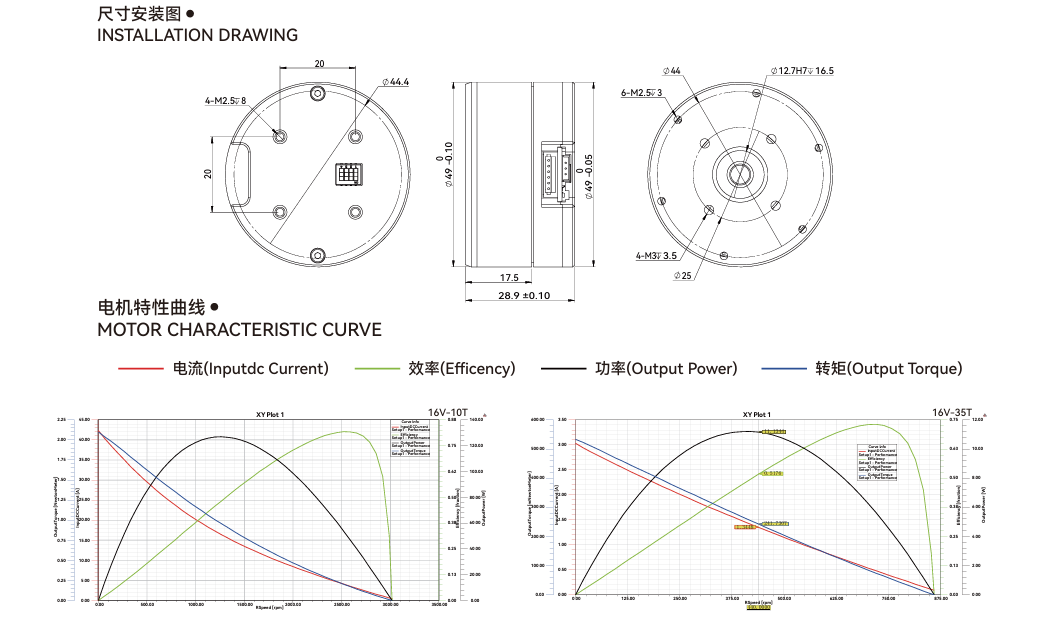
Item Name | K5034 |
Turns | 35 |
Rated Voltage (V) | 16 |
Max Speed (rpm) | 580 |
Rated Torque (N.m) | 0.32 |
Rated Speed (rpm) | 250 |
Rated Current (A) | 1.22 |
Max Power(W) | 8.8 |
Max Torque (N.m) | 0.82 |
Speed Constant (rpm/V) | 15.6 |
Torque Constant (N.m/A) | 0.26 |
Winding Type | Y |
Line Resistance (Q) | 1.76 |
Phase Inductance (mH) | 28 |
Motor Poles | 28 |
Rotor Inertia (gcm²) | 202 |
Motor Temperature | YES |
Bearing Rated Load (N) | 153 |
Motor Weight (g) | 175 |
Recommand Drive | DF40V2 |
Drive Input Voltage (V) | 7.4~32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps) / CAN:2KHz(1Mbps) |
Encoder | 19 bit Magnetic Encoder |
Baudrate (RS485)(bps) | 9600, 19200, 57600, 115200, 230400, 406800, 1M, 2M |
Baudrate (CAN) (bps) | 100K, 125K, 250K, 500K, 1M |
Control Mode | Open Loop(24KHz) /Speed Loop(8KHz) /Position Loop(8KHz) |
Acceleration Curve | Trapeziod acceleration |
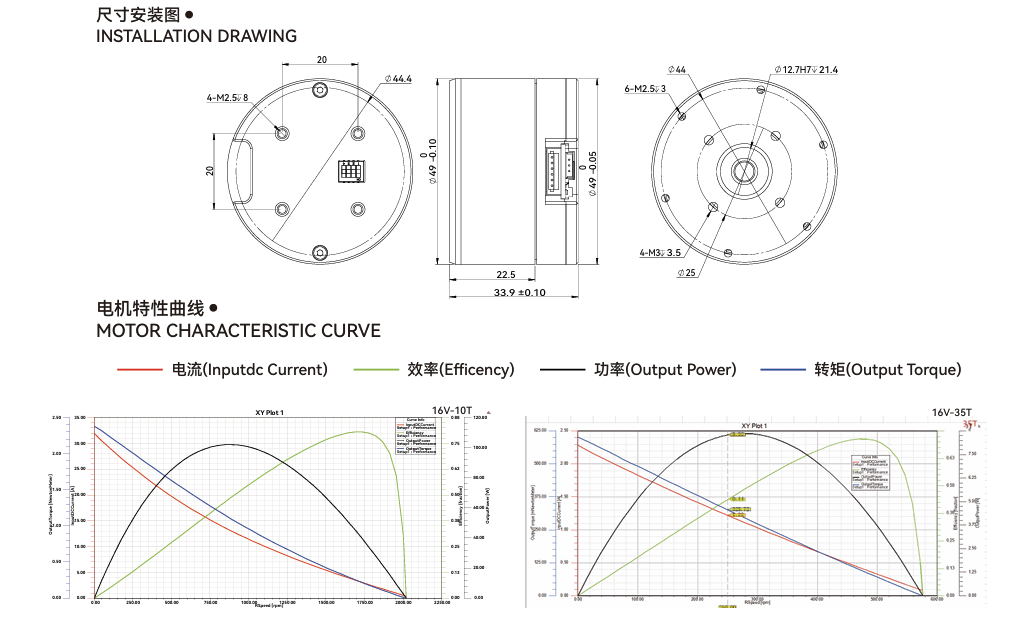
Item Name | K6020 |
Turns | 15 / 25 |
Rated Voltage (V) | 24 / 24 |
Max Speed (rpm) | 2200 / 1280 |
Rated Torque (N.m) | 0.55 / 0.55 |
Rated Speed (rpm) | 1700 / 900 |
Rated Current (A) | 3.1 / 5.3 |
Max Power(W) | 175 / 70 |
Max Torque (N.m) | 4 / 2.7 |
Speed Constant (rpm/V) | 71 / 37.5 |
Torque Constant (N.m/A) | 0.18 / 0.10 |
Winding Type | Y / Y |
Line Resistance (Q) | 0.65 / 1.59 |
Phase Inductance (mH) | 0.34 / 0.99 |
Motor Poles | 28 |
Rotor Inertia (gcm²) | 394 |
Motor Temperature | YES |
Bearing Rated Load (N) | 280 |
Motor Weight (g) | 193 |
Recommand Drive | DF40V2 |
Drive Input Voltage (V) | 7.4~32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps) / CAN:2KHz(1Mbps) |
Encoder | 18 bit Magnetic Encoder |
Baudrate (RS485)(bps) | 9600, 19200, 57600, 115200, 230400, 406800, 1M, 2M |
Baudrate (CAN) (bps) | 100K, 125K, 250K, 500K, 1M |
Control Mode | Open Loop(24KHz) /Speed Loop(8KHz) /Position Loop(4KHz) |
Acceleration Curve | Trapeziod acceleration |
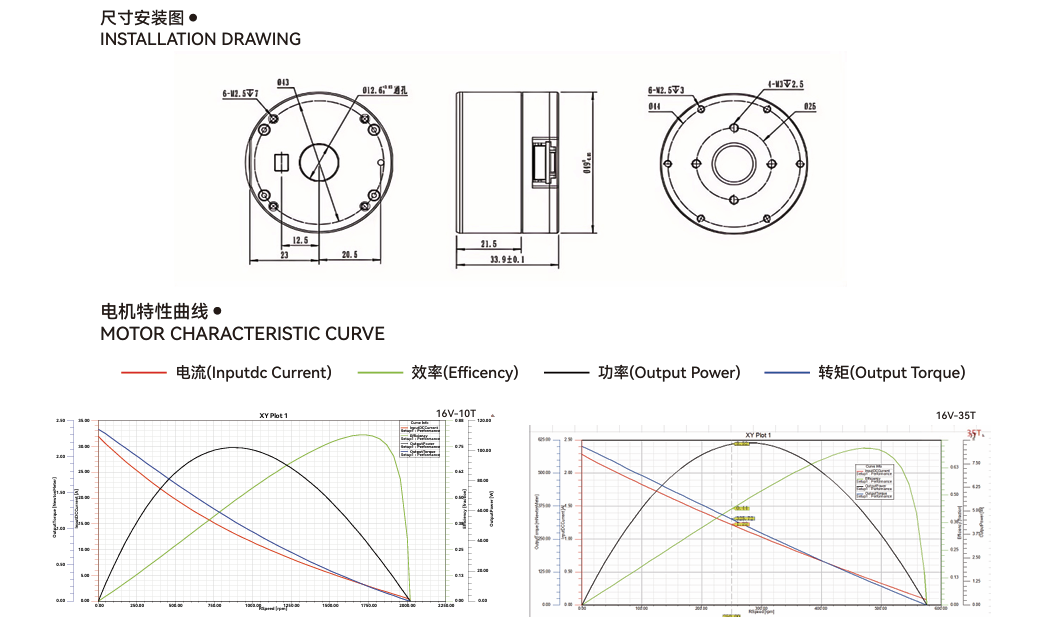
Item Name | K6030 |
Turns | 15 / 25 |
Rated Voltage (V) | 24 / 24 |
Max Speed (rpm) | 1650 / 872 |
Rated Torque (N.m) | 0.81 / 0.82 |
Rated Speed (rpm) | 1260 / 560 |
Rated Current (A) | 5.87 / 3.1 |
Max Power(W) | 185 / 57 |
Max Torque (N.m) | 5.5 / 3 |
Speed Constant (rpm/V) | 53 / 23.3 |
Torque Constant (N.m/A) | 0.14 / 0.26 |
Winding Type | Y / Y |
Line Resistance (Q) | 0.89 / 2.17 |
Phase Inductance (mH) | 0.49 / 1.44 |
Motor Poles | 28 |
Rotor Inertia (gcm²) | 515 |
Motor Temperature | YES |
Bearing Rated Load (N) | 280 |
Motor Weight (g) | 251 |
Recommand Drive | DF40V2 |
Drive Input Voltage (V) | 7.4~32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps) / CAN:2KHz(1Mbps) |
Encoder | 18 bit Magnetic Encoder |
Baudrate (RS485)(bps) | 9600, 19200, 57600, 115200, 230400, 406800, 1M, 2M |
Baudrate (CAN) (bps) | 100K, 125K, 250K, 500K, 1M |
Control Mode | Open Loop(24KHz) /Speed Loop(8KHz) /Position Loop(4KHz) |
Acceleration Curve | Trapeziod acceleration |
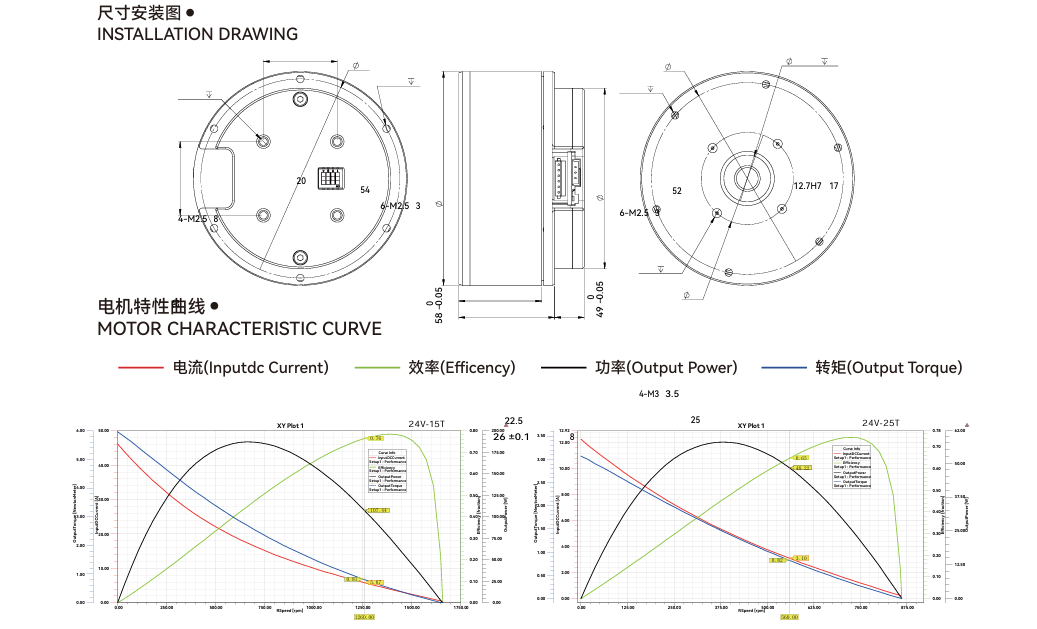
Item Name | K7028 |
Turns | 23 / 45 |
Rated Voltage (V) | 24 / 24 |
Max Speed (rpm) | 1230 / 620 |
Rated Torque (N.m) | 0.61 / 0.63 |
Rated Speed (rpm) | 940 / 400 |
Rated Current (A) | 3.3 / 1.75 |
Max Power(W) | 104 / 31 |
Max Torque (N.m) | 2 / 2.1 |
Speed Constant (rpm/V) | 39 / 16.7 |
Torque Constant (N.m/A) | 0.18 / 0.36 |
Winding Type | Y / Y |
Line Resistance (Q) | 0.71 / 0.23 |
Phase Inductance (mH) | 0.86 / 3.3 |
Motor Poles | 28 |
Rotor Inertia (gcm²) | 748 |
Motor Temperature | YES |
Bearing Rated Load (N) | 330 |
Motor Weight (g) | 278 |
Recommand Drive | DF70V2 |
Drive Input Voltage (V) | 7.4~32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps) / CAN:2KHz(1Mbps) |
Encoder | 18 bit Magnetic Encoder |
Baudrate (RS485)(bps) | 9600, 19200, 57600, 115200, 230400, 406800, 1M, 2M |
Baudrate (CAN) (bps) | 100K, 125K, 250K, 500K, 1M |
Control Mode | Open Loop(24KHz) /Speed Loop(8KHz) /Position Loop(8KHz) |
Acceleration Curve | Trapeziod acceleration |
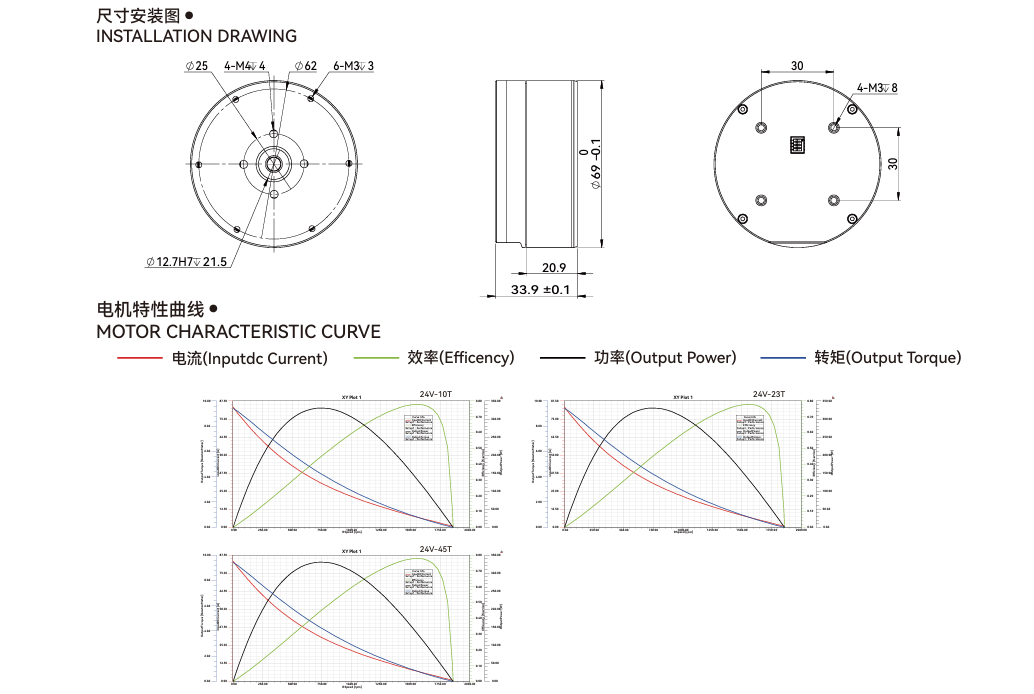
Item Name | K7030 |
Turns | 10 / 23 / 45 |
Rated Voltage (V) | 24 / 24 / 24 |
Max Speed (rpm) | 1890 / 805 / 410 |
Rated Torque (N.m) | 1 / 1 / 0.99 |
Rated Speed (rpm) | 1500 / 580 / 220 |
Rated Current (A) | 8.3 / 3.62 / 1.93 |
Max Power(W) | 330 / 75 / 24.5 |
Max Torque (N.m) | 2 / 3.8 / 2.42 |
Speed Constant (rpm/V) | 63 / 24.2 / 9.2 |
Torque Constant (N.m/A) | 0.12 / 0.28 / 0.51 |
Winding Type | Y / Y / Y |
Line Resistance (Q) | 0.28 / 1.14 / 3.9 |
Phase Inductance (mH) | 0.24 / 1.14 / 3.9 |
Motor Poles | 28 |
Rotor Inertia (gcm²) | 933 |
Motor Temperature | YES |
Bearing Rated Load (N) | 330 |
Motor Weight (g) | 352 |
Recommand Drive | DF70V2 |
Drive Input Voltage (V) | 7.4~32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps) / CAN:2KHz(1Mbps) |
Encoder | 18 bit Magnetic Encoder |
Baudrate (RS485)(bps) | 9600, 19200, 57600, 115200, 230400, 406800, 1M, 2M |
Baudrate (CAN) (bps) | 100K, 125K, 250K, 500K, 1M |
Control Mode | Open Loop(24KHz) /Speed Loop(8KHz) /Position Loop(8KHz) |
Acceleration Curve | Trapeziod acceleration |
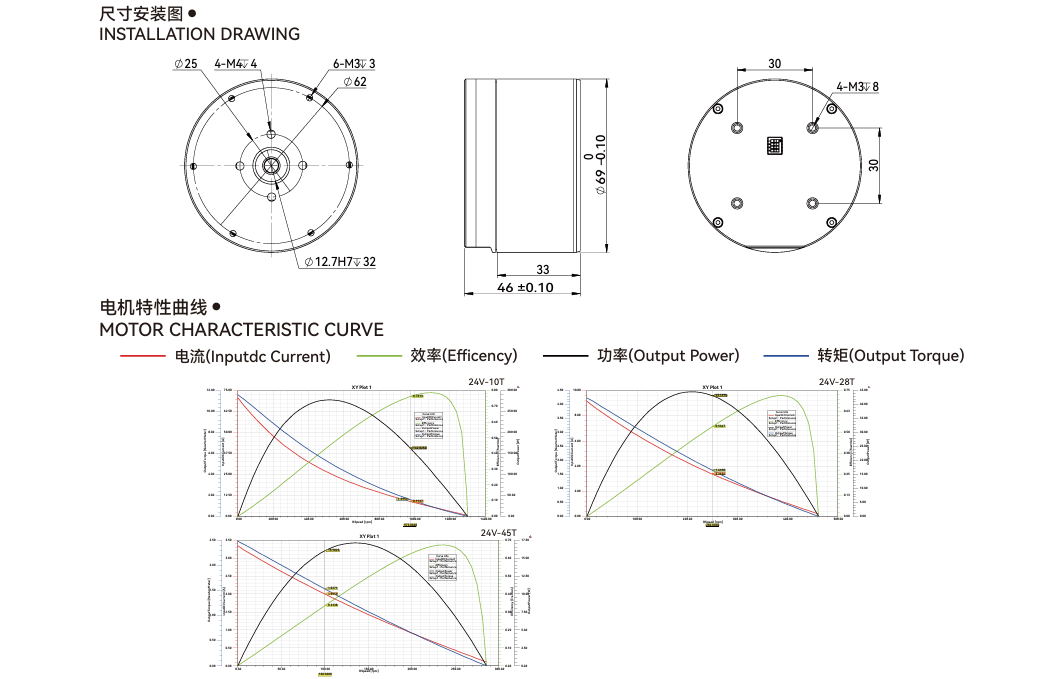
Item Name | K7050 |
Turns | 10 / 28 / 45 |
Rated Voltage (V) | 24 / 24 / 24 |
Max Speed (rpm) | 1350 / 462 / 285 |
Rated Torque (N.m) | 1.6 / 1.6 / 1.5 |
Rated Speed (rpm) | 970 / 250 / 100 |
Rated Current (A) | 8.9 / 3.36 / 2 |
278 / 44 / 17.5 | |
Max Torque (N.m) | 2.1 / 2.9 / 2.7 |
Speed Constant (rpm/V) | 40 / 10.4 / 4.2 |
Torque Constant (N.m/A) | 0.18 / 0.48 / 0.75 |
Winding Type | Y / Y / Y |
Line Resistance (Q) | 0.28 / 2.2 / 5.5 |
Phase Inductance (mH) | 0.24 / 2.95 / 7.6 |
Motor Poles | 28 |
Rotor Inertia (gcm²) | 1040 |
Motor Temperature | YES |
Bearing Rated Load (N) | 330 |
Motor Weight (g) | 526 |
Recommand Drive | DF70V2 |
Drive Input Voltage (V) | 7.4~32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps) / CAN:2KHz(1Mbps) |
Encoder | 18 bit Magnetic Encoder |
Baudrate (RS485)(bps) | 9600, 19200, 57600, 115200, 230400, 406800, 1M, 2M |
Baudrate (CAN) (bps) | 100K, 125K, 250K, 500K, 1M |
Control Mode | Open Loop(24KHz) /Speed Loop(8KHz) /Position Loop(8KHz) |
Acceleration Curve | Trapeziod acceleration |
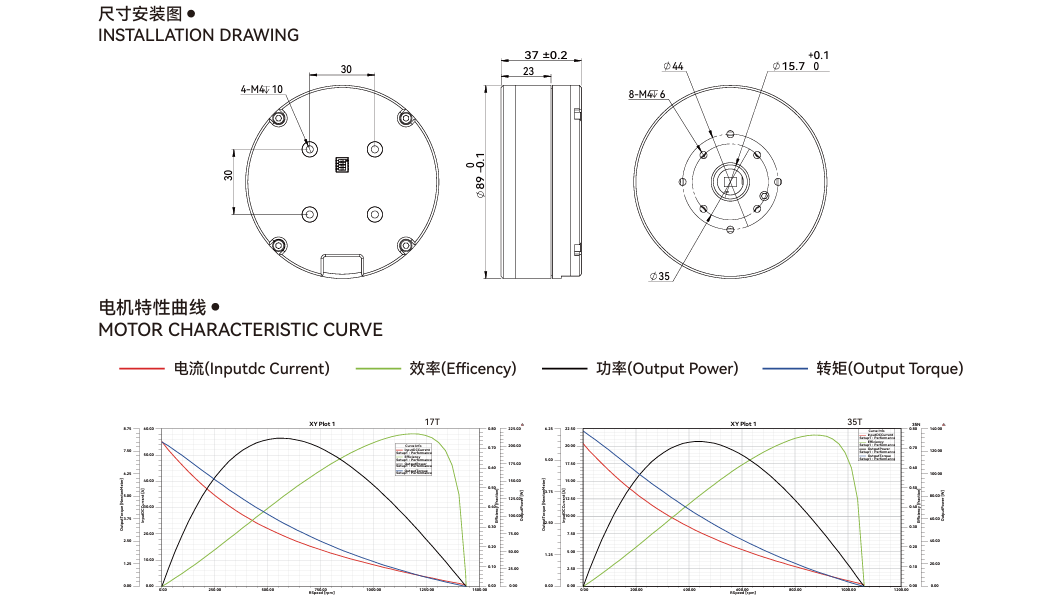
Item Name | K9030 |
Turns | 17 / 35 |
Rated Voltage (V) | 24 / 24 |
Max Speed (rpm) | 1465 / 690 |
Rated Torque (N.m) | 1.09 / 1.07 |
Rated Speed (rpm) | 1080 / 450 |
Rated Current (A) | 6.66 / 3.27 |
215 / 128 | |
Max Torque (N.m) | 2.2 / 4.1 |
Speed Constant (rpm/V) | 45 / 18.8 |
Torque Constant (N.m/A) | 0.16 / 0.33 |
Winding Type | Y / Y |
Line Resistance (Q) | 0.29 / 1.15 |
Phase Inductance (mH) | 0.53 / 3 |
Motor Poles | 28 |
Rotor Inertia (gcm²) | 2860 |
Motor Temperature | YES |
Bearing Rated Load (N) | 650 |
Motor Weight (g) | 525 |
Recommand Drive | DF70V2 |
Drive Input Voltage (V) | 7.4~32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps) / CAN:2KHz(1Mbps) |
Encoder | 18 bit Magnetic Encoder |
Baudrate (RS485)(bps) | 9600, 19200, 57600, 115200, 230400, 406800, 1M, 2M |
Baudrate (CAN) (bps) | 1M |
Control Mode | Open Loop(24KHz) /Speed Loop(8KHz) /Position Loop(8KHz) |
Acceleration Curve | Trapeziod acceleration |
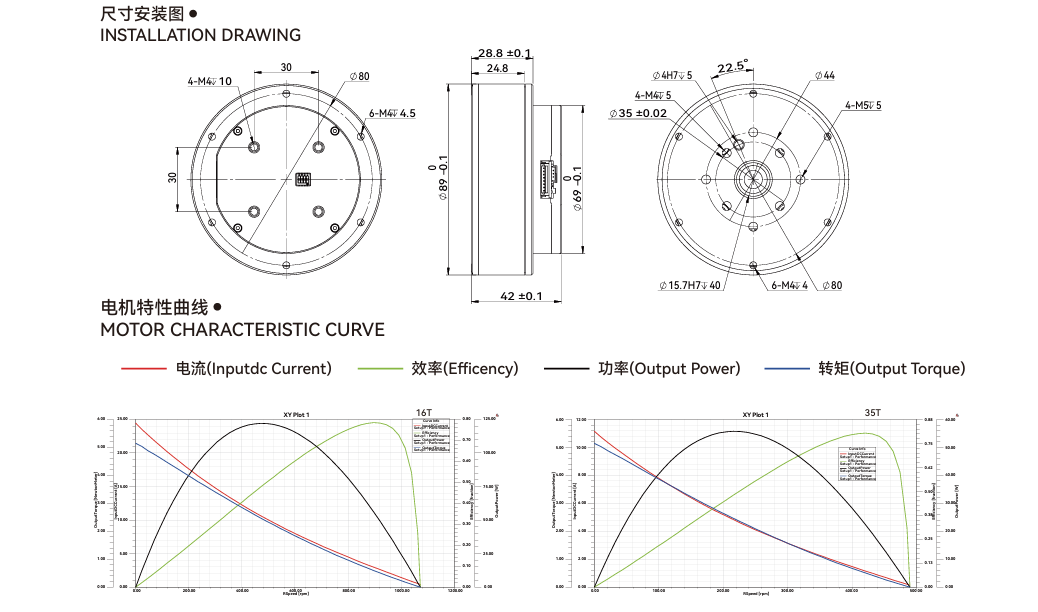
Item Name | K9040 |
Turns | 16 / 35 |
Rated Voltage (V) | 24 / 24 |
Max Speed (rpm) | 1085 / 500 |
Rated Torque (N.m) | 1.63 / 1.67 |
Rated Speed (rpm) | 780 / 290 |
Rated Current (A) | 7.03 / 3.34 |
120 / 55 | |
Max Torque (N.m) | 3.4 / 5 |
Speed Constant (rpm/V) | 33 / 12.1 |
Torque Constant (N.m/A) | 0.23 / 0.50 |
Winding Type | Y / Y |
Line Resistance (Q) | 0.35 / 0.51 |
Phase Inductance (mH) | 0.65 / 1.05 |
Motor Poles | 28 |
Rotor Inertia (gcm²) | 3271 |
Motor Temperature | YES |
Bearing Rated Load (N) | 650 |
Motor Weight (g) | 660 |
Recommand Drive | DF70V2 |
Drive Input Voltage (V) | 7.4~32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps) / CAN:2KHz(1Mbps) |
Encoder | 18 bit Magnetic Encoder |
Baudrate (RS485)(bps) | 9600, 19200, 57600, 115200, 230400, 406800, 1M, 2M |
Baudrate (CAN) (bps) | 1M |
Control Mode | Open Loop(24KHz) /Speed Loop(8KHz) /Position Loop(8KHz) |
Acceleration Curve | Trapeziod acceleration |
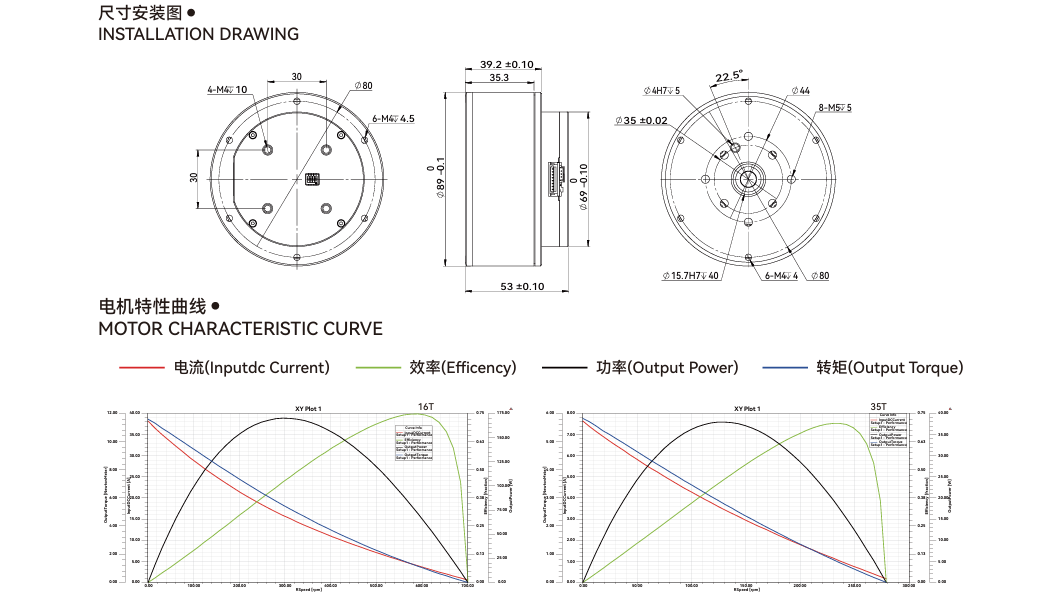
Item Name | K12060 |
Turns | 20 |
Rated Voltage (V) | 24 |
Max Speed (rpm) | 250 |
Rated Torque (N.m) | 5 |
Rated Speed (rpm) | 115 |
Rated Current (A) | 4 |
60 | |
Max Torque (N.m) | 10 |
Speed Constant (rpm/V) | 4.8 |
Torque Constant (N.m/A) | 1.25 |
Winding Type | Y |
Line Resistance (Q) | 2.4 |
Phase Inductance (mH) | 5 |
Motor Poles | 42 |
Rotor Inertia (gcm²) | 5500 |
Motor Temperature | YES |
Bearing Rated Load (N) | 1560 |
Motor Weight (g) | 1147 |
Recommand Drive | DF70V2 |
Drive Input Voltage (V) | 7.4~32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps) / CAN:2KHz(1Mbps) |
Encoder | 18 bit Magnetic Encoder |
Baudrate (RS485)(bps) | 9600, 19200, 57600, 115200, 230400, 406800, 1M, 2M |
Baudrate (CAN) (bps) | 100K, 125K, 250K, 500K, 1M |
Control Mode | Open Loop(24KHz) /Speed Loop(8KHz) /Position Loop(8KHz) |
Acceleration Curve | Trapeziod acceleration |