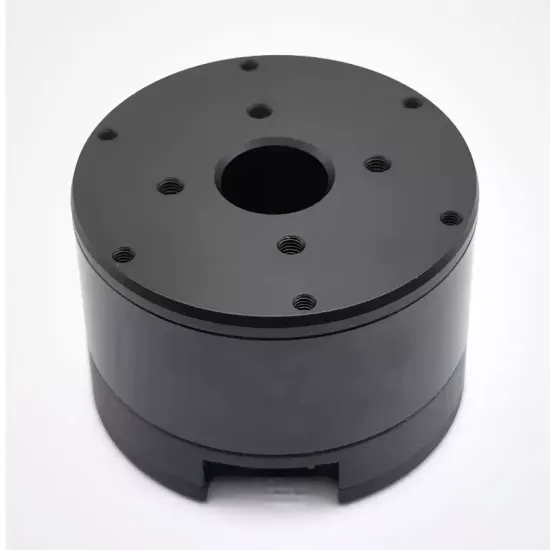
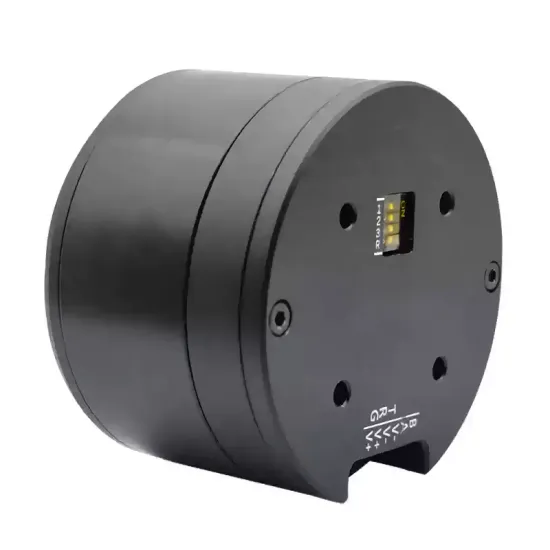
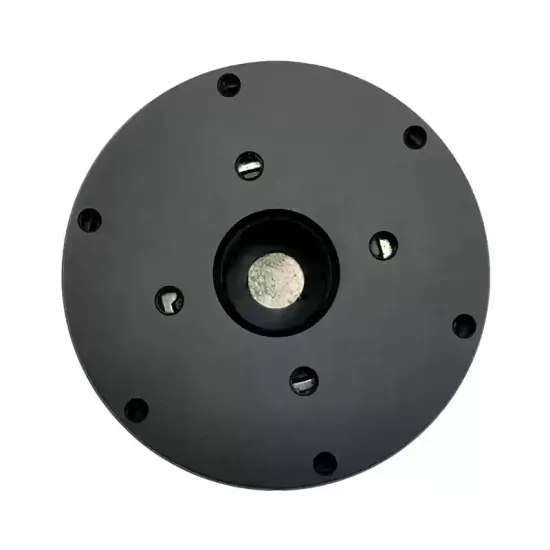
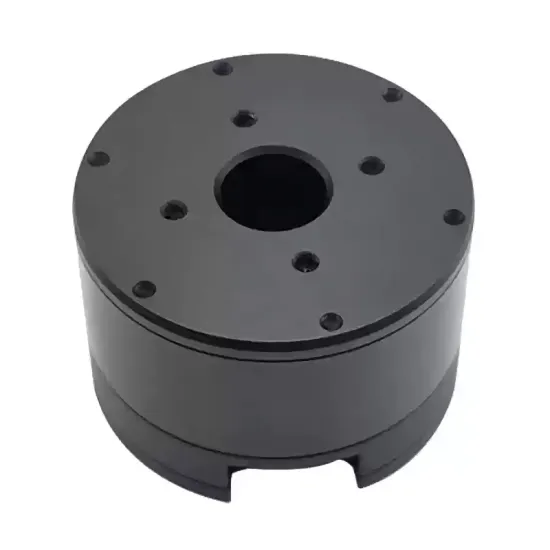


Characteristics of Integrated Electric Drive Motors
The high-performance 32-bit MCU enables the MS series to be fully compatible with all control commands of the MF series.
Meets the requirements for low-speed, high-precision position control.
1.The motor's core materials consist of high-quality silicon steel sheets and high-temperature resistant, high-strength permanent magnets. |
4.High-precision, low-temperature-drift alloy resistors for precise current control. |
2.Outer-rotor, multi-stage, low-profile design delivers higher torque, suitable for space-constrained applications. |
5.Three-phase full-bridge driver using all N-channel MOSFETs; features low internal resistance and high current capability. |
3.The brushless design, combined with high-performance bearings, ensures smoother rotation and a longer lifespan. |
6.Seamless switching between torque (open-loop), speed, and position control modes. |
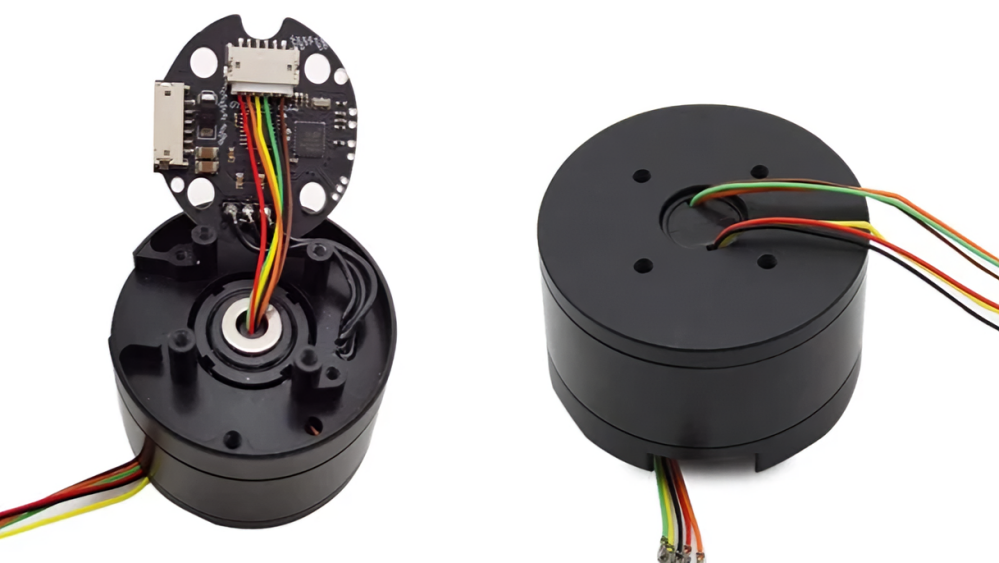
Slip ring demonstration diagram
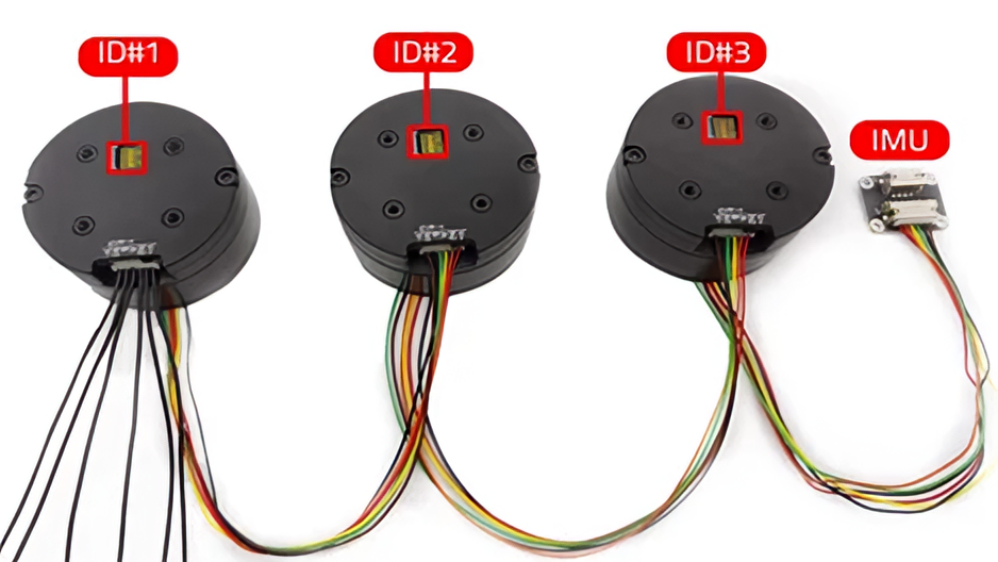
Series connection of multiple motors
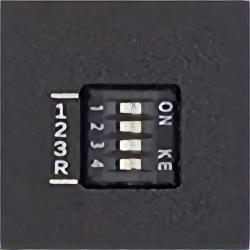
| ID | Switch 3 | Switch 2 | Switch 1 |
#1 | OFF | OFF | OFF | |
#2 | OFF | OFF | ON | |
#3 | OFF | ON | OFF | |
#4 | OFF | ON | ON | |
#5 | ON | OFF | OFF | |
#6 | ON | OFF | ON | |
#7 | ON | ON | OFF | |
#8 | ON | ON | ON |
High-Performance MCU Direct from Manufacturer | Built-in driver board Customization supported |
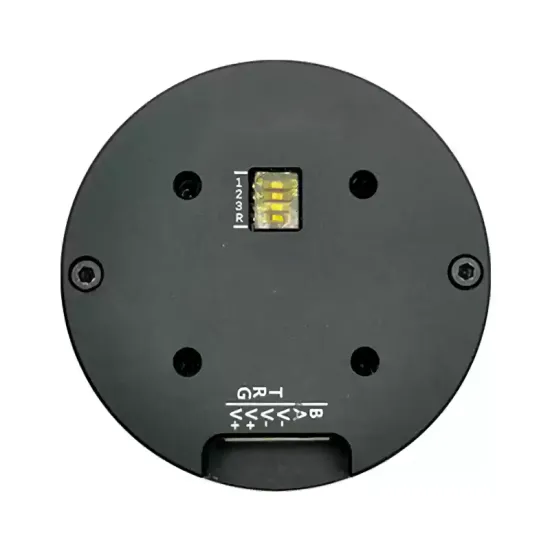
API Definition Description
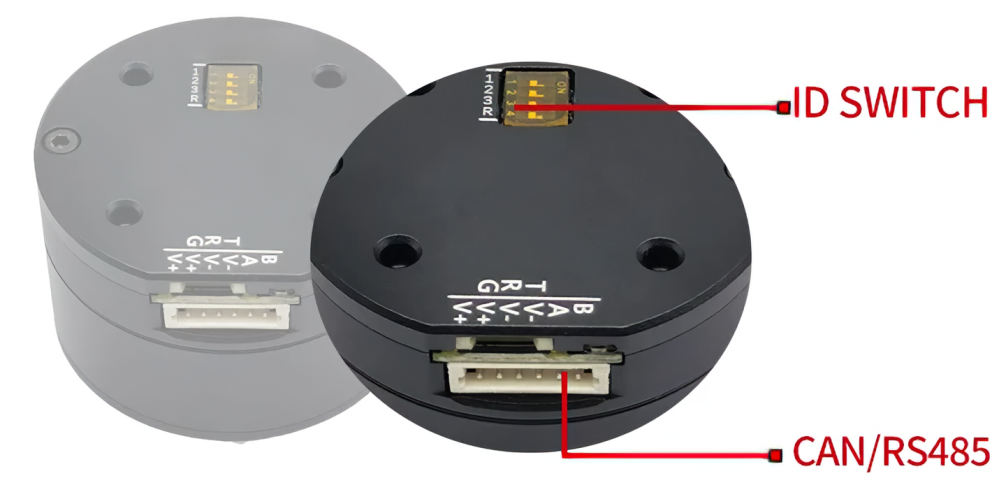
Interface | NOTE |
B/L | RS485-B Or CAN-L |
A/H | RS485-A Or CAN-H |
V- | Negative Power Supply |
V- | Negative Power Supply |
V+ | Positive Power Supply |
V+ | Positive Power Supply |
I | UARTTransmitter |
R | UART Receiver |
G | SignalGND |
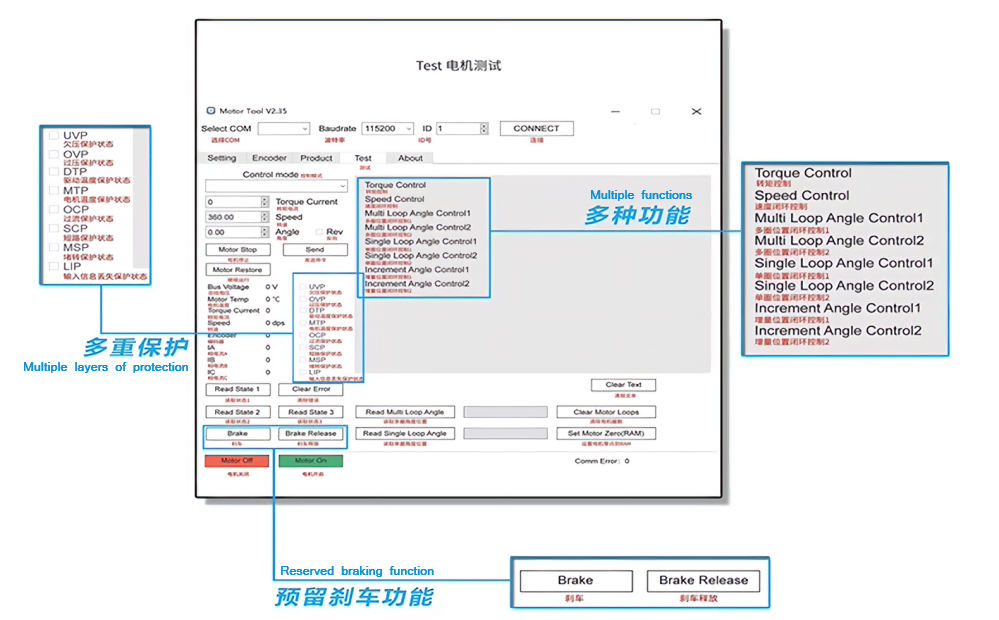
Supports parameter tuning, testing, and firmware upgrades via a host computer.
Supports open-source development platforms such as PC, MCU, PLC, industrial PCs, and Raspberry Pi.
Torque mode Speed Mode Multi-turn control mode Single-turn position + direction mode Incremental position mode Multi-turn control mode (with speed limit)
Single-turn position + direction mode (with speed limit) Incremental position mode (with speed limit)
Multiple control modes
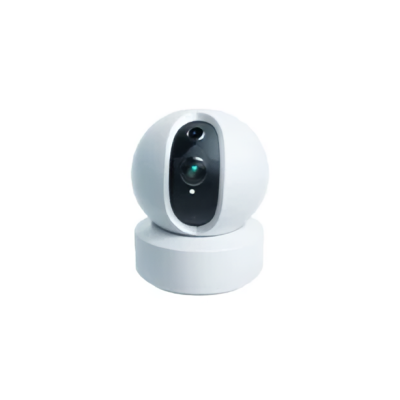
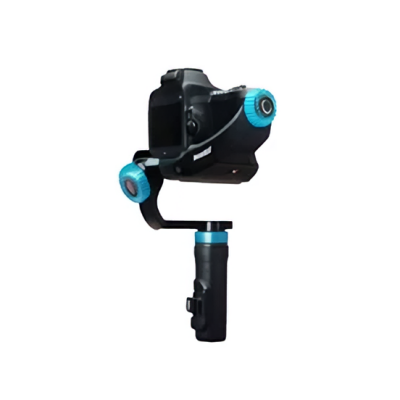
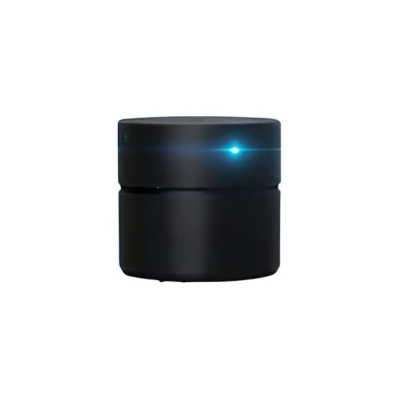
Application Scenarios
|
|
|
|
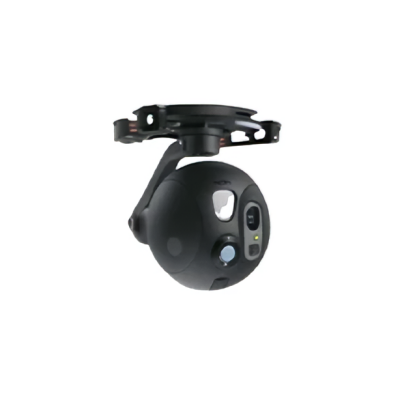
| 360° camera | Handheld camera | LiDAR | Pod-mounted gimbal |
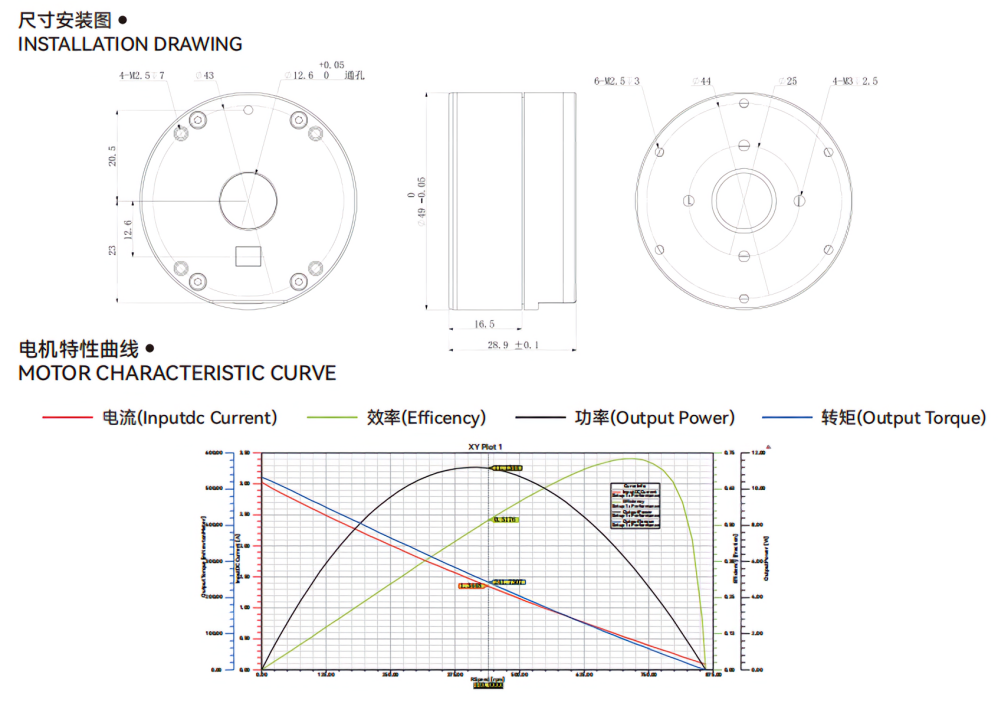
Product Specifications
Product Model | ZH5030 |
Turns | 35 |
Rated voltage (V) | 16 |
Max Speed (rpm) | 870 |
Rated torque (N.m) | 0.24 |
Rated speed (rpm) | 440 |
Rated current (A) | 1.35 |
Max Power (W) | 12 |
Max Torque (N.m) | 0.53 |
Speed Constant (rpm/V) | 27.5 |
Torque constant (N.m/A) | 0.18 |
Winding type | Y |
Line Resistance (Ω) | 3.2 |
Phase Inductance (mH) | 1.2 |
Motor Poles | 28 |
Rotor Inertia | 202 |
Motor Temperature | YES |
Bearing Rated Load (N) | 153 |
Motor weight (g) | 145 |
Compatible Drive Types | DF40V2 |
Drive input voltage (V) | 7.4r32 |
Communication method | RS485 Or CAN |
Communication frequency (Hz) | RS485:500Hz (115200bps)/CAN:2KHz(1Mbps) |
Encoder resolution | 18bit Magnetic Encoder |
RS485 baud rate (bps) | 9600、19200、57600、115200、230400、406800、1M、2M |
CAN baud rate | 100K、125K、250K、500K、1M |
Control Mode | Torque Loop(24KHz) /Speed Loop(8KHz) /Position Loop(8KHz) |
Acceleration curve | (Trapeziod acceleration) |
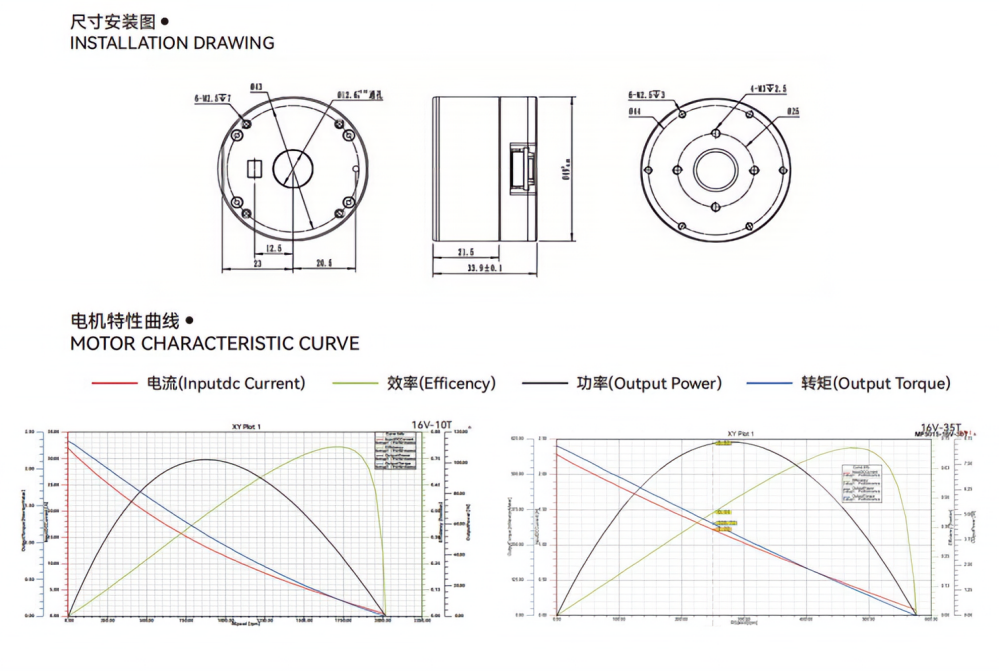
Product Model | ZH5034 |
Turns | 35 |
Rated voltage (V) | 16 |
Max Speed (rpm) | 580 |
Rated torque (N.m) | 0.32 |
Rated speed (rpm) | 250 |
Rated current (A) | 1.22 |
Max Power (W) | 8.8 |
Max Torque (N.m) | 0.82 |
Speed Constant (rpm/V) | 15.6 |
Torque constant (N.m/A) | 0.26 |
Winding type | Y |
Line Resistance (Ω) | 4 |
Phase Inductance (mH) | 1.76 |
Motor Poles | 28 |
Rotor Inertia | 202 |
Motor Temperature | YES |
Bearing Rated Load (N) | 153 |
Motor weight (g) | 175 |
Compatible Drive Types | DF40V2 |
Drive input voltage (V) | 7.4-32 |
Communication method | RS485OrCAN |
Communication frequency (Hz) | RS485:500Hz(115200bps)/CAN:2KHz(1Mbps) |
Encoder resolution | 19bit Magnetic Encoder |
RS485 baud rate (bps) | 9600、19200、57600、115200、230400、406800、1M、2M |
CAN baud rate | 100K、125K、250K、500K、1M |
Control Mode | Torque Loop(24KHz)/Speed Loop(8KHz)/PositionLoop(8KHz) |
Acceleration curve | (Trapeziod acceleration) |