

Product Description
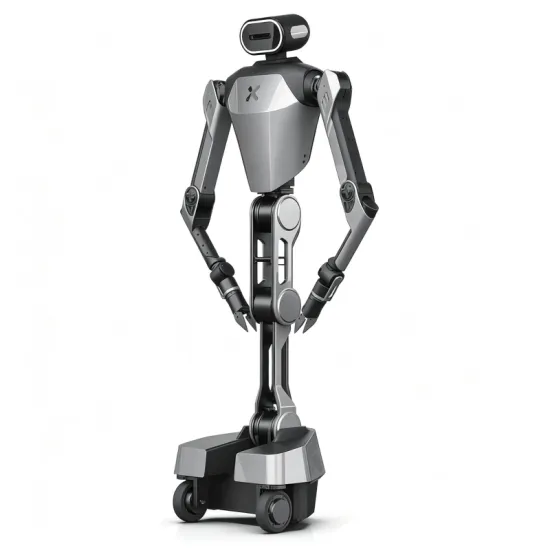
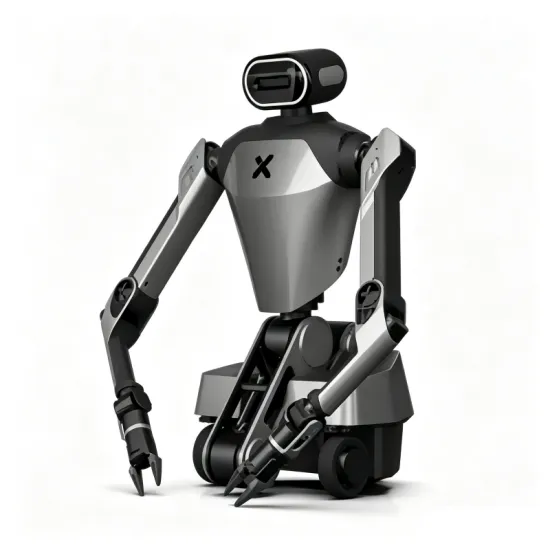
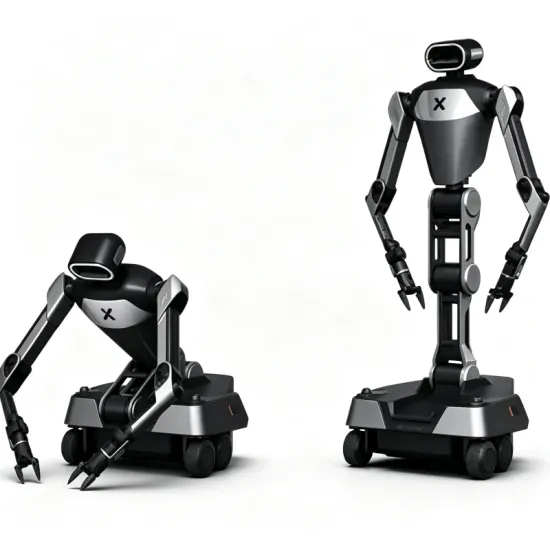
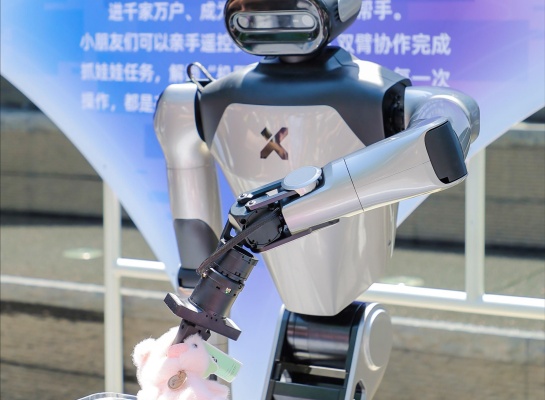
Full-size dual-arm humanoid robot
GALAXEA R1
— comprehensive and efficient, a research powerhouse.
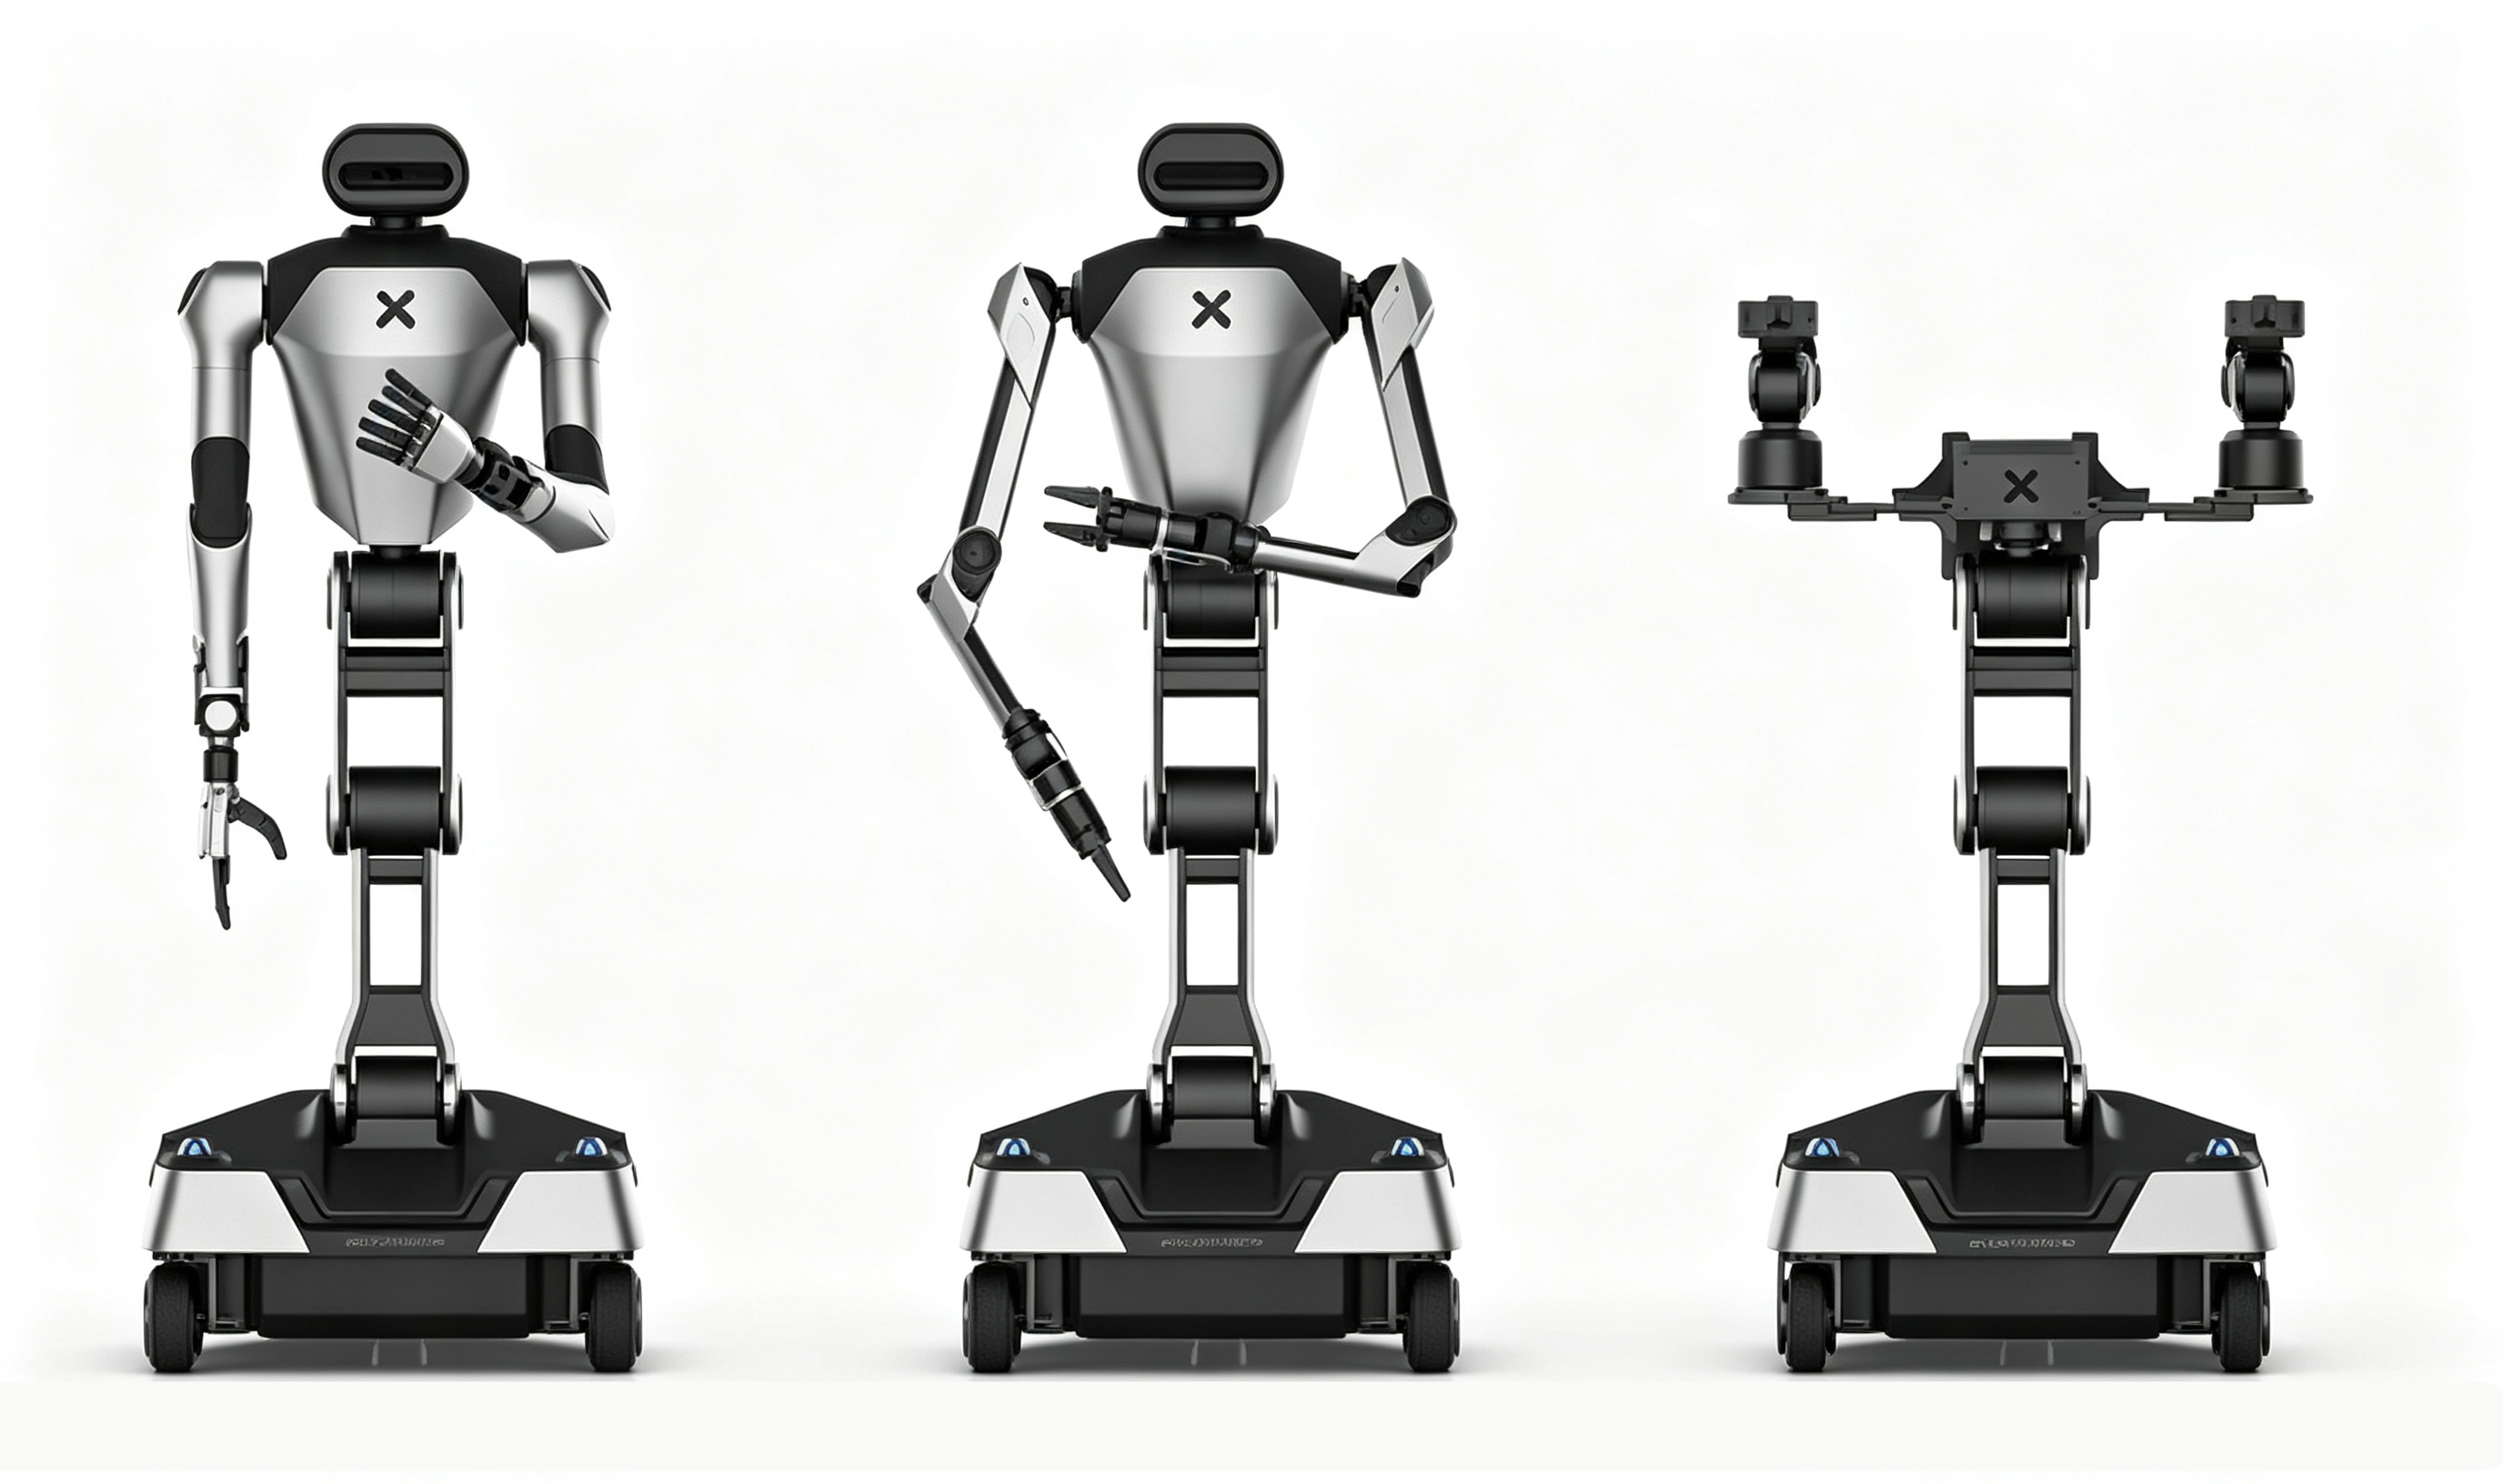
Product Highlight | Detail |
Independent DOF | 24 |
Max dual-arm payload | 10KG |
All-round sensing | 360° |
Teleoperation | Homogeneous & VR |
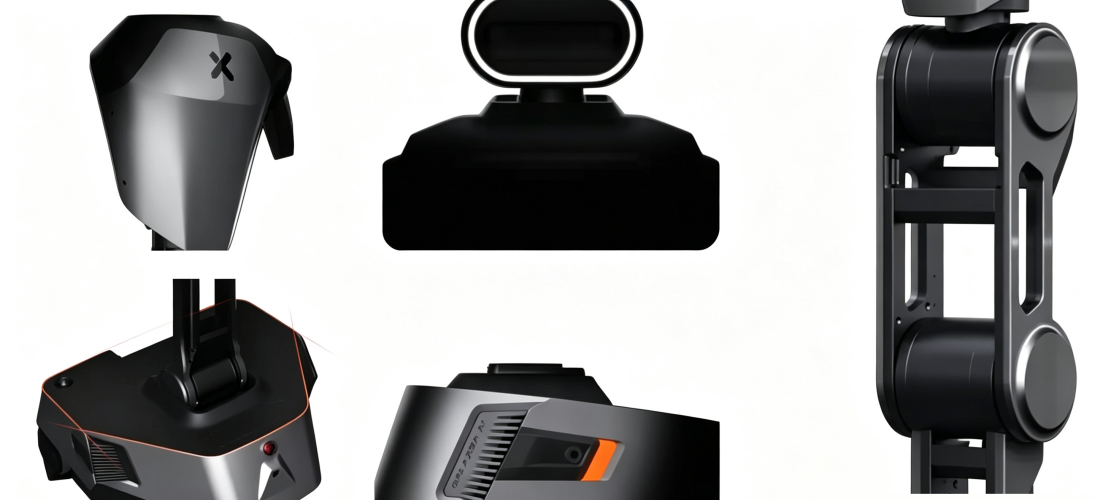
Ultimate aesthetics, redefining the era of robots
— the ultimate pursuit of design, the ultimate experience of intelligence.
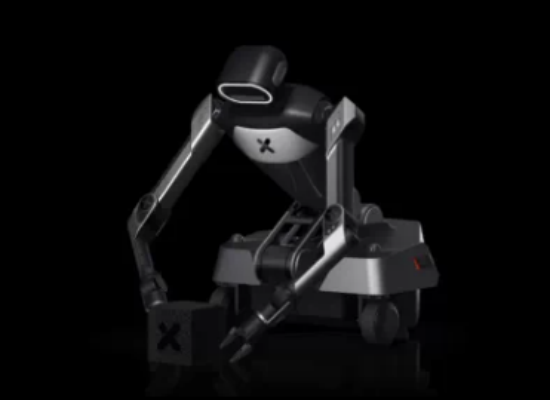
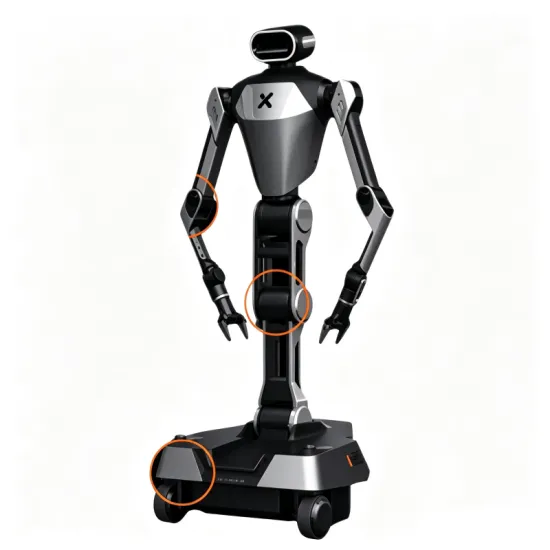
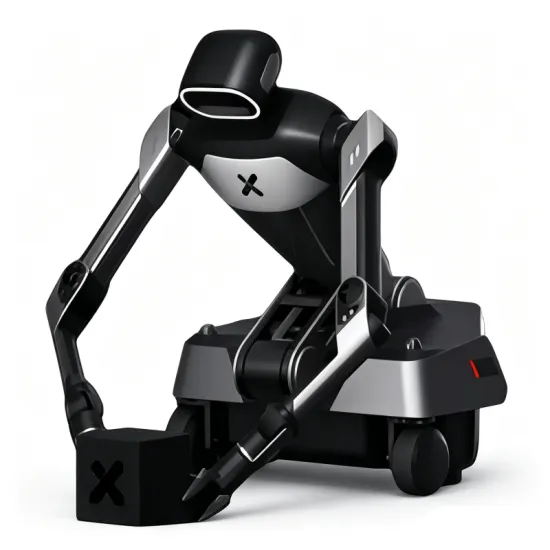
Whole-body 24 DOF with a 0-2m vertical workspace
6x2-DOF arms
4x1-DOF torso
2x3-DOF
Functional features
Perceive every moment:360° 3D sensing with full-sensor calibration and millisecond-level synchronization
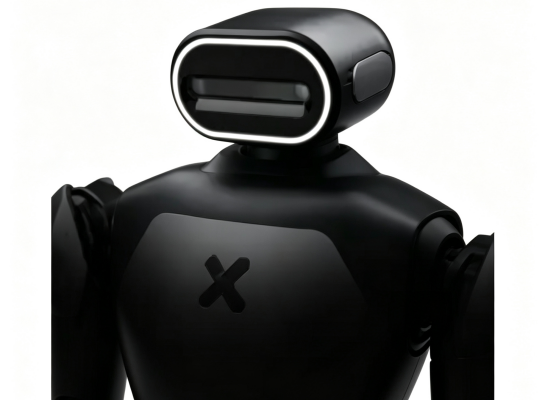
2MP stereo binocular camera
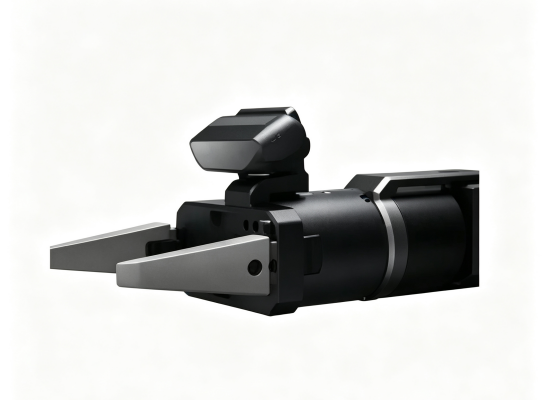
2MP wrist camera (optional)
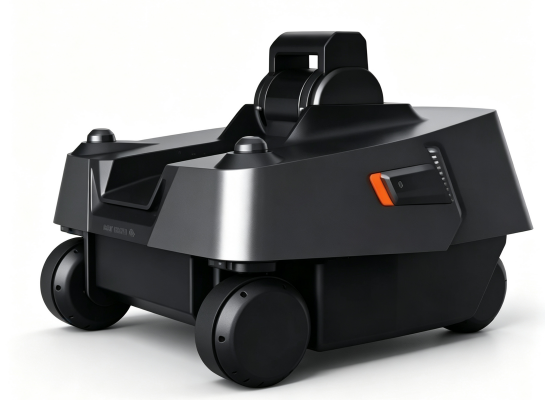
5x2MP surround cameras
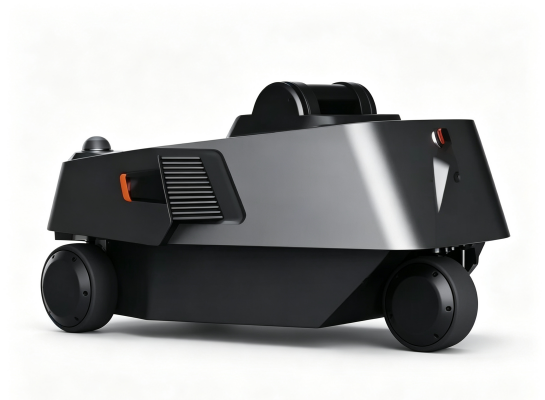
360° LiDAR
Product Display
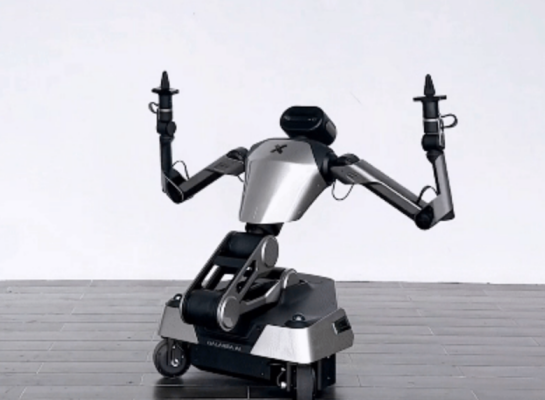
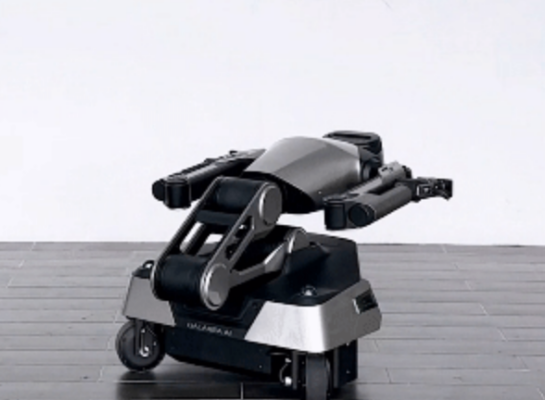
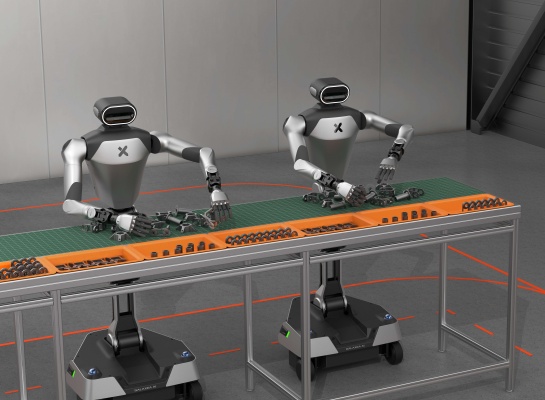
Product parameters
Parameter | R1 Pro | R1 | R1 Lite |
Whole-body Parameters | |||
Key dimensions | 1700mm (H), 675mm (W) | 1700mm (H), 675mm (W) | 1455mm (H), 675mm (W) (torso platform 780mm (W)) |
Whole-body DOF (standard grippers) | 26 | 24 | 23 |
DOF per arm | 7 | 6 | 6 |
Arm length | 62cm | 70cm | 70cm |
Arm sensors | Force sensing, camera (optional) | - | - |
Arm Parameters | |||
Payload per arm | Rated 3.5kg (max 5kg) @0.62m | Rated 2kg (max 3.5kg) @0.5m | Rated 2kg (max 3.5kg) |
Arm mounting | Side-mounted | Side-mounted | Top-mounted |
End effector | Gripper | Gripper | Gripper |
Torso Parameters | |||
Torso DOF | 4 | 4 | 3 |
Vertical workspace | 0-2m | 0-2m | 0-1.7m |
Chassis Parameters | |||
Chassis DOF | 6 | 6 | 6 |
Steering wheels | 3 | 3 | 3 |
Chassis speed | 1.5m/s | 1.5m/s | 1.5m/s |
Compute Parameters | |||
Architecture | NVIDIA Jetson AGX Orin 32GB | Same as left | Same as left |
Compute power | 200TOPS | 200TOPS | 200TOPS |
CPU | 8 cores | 8 cores | 8 cores |
CPU max frequency | 2.2GHz | 2.2GHz | 2.2GHz |
GPU max frequency | 930MHz | 930MHz | 930MHz |
Sensor configuration | 7x HD cameras + 1x LiDAR | 7x HD cameras + 1x LiDAR | 1x HD stereo binocular camera |