

Detailed Specifications & Images
Explosion-proof Joint Module
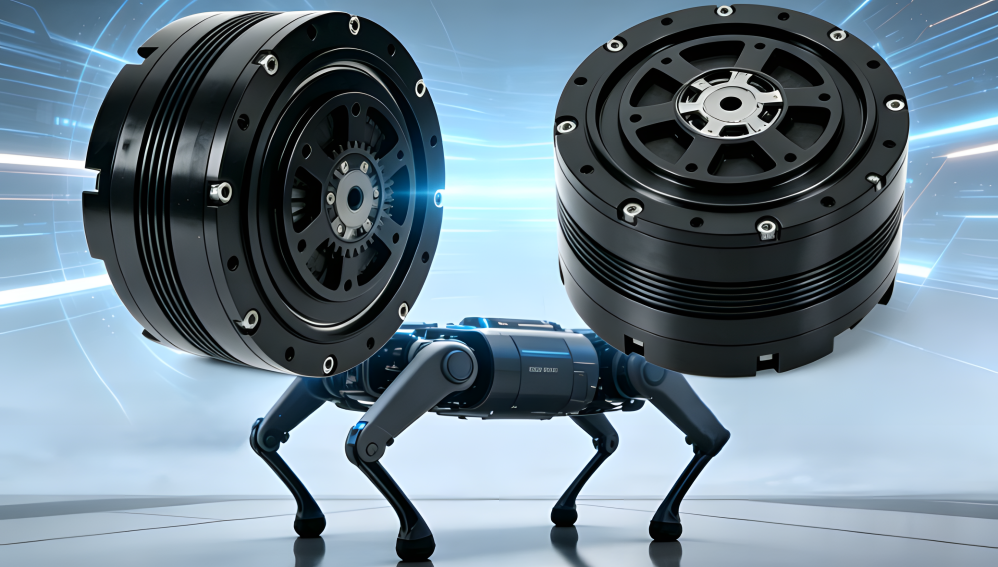
| Explosion-proof design | High torque output | Joint module for inspection robot dog |
Explosion-proof Joint Module
High Torque | High Precision | High Reliability
| Humanoid robot | Collaborative robot | Gimbal | Turntable |
| Laser guidance | Weapon station | Semiconductor equipment | Inspection robot |
| Laser guidance | Semiconductor equipment | Specialized robots | Specialized robots |
Product Features
Core Advantages of Joint Modules
| Highly integrated, all-in-one design | Large hollow-bore design | High torque density | Lightweight design |
| Large hollow-bore design | High reliability and long service life | High torque density | High precision and low noise |
High torque, low noise, Compact design Precision craftsmanship, superior quality; Well-engineered structure, low noise |
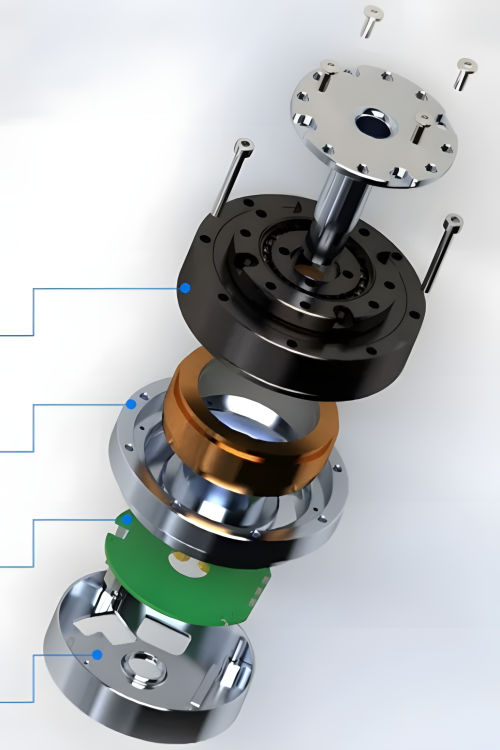
|
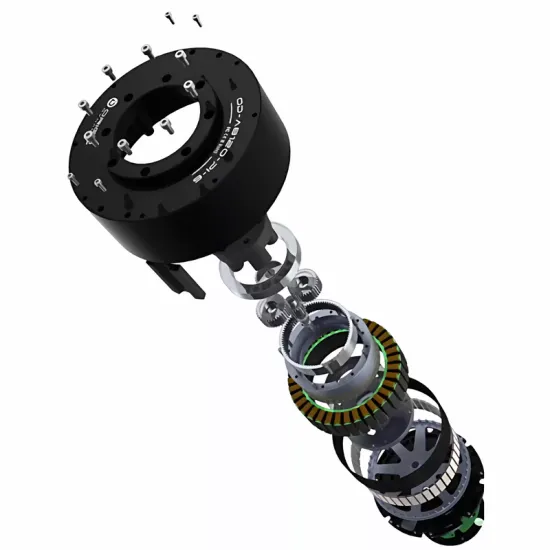
| Ultra-thin harmonic reducer | |
| Brushless torque motor | |
| High-precision encoder | |
| FOC control board |
Joint Module for Quadruped Inspection Robot
High Torque | High Precision | High Reliability
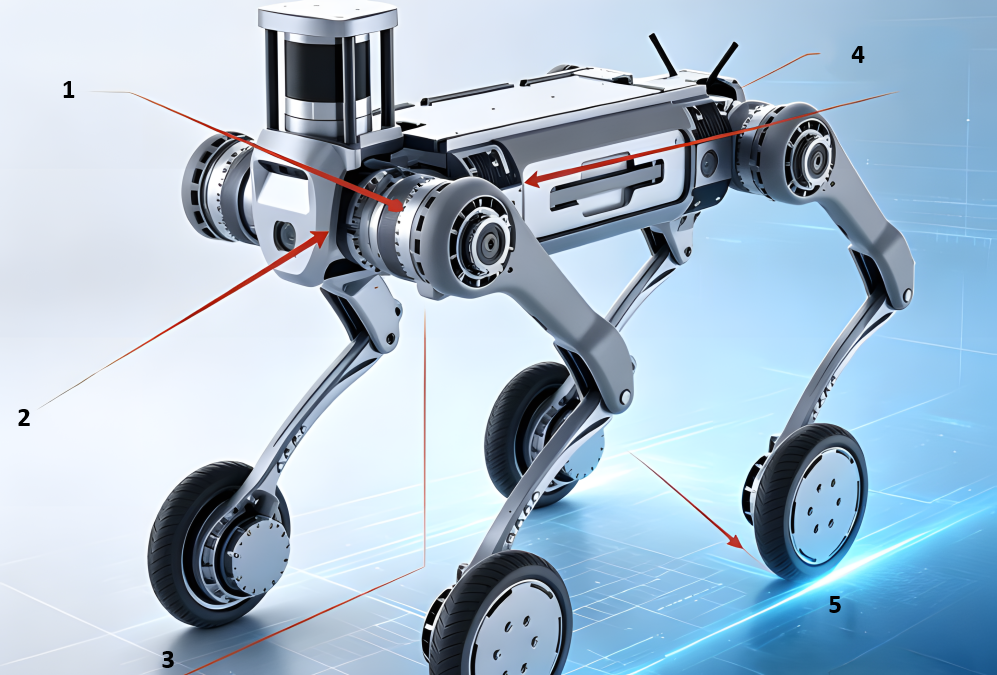
| 1. Motor 1: Hip joint motor | 2. Motor 2 : Lower leg joint motor | 3. Hub motor |
| 4. Explosion-proof design | 5. Inspection robot joints Core motor module | |
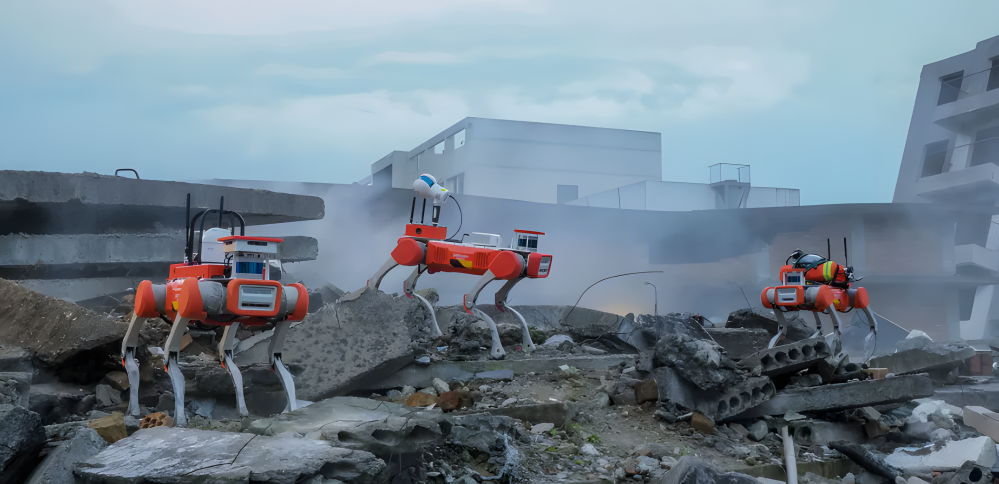
Detailed Specifications
Please contact customer service
to obtain additional product specification manuals, as well as 3D STP models and 2D PDF drawings of the motor.
Please also contact customer service for the drive control manual.
Specifications
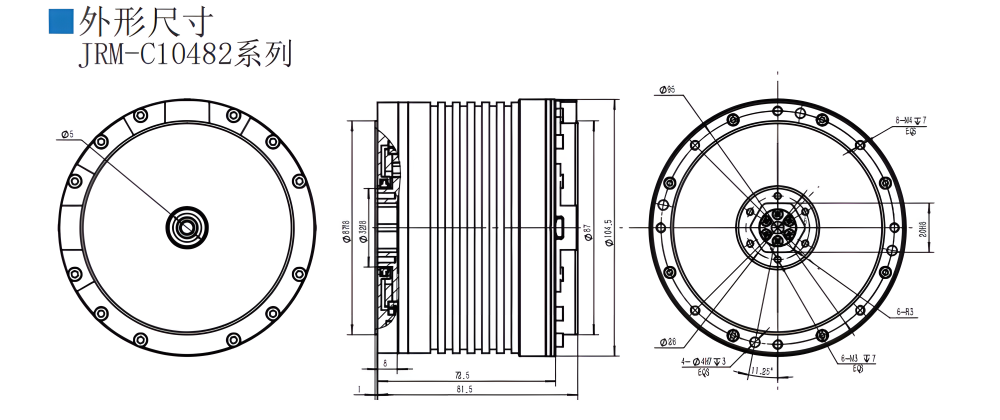
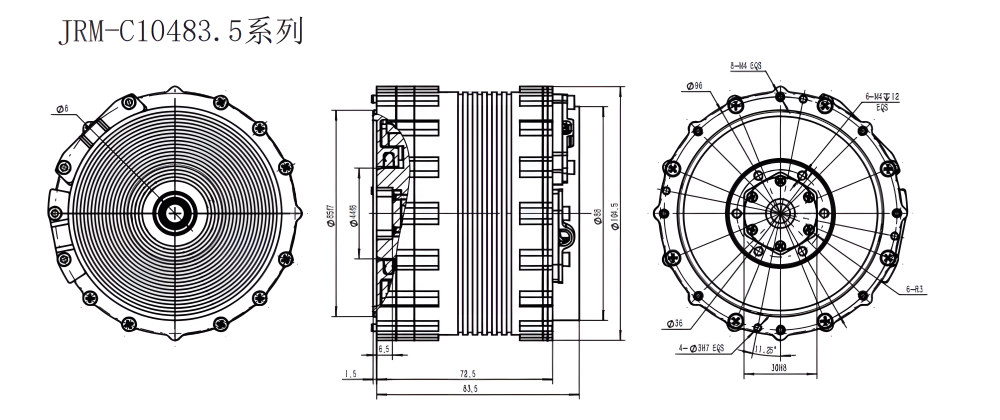
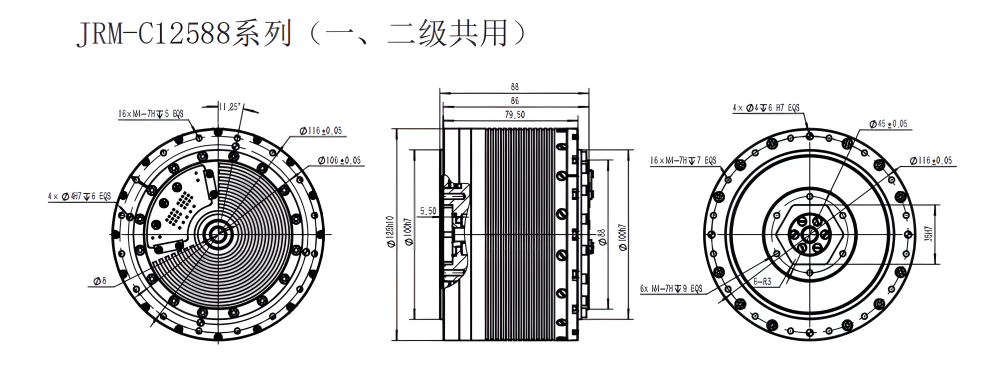
Model | 104 Series | 125 Series | |||
Item | JRM-C10482 | JRM-C10483.5 | JRM-C12588 | ||
Reduction Ratio | 10 | 20.4 | 8 | 20 | 24 |
Rated Speed | 320 rpm | 150 rpm | 375 rpm | 150 rpm | 120rpm |
Peak Speed | 420 rpm | 200 rpm | 375 rpm | 150 rpm | 120rpm |
Rated Torque | 23 N·m / 50 N·m | 50 N·m / 100 N·m | 30 N·m / 45 N·m | 80 N·m / 120 N·m | 90N.m/150N.m |
Peak Torque | 145 N·m | 300 N·m | 145 N·m | 360 N·m | 450N.m |
Resolution | 17-bit | 17-bit | 17-bit | 17-bit | 17-bit |
Communication Interface | CAN-FD/EtherCAT | CAN-FD/EtherCAT | CAN-FD/EtherCAT | CAN-FD/EtherCAT | CAN-FD/EtherCAT |
Voltage | 48 V DC | 48 V DC | 48 V DC | 48 V DC | 48 V DC |
Weight | 1.9 kg | 1.9 kg | 2.3 kg | 2.8kg | 2.8kg |
Encoder | Dual-encoder setup | ||||
Encoder Repeatability | ±40″ | ±40″ | ±40″ | ±40″ | ±40″ |
Drive Power | Integrated | Integrated | Integrated | Integrated | Integrated |
Hollow Bore Diameter | 8 mm | 8 mm | 8 mm | 8 mm | 8 mm |
Rated Power | 0.82 kW | 0.82 kW | 1.26 kW | 1.26 kW | 1.26 kW |
Motor Rated Speed | 3200 rpm | 3200 rpm | 3000 rpm | 3000 rpm | 3000 rpm |
Motor Peak Speed | 4200 rpm | 4200 rpm | 3000 rpm | 3000 rpm | 3000 rpm |
Motor Rated Torque | 2.5 N·m / 5.3 N·m | 2.5 N·m / 5.3 N·m | 4.0 N·m / 6.4 N·m | 4.0 N·m / 6.4 N·m | 4.0 N·m / 6.4 N·m |
Motor Peak Torque | 15.5 N·m | 15.5 N·m | 19.16 N·m | 19.16 N·m | 19.16 N·m |
Motor Rated Current | 19 A | 19 A | 27 A / 43 A | 27 A / 43 A | 27 A / 43 A |
Motor Peak Current | 130 A | 130 A | 150 A | 150 A | 150 A |