


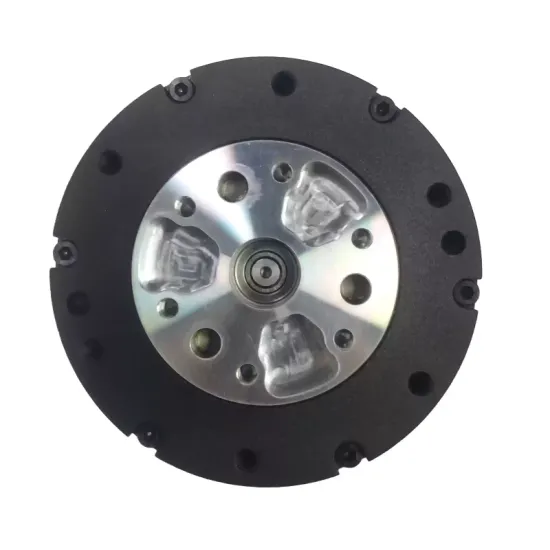
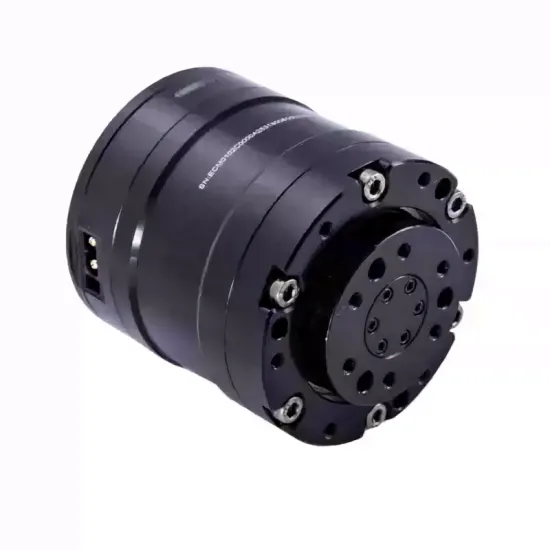
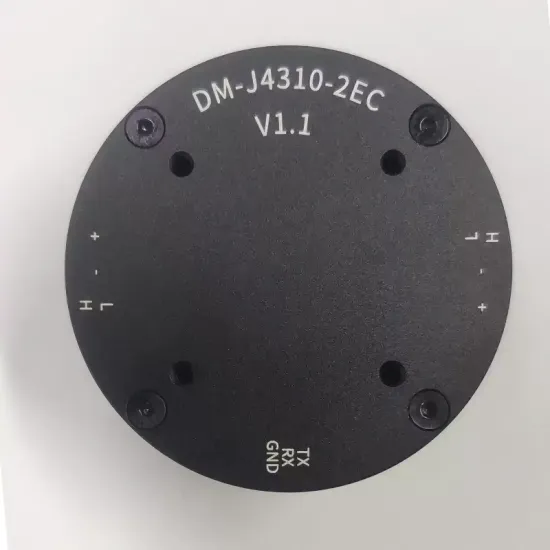
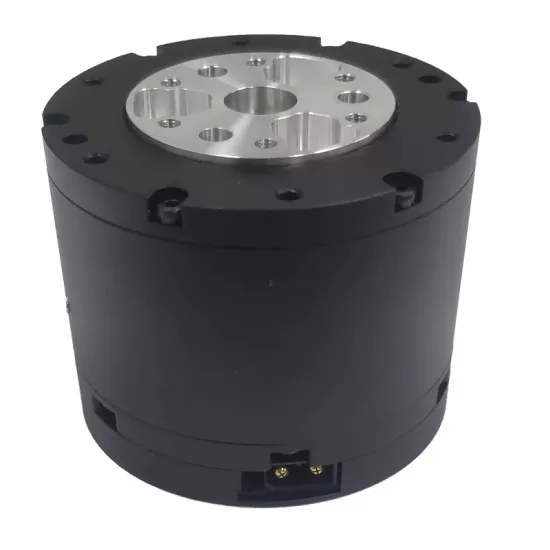
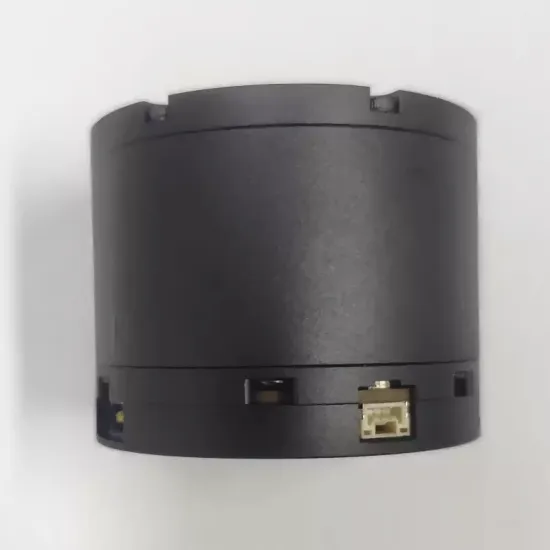


Humanoid robot
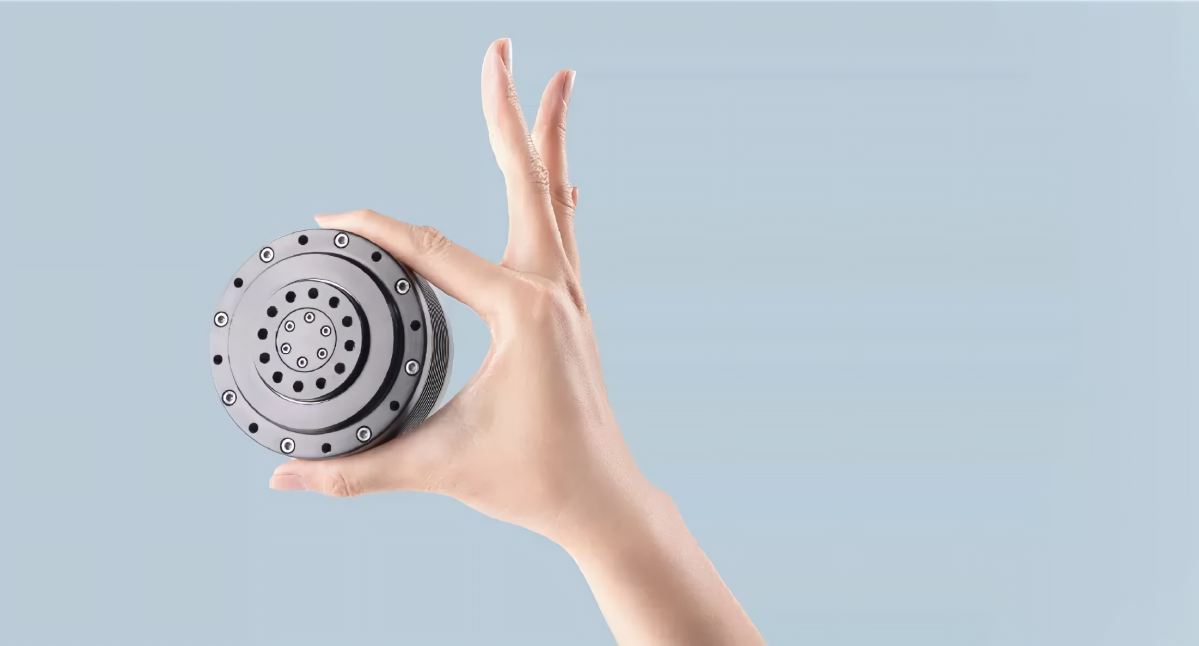
Integrated Joint Module

Meticulous Craftsmanship·Exceptional Quality
Six major advantages provide you with a better user experience.
Comprehensive Range Over 50 Specifications Versatile Application | Cost-effectiveness In-house component development 50% cost reduction | Ultra-lightweight Weight Reduced by 1/ |
Ultra-high performance, high load-to-weight ratio Torque density is twice that of comparable products. | Factory-Direct | Authentic Product Strict Quality Control | A Decade of Professional Service Technical Support Provided by Engineers |
| High stability Capable of withstanding instantaneous peak torque shocks of three times the rated value. | Dual encoders ensure precise positioning. Retains location data during power loss, ensuring precise positioning and worry-free operation. |
|
|
Stable performance, capable of withstanding instantaneous peak torque shocks three times the rated value; rated service life is 5,000 hours, with actual continuous operation already exceeding 12 months. | |
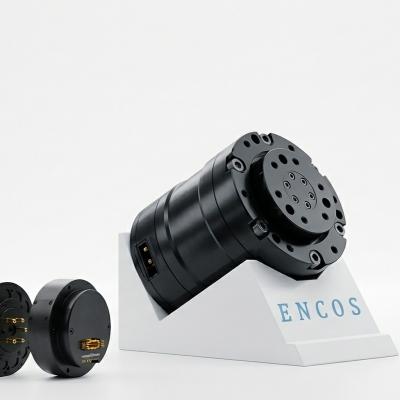
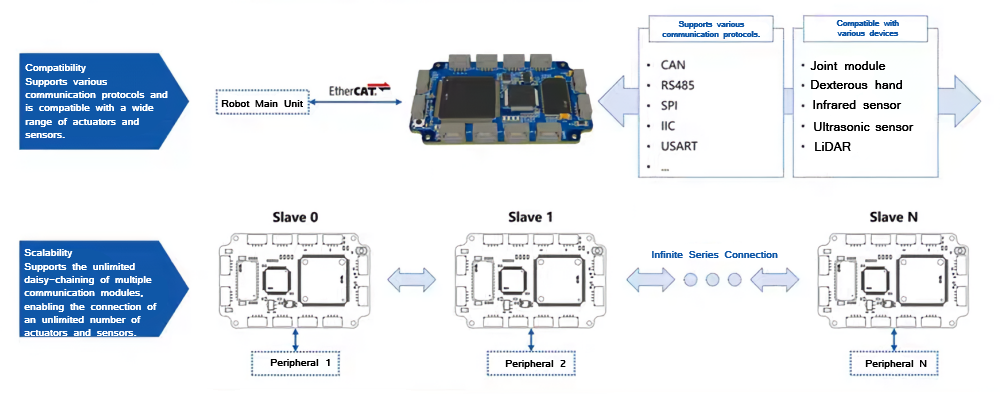
High adaptability
"High-speed, high-real-time" communication solution for full-body joints and sensors
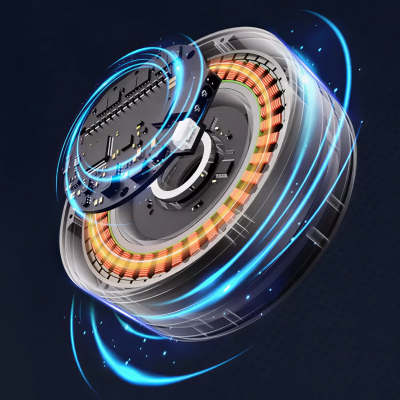
Full series with dual encoders
Switch between multiple control modes at any time; features load self-adaptation—no tuning required.
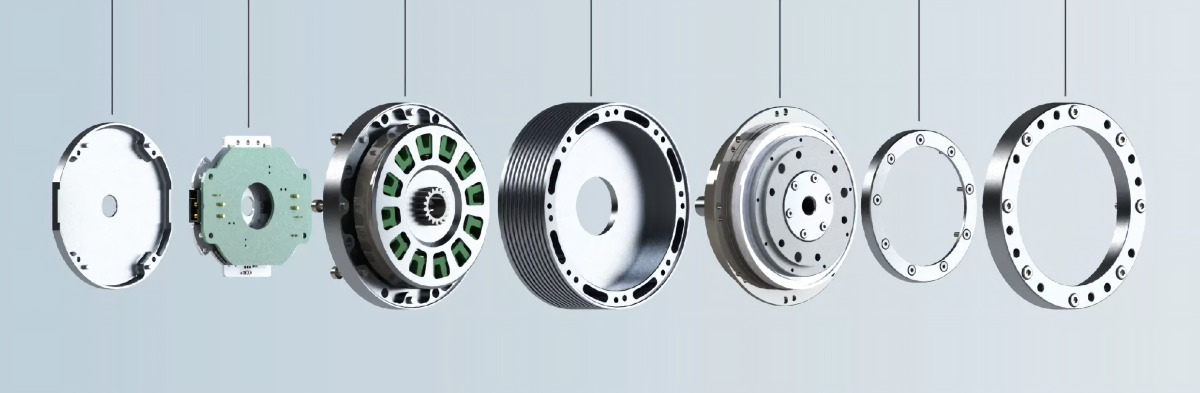
| 1.Drive cover | 2.Driver board | 3.Drive motor | 4.shell | 5.Reduction gearbox | 6.Bearing | 7.Front cover |
Solution
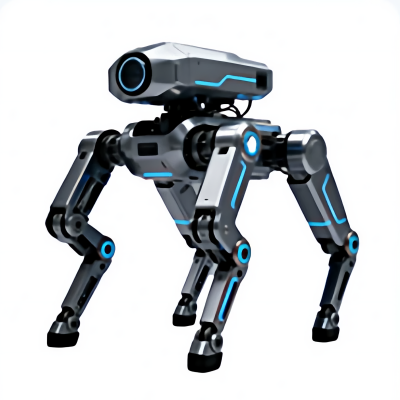
30cm-tall robotic dog Recommended model: EC-A6408-P2-25 |
60cm-tall robotic dog Recommended model: EC-AB112-P1-18 |
80cm-tall robotic dog Recommended model: EC-A10020-P2-24 |
1.2-meter humanoid robot |
1.6–1.8 meter humanoid robot |
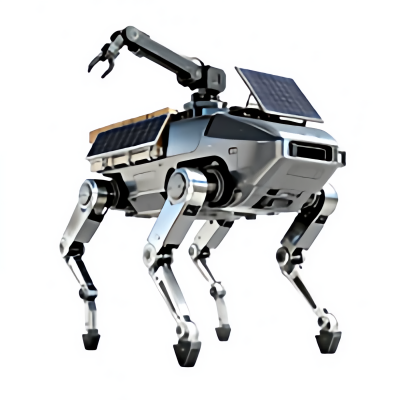
Wheeled service robot |
Selected Case Studies
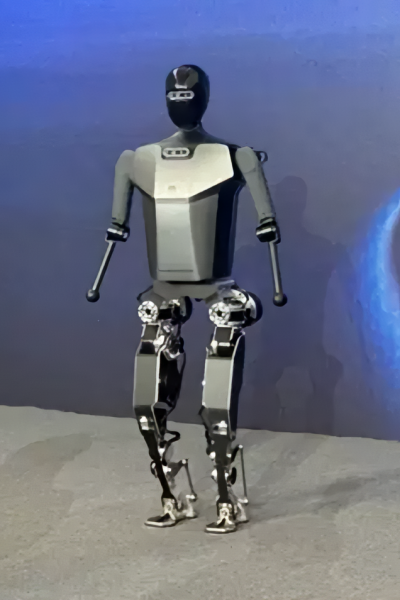
Tiangong Robot |
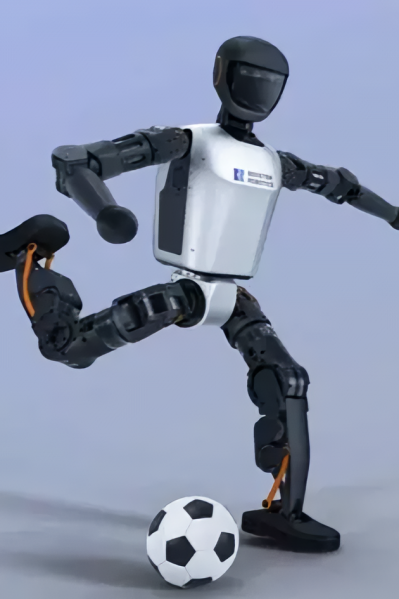
BOOSTER T1 |
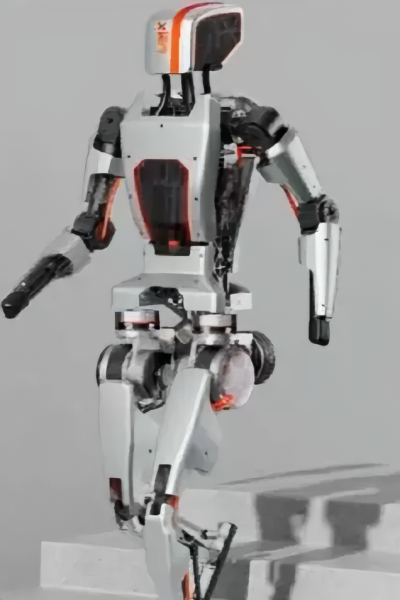
CL-1 |
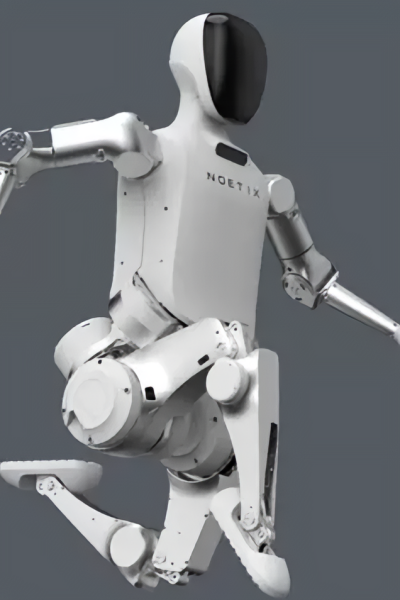
N2 |
1.Introduction to the EC-A2806-P2-36 Moto
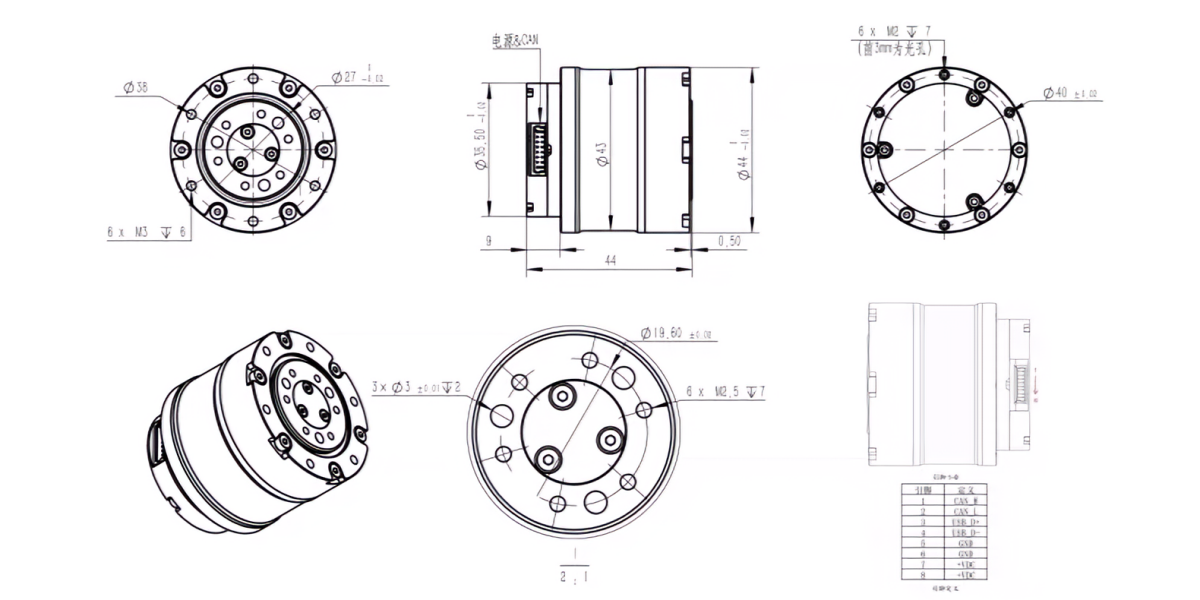
Performance Parameters | ||
Reduction Ratio | 36 | |
Rated Voltage | v | 48 |
Rated Bus Current | A | 2.1 |
Rated Phase Current | A | 2.4 |
Rated Power | W | 101 |
Rated Speed | RPM | 207 |
Rated Torque | Nm | 3 |
Peak Speed | RPM | 220 |
Peak Phase Current | A | 10 |
Peak Torque | Nm | 12 |
Efficiency | 60% | |
Torque Constant | Nm/A | 1.35 |
Weight | 8 | 162 |
Backlash | Arcmin | 12 |
MotorSize | mm | 44×44 |
Communication Mode | CAN | |
Communication Baud Rate | 1M | |
Double Encoder | yes | |
AxialAndRadialLoads | KN | 2.23 |
BendingMoment Resistance | Nm | 13 |
Introduction to the EC-A4310-P2-36 Motor
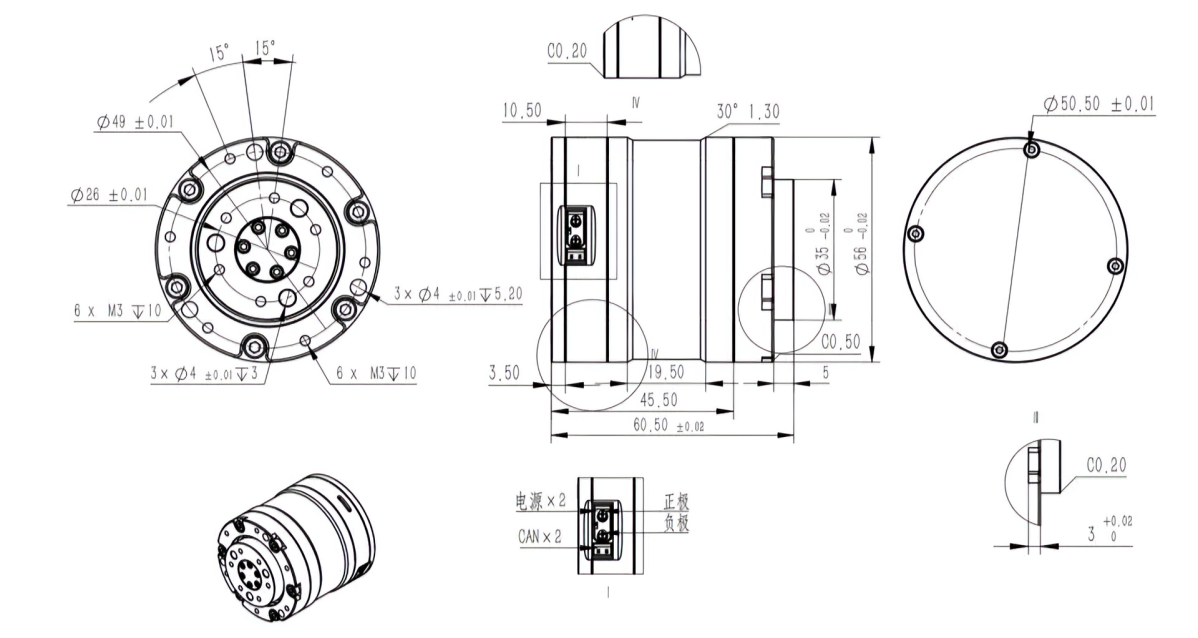
Performance Parameters | ||
Reduction Ratio | 36 | |
Rated Voltage | v | 24 (supports 48V) |
Rated Bus Current | A | 6.5 |
Rated Phase Current | A | 7.8 |
Rated Power | W | 156 |
Rated Speed | RPM | 75 |
Rated Torque | Nm | 12 |
Peak Speed | RPM | 89 |
Peak Phase Current | A | 30 |
Peak Torque | Nm | 36 |
Efficiency | 71% | |
Torque Constant | Nm/A | 1.4 |
Weight | 8 | 384 |
Backlash | Arcmin | 10 |
MotorSize | mm | 56×60.5 |
Communication Mode | CAN | |
Communication Baud Rate | 1M | |
Double Encoder | yes | |
AxialAndRadialLoads | KN | 1.89 |
BendingMoment Resistance | Nm | 28 |
Cross Roller Bearing Type | 300s | |
The Rotor Inertia OfThe Motor | kgmm² | 18.2 |
Torque Density | Nm/kg | 93.75 |
Introduction to the EC-A4315-P2-36 Motor
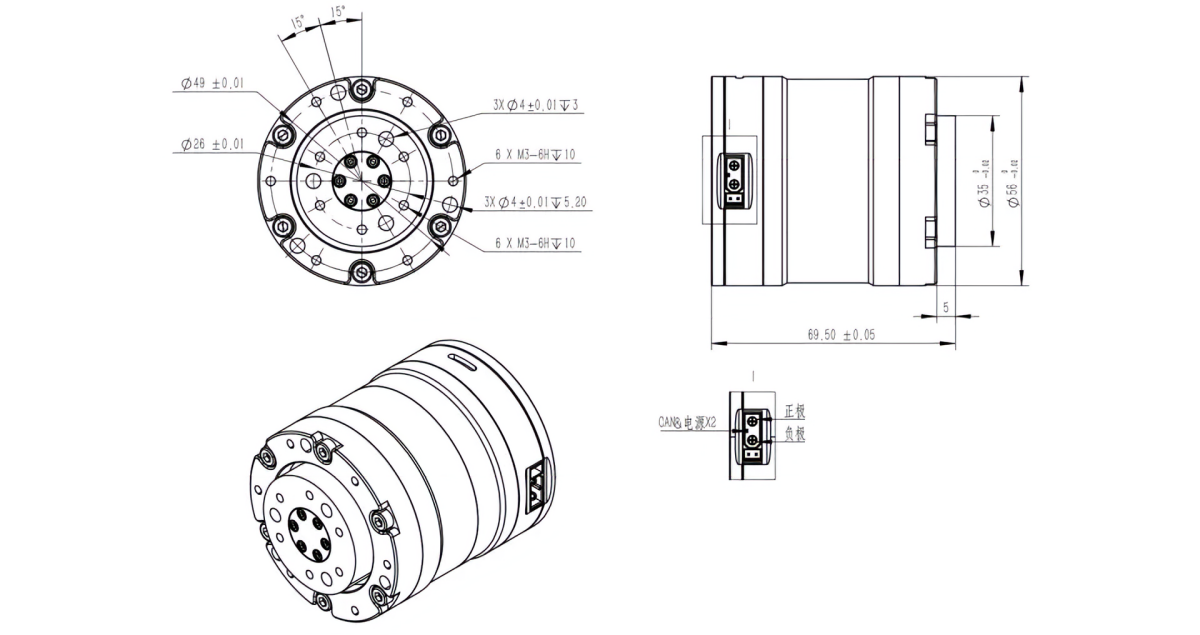
Performance Parameters | ||
Reduction Ratio | 36 | |
Rated Voltage | v | 48 |
Rated Bus Current | A | 8.28 |
Rated Phase Current | A | 10.22 |
Rated Power | W | 397 |
Rated Speed | RPM | 109 |
Rated Torque | Nm | 25 |
Peak Speed | RPM | 117 |
Peak Phase Current | A | 30 |
Peak Torque | Nm | 75 |
Efficiency | 74% | |
Torque Constant | Nm/A | 2.6 |
Weight | 8 | 455 |
Backlash | Arcmin | 10 |
MotorSize | mm | 56×69.5 |
Communication Mode | CAN | |
Communication Baud Rate | 1M | |
Double Encoder | yes | |
AxialAndRadialLoads | KN | 1.89 |
BendingMoment Resistance | Nm | 28 |
Cross Roller Bearing Type | 3005 | |
The Rotor Inertia OfThe Motor | kgmm² | 25.5 |
Torque Density | Nm/kg | 164.84 |
EC-A6408-P2-25电机简介
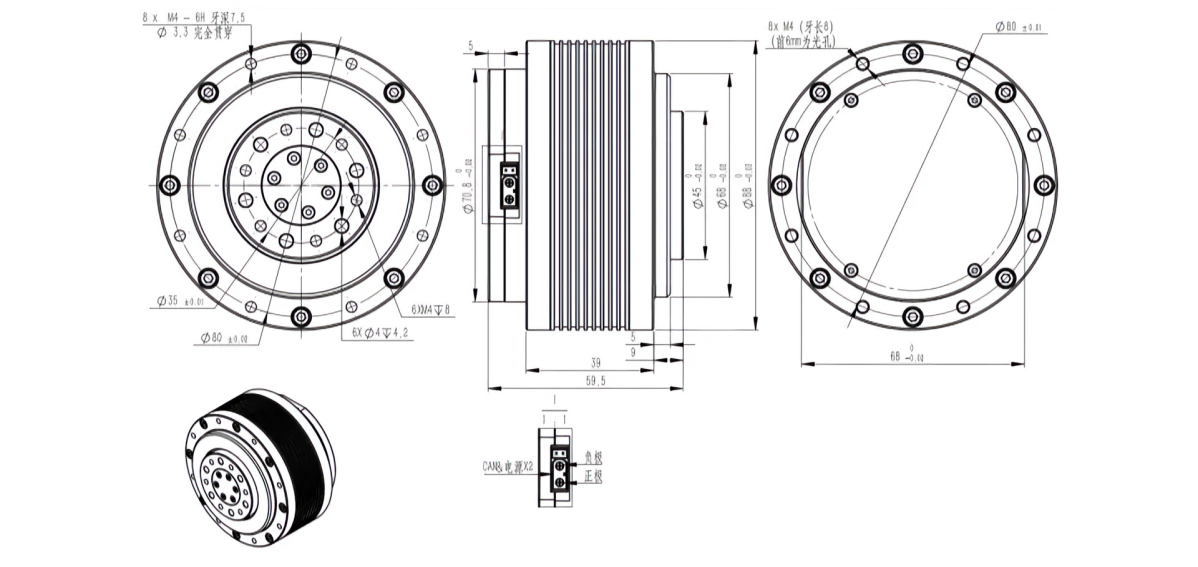
Performance Parameters | ||
Reduction Ratio | 25 | |
Rated Voltage | v | 48 |
Rated Bus Current | A | 6.92 |
Rated Phase Current | A | 11.83 |
Rated Power | W | 332 |
Rated Speed | RPM | 133 |
Rated Torque | Nm | 20 |
Peak Speed | RPM | 149 |
Peak Phase Current | A | 60 |
Peak Torque | Nm | 60 |
Efficiency | 72% | |
Torque Constant | Nm/A | 2.35 |
Weight | 8 | 604 |
Backlash | Arcmin | 10 |
MotorSize | mm | 88×59.5 |
Communication Mode | CAN | |
Communication Baud Rate | 1M | |
Double Encoder | yes | |
AxialAndRadialLoads | KN | 2.14 |
BendingMoment Resistance | Nm | 40 |
Cross Roller Bearing Type | 4005 | |
The Rotor Inertia OfThe Motor | kgmm² | 62.254 |
Torque Density | Nm/kg | 99.34 |
EC-A6416-P2-25 电机简介
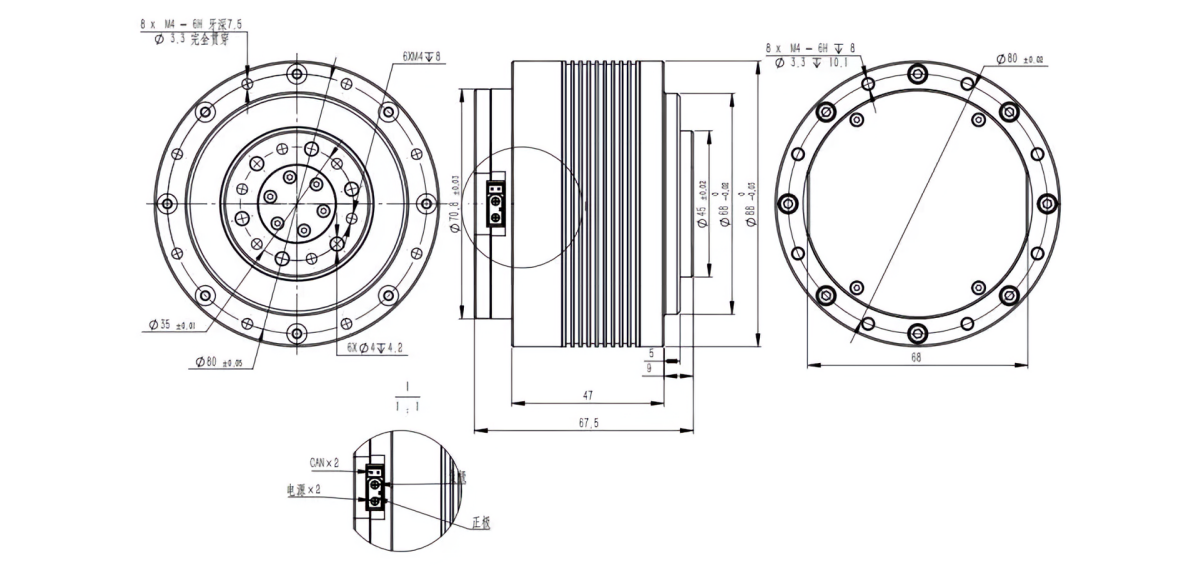
Performance Parameters | ||
Reduction Ratio | 25 | |
Rated Voltage | v | 48 |
Rated Bus Current | A | 13 |
Rated Phase Current | A | 17.5 |
Rated Power | W | 624 |
Rated Speed | RPM | 107 |
Rated Torque | Nm | 40 |
Peak Speed | RPM | 120 |
Peak Phase Current | A | 60 |
Peak Torque | Nm | 120 |
Peak Torque | 73% | |
Torque Constant | Nm/A | 2.74 |
Weight | 8 | 803 |
Backlash | Arcmin | 15 |
MotorSize | mm | 88x67.5 |
Communication Mode | CAN | |
Communication Baud Rate | 1M | |
Double Encoder | yes | |
AxialAndRadialLoads | KN | 2.14 |
BendingMoment Resistance | Nm | 40 |
Cross Roller Bearing Type | 4005 | |
The Rotor Inertia OfThe Motor | kgmm² | 104.395 |
Torque Density | Nm/kg | 149.44 |
Introduction to the EC-A8112-P1-18 Motor
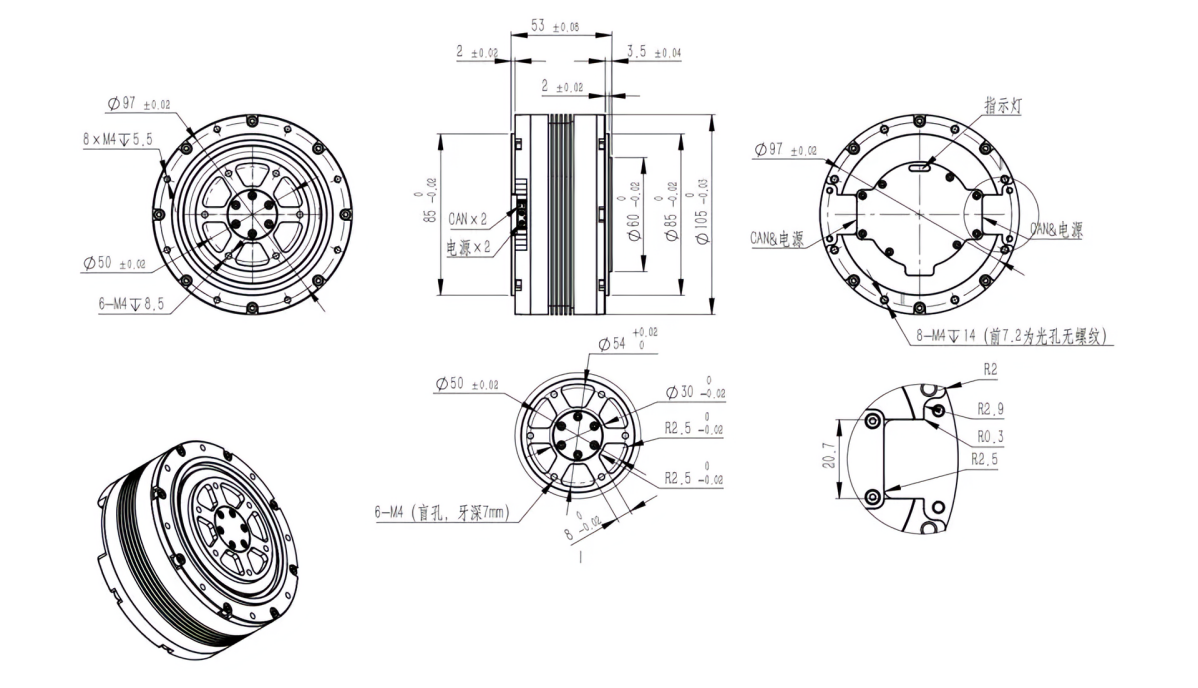
Performance Parameters | ||
Reduction Ratio | 18 | |
Rated Voltage | v | 48 |
Rated Bus Current | A | 13.3 |
Rated Phase Current | A | 15.9 |
Rated Power | W | 638.4 |
Rated Speed | RPM | 155 |
Rated Torque | Nm | 30 |
Peak Speed | RPM | 157 |
Peak Phase Current | A | 60 |
Peak Torque | Nm | 90 |
Efficiency | 78% | |
Torque Constant | Nm/A | 2.1 |
Weight | 8 | 860 |
Backlash | Arcmin | 12 |
MotorSize | mm | 105×53 |
Communication Mode | CAN | |
Communication Baud Rate | 1M | |
Double Encoder | yes | |
AxialAndRadialLoads | KN | 2.81 |
BendingMoment Resistance | Nm | 98 |
Cross Roller Bearing Type | 7005 | |
The Rotor Inertia OfThe Motor | kgmm² | 146.69 |
Torque Density | Nm/kg | 104.65 |
EC-A8116-P1-18 电机简介
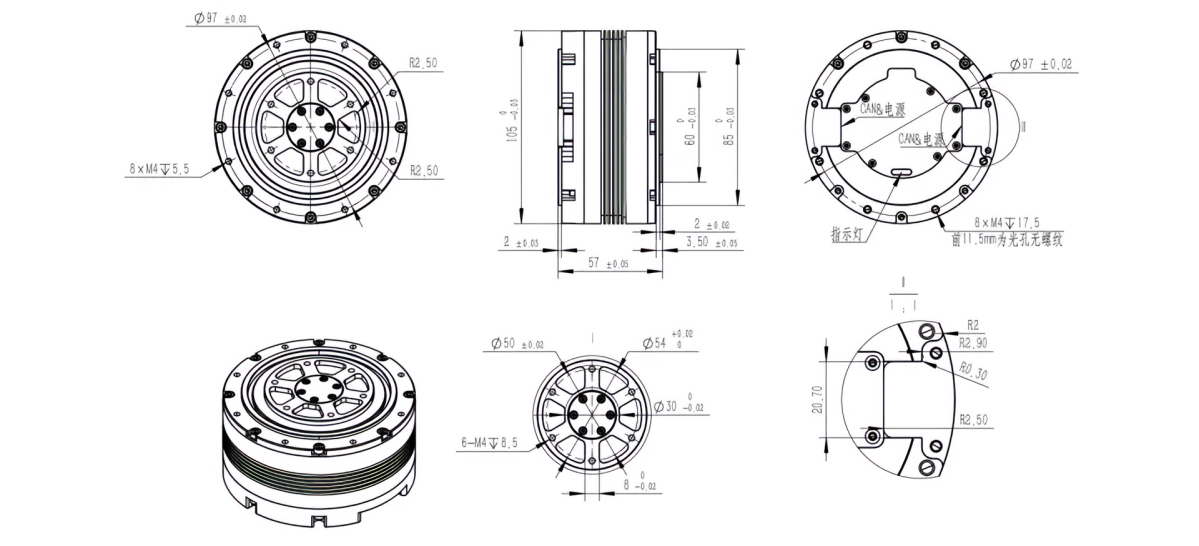
Performance Parameters | ||
Reduction Ratio | 18 | |
Rated Voltage | v | 48 |
Rated Bus Current | A | 19.4 |
Rated Phase Current | A | 21 |
Rated Power | W | 931.2 |
Rated Speed | RPM | 132 |
Rated Torque | Nm | 40 |
Peak Speed | RPM | 140 |
Peak Phase Current | A | 70 |
Peak Torque | Nm | 130 |
Efficiency | 76% | |
Torque Constant | Nm/A | 2.35 |
Weight | 8 | 961 |
Backlash | Arcmin | 12 |
MotorSize | mm | 105X57 |
Communication Mode | CAN | |
Communication Baud Rate | 1M | |
Double Encoder | yes | |
AxialAndRadialLoads | KN | 2.81 |
BendingMoment Resistance | Nm | 98 |
Cross Roller Bearing Type | 7005 | |
The Rotor Inertia OfThe Motor | kgmm² | 184.053 |
Torque Density | Nm/kg | 135.28 |
Introduction to the EC-A10020-P1-12 Motor
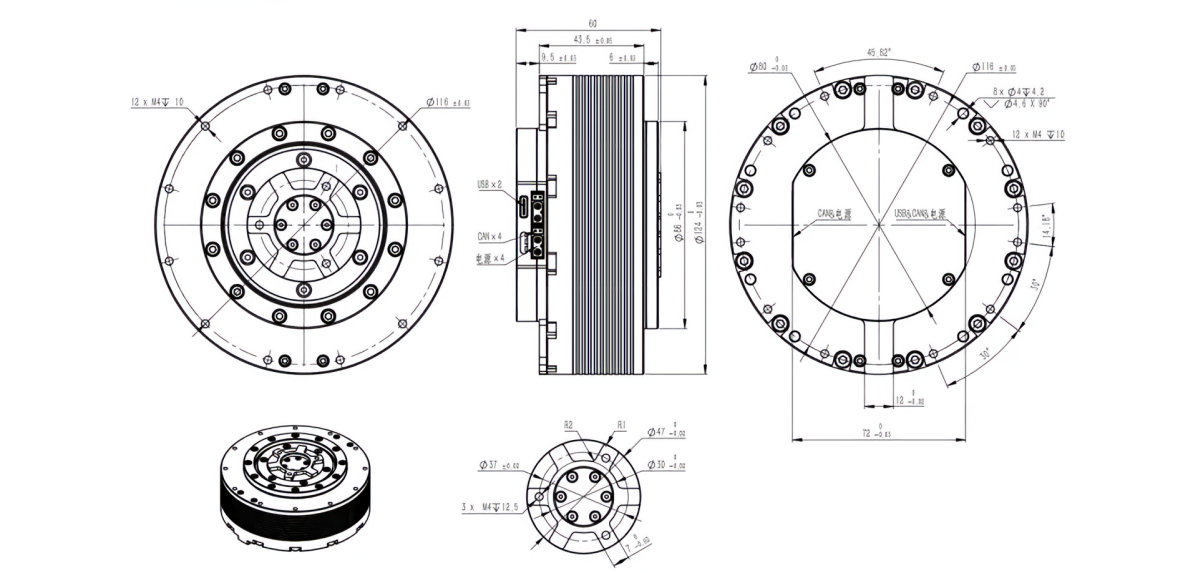
Performance Parameters | ||
Reduction Ratio | 12 | |
Rated Voltage | v | 48 |
Rated Bus Current | A | 18.34 |
Rated Phase Current | A | 21.04 |
Rated Power | W | 880 |
Rated Speed | RPM | 127 |
Rated Torque | Nm | 50 |
Peak Speed | RPM | 140 |
Peak Phase Current | A | 70 |
Peak Torque | Nm | 150 |
Efficiency | 79% | |
Torque Constant | Nm/A | 2.5 |
Weight | 8 | 1362 |
Backlash | Arcmin | 20 |
MotorSize | mm | 124×60 |
Communication Mode | CAN | |
Communication Baud Rate | IM | |
Double Encoder | yes | |
AxialAndRadialLoads | KN | 2.63 |
BendingMoment Resistance | Nm | 78 |
Cross Roller Bearing Type | 6005 | |
The Rotor Inertia OfThe Motor | kgmm² | 488.265 |
Torque Density | Nm/kg | 110.13 |
Introduction to the EC-A10020-P2-24 Motor
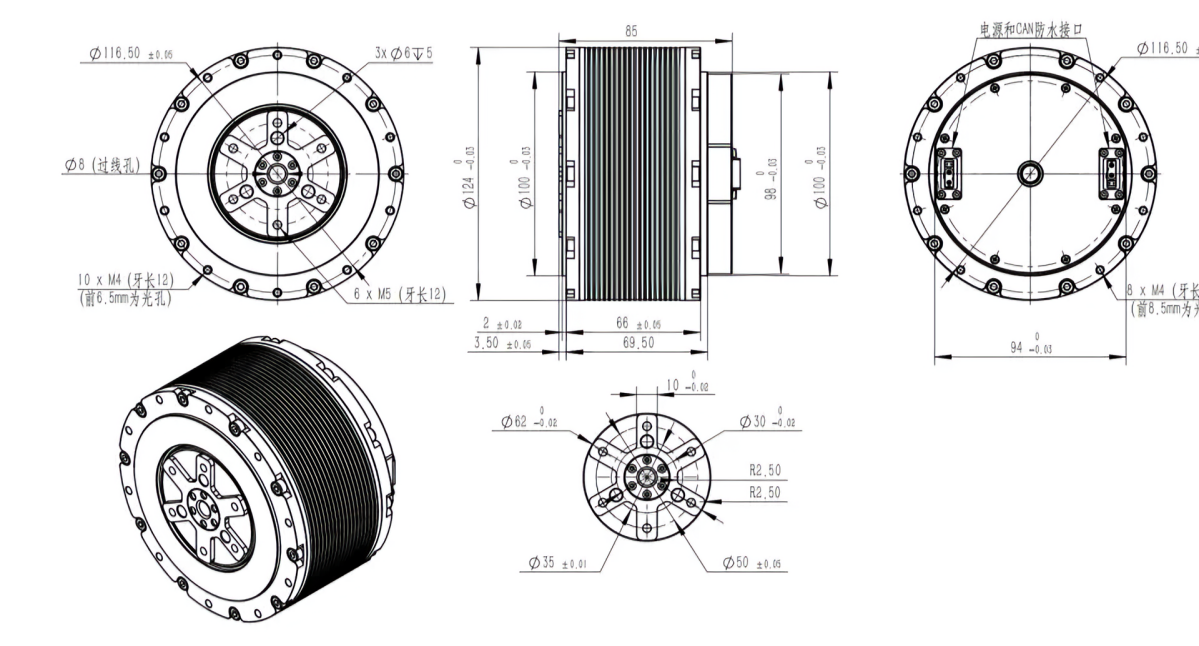
Performance Parameters | ||
Reduction Ratio | 24 | |
Rated Voltage | v | 48 |
Rated Bus Current | A | 35.12 |
Rated Phase Current | A | 44.05 |
Rated Power | W | 1686 |
Rated Speed | RPM | 115 |
Rated Torque | Nm | 100 |
Peak Speed | RPM | 123 |
Peak Phase Current | A | 140 |
Peak Torque | Nm | 330 |
Efficiency | 75% | |
Torque Constant | Nm/A | 2.6 |
Weight | 8 | 2180 |
Backlash | Arcmin | 20 |
MotorSize | mm | 124×85 |
Communication Mode | CAN | |
Communication Baud Rate | IM | |
Double Encoder | yes | |
AxialAndRadialLoads | KN | 6.76 |
BendingMoment Resistance | Nm | 300 |
Cross Roller Bearing Type | 9008 | |
The Rotor Inertia OfThe Motor | kgmm² | 476.222 |
Torque Density | Nm/kg | 151.38 |
EC-A13720-P1-11.4电机简介
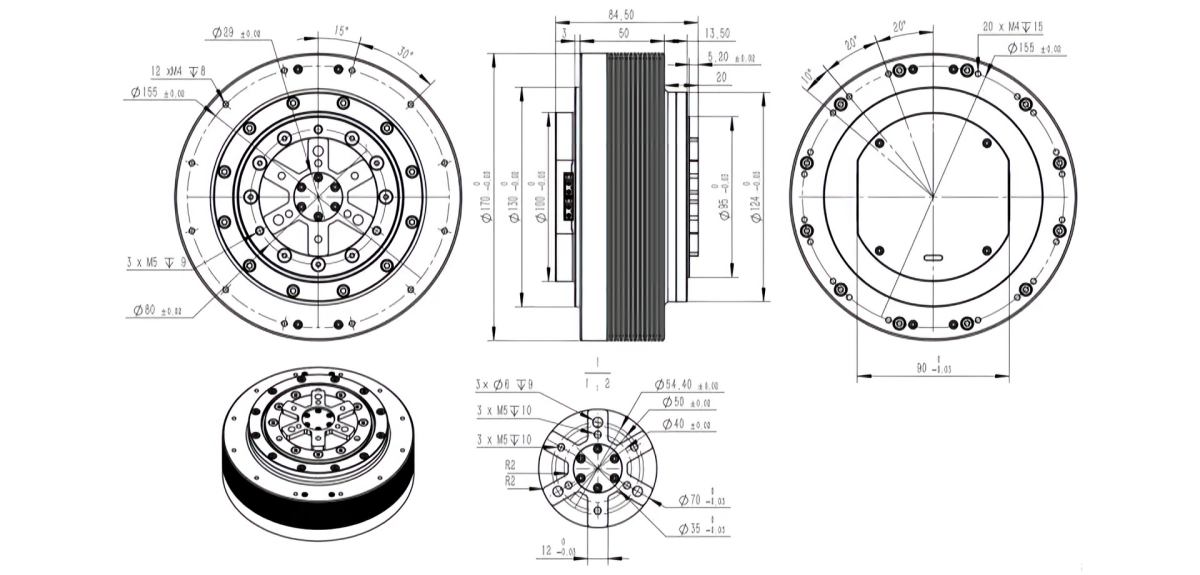
Performance Parameters | ||
Reduction Ratio | 11.4 | |
Rated Voltage | v | 48 |
Rated Bus Current | A | 36.6 |
Rated Phase Current | A | 46.7 |
Rated Power | W | 1756.8 |
Rated Speed | RPM | 126 |
Rated Torque | Nm | 120 |
Peak Speed | RPM | 139 |
Peak Phase Current | A | 220 |
Peak Torque | Nm | 400 |
Efficiency | 73% | |
Torque Constant | Nm/A | 2.5 |
Weight | 8 | 3109 |
Backlash | Arcmin | 15 |
MotorSize | mm | 170×84.5 |
Communication Mode | CAN | |
Communication Baud Rate | 1M | |
Double Encoder | yes | |
AxialAndRadialLoads | KN | 6.76 |
BendingMoment Resistance | Nm | 300 |
Cross Roller Bearing Type | 9008 | |
The Rotor Inertia OfThe Motor | kgmm² | 1506.601 |
Torque Density | Nm/kg | 128.66 |


