

Product Description
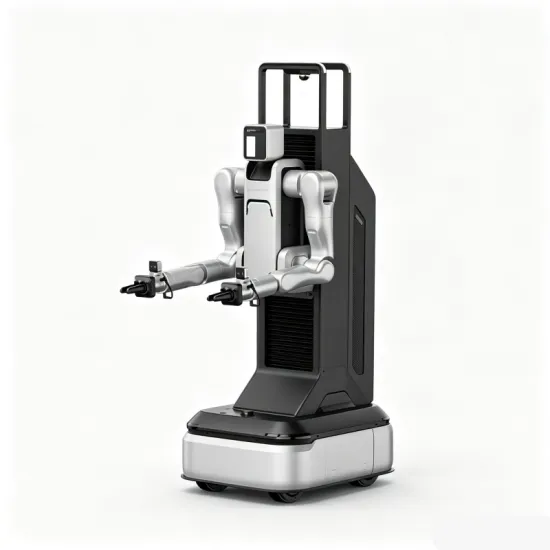
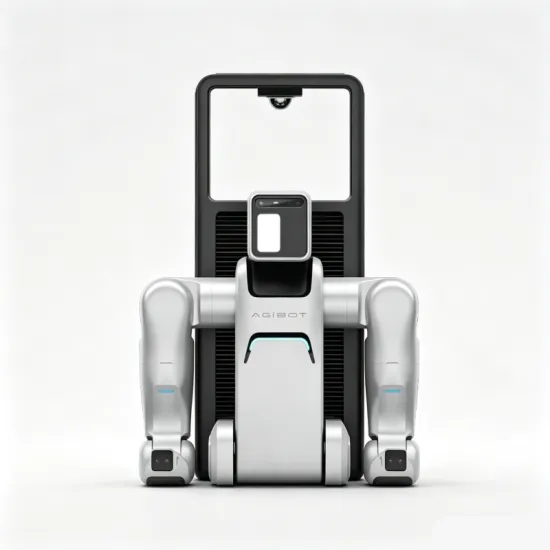
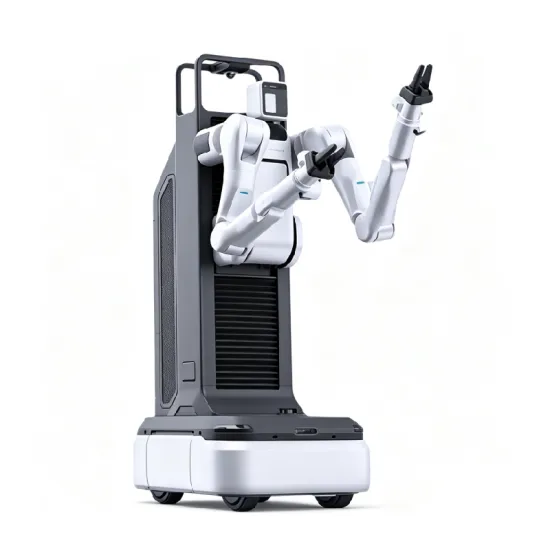
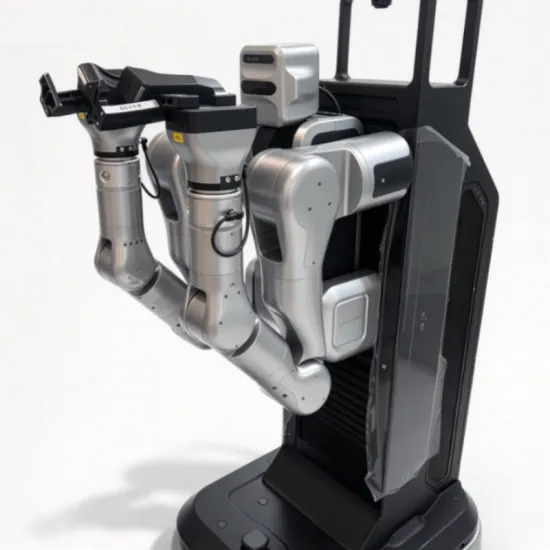
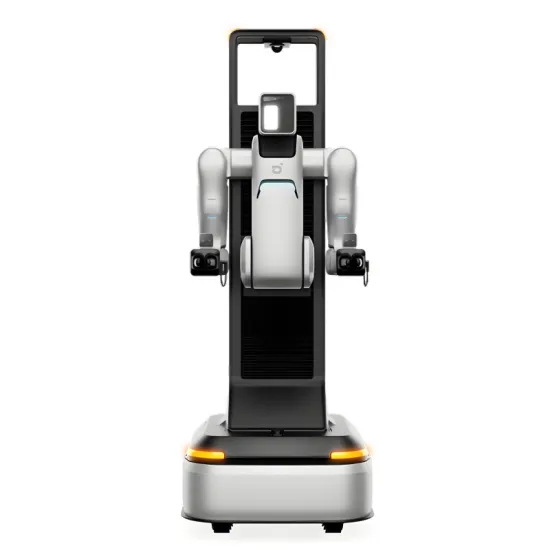
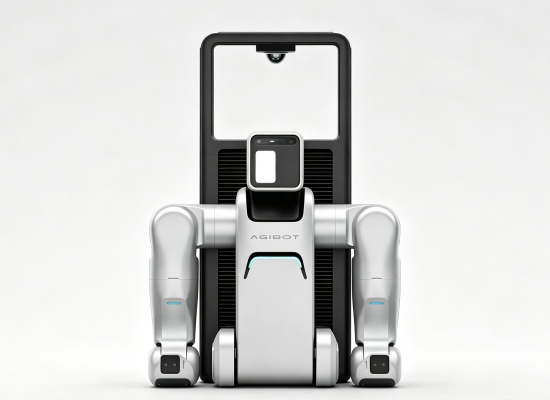
AgiBot Expedition A2-W Flexible Manufacturing Robot
Capable of performing tasks such as grabbing, placing, transporting, and plugging.
It featuresself-developed embodied intelligence algorithms, with open interfaces and tools to facilitatesecondary development.
The operational skills of AGIBOT A2-W improve with dataaccumulation, becoming smarter and more efficient over time.
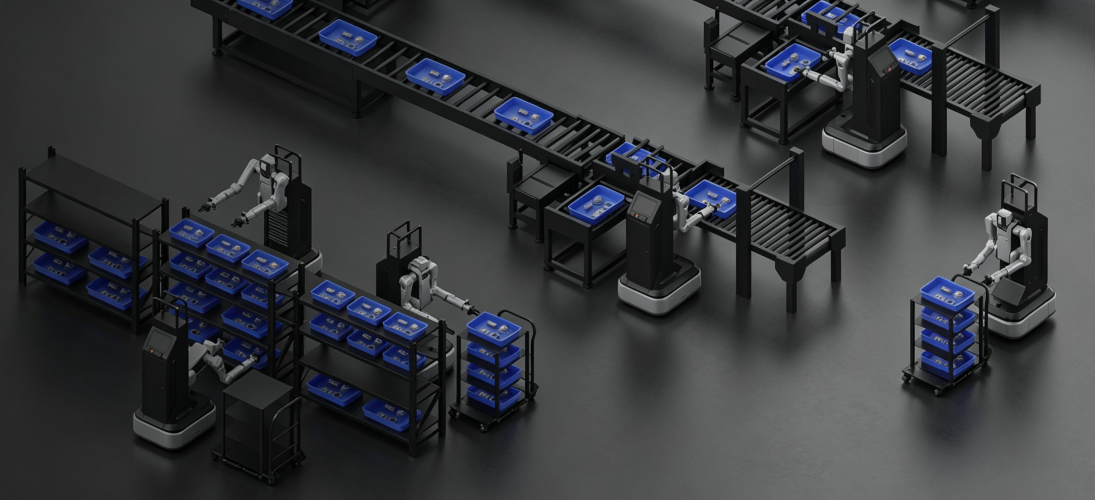
Flexible intelligent manufacturing experts create one‑stop solutions.
The AgiBot Expedition A2‑W wheeled universal robot targets flexible manufacturing scenarios.
It supports grasping, placing, transporting and inserting, equipped with self‑developed embodied AI algorithms and open interfaces for secondary development.
Its operational capabilities keep improving with data accumulation. Featuring biomimetic dual‑arms, high‑precision force control, multiple depth‑vision sensors and four‑wheel drive system, it works reliably in complex environments.
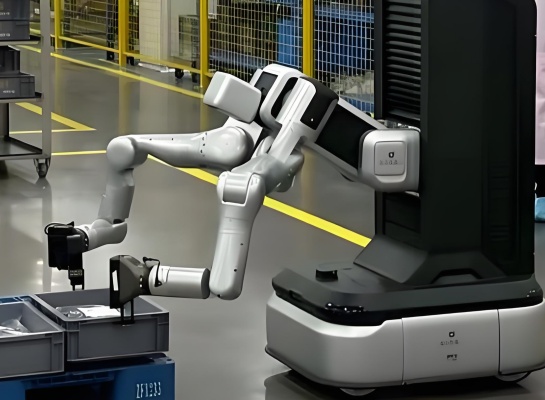
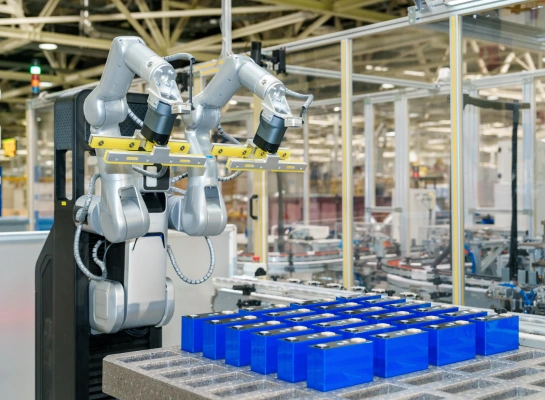
The integrated design enables out‑of‑box deployment with hot‑swap battery support. Ideal for loading‑unloading, terminal insertion and logistics transfer to upgrade production‑line flexible automation.
Functional Features
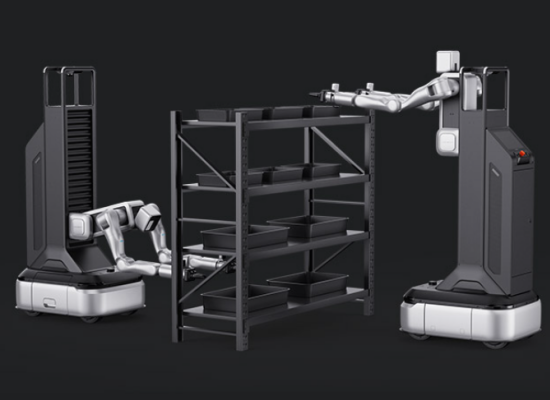
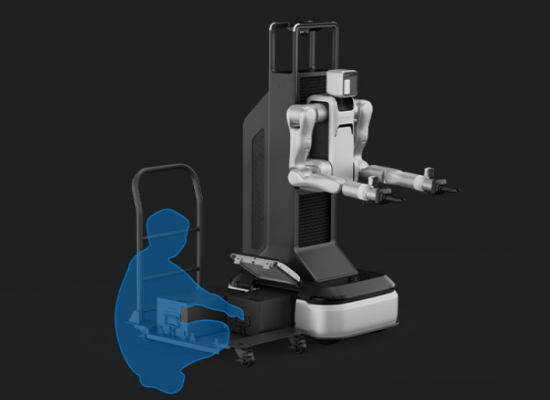
Dual arm collaboration, global accessibility
·Biomimetic seven degree of freedom dual arms, supporting parallel and asynchronous operations, capable of aerial relay and hand changing, easily handling complex workpieces and specific pose operations.
·Four wheel drive, supporting zero turning radius and crab walking, waist adjustable and pitching, 22 degrees of freedom covering human workspace in all directions.
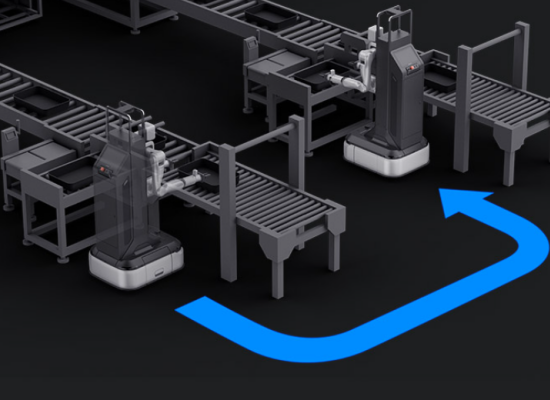
Efficient Deployment and Flexible Operation
·Integrated design of chassis, arms, and sensing system, supporting day level installation, debugging, and deployment time.
·Based on embodied atomic capabilities such as UniGrasp, Uni6DPose, UniPlug, and 275T computing power, it can achieve millisecond level real-time object recognition, pose estimation, and operational decision-making, dynamically adapting to flexible work environments.
·Through 3D model synthesis training and reinforcement learning, the replacement of operational objects can be shortened to the hour level at the fastest.
Model Evolution and Continuous Improvement
·Modular design of atomic capabilities allows for OTA iterative upgrades; thetask skill library can be continuously expanded, becoming richer with use.
·Embodied algorithms can be continuously optimized through data collection
and training, becoming smarter and more efficient over time
·Integrated design for data collection, simulation training, and inference
deployment supports efficient data acquisition and deployment.
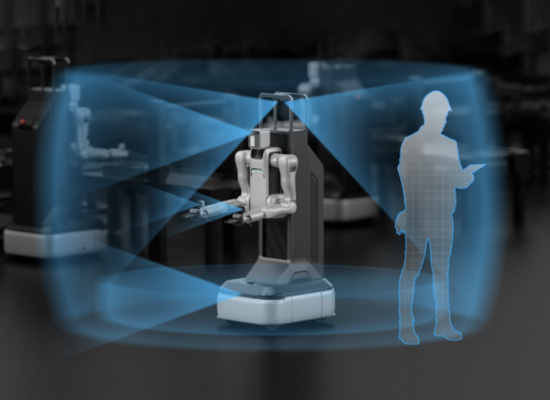
Multi-Modal Perception, Ensured Safety
·360° Lidar, 4 Al vision sensors, and 2 six-dimensional force sensors combine toprovide multi-sensor fusion perception, enabling millisecond-level detection andintelligent obstacle avoidance.
·The arm collision detection system, 360° real-time environmental sensing, andredundant perception and control design ensure safety for both personnel and the environment.
Sustained Operation and Minimal Maintenance
·Supports hot-swappable batteries with energy replenishment in minutes andautonomous charging, reducing manual intervention.
·Built-in real-time task self-diagnosis and self-recovery mechanisms minimize
unplanned downtime and maintenance efforts.
Application
Product parameters
Parameter | Value |
Machine Dimensions | 770(L)*620(W)*1630(H) mm |
Machine Weight | 230kg |
Battery Capacity | 2kWh |
Charging Time | 2h |
Operating Temperature | 0-45℃ |
Single Arm Load | 5kg |
Degrees of Freedom per Arm | 7 |
Operating Height | 0-2m |
Runtime | 5h, supports hot-swappable battery replacement |