




Product Description
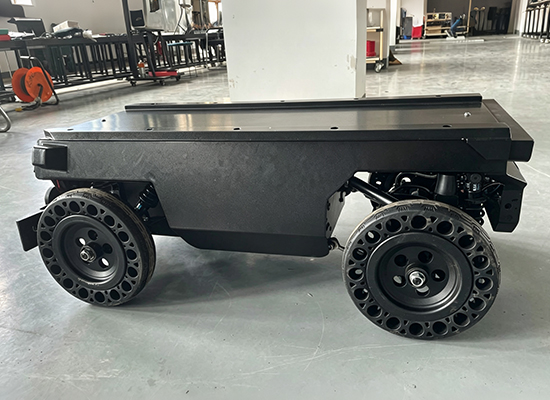
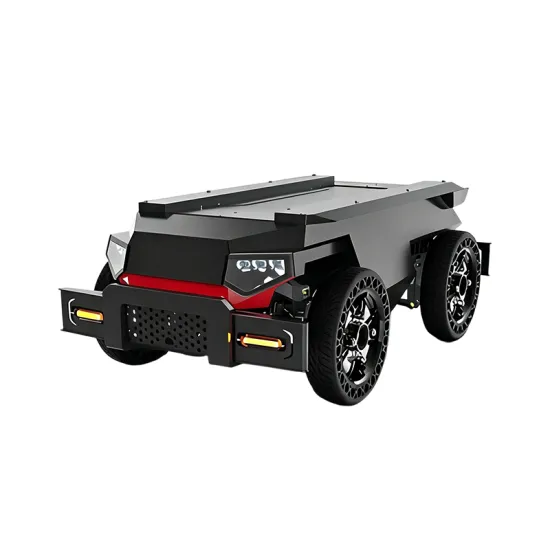
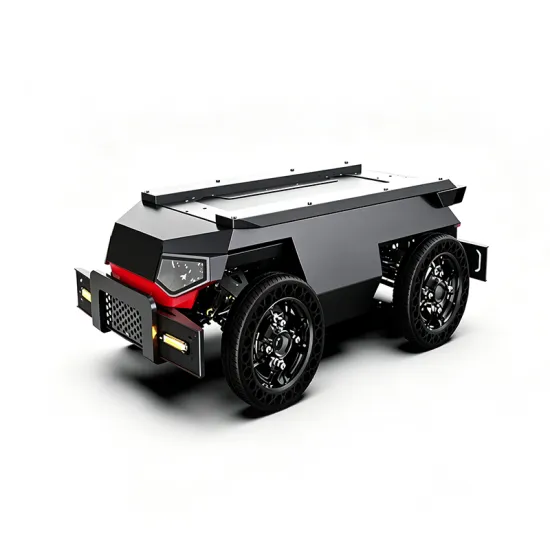
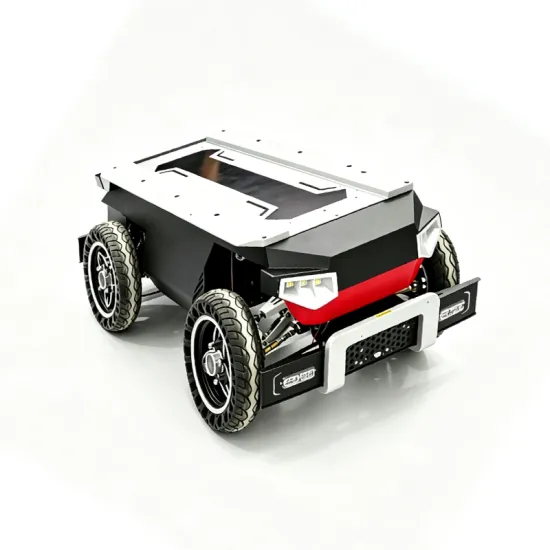
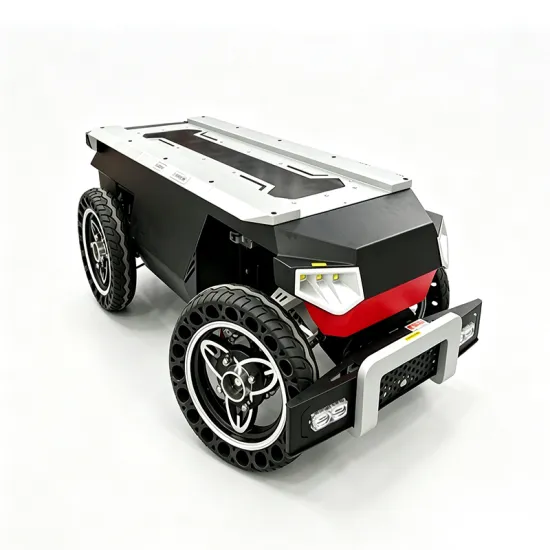
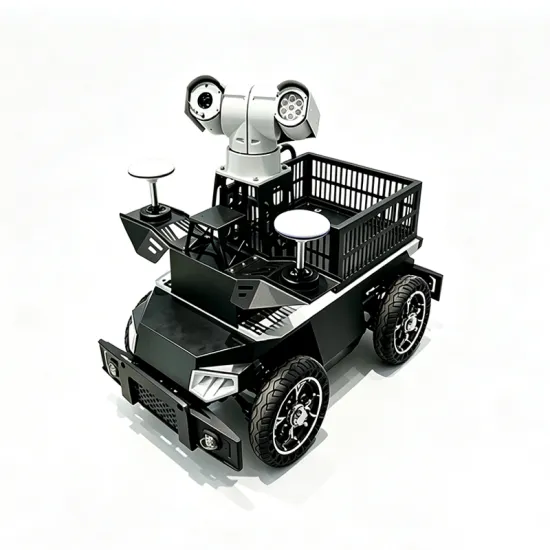
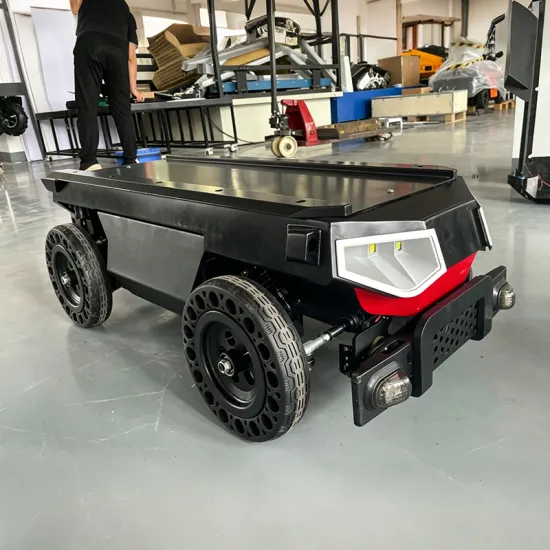
AVT-W14 is a universal wheeled mobile robot chassis, featuring a front Ackerman steering and an overall bridge differential drive system.
1. The front suspension structure of this chassis is compact and unique. It adopts a double A-arm left-right balanced pushrod single reduction transverse design, significantly improving the stability and passability of the entire vehicle.
2. In terms of the rear drive configuration, it uses an overall differential hard bridge, equipped with a DC brushless motor and driver. The motor has a encoder, and the driver has a complete communication interface.
3. The standard power battery is 48V 30Ah, and there is a BMS battery protection system.
The braking system is configured as front disc and rear drum, serving both driving and parking functions.
4. The tires are selected as explosion-proof solid tires, with strong road adaptability and no maintenance required.
5. The shell has been meticulously designed for industrial purposes, with a large internal space that is convenient for users to install electrical equipment.
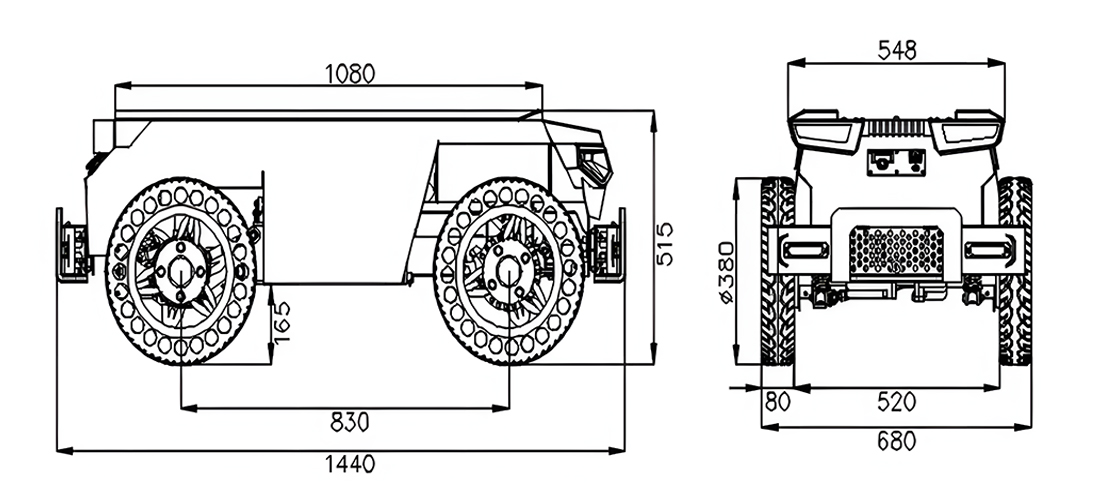
Dimensional Drawin
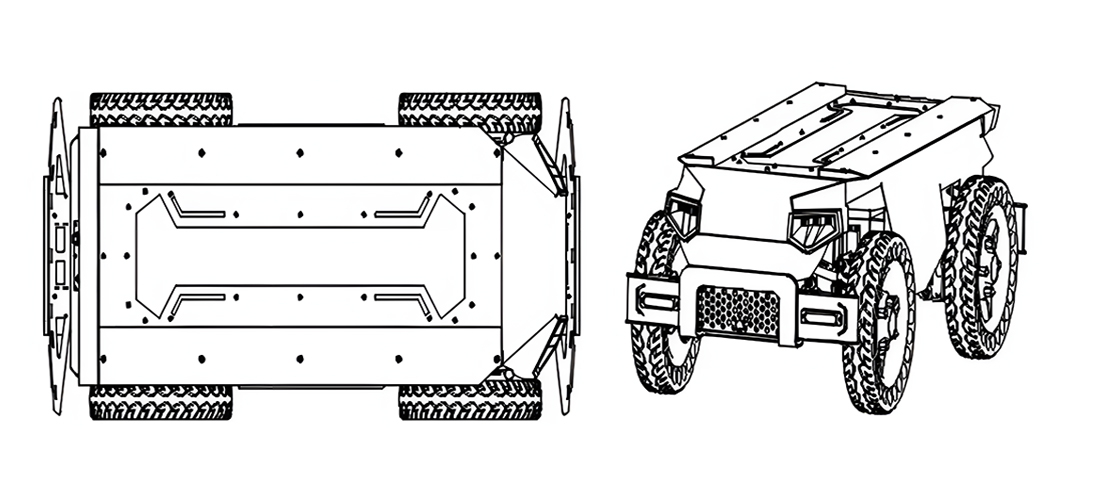
Product parameters
Indicator | Parameter | Indicator | Parameter |
Design Dimensions | 1440*680*515mm | Inner Cargo Compartment Size | 350*268*220mm (expandable) |
Chassis Self-Weight | 115kg | Travel Speed | 0-20km/h |
Tire Type/Specification | Puncture-proof Inflation-free Rubber Tire / 15 inch | Chassis Height | 165mm |
Main Material | Carbon Steel / Alloy Steel Plate / Aluminum Alloy | Ingress Protection Rating | IP54 |
Shock Absorber | 1 Front + 2 Rear | Surface Coating | Spray Paint / Powder Coating |
Drive Motor | 48V 800W DC Brushless Motor | Design Load Capacity | 100kg |
Rear Axle Reduction Ratio | 1:10 | Max. Climbing Angle | 8° |
Max. Obstacle-crossing Height | 150mm | Turning Radius | 2.2m |
Battery Capacity | 48V/30Ah | Driving Range | 40km |
Service
FAQ:


