

Product Description
Intelligent Bionic Hand
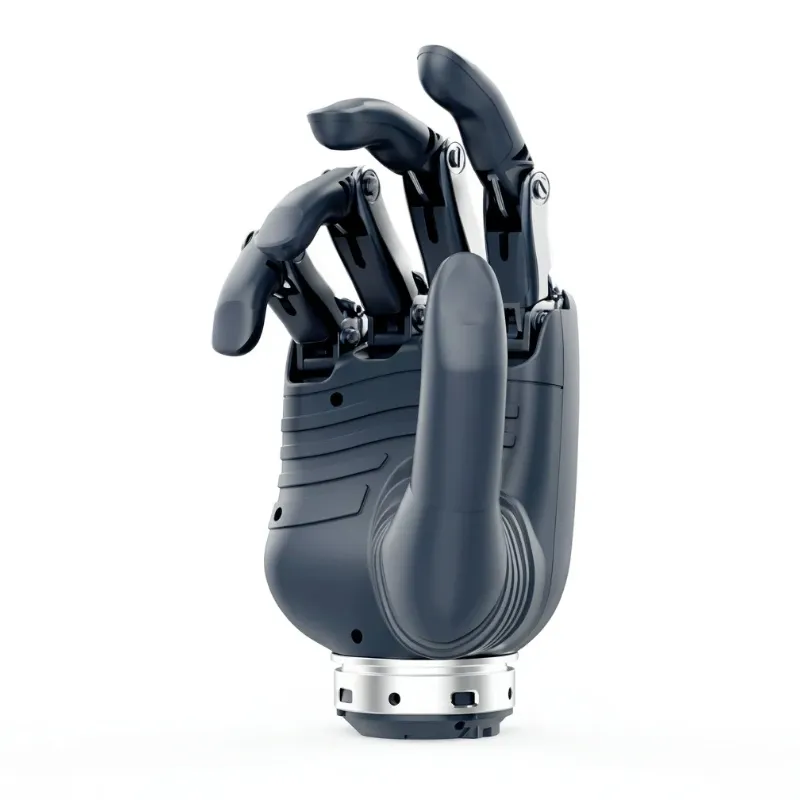
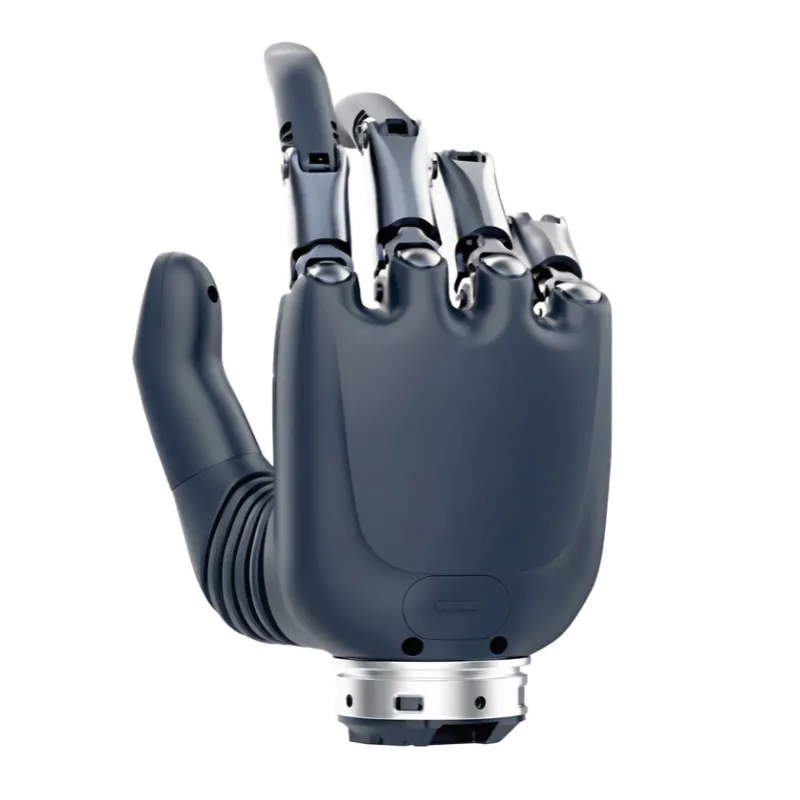
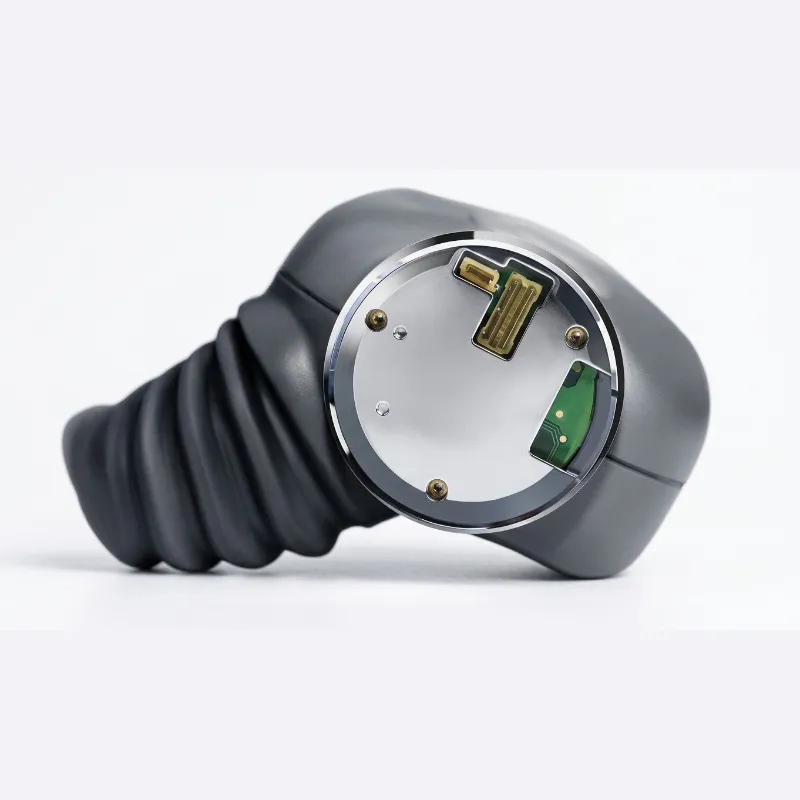
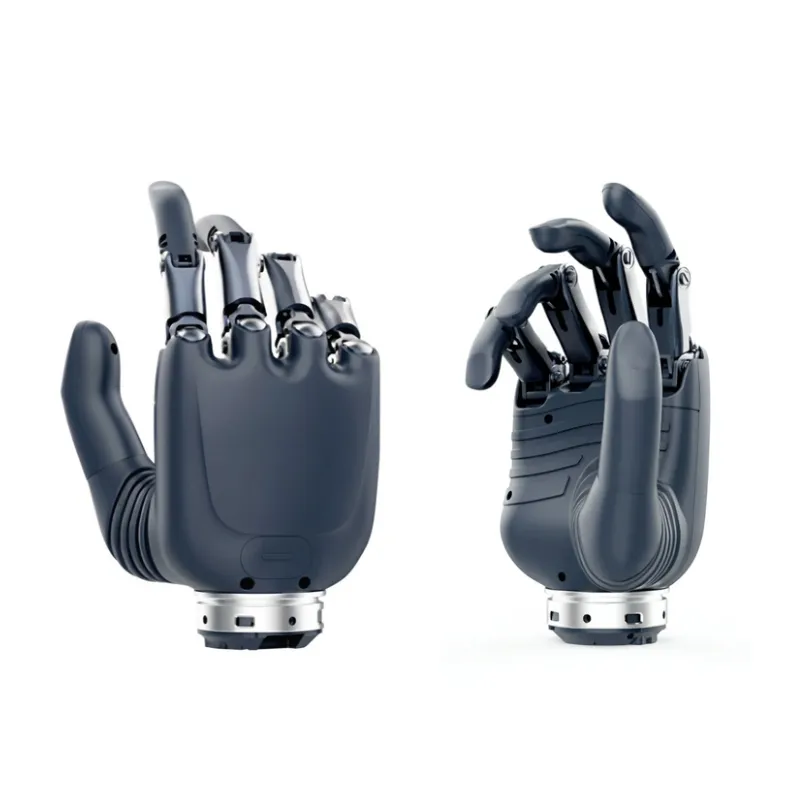
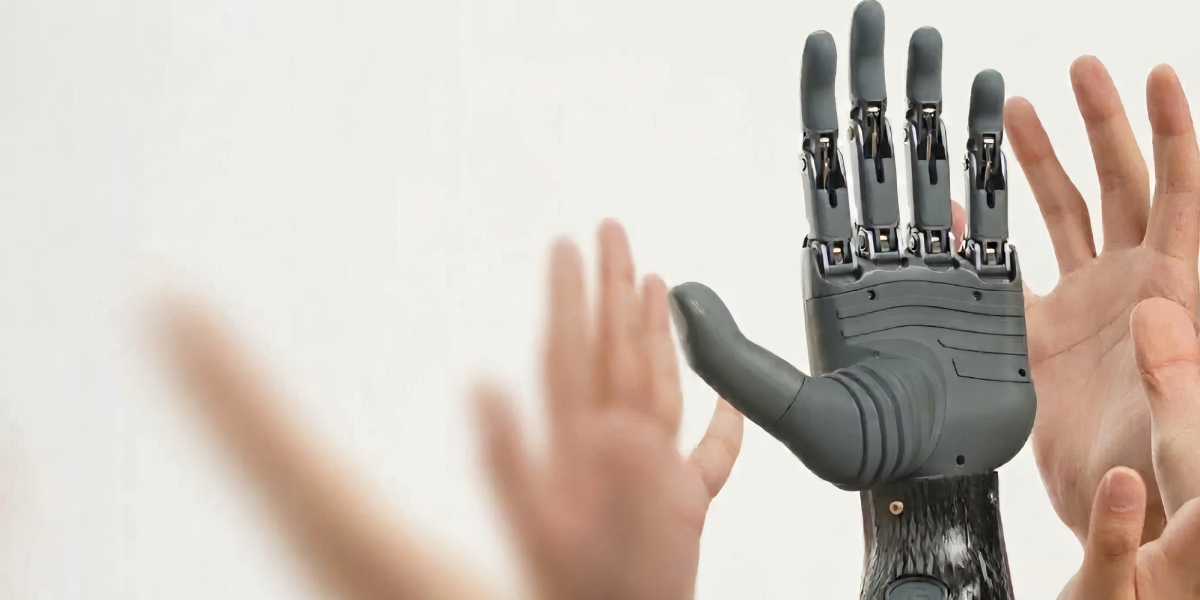
The BrainCo Intelligent Bionic Hand is a smart device that highly integrates brain-computer interface (BCI) technology with artificial intelligence algorithms. By detecting the wearer’s neural and muscular electrical signals, the bionic hand identifies their intended movements and translates these intentions into corresponding actions—enabling dexterous, intelligent operation that allows the hand to move in sync with the user’s intent.
 | Single Finger Point (Abducted) Touch the button switch to show number 8. To protect your bionic hand, avoid pressing fingers forcefully. |
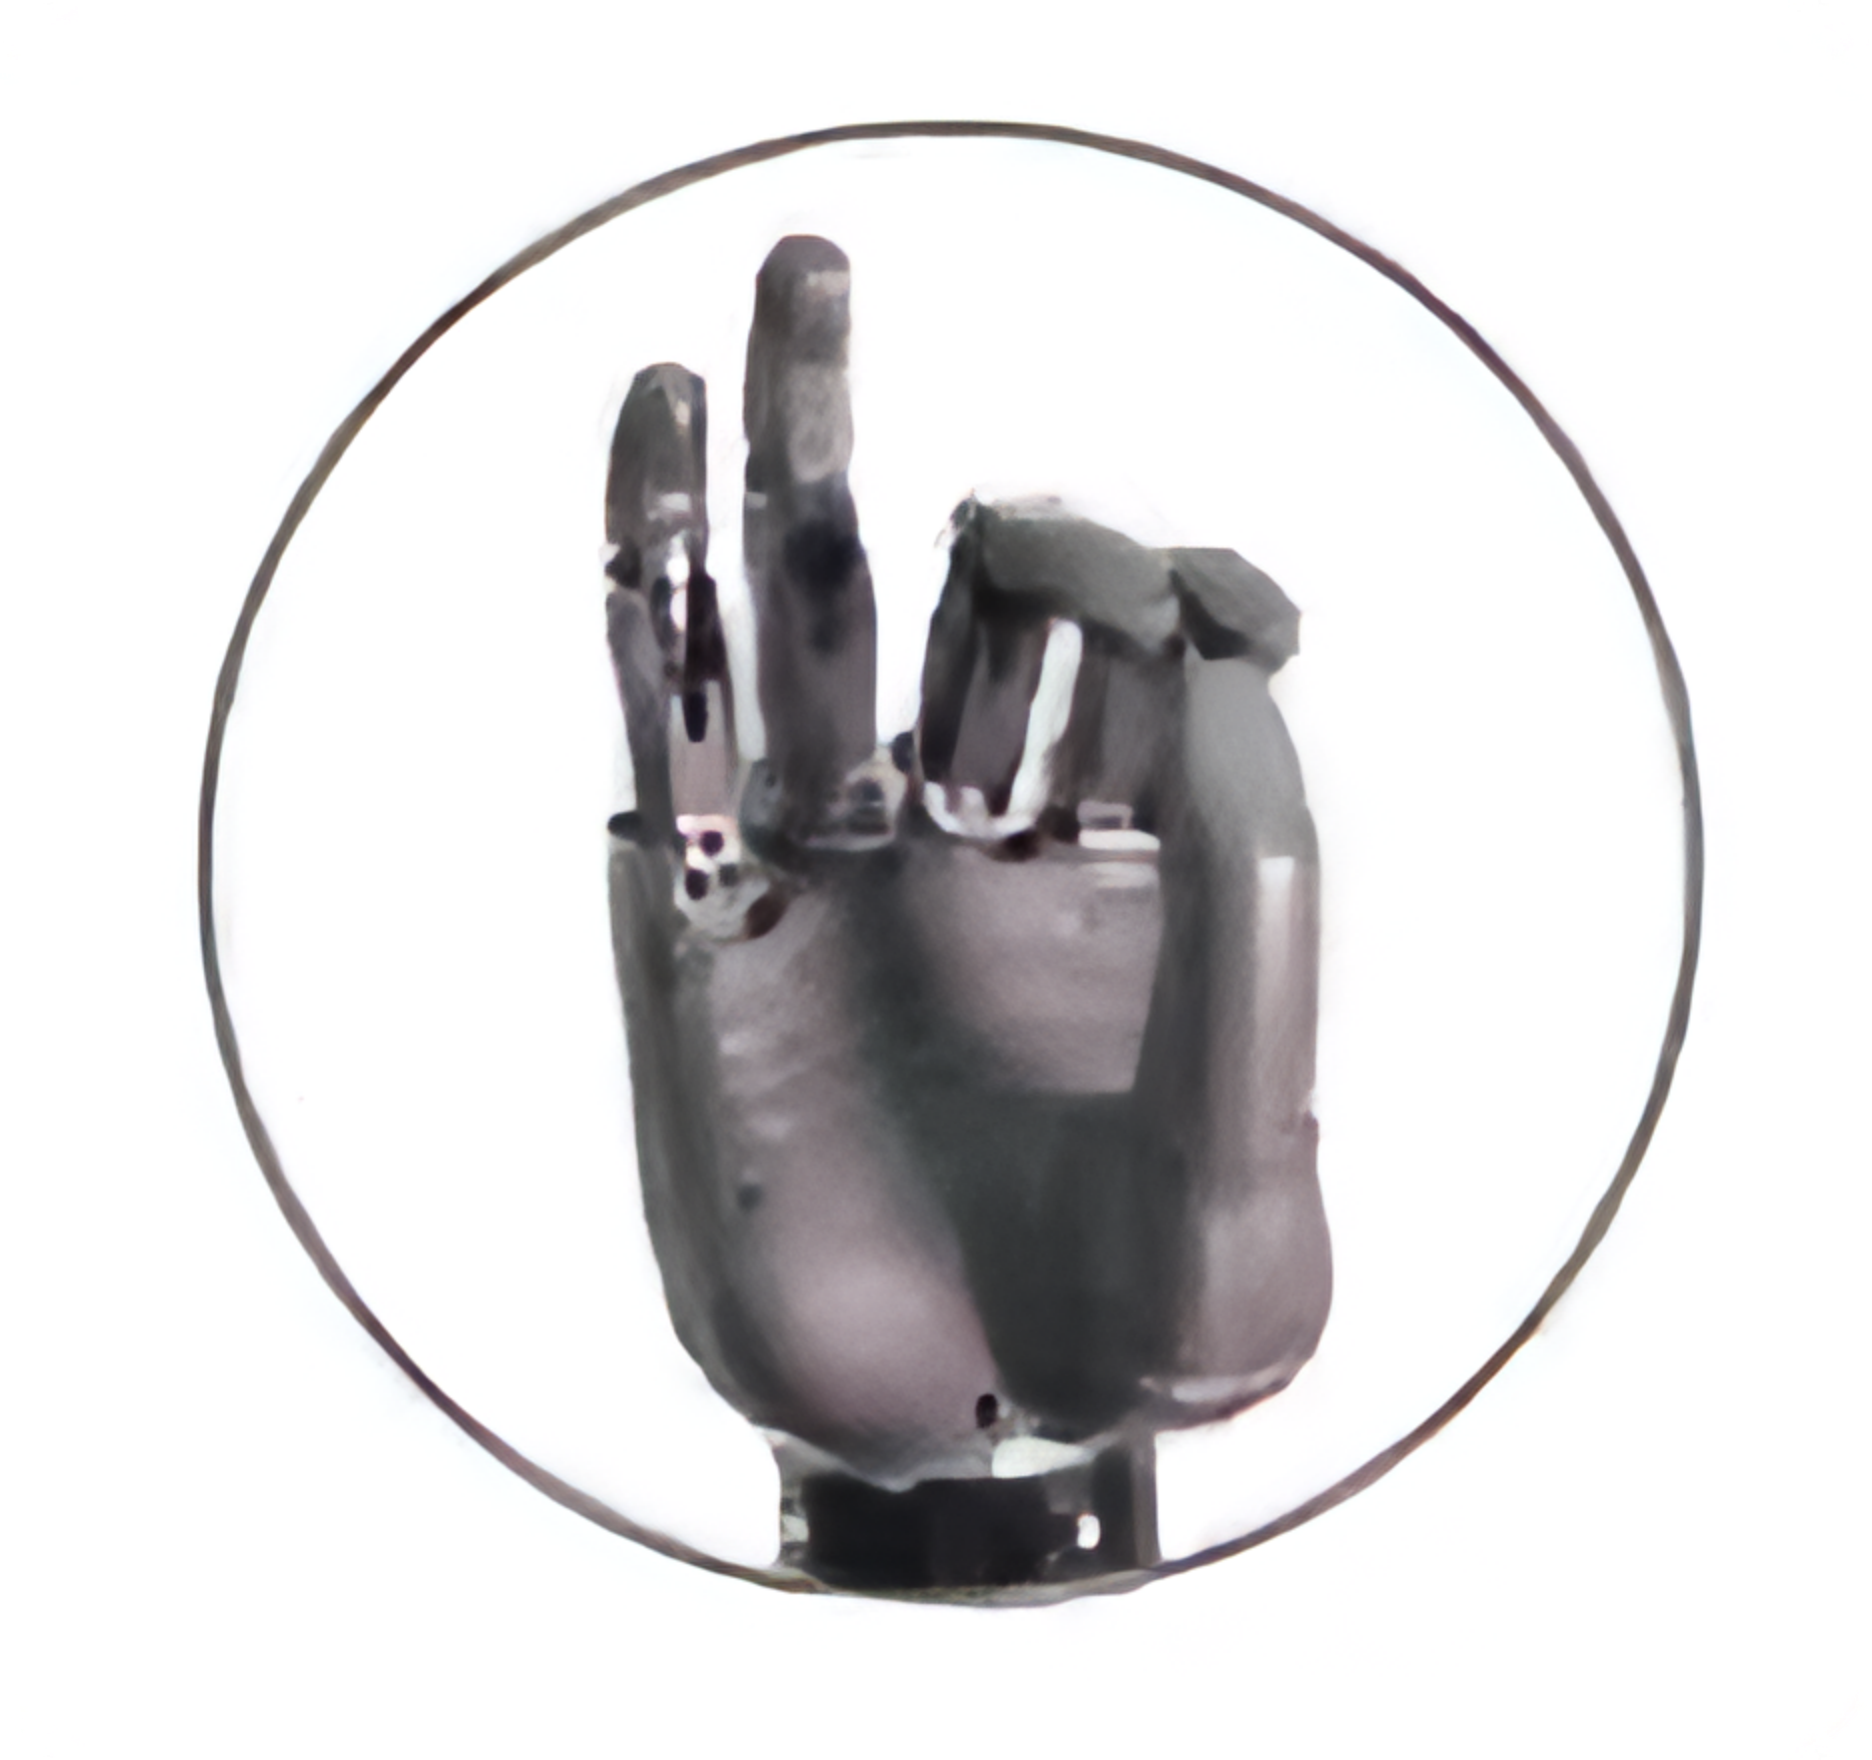 | Three-Finger Pinch (Abducted) Used to pinch medium objects or discs, such as phones, bottle caps, glue sticks. To protect your bionic hand, avoid pressing fingers forcefully. |
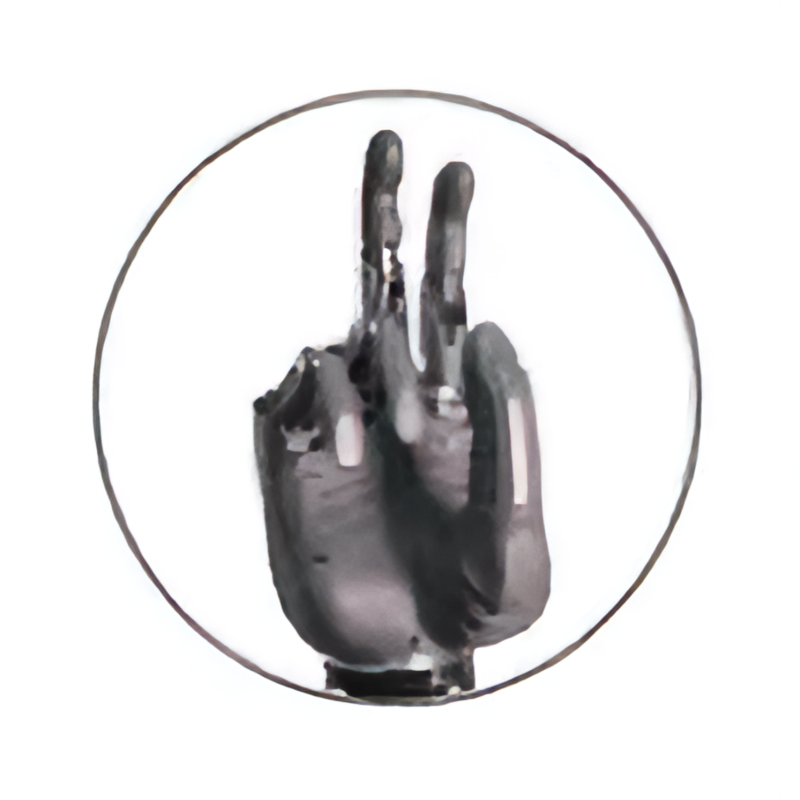 | Two-Finger Pinch (Adducted) Used to hold strip-shaped objects like cigarettes, or represent "Victory" and number 2. To protect your bionic hand, avoid clamping heavy objects. |
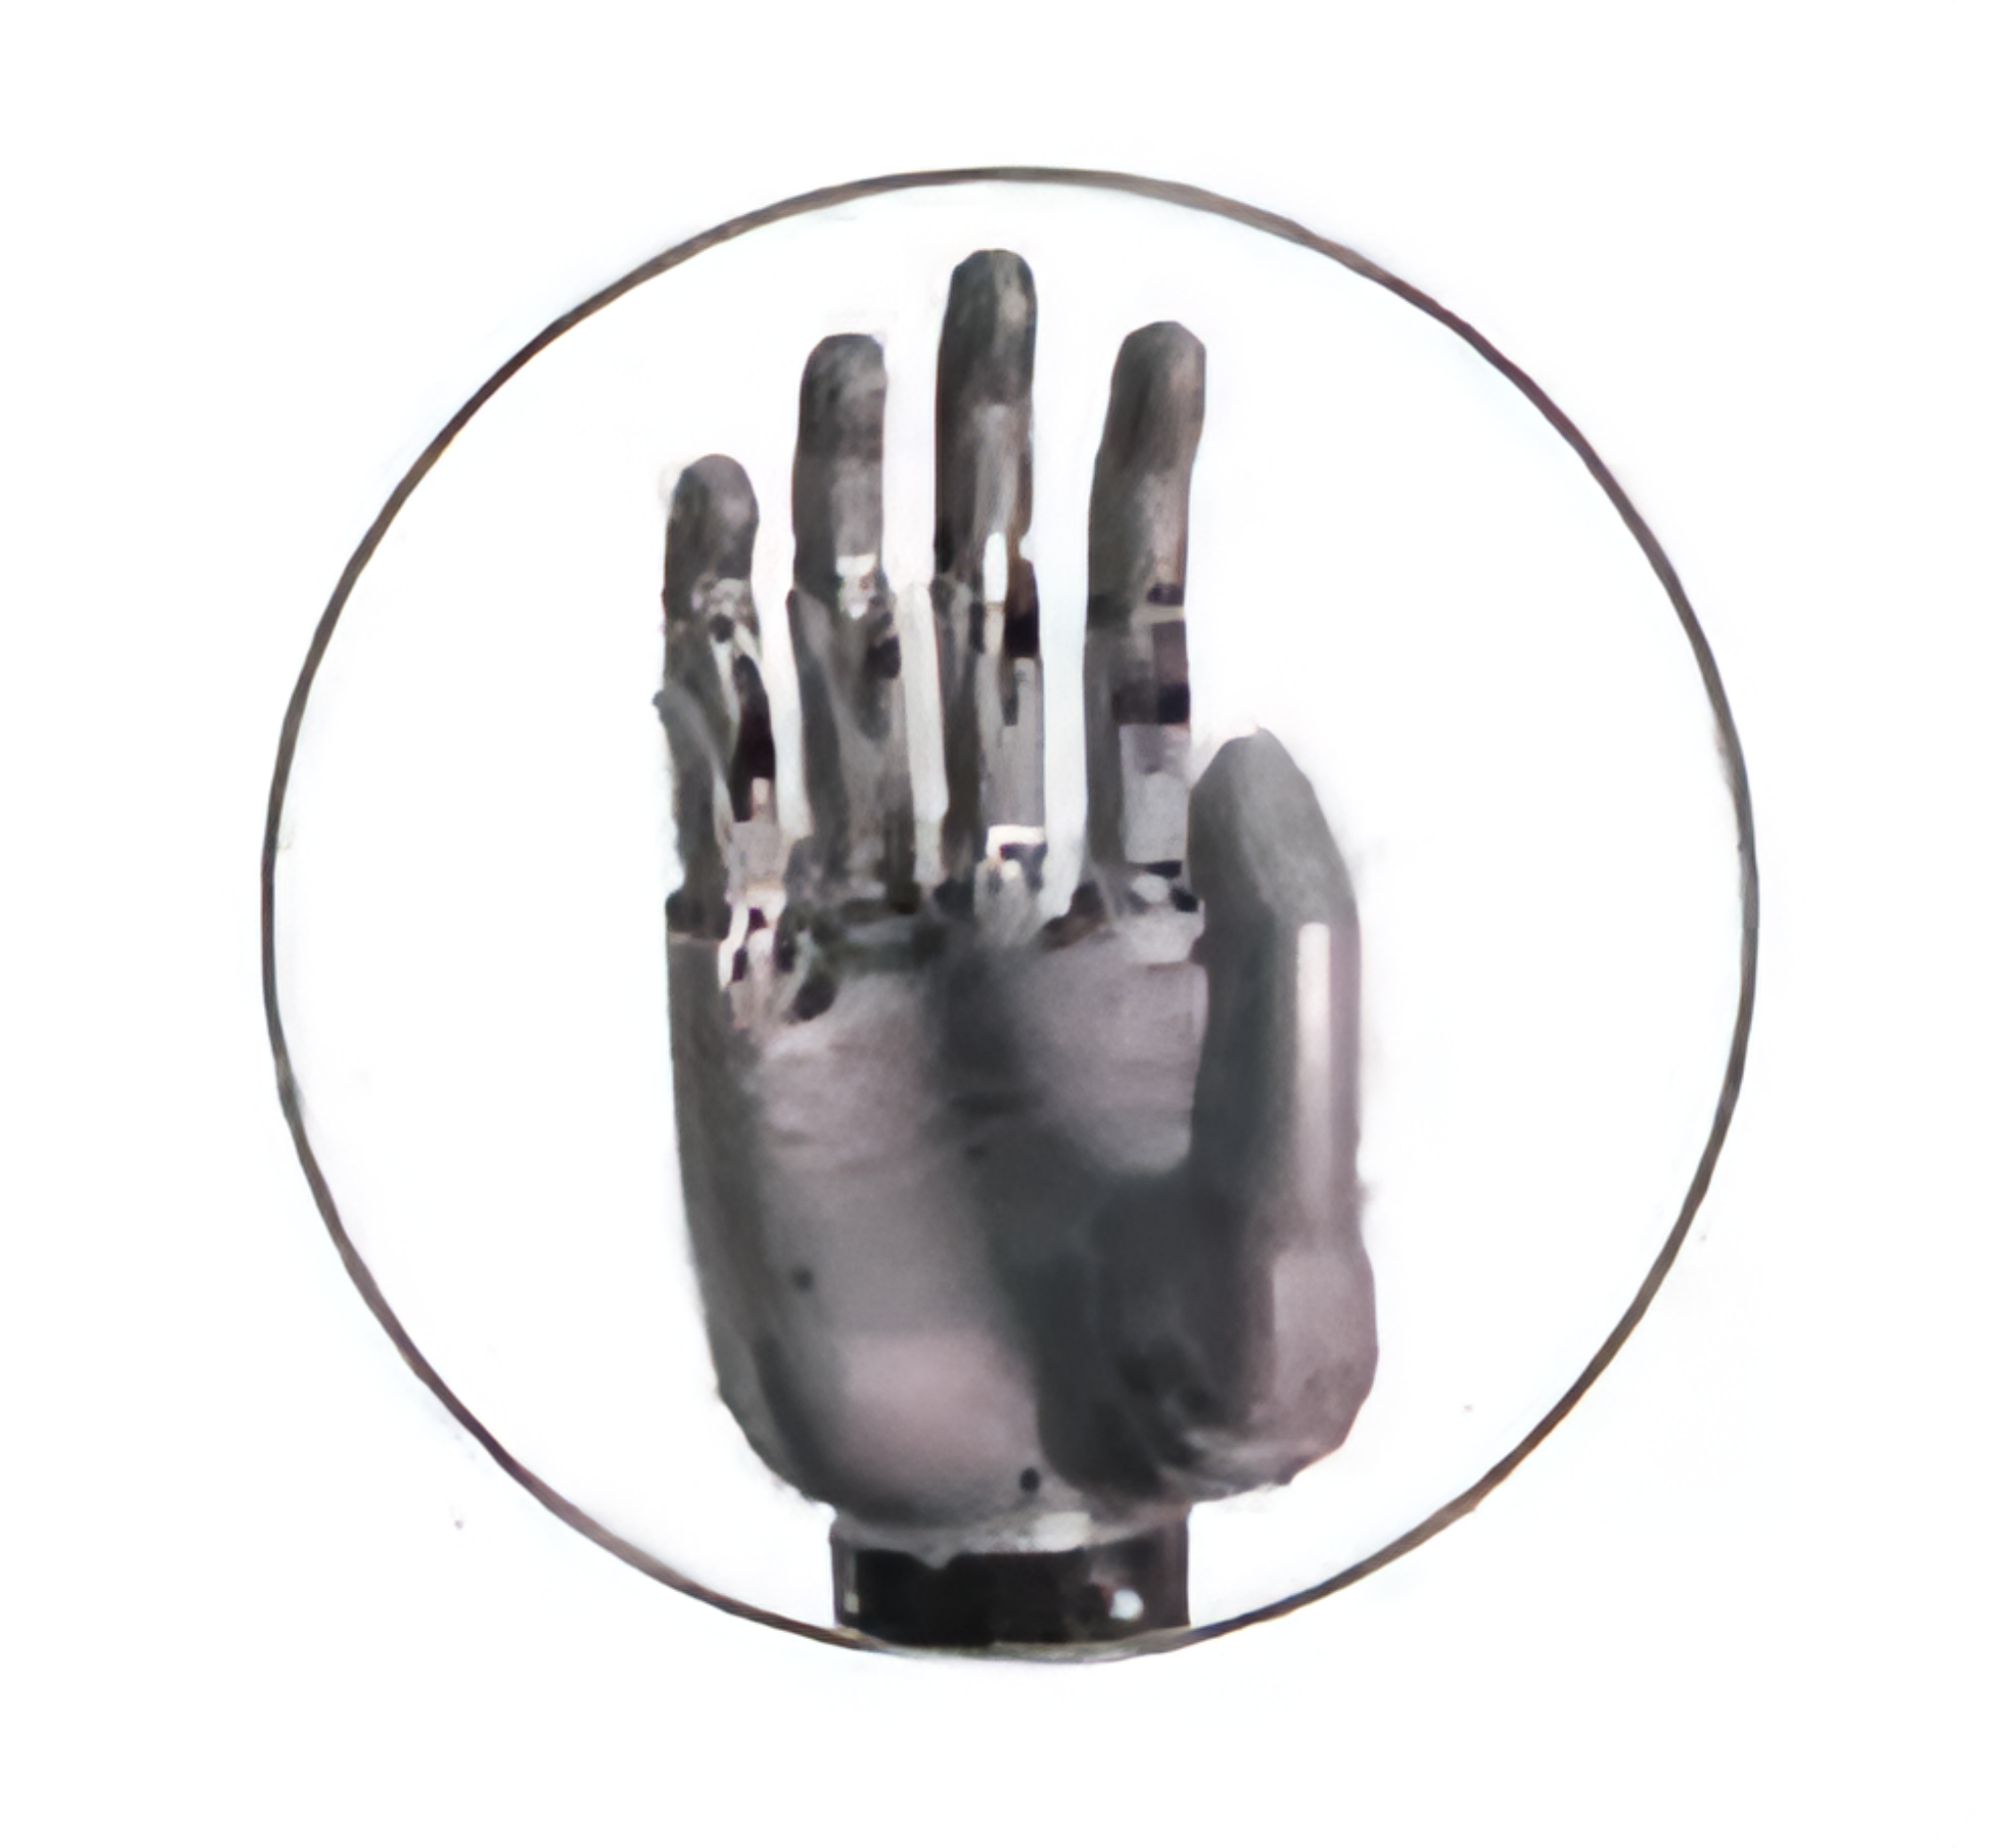 | Support-Pinch (Thumb Adducted) Used for supporting bowls, plates, etc. Represents the number 4. |
| Two-Finger Pinch (Abducted) Used to hold strip-shaped objects like cigarettes. To protect your bionic hand, avoid clamping heavy objects. |
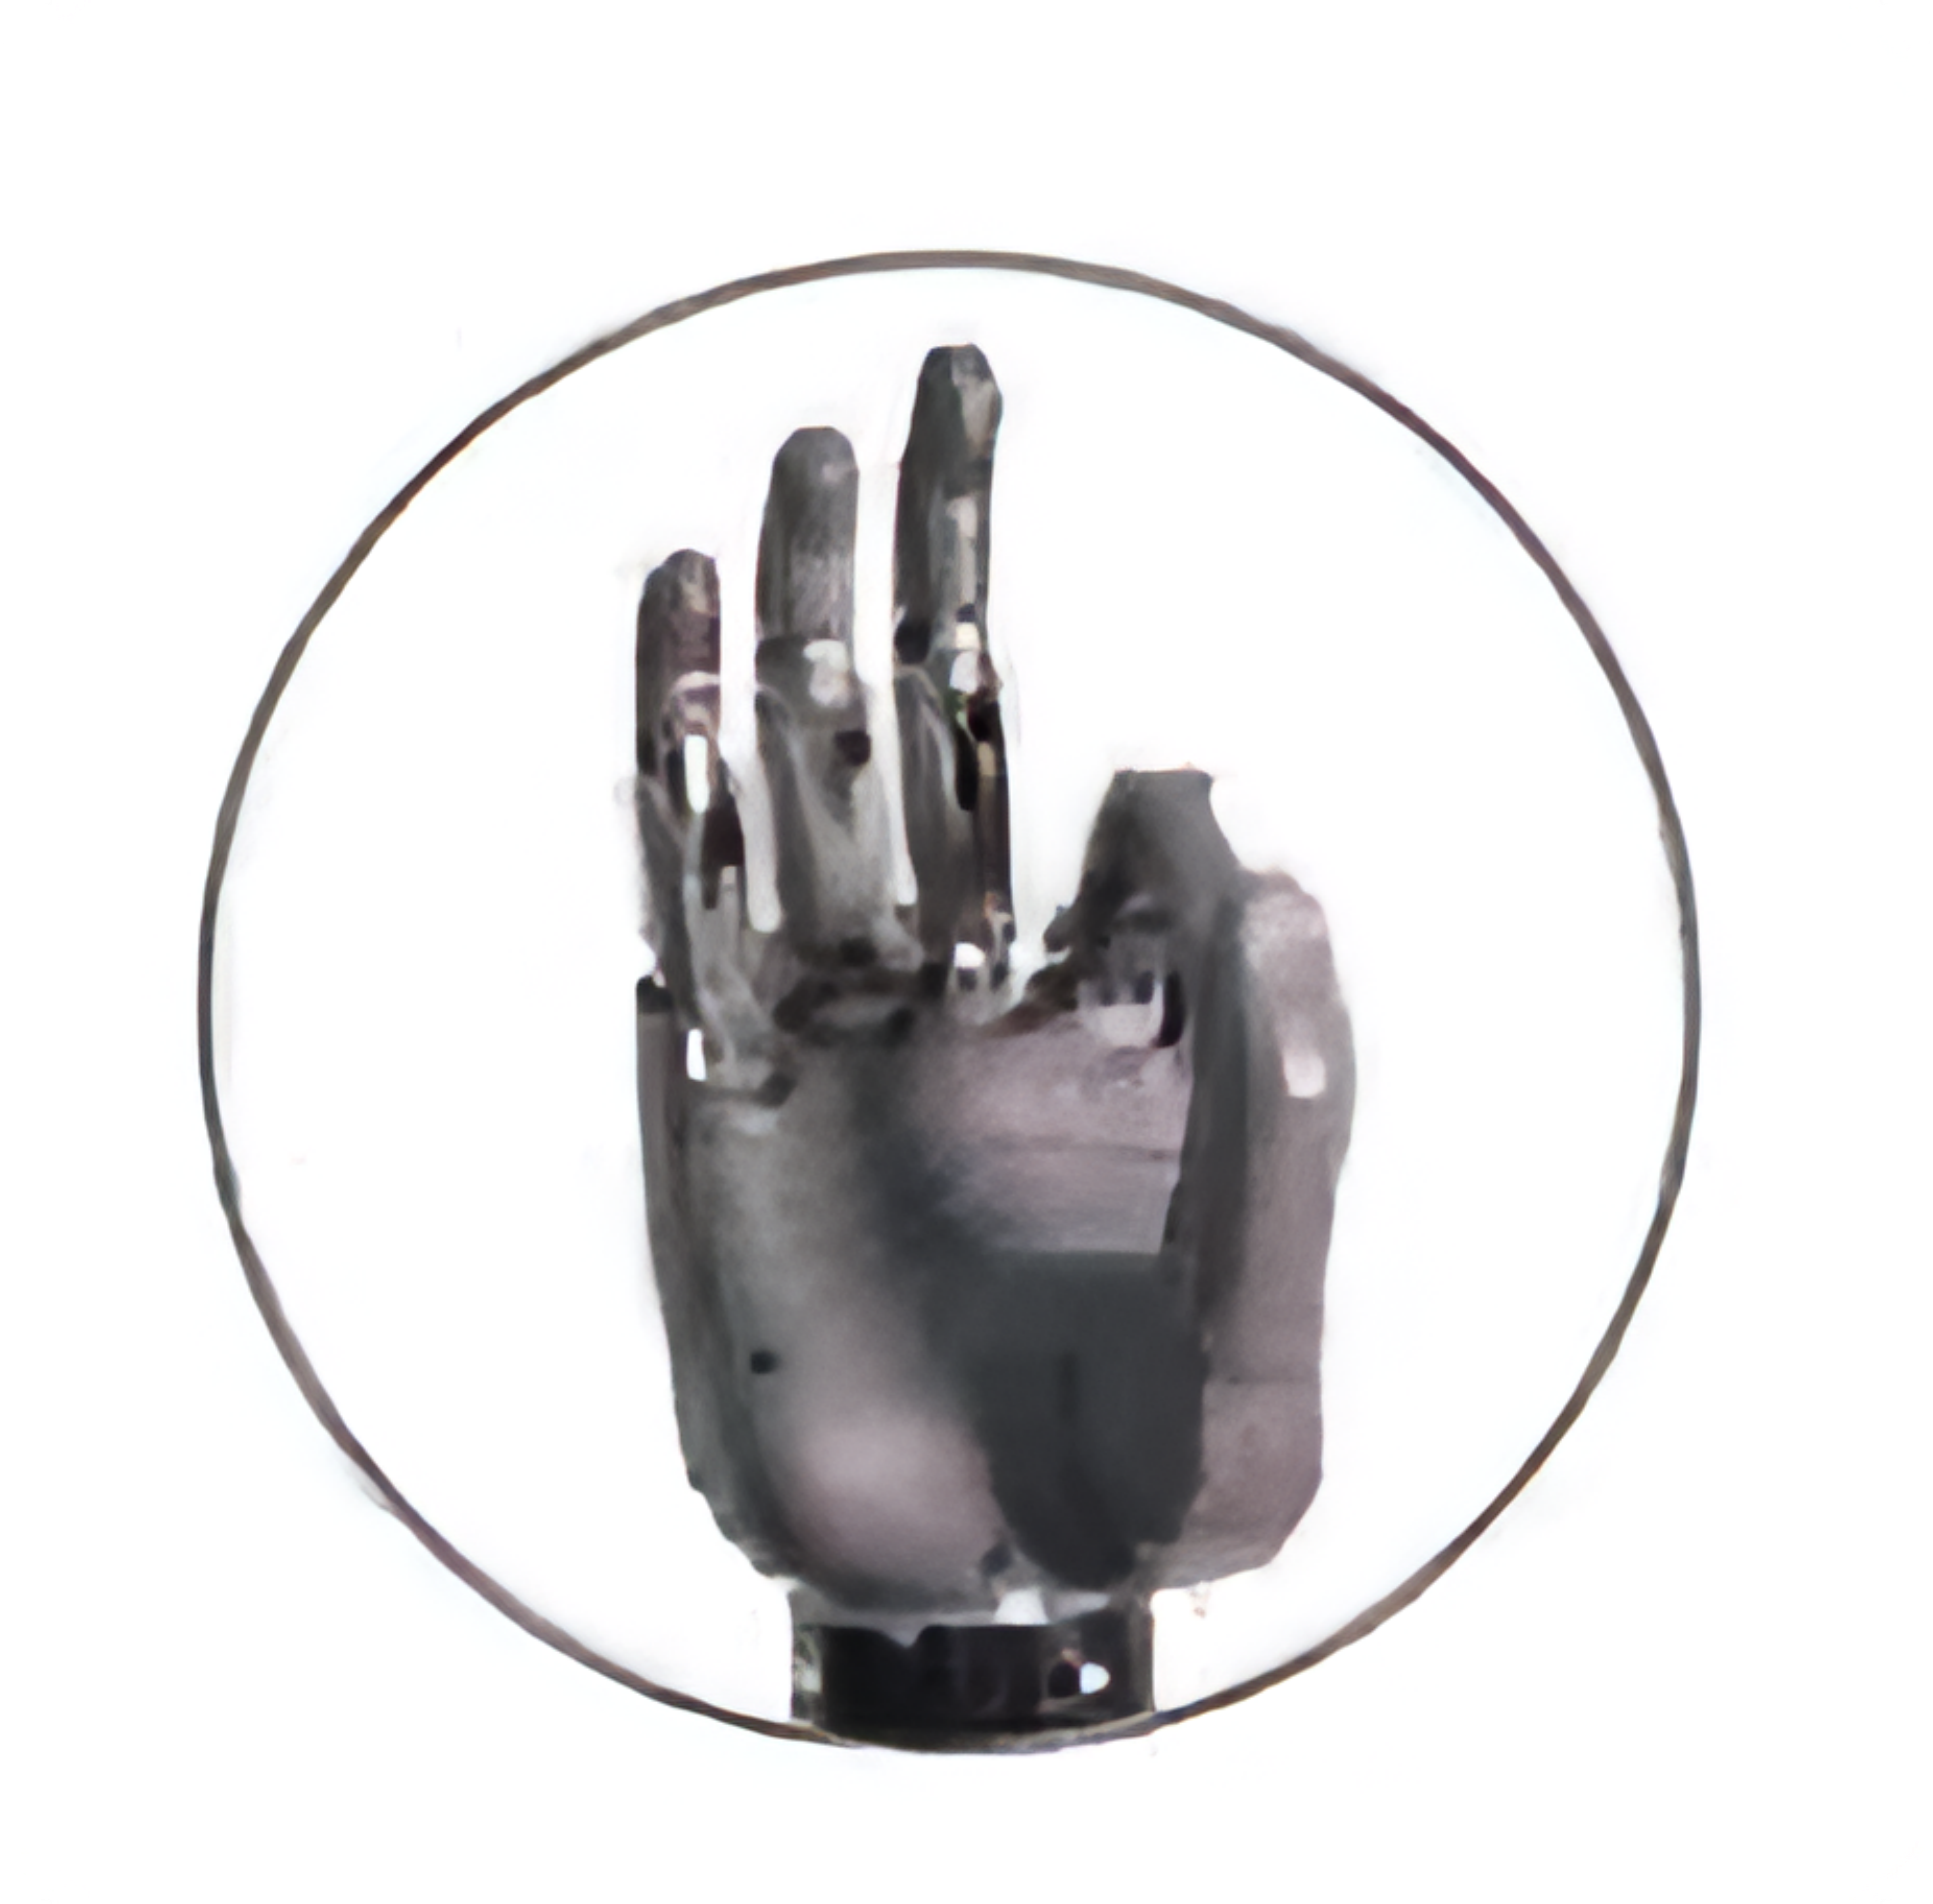 | Index Finger Flick Uses a motor and torsion spring to flick the index finger outward. To protect your bionic hand, it is recommended not to use this gesture frequently. |
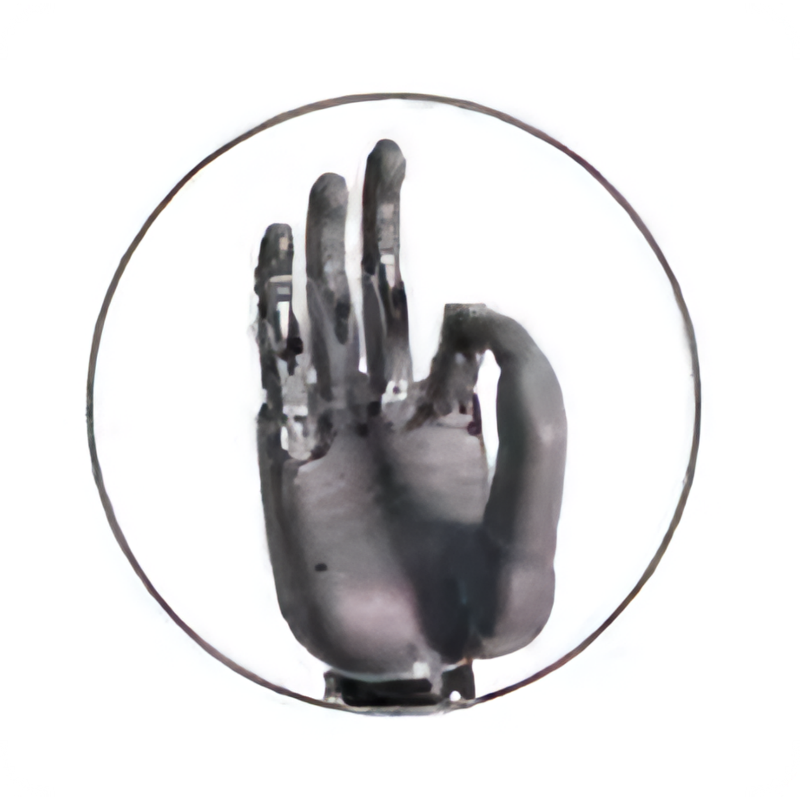 | Two-Finger Pinch (Abducted) Used to pinch objects of smaller size and weight, representing "OK". To protect your bionic hand, avoid hooking heavy objects with a single finger. |
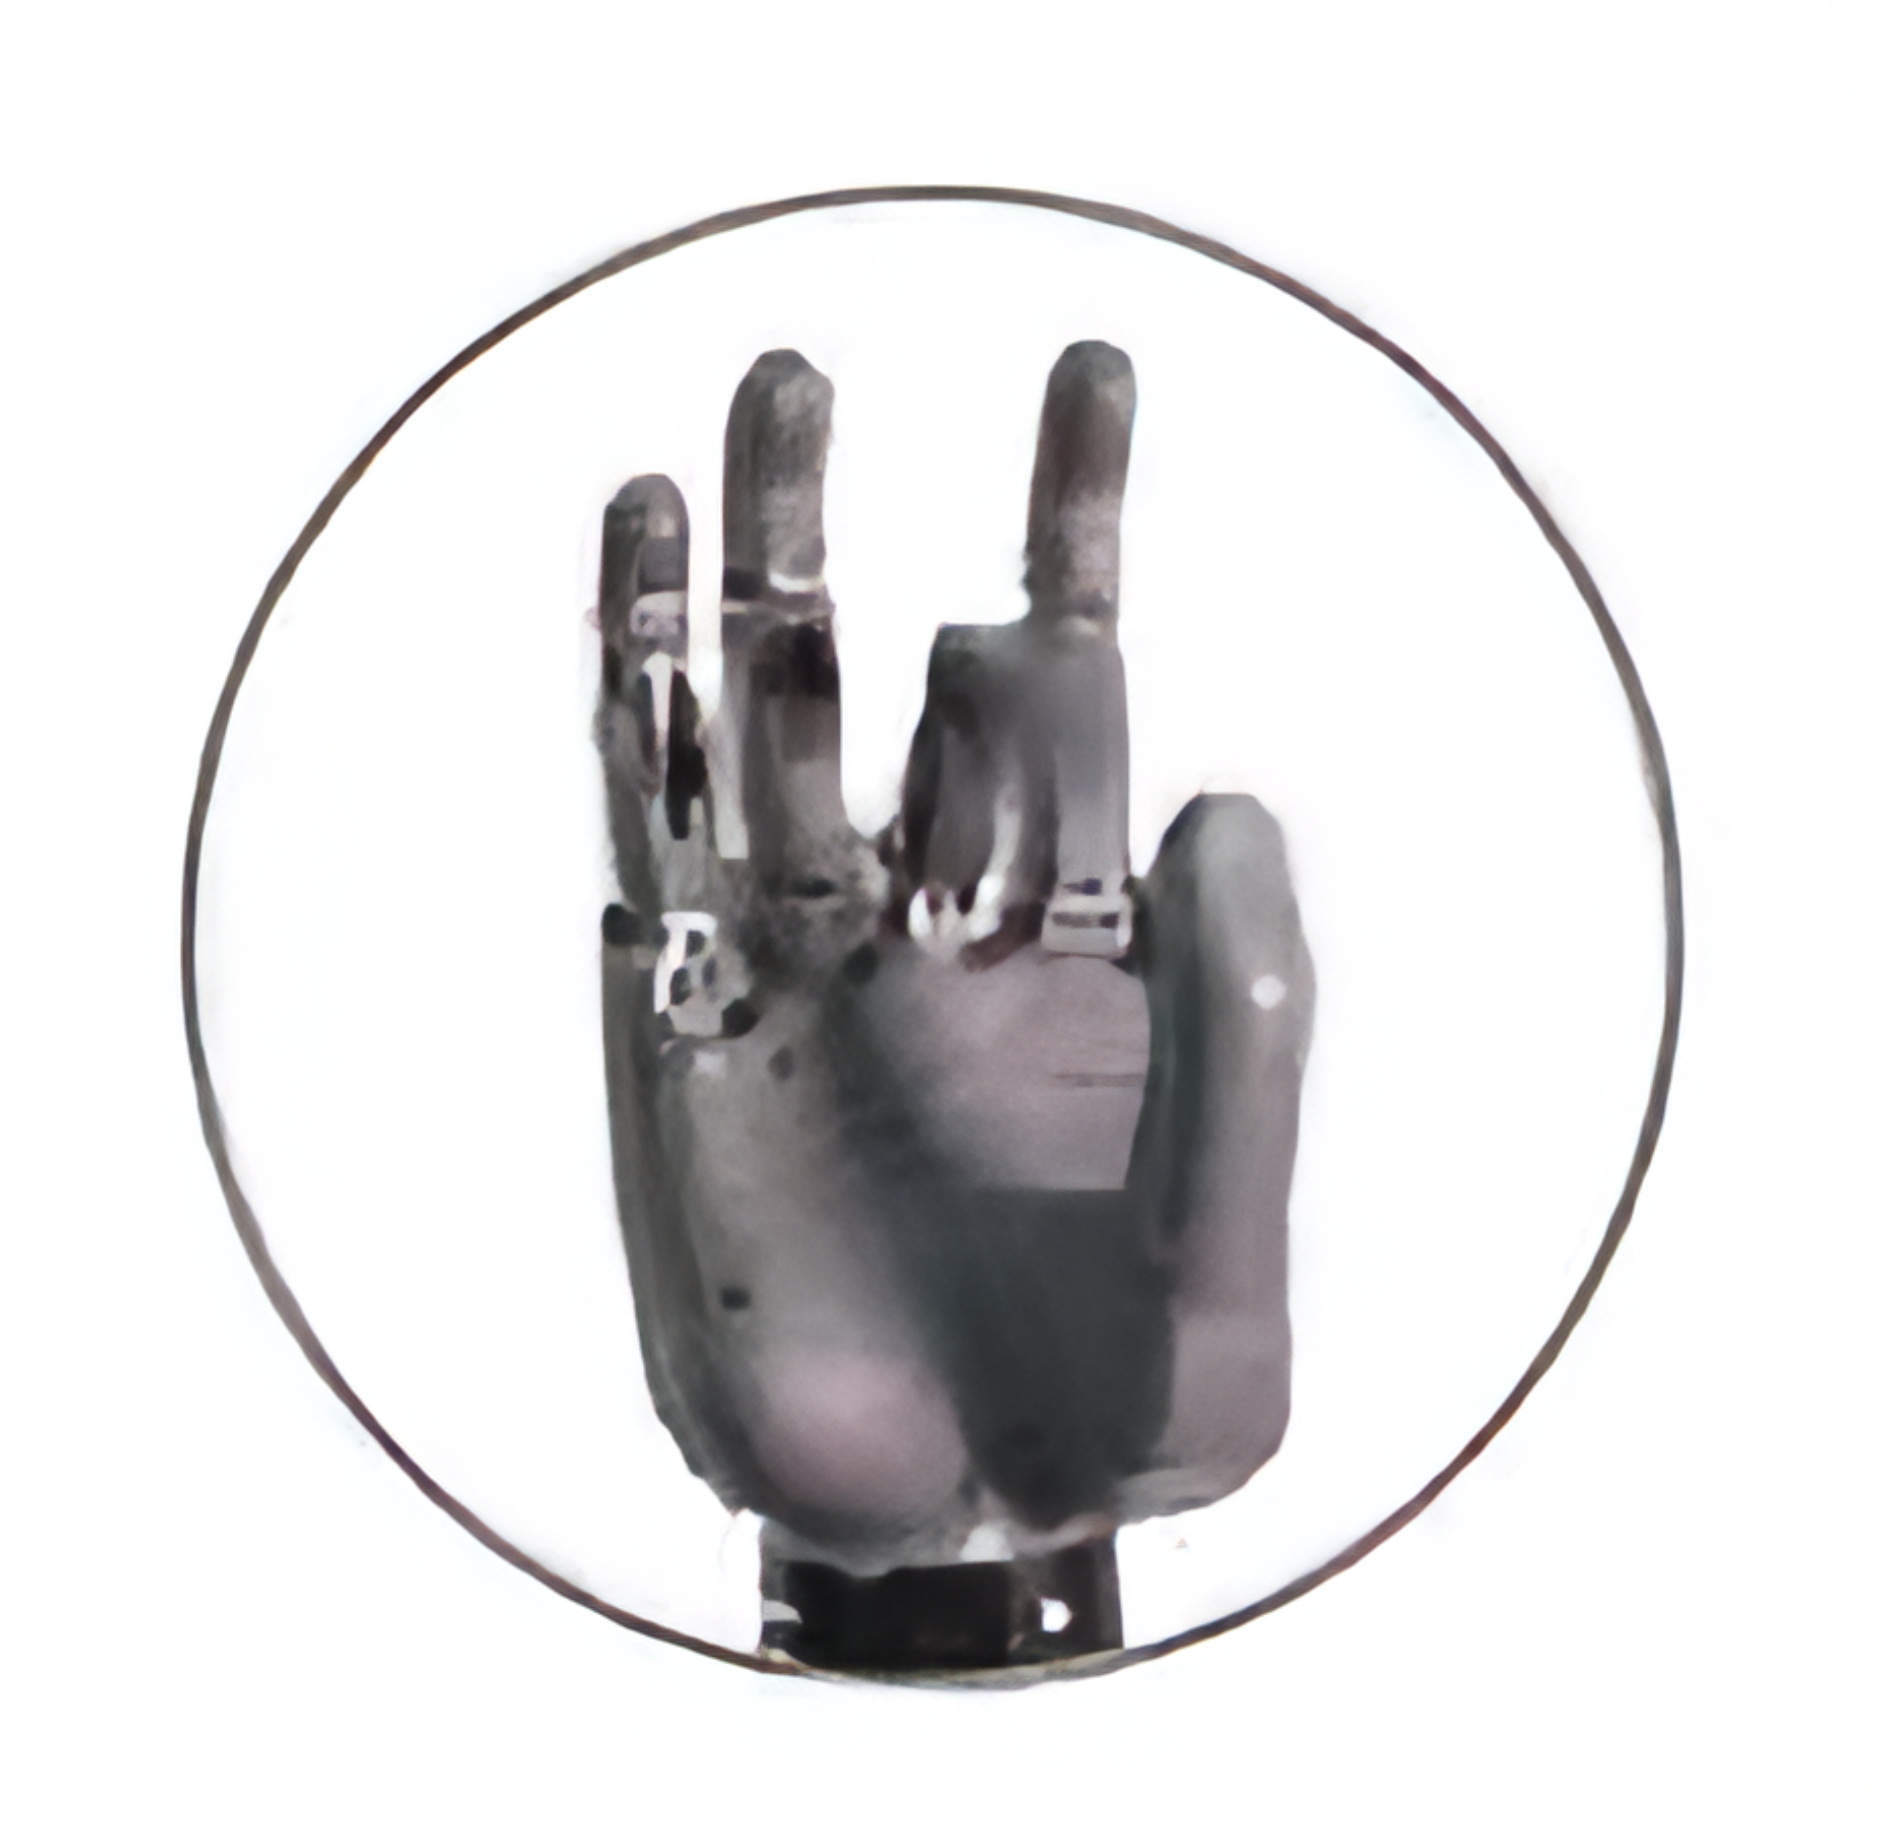 | Middle Finger Flick Uses a motor and torsion spring to flick the middle finger outward. To protect your bionic hand, it is recommended not to use this gesture frequently. |
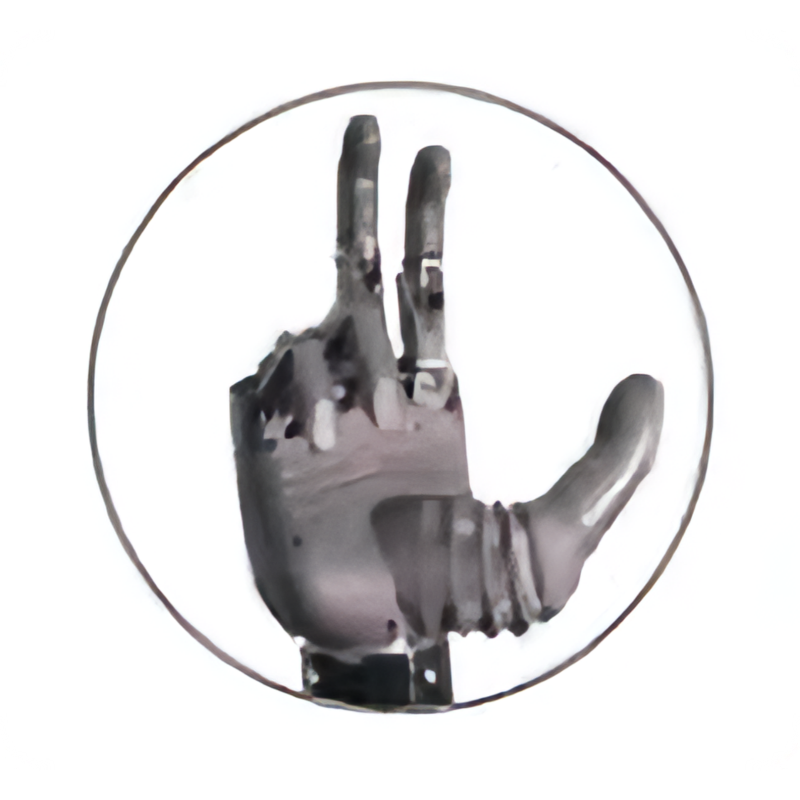
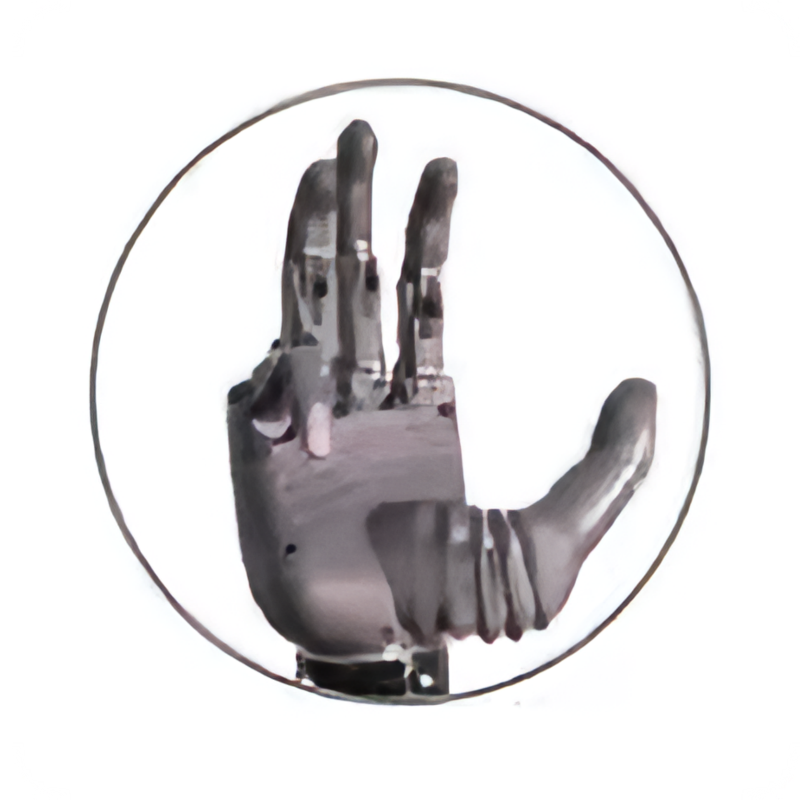 | Four-Finger Grasp (Abducted) Used for holding items such as bowls or large-diameter cylindrical objects, where the object does not come into contact with the palm. To protect your bionic hand, please avoid lifting excessively heavy objects. |
| Mouse-Grip Gesture When this gesture is selected, the bionic hand forms an enclosure around the mouse. |
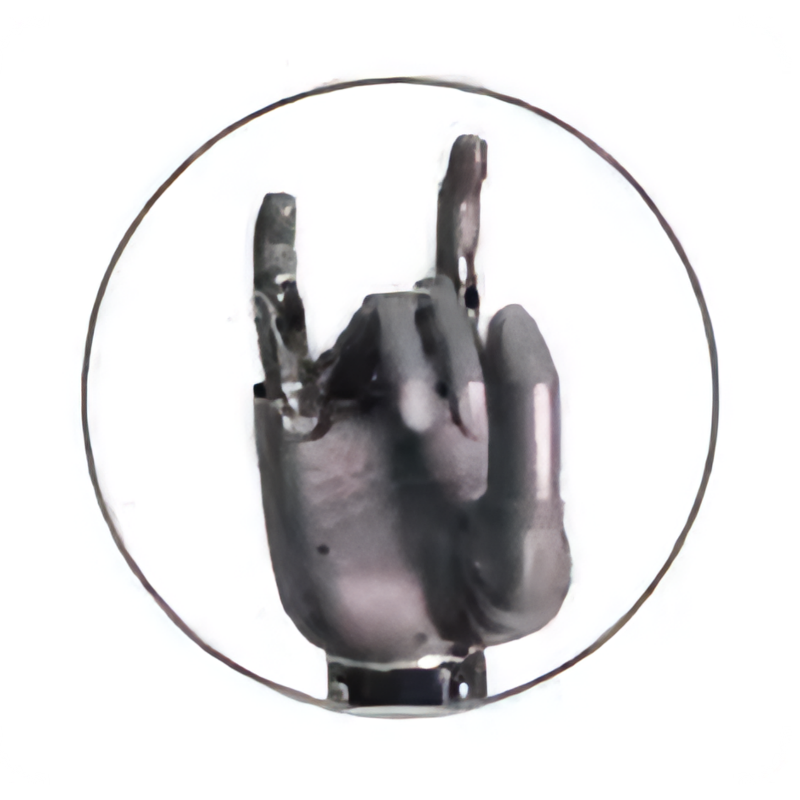 | Bunny Ears Gesture Allows the user to showcase their personality. |
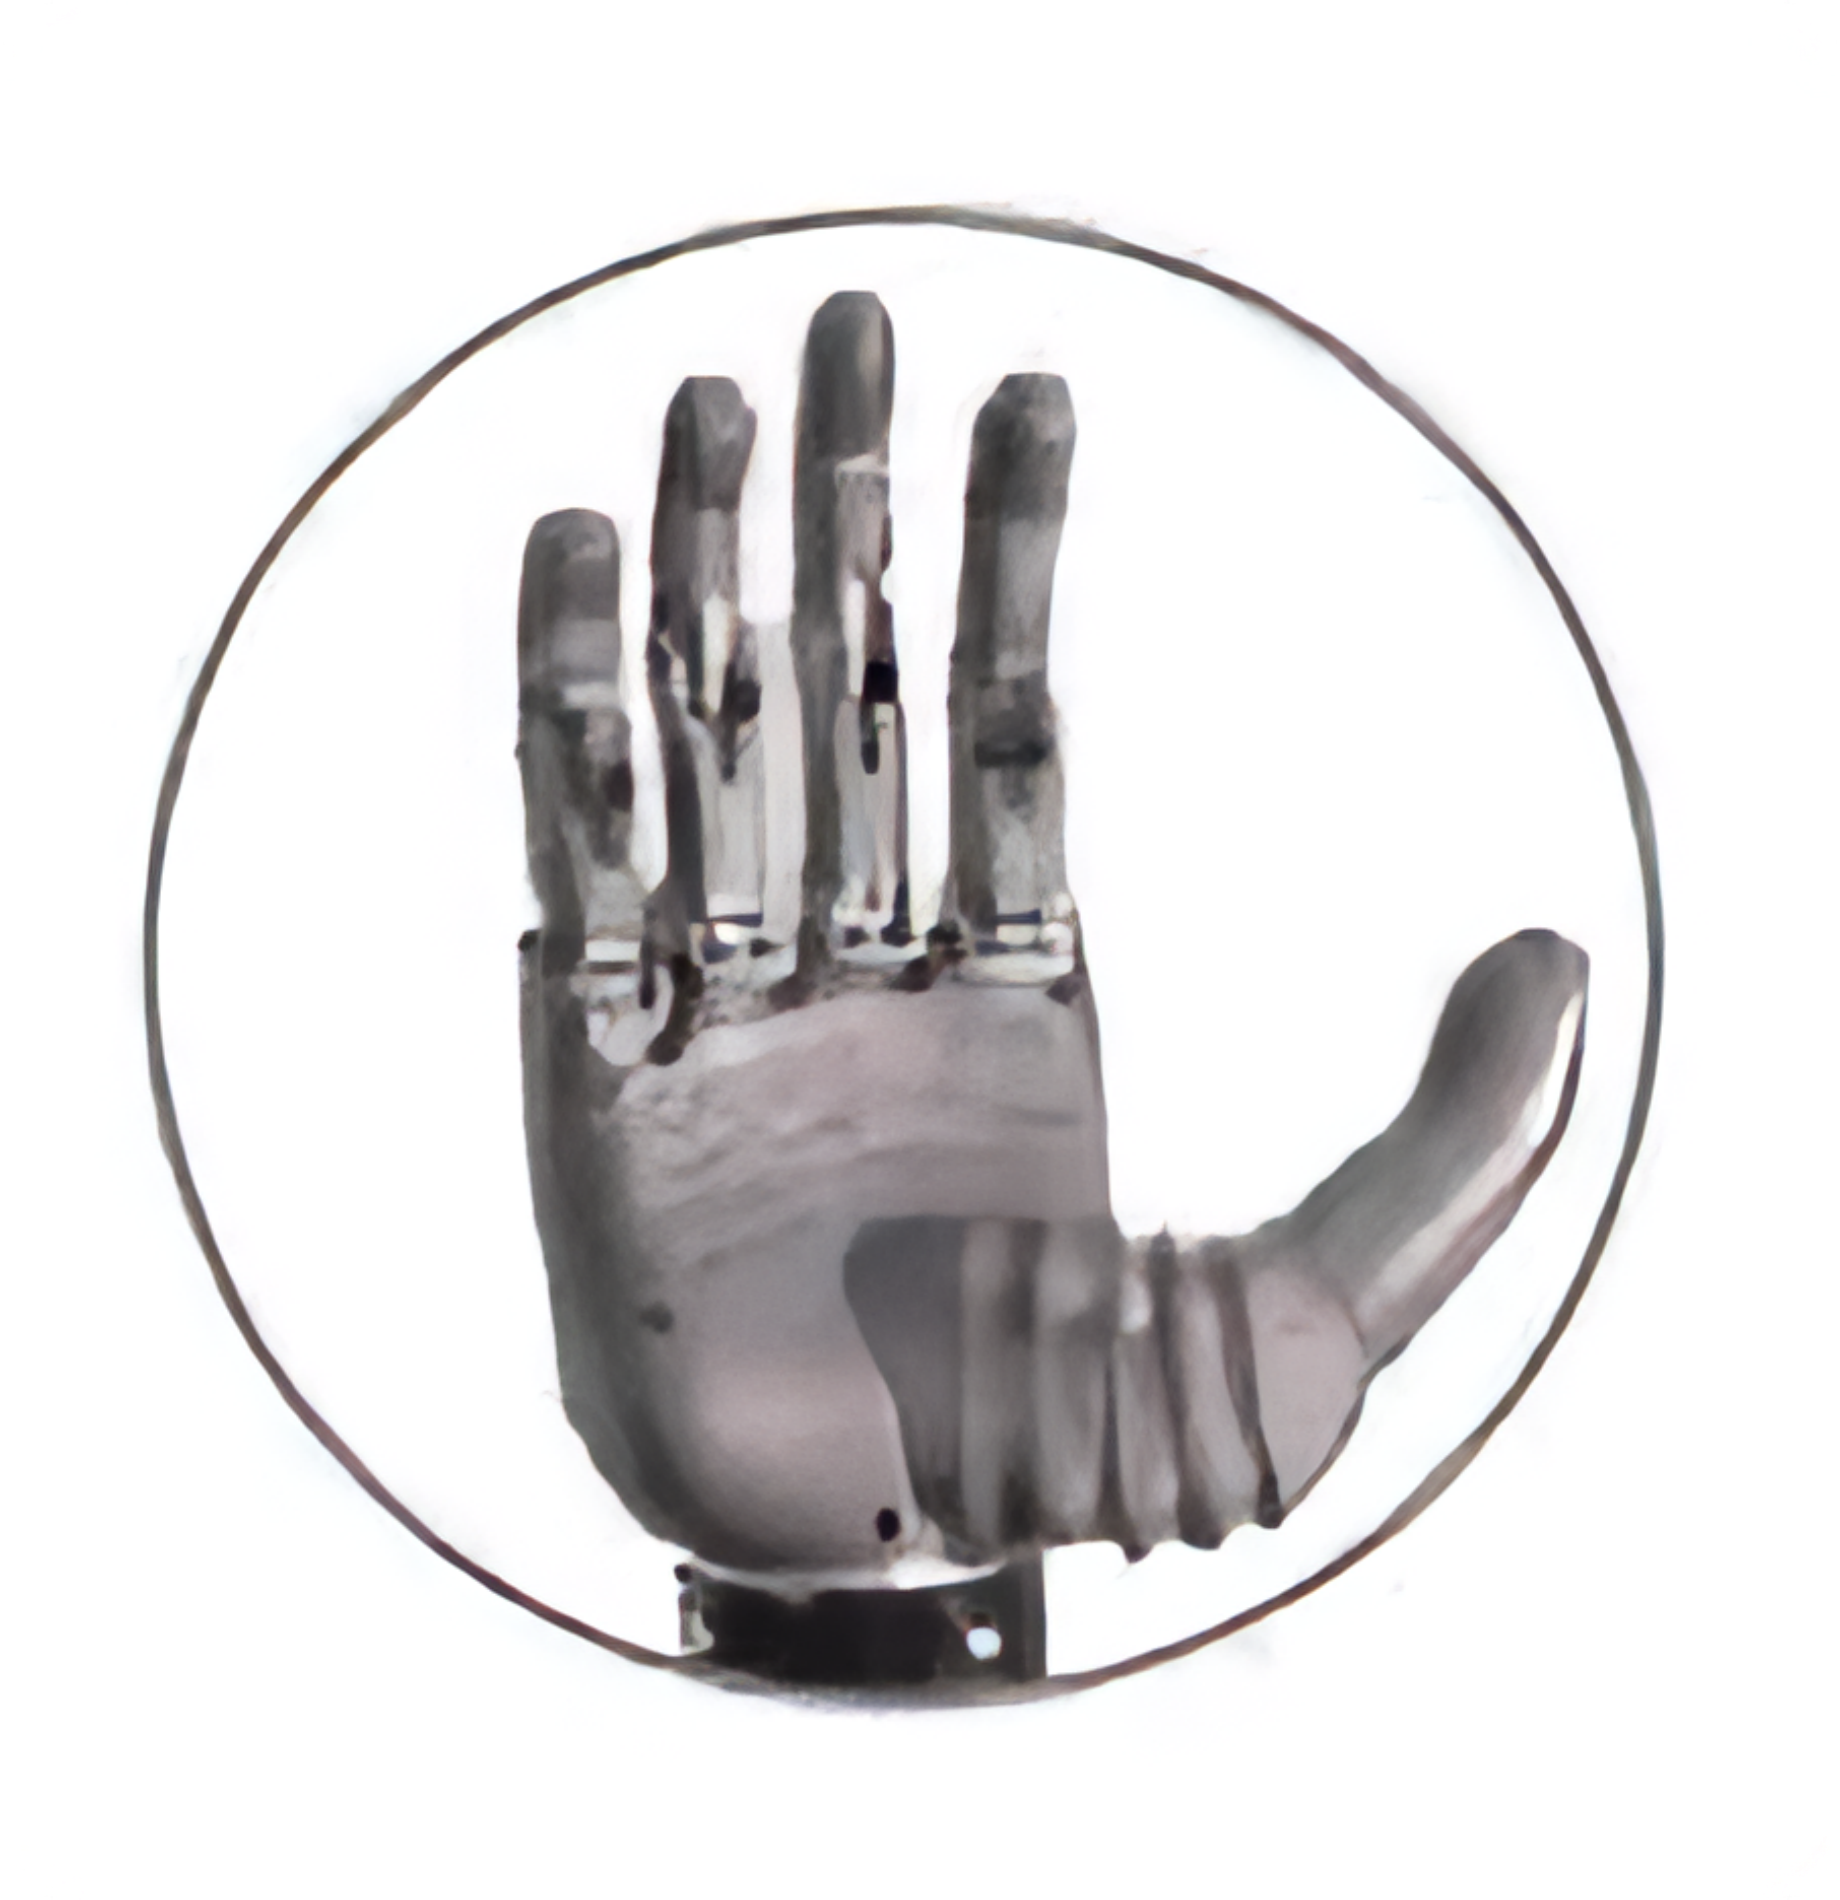 | Five-Finger Open Used to hold objects flat and represent the number 5. To protect your bionic hand, avoid supporting overly heavy objects |
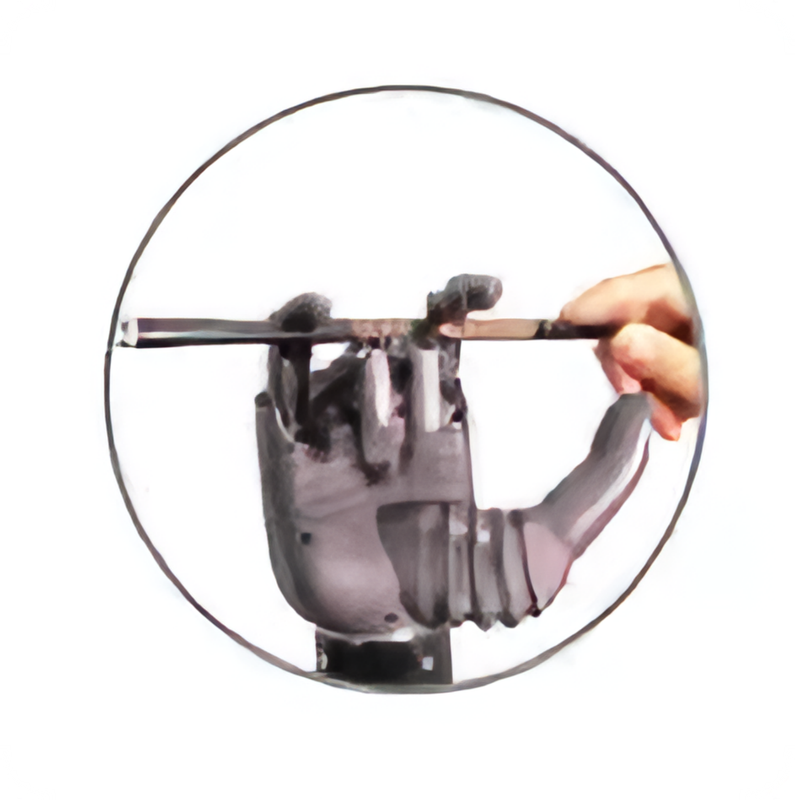 | Pen Clamp 1 Used to hold thin and long objects, such as pens, pencils, and calligraphy brushes, for writing. |
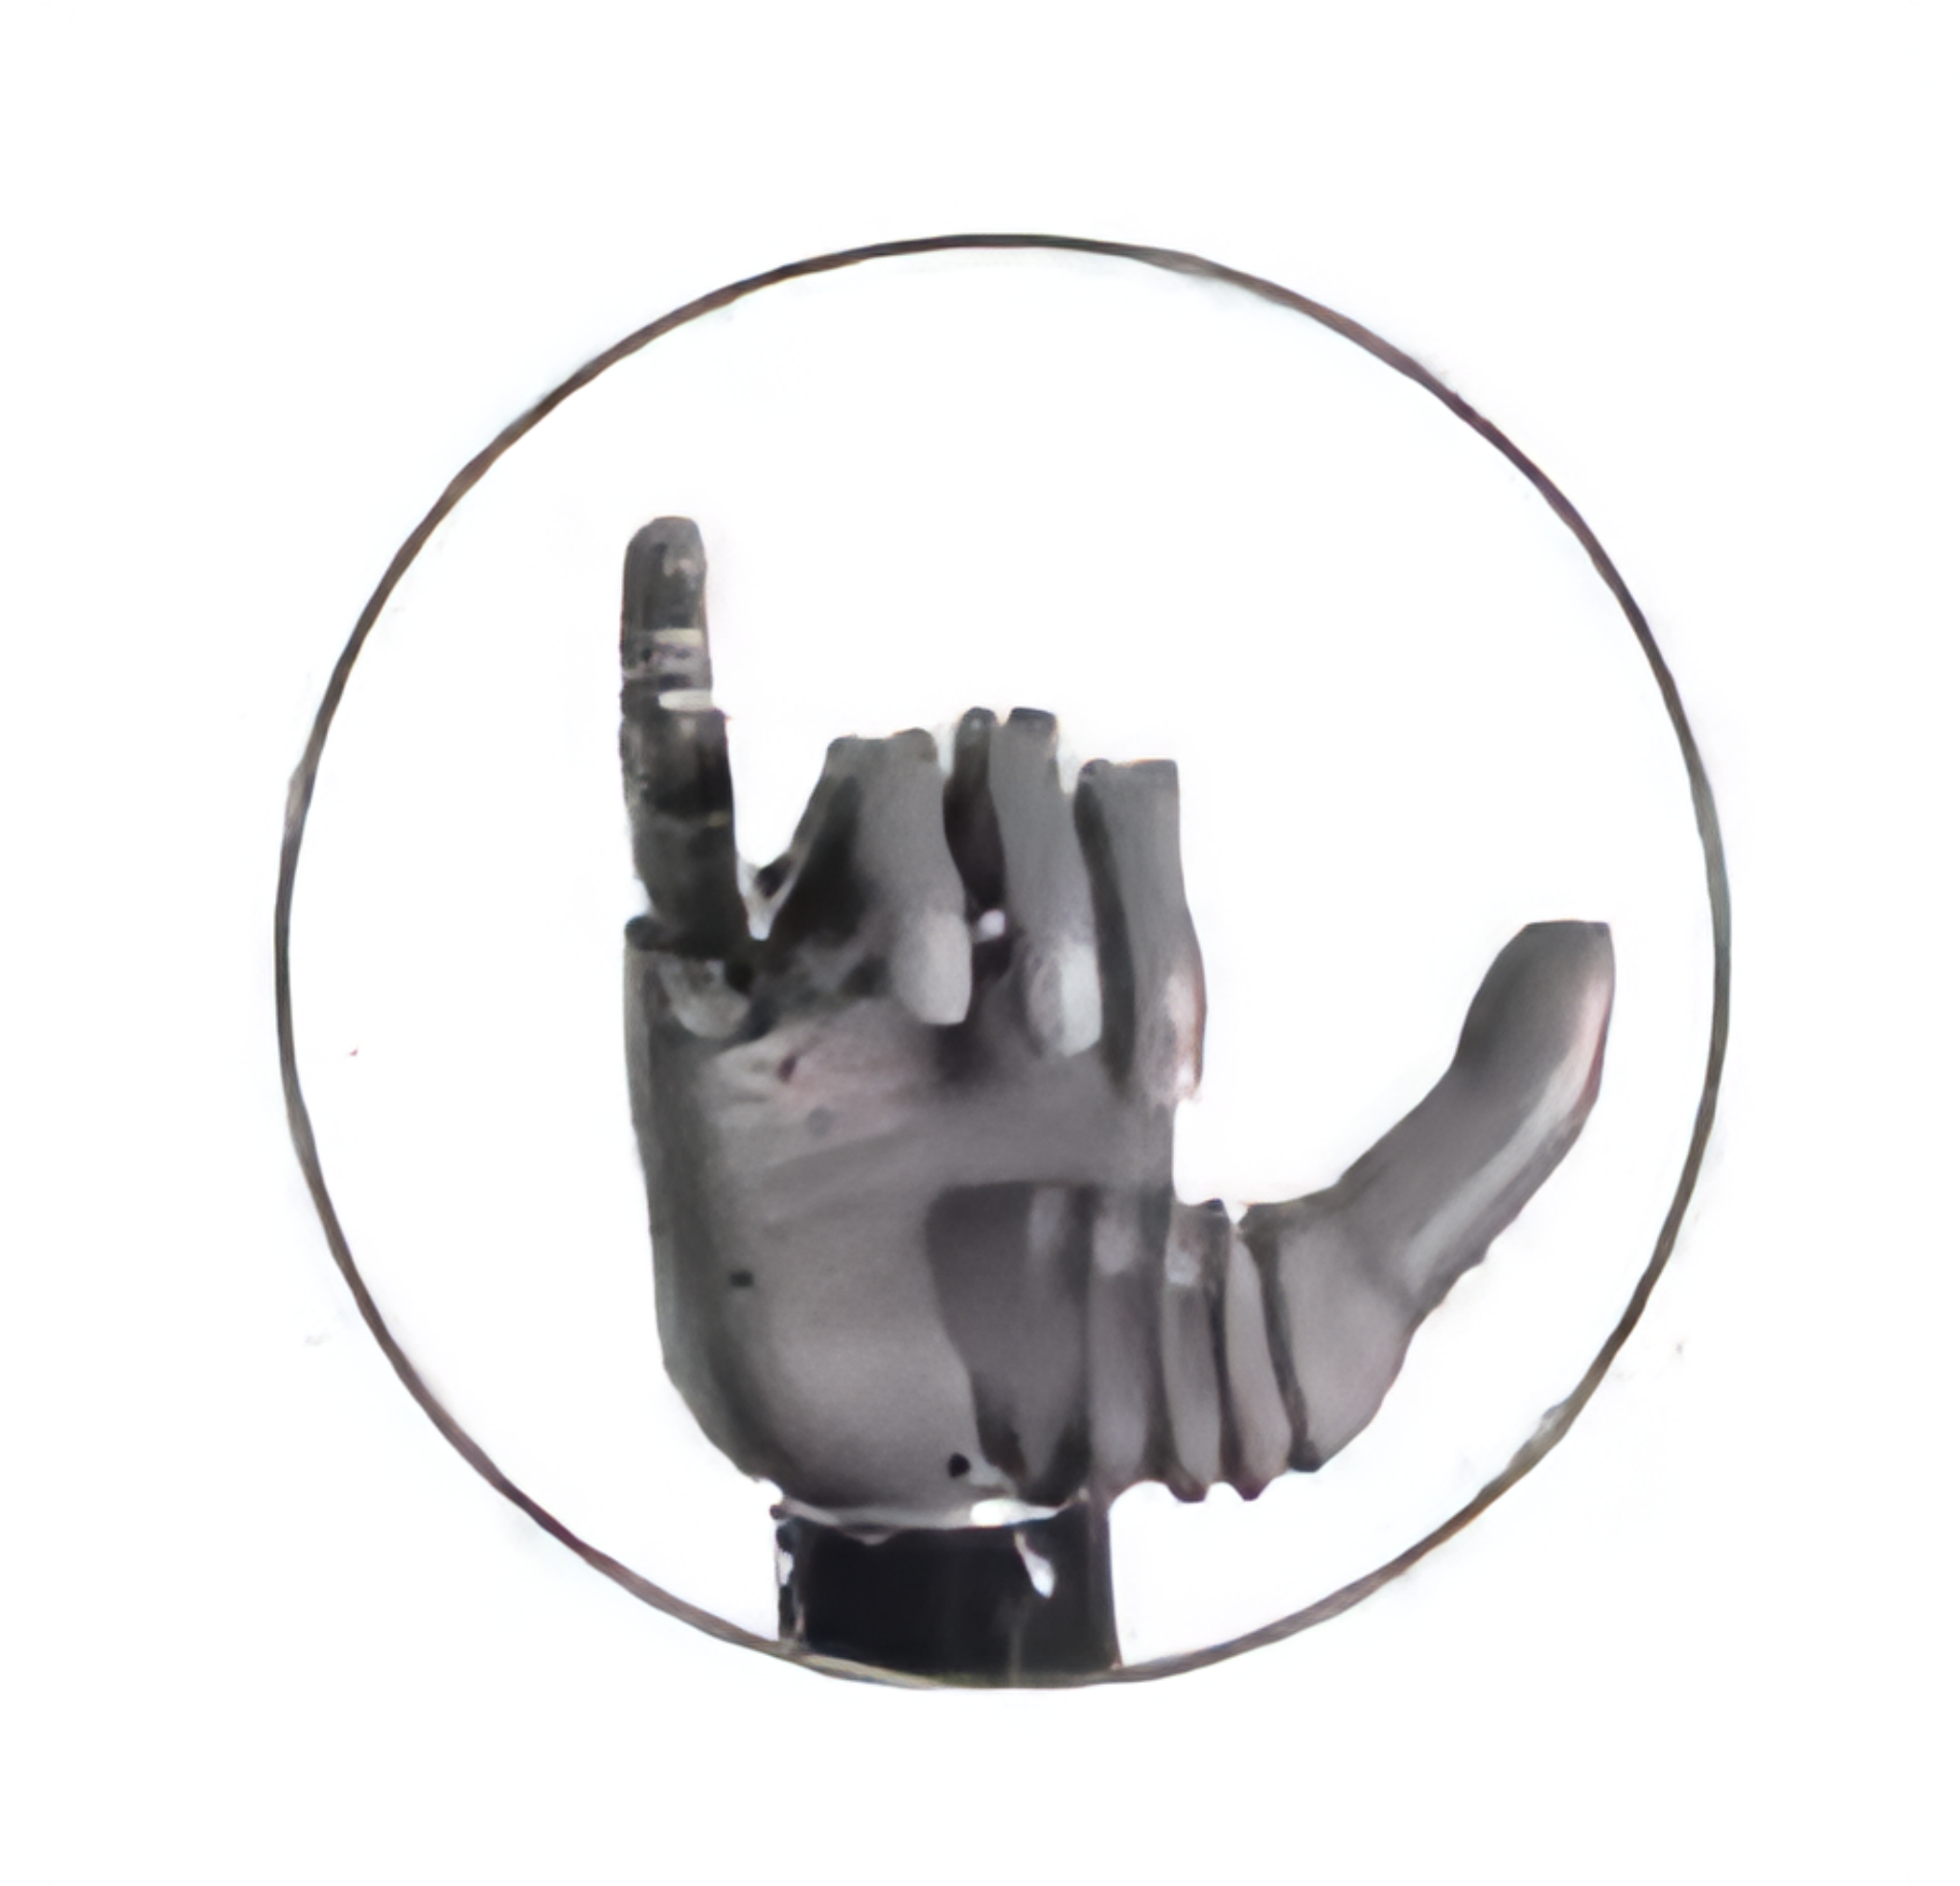 | 666 GestureRepresents the number 6 gesture. |
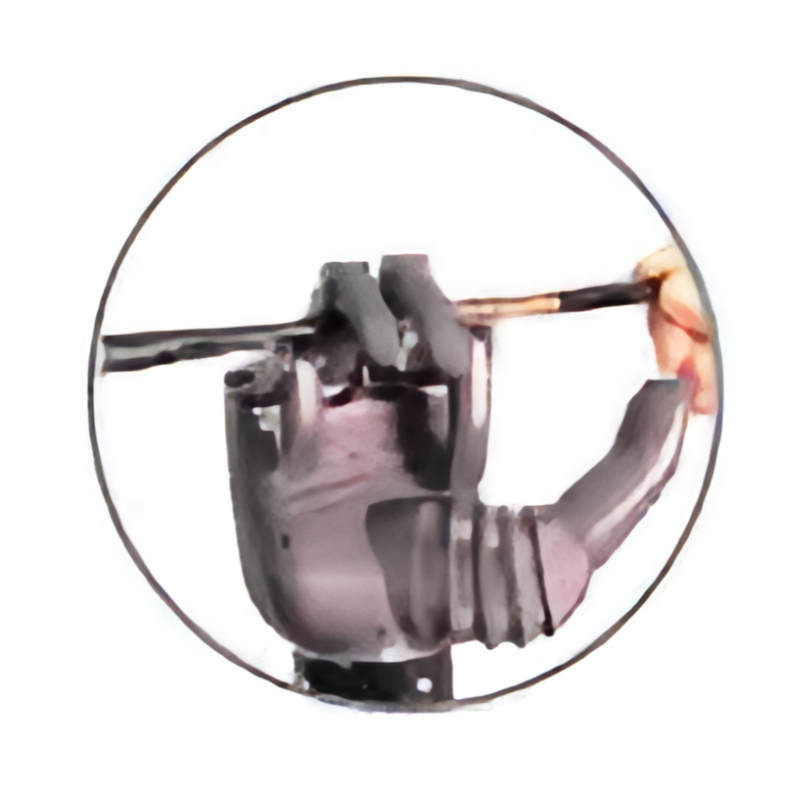 | Pen Clamp 2 Used to hold thin and long objects, such as pens, pencils, and calligraphy brushes, for writing. |
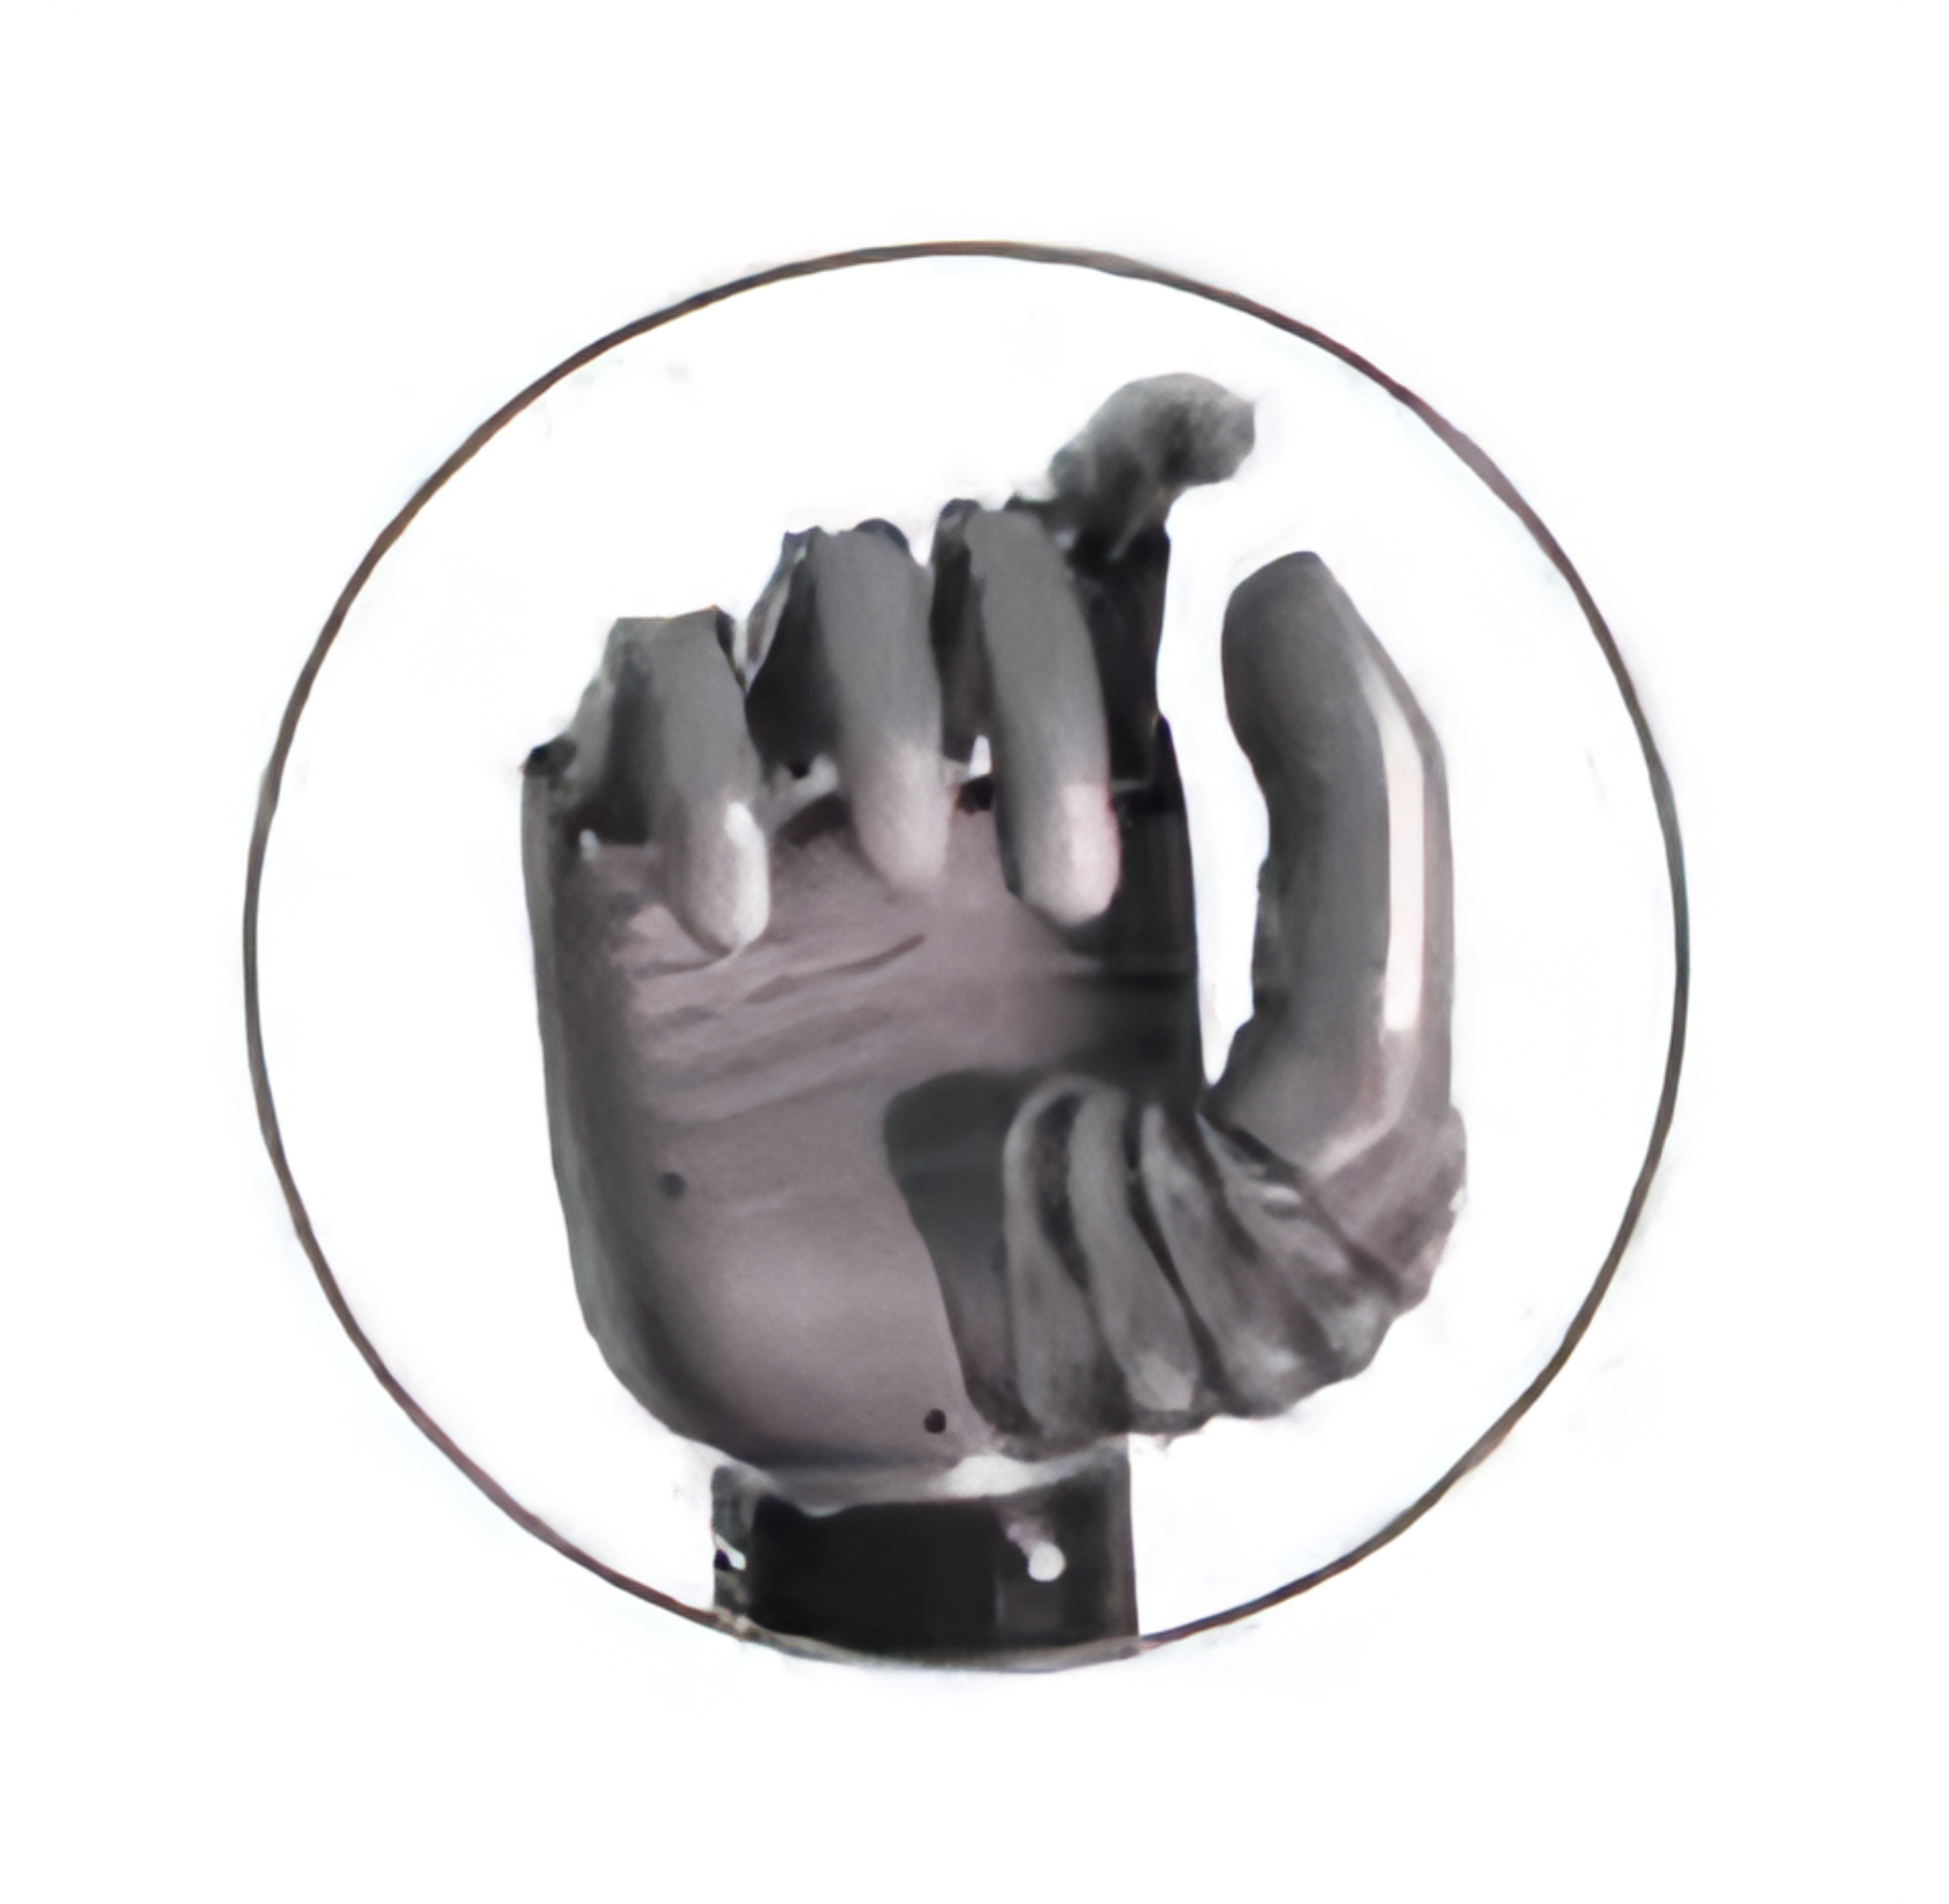 | Hook 9 Used to hook and pull objects, such as pull rings, and represents the number 9. |
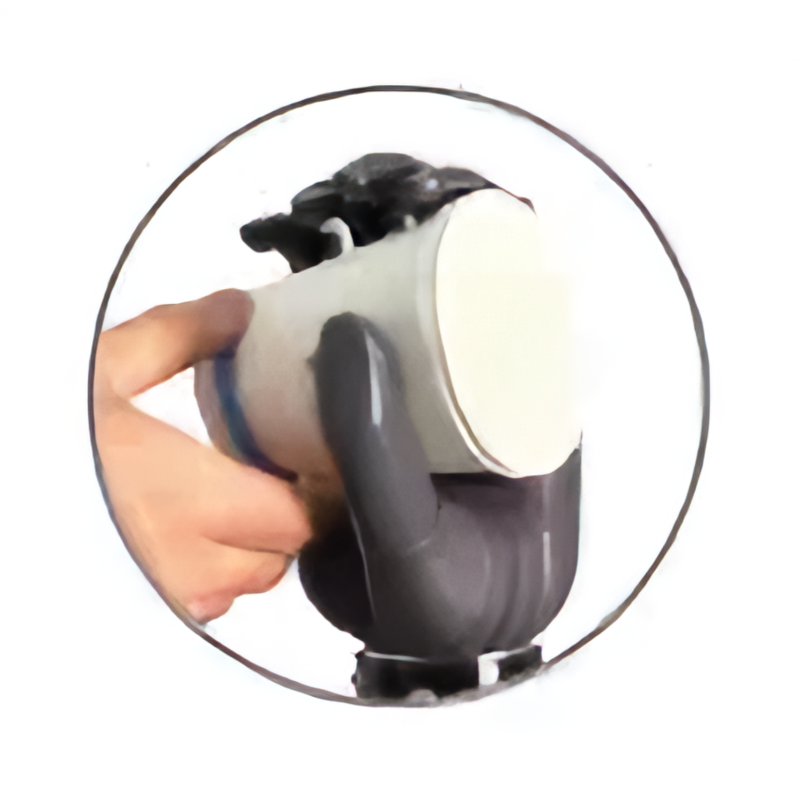 | Five-finger grasp Used for gripping large cylindrical objects or relatively soft items. Prevents excessive deformation upon contact; the palm does not make full contact with the object. |
| Two-finger side-pinch Using the side of the index finger in coordination with the thumb to grasp an object. |
Product parameters
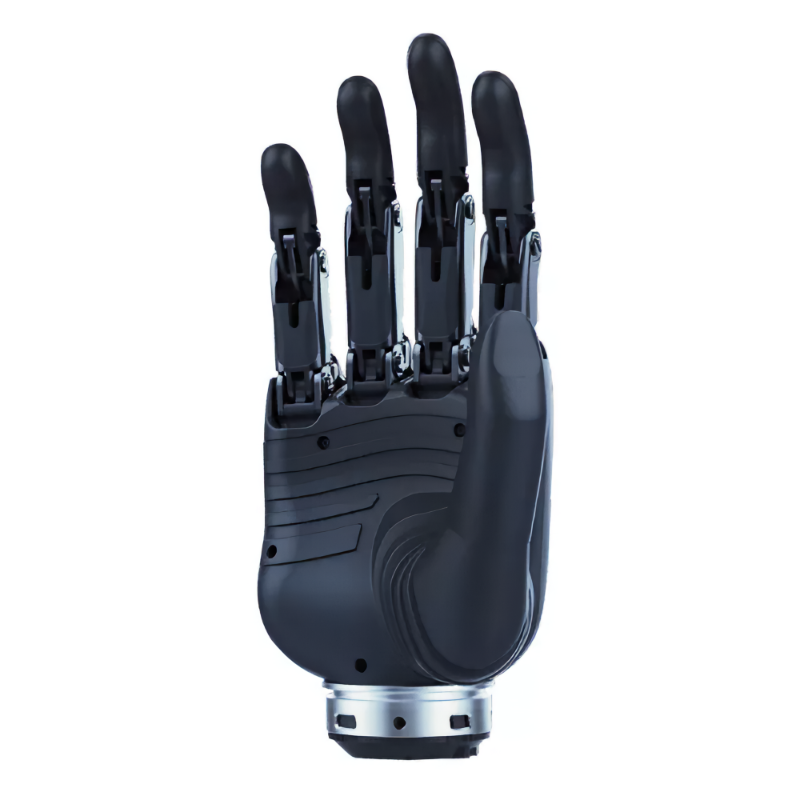
Opening and Closing Speed 0.8 seconds | Socket 3D Modeling | Dexterous Joint10 Degrees of Freedom | Weight in one hand 540 g | Precise Manipulation 0.1 mm |
Real-time sensing of neural and myoelectric signals. | Highly contoured fit for comfort | All 5 fingers can move independently or work in coordination. | Similar to the weight of an adult man’s hand | Capable of picking up items as thin as a tissue or a business card |
Premium Version | Standard Version | |
Control algorithm | Advanced Control Technology for Imagined Limb Movements | Control via Various Gestural Movements |
Operating mode | Basic Mode (Switching between preset gestures) | Basic Mode (switch via preset gestures) |
Smart hardware | Raspberry Pi Compute Module 3+ | None |
Number of electrode channels | 8-channel electrodes | 2-channel electrode |
Applicable conditions | Wrist disarticulation, forearm amputation | Wrist disarticulation, forearm amputation, upper arm amputation |
The list of components for the high-end version of the smart bionic hand is as follows:
Attachment Name | Quantity | Functionality |
Adapter | 1 | Charge the battery via the charging port on the bionic hand’s wrist. |
Power cord | 1 | Connect the bionic hand to a charging adapter; the cable also functions as a data link for recording information. |
Battery | 1 | Power the bionic hand via the socket located at the base of its wrist. |
Battery connecting cable | 1 | Extend the battery cables. |
Battery adapter board | 1 | |
Heat-shrink tubing | 1 | Secure the battery cables to the battery ada |
Mainboard enclosure | 1 | Connect the electrodes to the bionic hand for signal acquisition and computational processing. |
Mainboard connecting cable | 1 | Connect the mainboard housing to the bionic hand/wrist assembly (which is already integrated into the mainboard housing). |
Electrode | 8 | Placed in close contact with the skin to sense the user’s physiological electrical signals |
Electrode connecting cable | 2 | Placed in close contact with the skin to sense the user’s physiological electrical signals |
Electrode screws | 16 | Secure the electrodes to the inner surface of the prosthetic socket |
Switch | 1 | Control the power (on/off) of the bionic hand |
Switch connecting cable | 1 | Connect the power switch to the bionic hand |
Switch screws and washers | 2 | Secure the power switch |
Hex key (Allen wrench) | 1 | Assemble the bionic hand and its accessories |
Wrist screws | 4 | Securely attach the socket to the bionic hand |
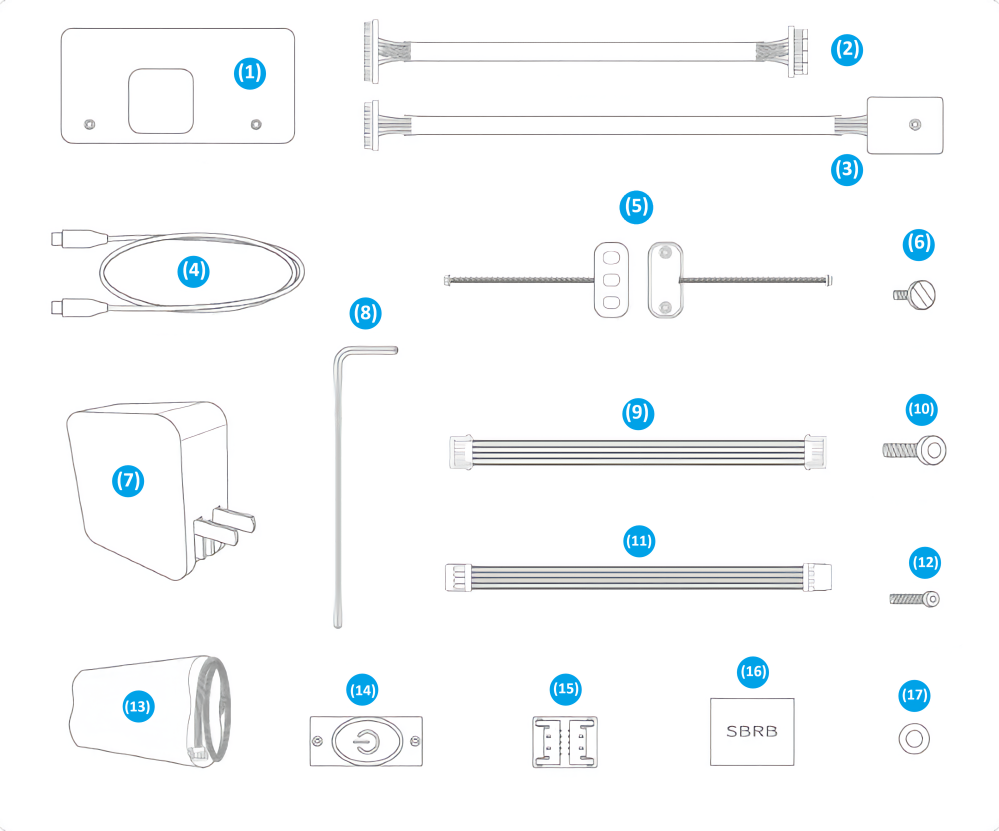
1. Motherboard box *1
2. Motherboard connecting cable *1
3. Electrode adapter cable *2
4. Power cable *1
5. Electrode *8
6. Electrode screw *16
7. Adapter *1
8. Allen wrench (Hex key) *1
9. Battery connecting cable *1
10. Wrist screw *4
11. Switch connecting cable *1
12. Switch screw *2
13. Battery *1
14. Switch *1
15. Battery adapter board *1
16. Heat shrink tubing *1
17. Metal washer *2
The list of accessories for the standard version of the smart bionic hand is as follows:
Accessory Name | Quantity | Function |
Power Adapter | 1 | Charges the battery via the charging port on the bionic hand wrist |
Power Cable | 1 | Connects the bionic hand to the adapter, and can also serve as a data cable for data logging |
Battery | 1 | Supplies power to the bionic hand via the socket at the base of the wrist |
Battery Connecting Cable | 1 | Extends the battery wire |
Battery Adapter Board | 1 | |
Heat Shrink Tubing | 1 | Fixes/secures the battery wire and adapter board |
Electrode Adapter Board | 1 | Connects the electrode to the bionic hand |
Electrode Connecting Cable | 1 | Connects the electrode adapter board to the bionic hand wrist |
Electrode | 2 | Attaches closely to the skin to sense the user's bioelectric signals |
Electrode Screw | 4 | Fixes the electrode inside the socket / inner cavity |
Switch | 1 | Controls the power on/off of the bionic hand |
Switch Connecting Cable | 1 | Connects the power switch to the bionic hand |
Switch Screw & Washer | 2 | Fixes/secures the power switch |
Allen Wrench (Hex Key) | 1 | Used for assembling the bionic hand and accessories |
Wrist Screw | 4 | Fixes and connects the socket / prosthetic socket to the bionic hand |
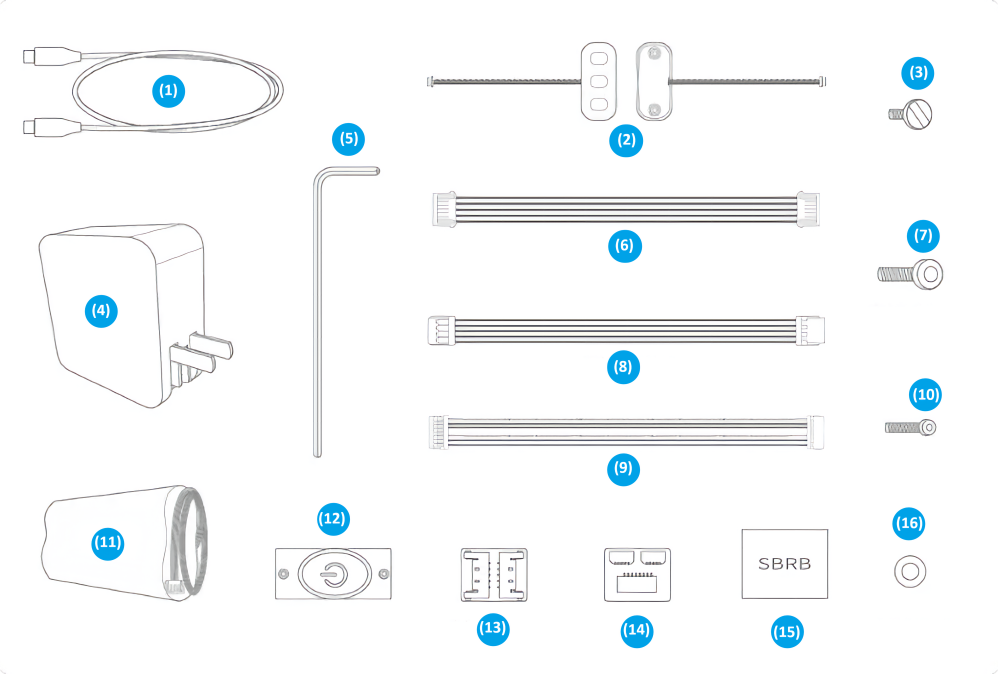
1. Power cable *1
2. Electrode *2
3. Electrode screw *4
4. Adapter *1
5. Allen wrench (Hex key) *1
6.Battery connecting cable *1
7. Wrist screw *4
8. Switch connecting cable *1
9. Electrode connecting cable *1
10. Switch screw *2
11. Battery *1
12. Switch *1
13. Battery adapter board *1
14. Electrode adapter board *1
15. Heat shrink tubing *1
16. Metal washer *2