

Product Description
Mini Pupper2: Open Source, ROS, OpenCV
An open-source robot platform supporting LLM, ROS2 and OpenCV.
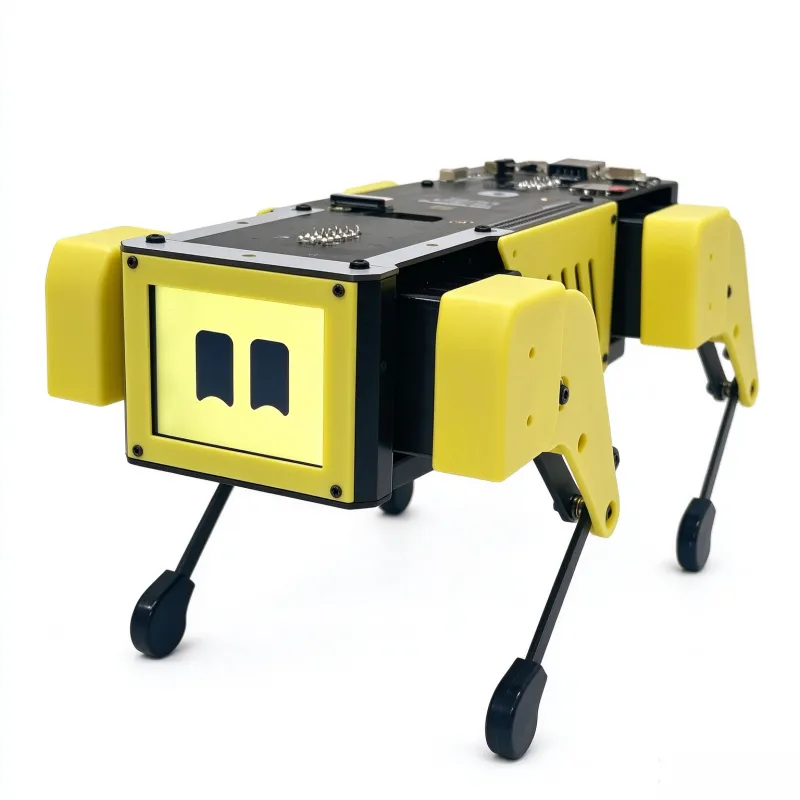
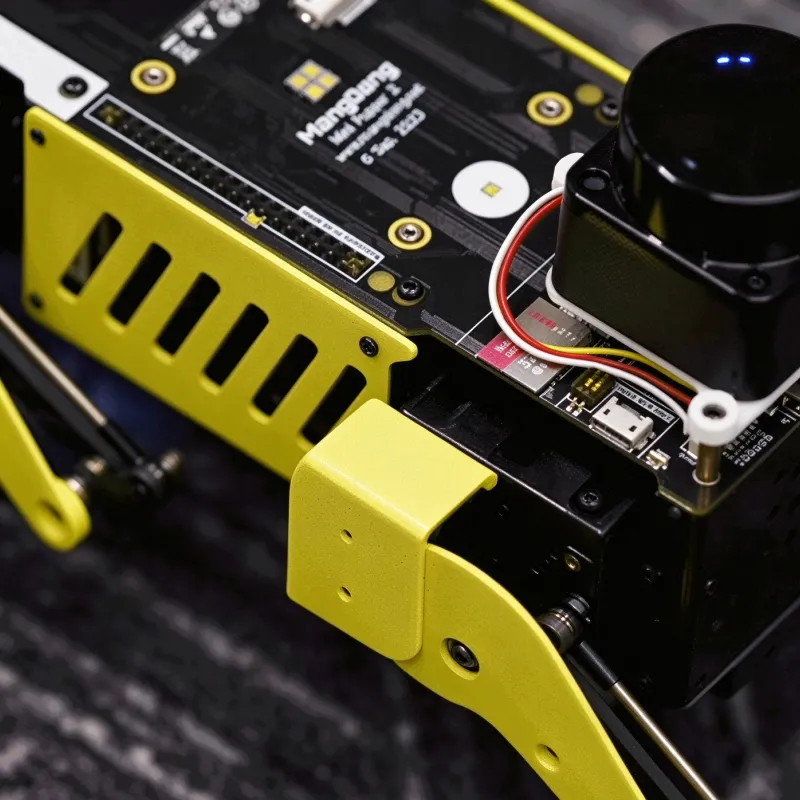
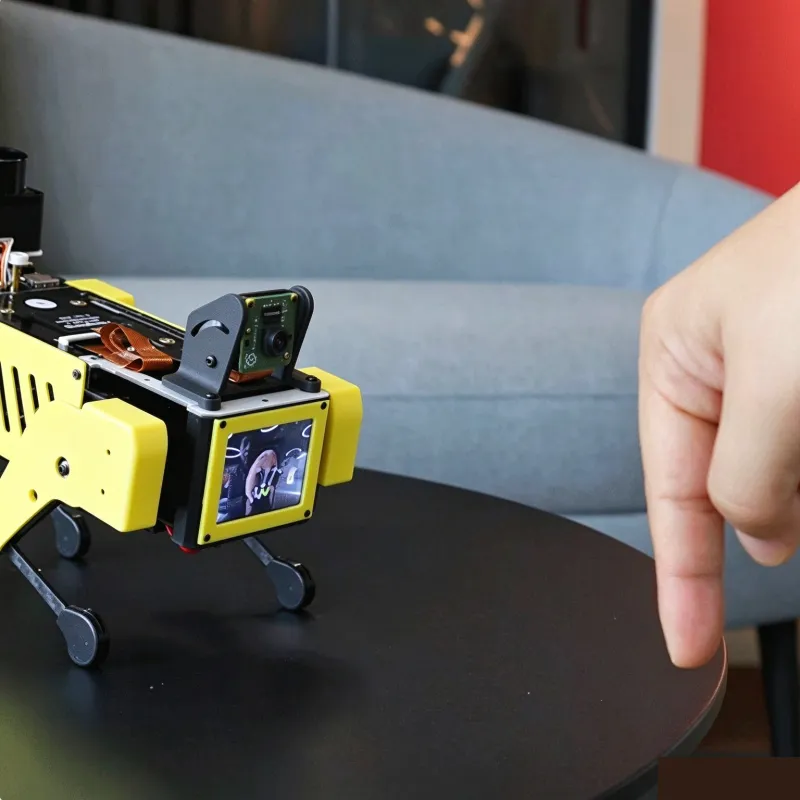
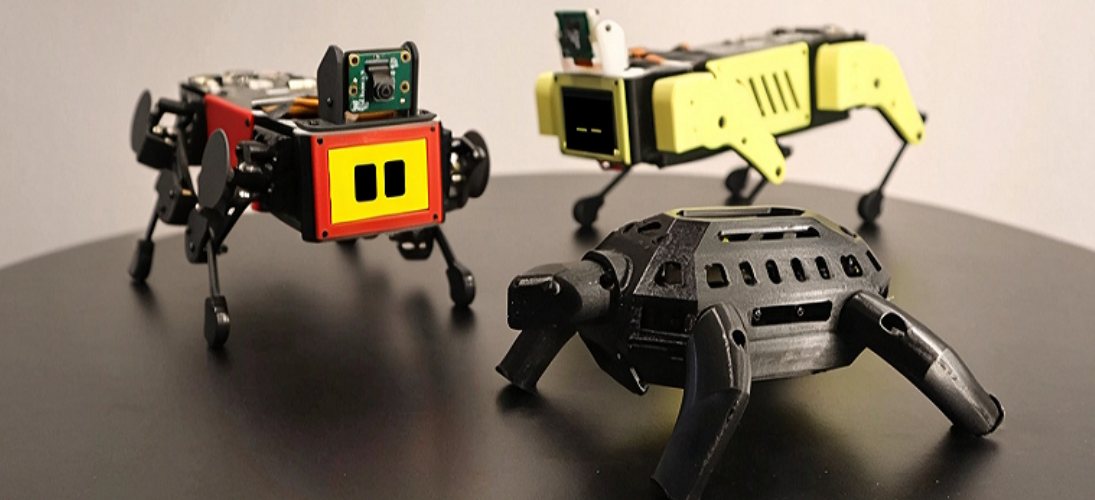
Mini Pupper 2 is an upgraded version of the first generation. Derived from the open-source Stanford Pupper project, it is a compact quadruped robot capable of running, jumping and walking around.
Its simple design enables K12 and older robot enthusiasts to DIY a fun, movable quadruped robot by themselves.
Since its launch in 2021, Mini Pupper has joined hands with well-known global organizations and companies including Ubuntu, ROS, OpenCV, IEEE, Google and Amazon to host many offline events, winning popularity among users worldwide.
Mini Pupper 2 is equipped with a camera, microphone and speaker, making it easy to learn LLM AI quickly.
MangDang’s mission is to bring robots into every ordinary family around the world and make life better for everyone!
Functional Features
Intelligent "Hack Mode" Design
Users can adjust and extend the robot's behaviors according to their needs.
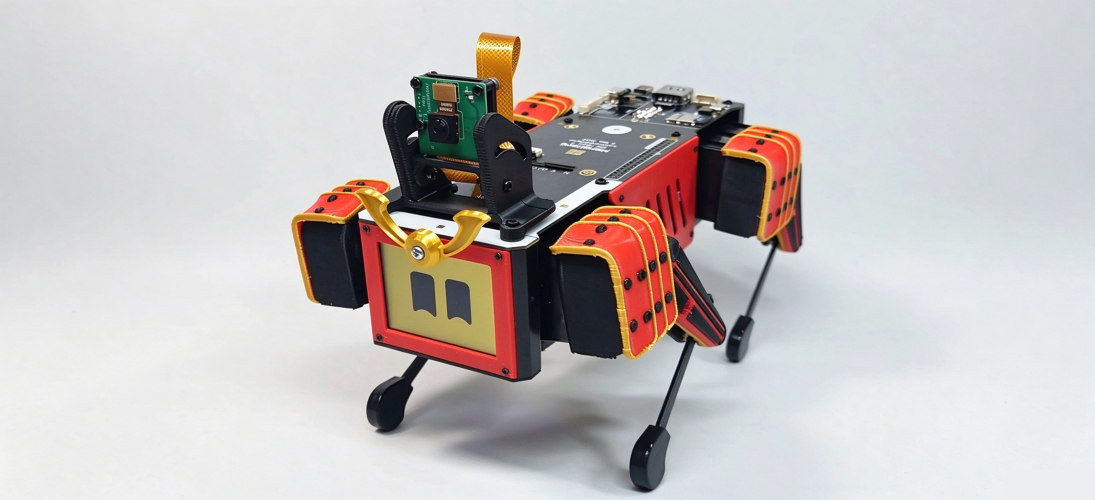
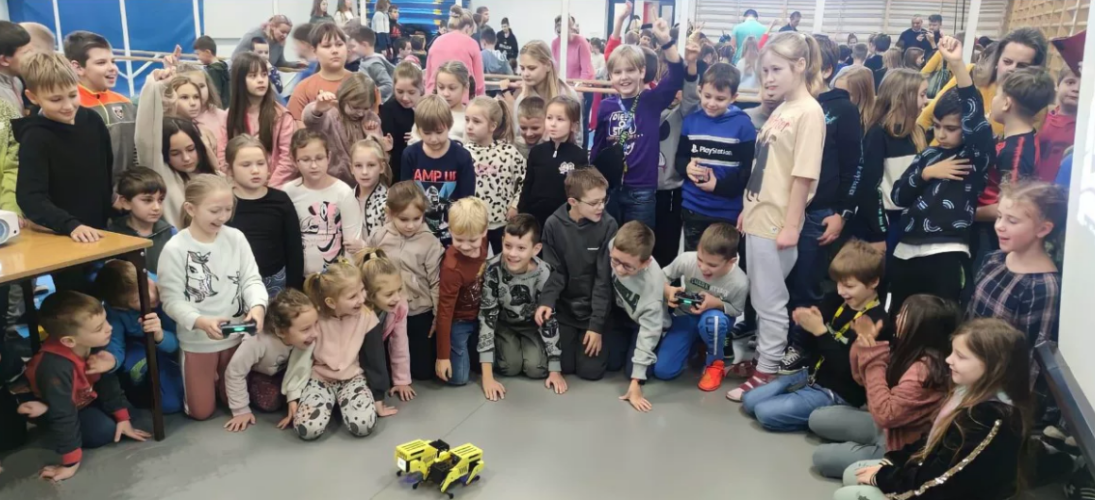
Mini Pupper is also a great helper for kids to learn robotics.
Open Source for Unlimited Creation
Easily research various large language models with the samples we provide.
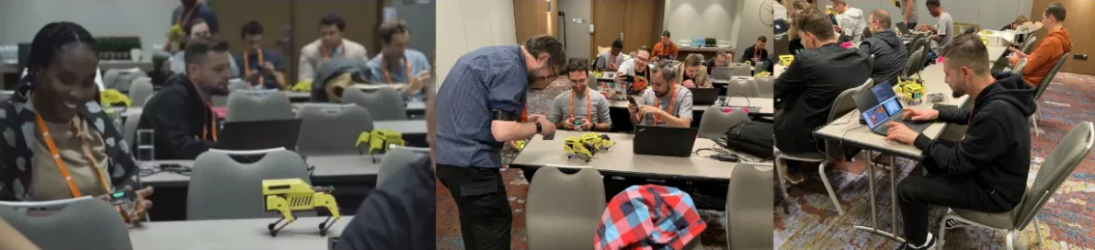
Mini Pupper Workshop Shines at Ubuntu Summit 2022
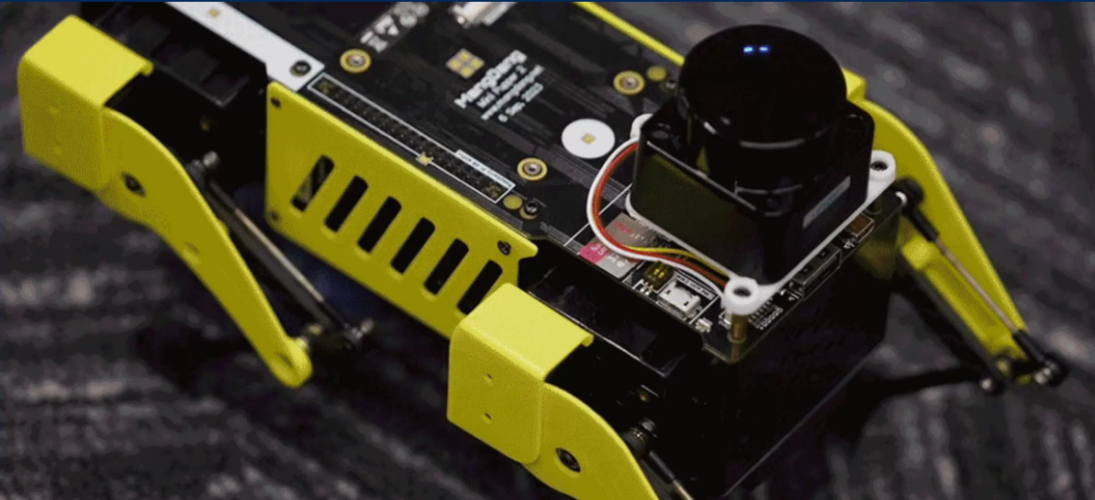
ROS SLAM & Navigation
Compatible with both ROS1 and the latest ROS2 Humble
Mini Pupper Workshop at ROS Developers Conference 2022 Hosted by MangDang, we invited AWS, Luxonis and Japanese Makers to join us. Thanks for the strong support from the official ROS team!
Product Display
OpenCV Visual Artificial Intelligence
Unleash multiple potentials of AI
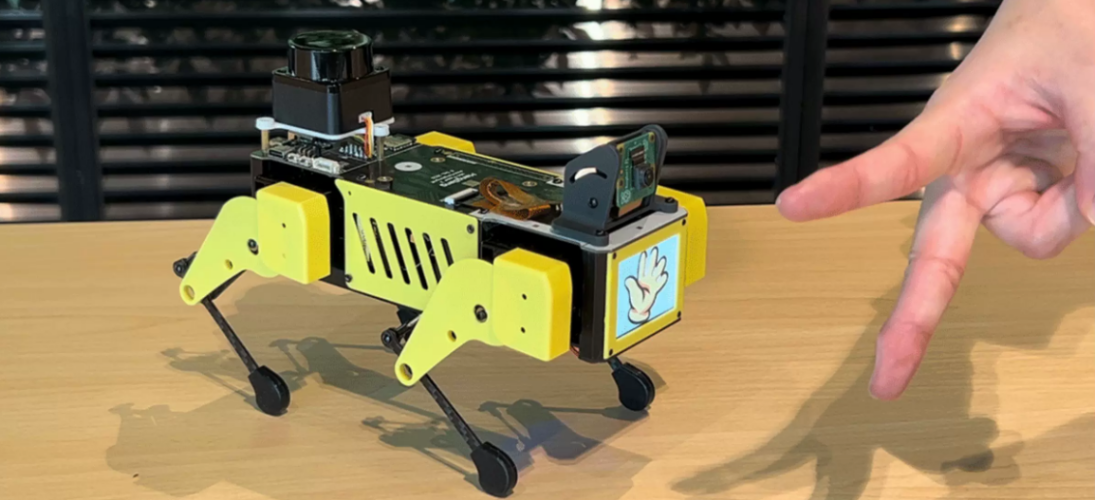
Unleash multiple potentials of AI
Discussed OpenCV AI features based on Mini Pupper with Satya, CEO of OpenCV.
Sim-to-Real
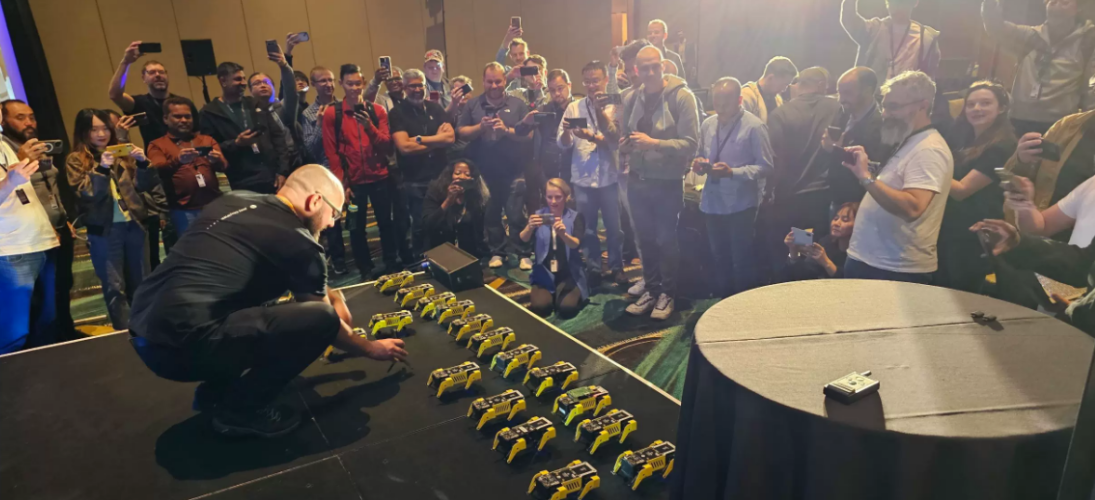
AWS cloud service supported for easier learning……
At AWS re:MARS and re:Invent 2022, many enthusiasts enjoyed the fun of Sim-to-Real via Mini Pupper Workshop.
Application
Diverse Gameplays Waiting to Be Unlocked
Each leg is driven by 3 servos, with 12 degrees of freedom in total to realize various postures and movements.
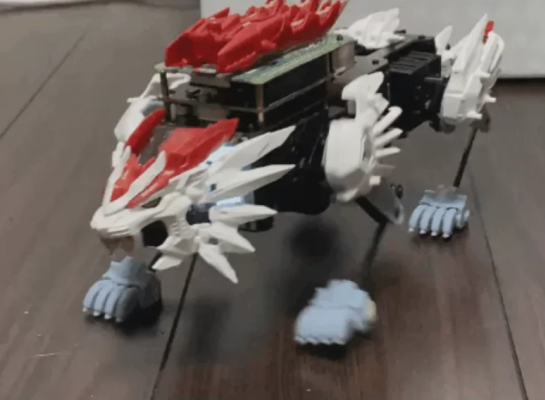
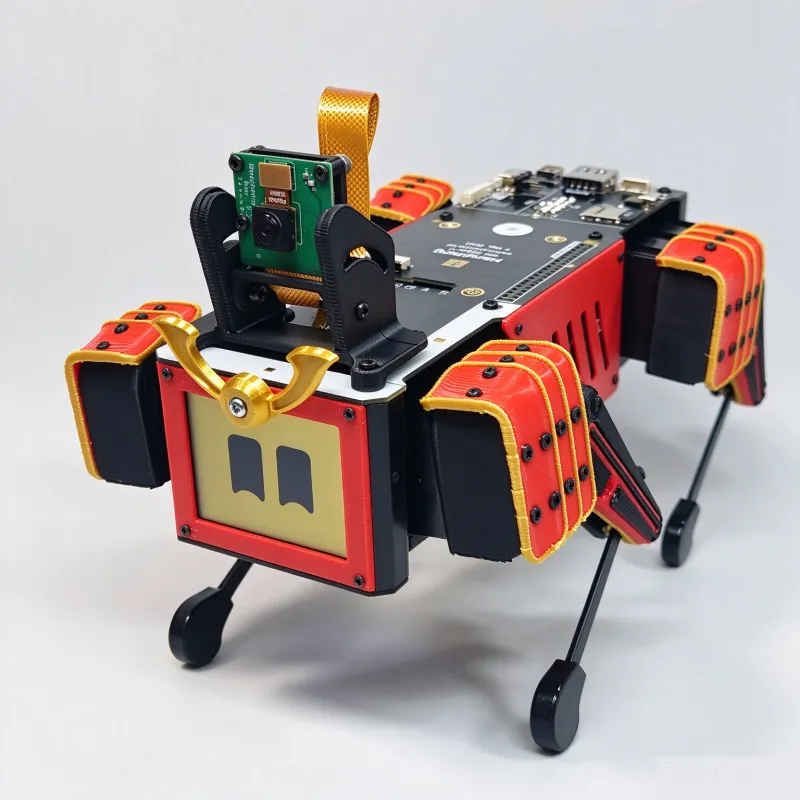
Change Its Shell by Itself
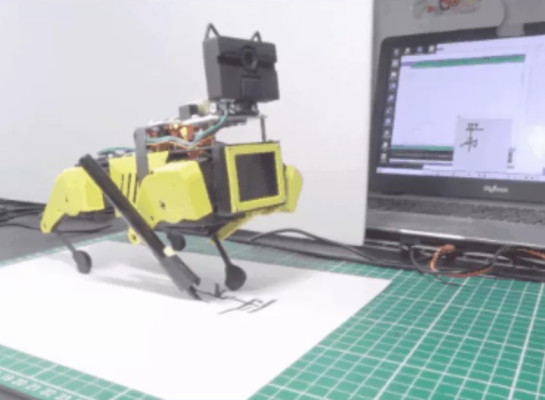
Learning to Write
Product parameters
Parameter | Value |
Dimensions | 209x109x145mm |
Weight | 465g |
Payload | 200g |
CPU | Raspberry Pi CM4 |
Servo | Serial Bus Servo with position feedback |
Mic/Speaker | Yes |
I/O interfaces | USB2 x1 / HDMI output x1 |
MCU | ESP32-S3 |
IMU | Yes |
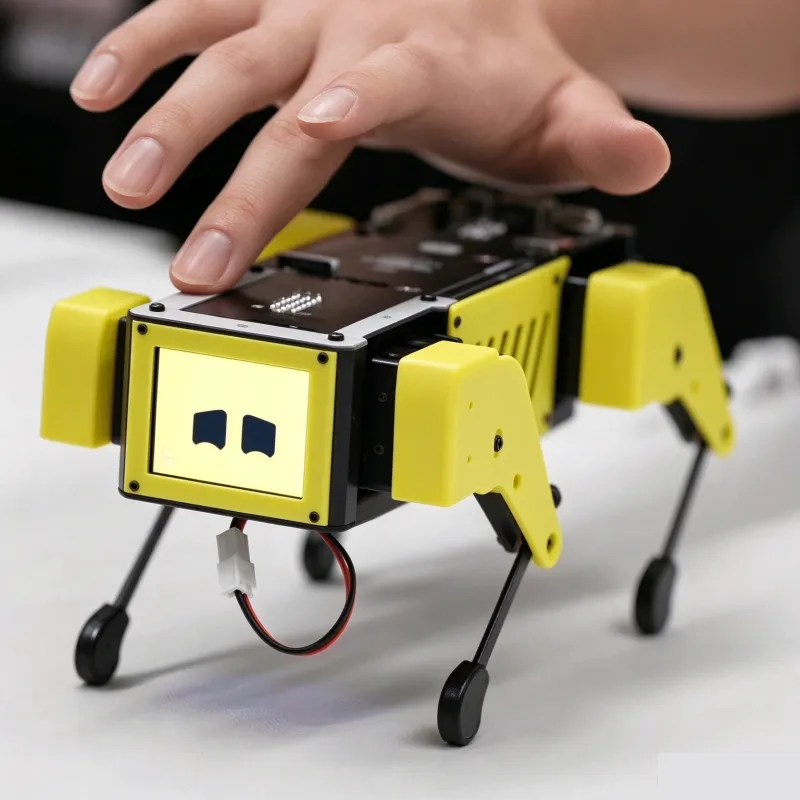
Touch sensor | Yes |
Reserved pins | Yes |
Screen | 320x240 |
Battery | 1000mAh |
OS | Ubuntu 24.04 / 22.04 |
ROS | ROS2 Humble / Jazzy |
Generative AI | ChatGPT@OpenAI / Gemini@Google / Claude@AWS / openClaw |
FAQ
1. Assembly
Documentation: https://minipupperdocs.readthedocs.io/en/latest/index.html Code: https://github.com/mangdangroboticsclub
2. Returns & Exchanges
This product is sold as unassembled parts. First-time users may leave marks during assembly which prevent resale. Returns or exchanges will NOT be accepted once the package is opened. If individual components get damaged during later use, replacement parts are available at the original component price.
3. One-on-one technical support?
We mainly provide online documentation. One-on-one technical support is not offered. Customers with limited assembly skills are advised to purchase the kit with caution.
4. Secondary development allowed?
Both software and hardware are fully open-source for secondary development. Great for quadruped robot enthusiasts!