

Product Description
AgiBot OmniHand (Agile Version 2025)
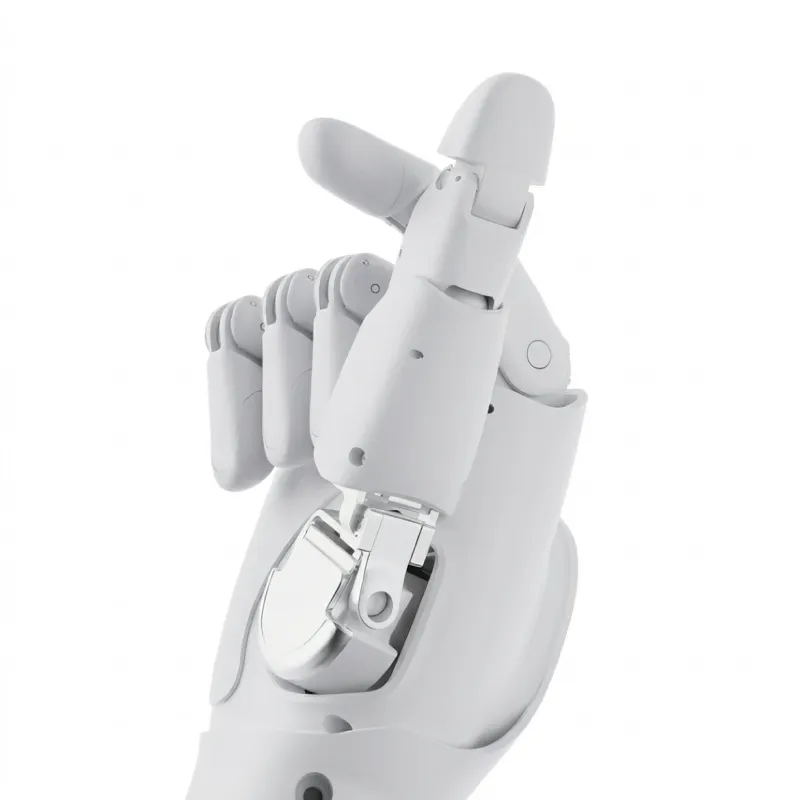
Compact, High-DOF Interactive Dexterous Hand
Small Form Factor, Truly Versatile
Compact & Lightweight | Natural Interaction | Safe & Friendly
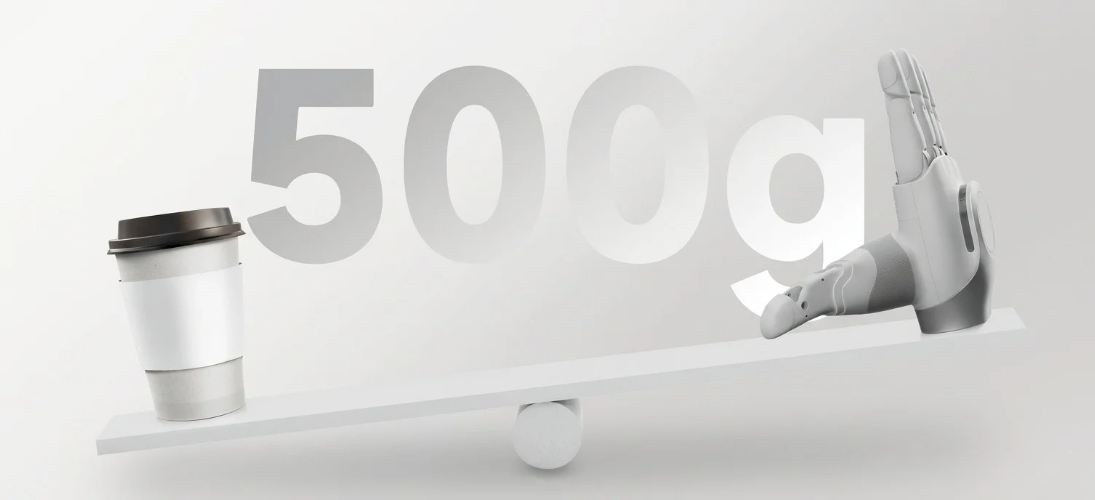
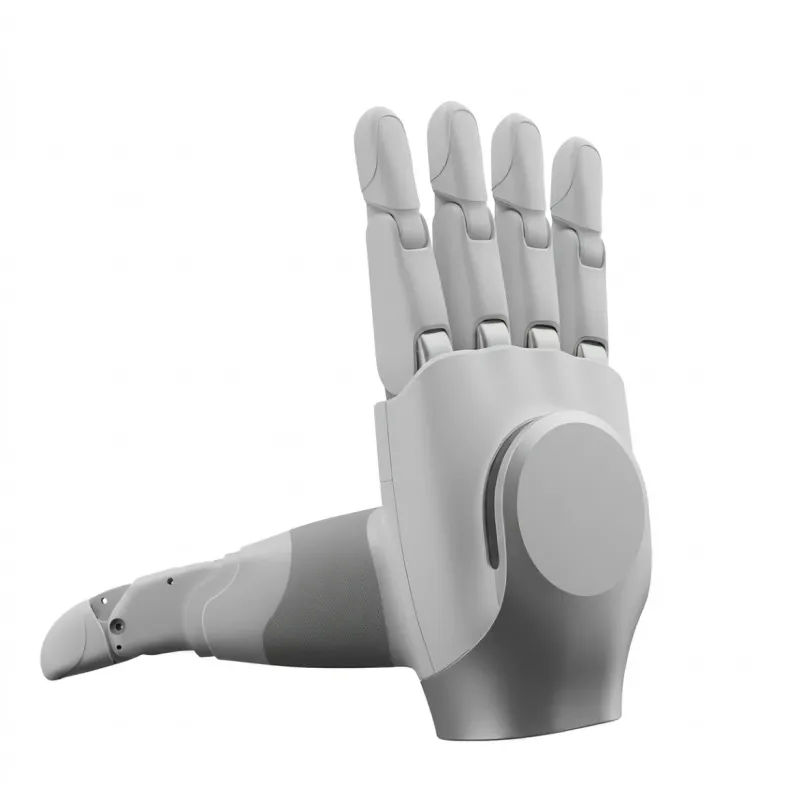
Compact & Lightweight
Total length: 180 mm | Ultra-light: 500 g | Versatile sizing
The ideal pair of hands for various humanoid robot models
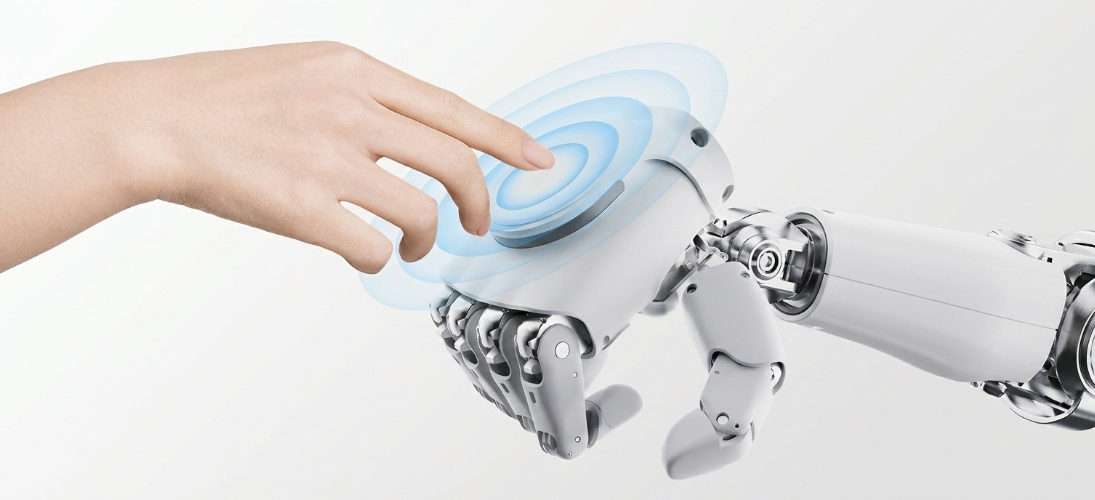
Natural & Responsive Interaction
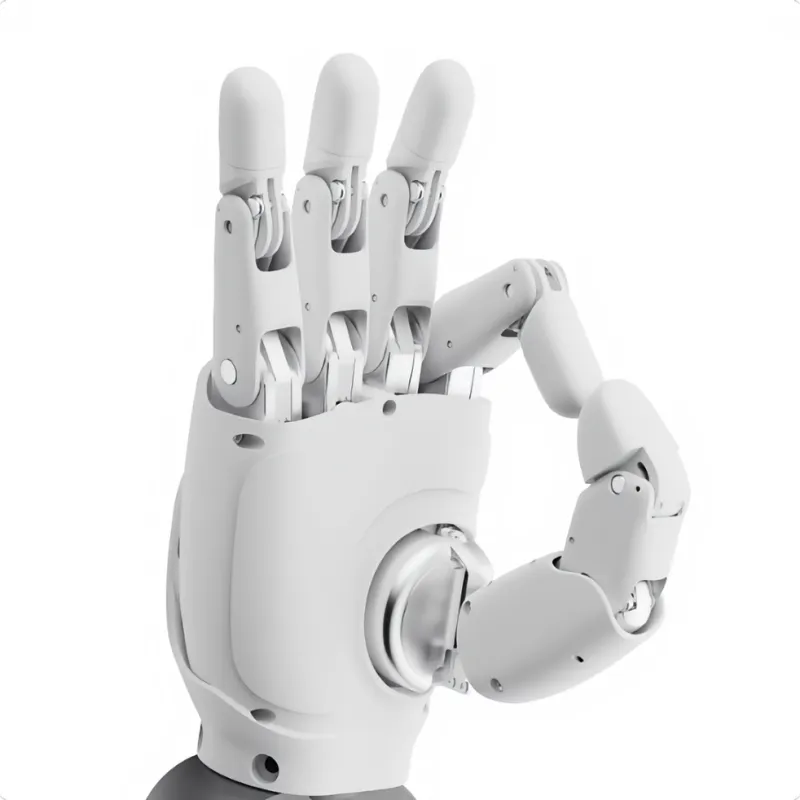
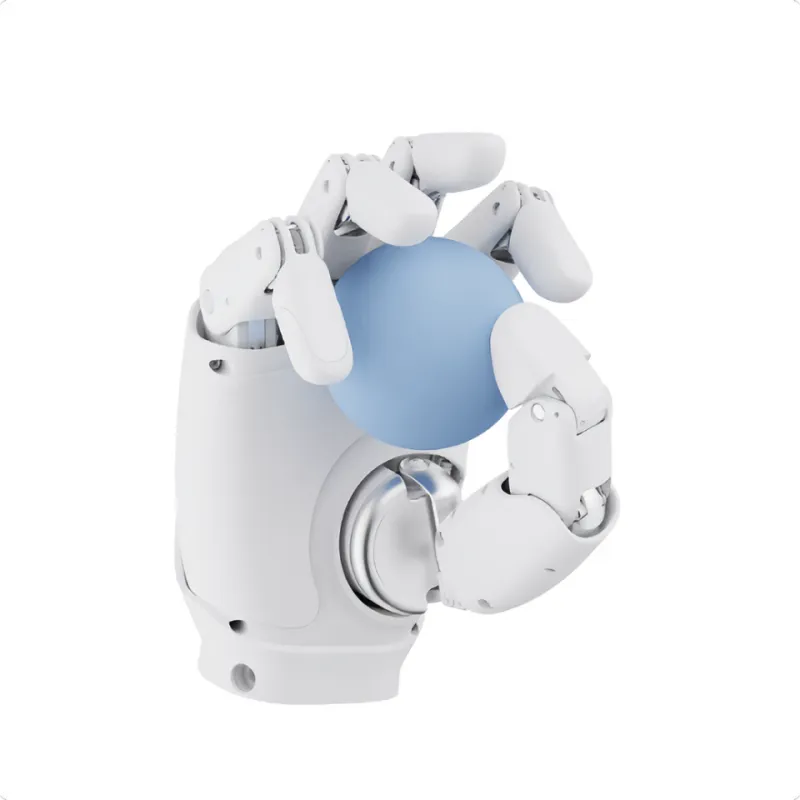
16 Degrees of Freedom (DOF) for more human-like gestures
Full coverage of common interactive gestures, featuring an innovative back-of-hand touch interaction
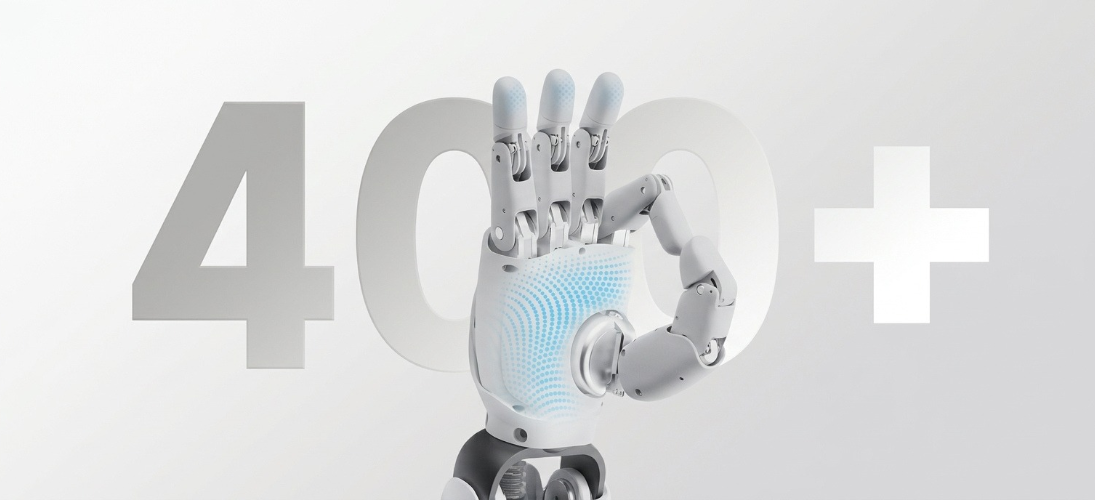
Safe & Friendly
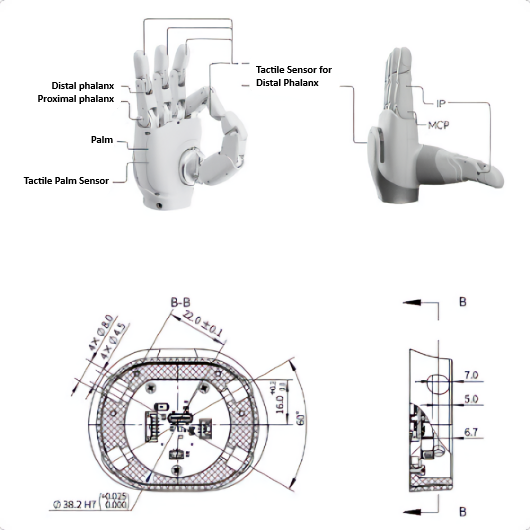
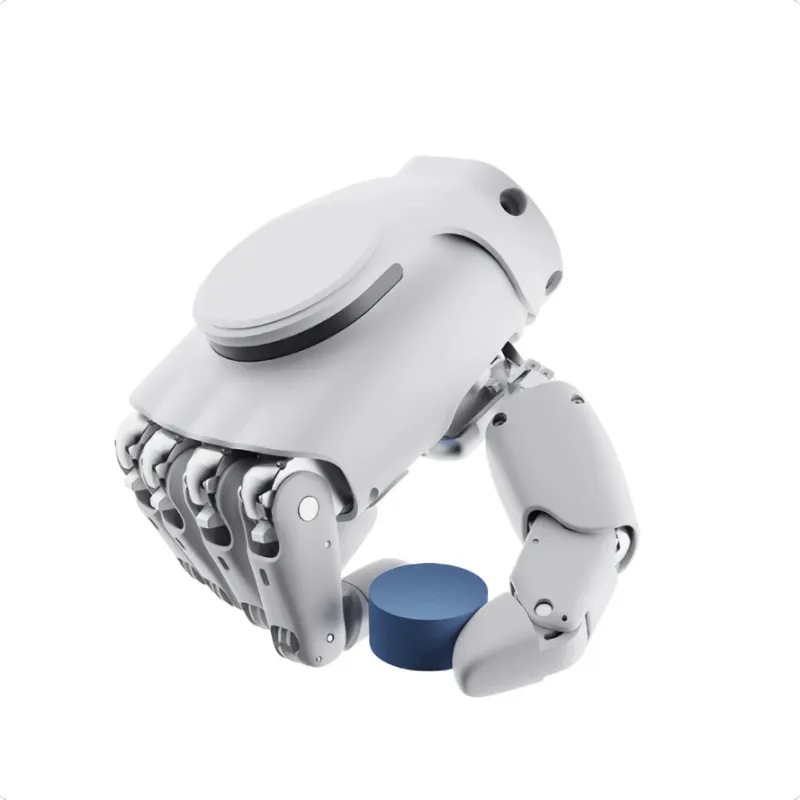
Over 400+ tactile sensing points for precise force control
Anti-pinch safety design for secure human-robot interaction
Complete unit packaging
|
|
| OmniHand *1 | RS485 communication cable *1 CAN FD communication cable *1 |
|
|
Power cord × 1 Type-C data cable × 1 | Factory Certificate of Conformity *1 |
Product parameters
OmniHand | Agile Model | Tactile Model | |
Physical Specs | Weight | ≤500g | ≤550g |
Dimensions | 180*85*38.5mm | 180*85*38.5mm | |
Material | PA+Silicone | PA+Silicone | |
Active Degrees of Freedom | 10 | 10 | |
Total Degrees of Freedom | 16 | 16 | |
Transmission Structure | Linkage Transmission | Linkage Transmission | |
Drive Method | Motor + Gear | Motor + Gear | |
Joint Angles | 4-Finger Flexion: 80° | 4-Finger Flexion: 80° | |
4-Finger Abduction: +-10° | 4-Finger Abduction: +-10° | ||
Thumb Flexion: 50° | Thumb Flexion: 50° | ||
Thumb Abduction: 100° | Thumb Abduction: 100° | ||
Thumb Rotation: 60° | Thumb Rotation: 60° | ||
Min. Opening/Closing Time (Typical) | 0.7s | 0.7s | |
Min. Grasping Diameter | 5mm | 5mm | |
Fingertip Repeatability (Typical) | 0.5mm | 0.5mm | |
Max. Fingertip Force (Typical) | 5N | 5N | |
Operating Voltage | 24V | 24V | |
Quiescent Current | 0.2A | 0.2A | |
Max. Current | 3.5A | 3.5A | |
Communication Interface | CANFD/RS485 | CANFD/RS485 | |
Operating Temperature | -10~45℃ | -10~45℃ | |
Payload Capacity (Palm facing up, grasping 5cm rigid cylinder at room temp) | 1kg | 1kg | |
Payload Capacity (Palm facing left, grasping 5cm rigid cylinder at room temp) | 0.5kg | 0.5kg | |
Perception | Array Sensor Quantity | / | 400+ Haptic Points |
Array Resolution | / | 0.1N | |
Sensing Range | / | 0~20N | |
Max Acceptable Force (Without Damage) | / | 200N | |
Software Features | Operating System | Windows | Windows |
Communication Rate | 1kHz | 1kHz | |
Total Number of Bytes per Packet | Received 51 bytes | Received 51 bytes | |
Sensory feedback | Joint position | Joint position | |
Joint velocity, joint torque | Joint velocity | ||
Joint temperature, voltage, current | Joint torque | ||
Joint temperature | |||
Voltage and current sensing | |||
Pressure value | |||
Control Mode | Speed mode | Speed Mode | |
Position mode Force control mode | Position Mode | ||
force position blending mode | Force Control Mode | ||
Force/Position Hybrid Mode | |||
Touch Module | |||
Secondary Development Ecosystem | Supports secondary development | Supports secondary development | |
other | Compatibility | Compatible | Compatible |
Non-Agibot Robots |
Application wiring diagram