

Product Description
WALK
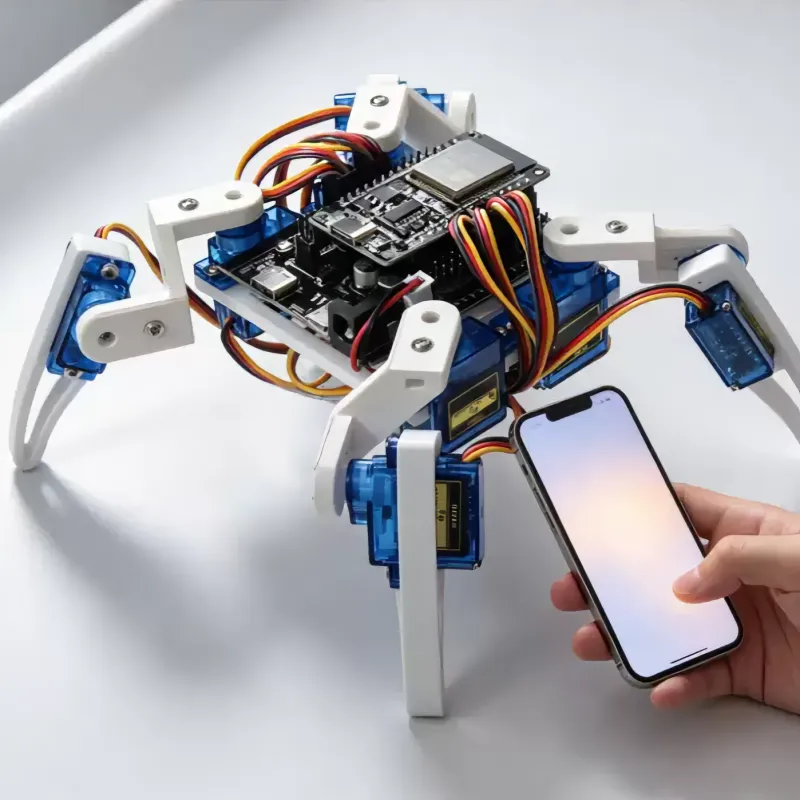
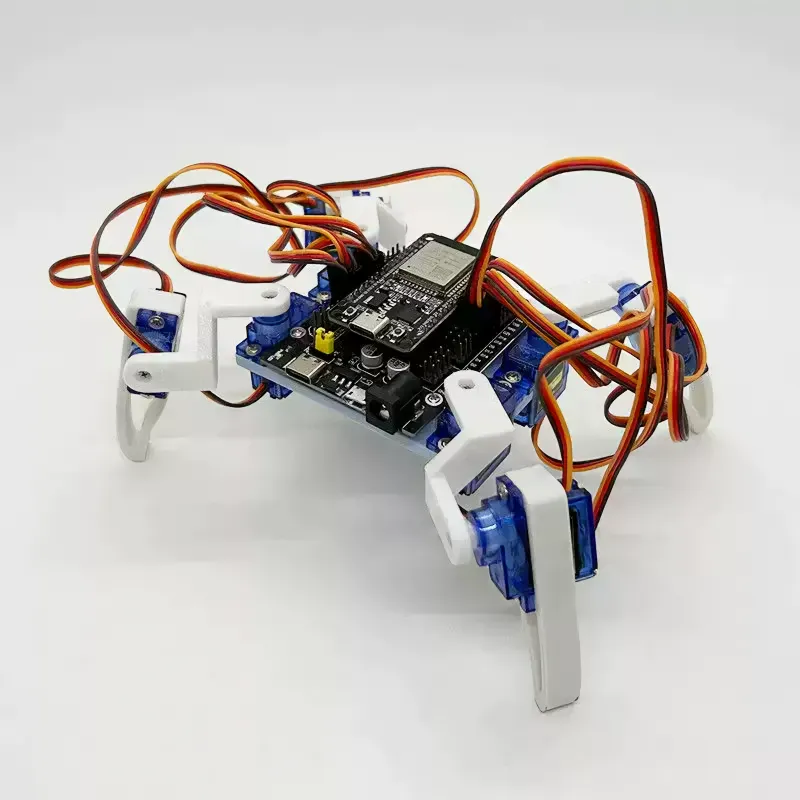
Quad-Mpy: Fully Open-Source Quadruped Robot
Why choose it?
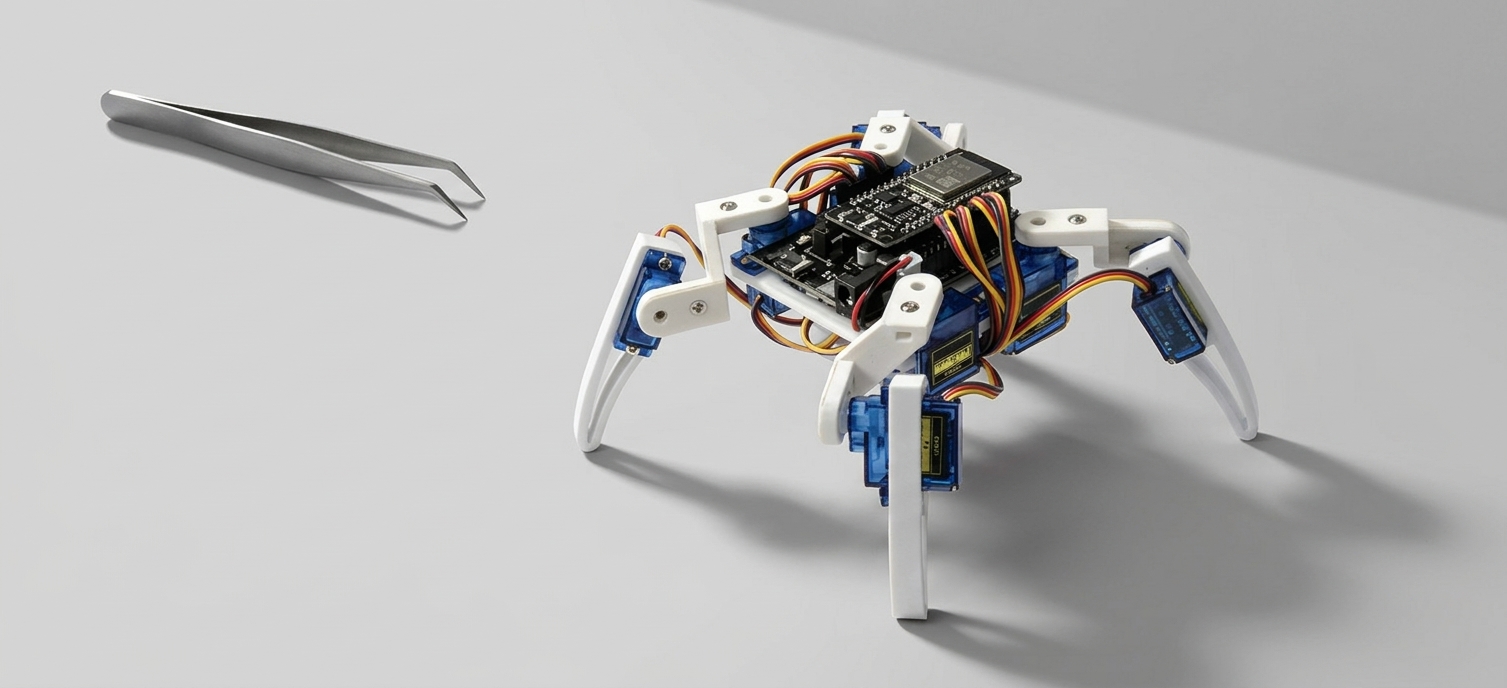
Ready to use right away, yet fully customizable.
Please include a note with your order, and we will flash the program for you in advance simply connect the wiring upon receipt, and it’s ready to go. |
MicroPython is quick to get started with by default and is compatible with the Arduino framework. |


Visible Progress
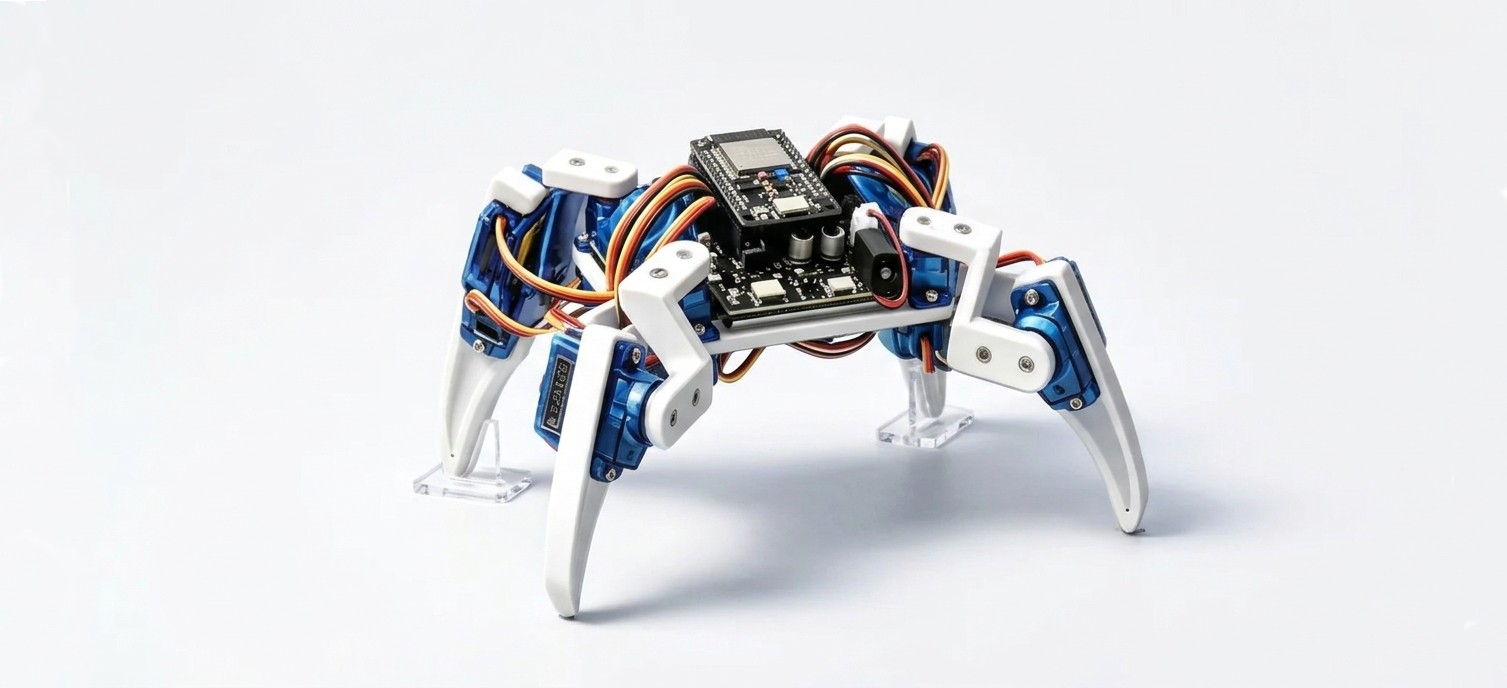
Every parameter adjustment yields immediate feedback.
From struggling to stand to walking steadily—changing a single line of parameters can alter behavior—this offers a level of freedom that ordinary toys simply cannot provide.
Professional-grade configuration
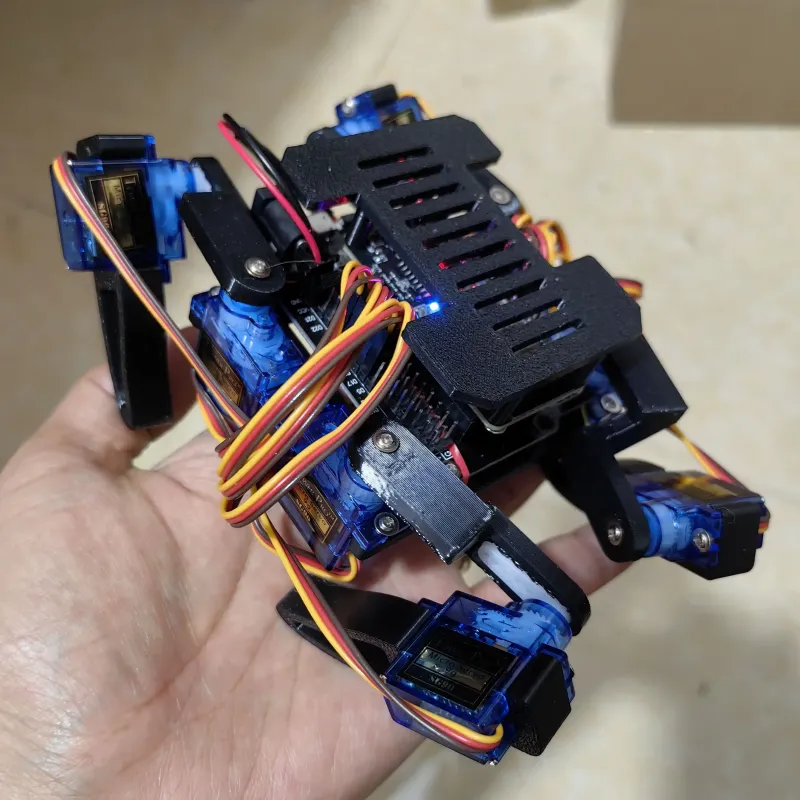
| ESP32-WROOM Dual-core 240MHz, with built-in WiFi/Bluetooth, Type-C for debugging. | 8x SG90 servos. Direct PWM drive; the ESP32 LEDC peripheral can support up to 16 channels. |
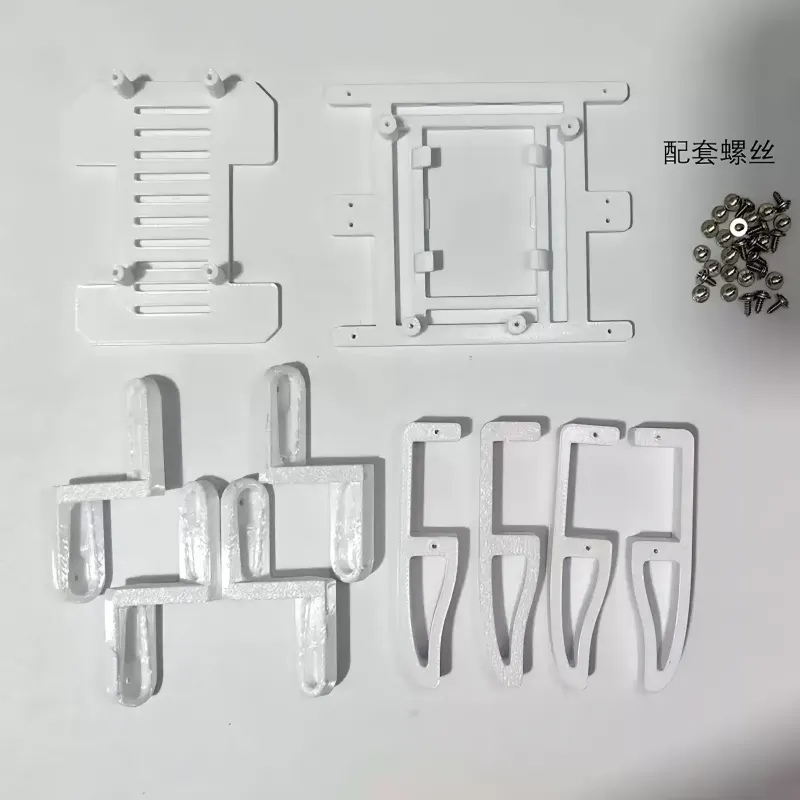
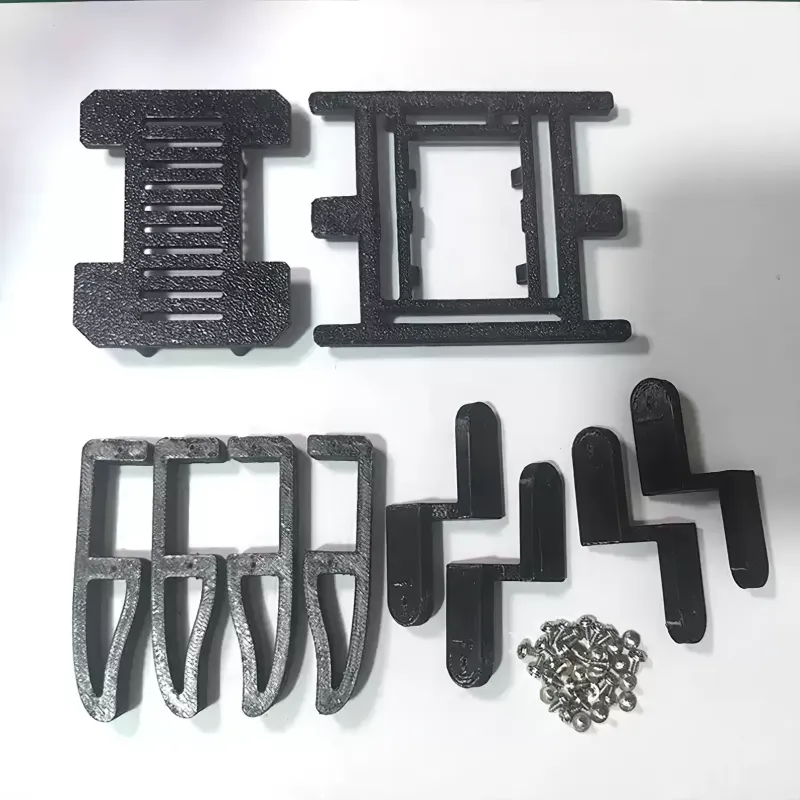
3D-printed structure Made of PLA; precise hole placement; components can be replaced as needed. Leg-style design. | WiFi Web Interface Zero-installation, cross-platform; use directional keys and a slider to adjust speed. |
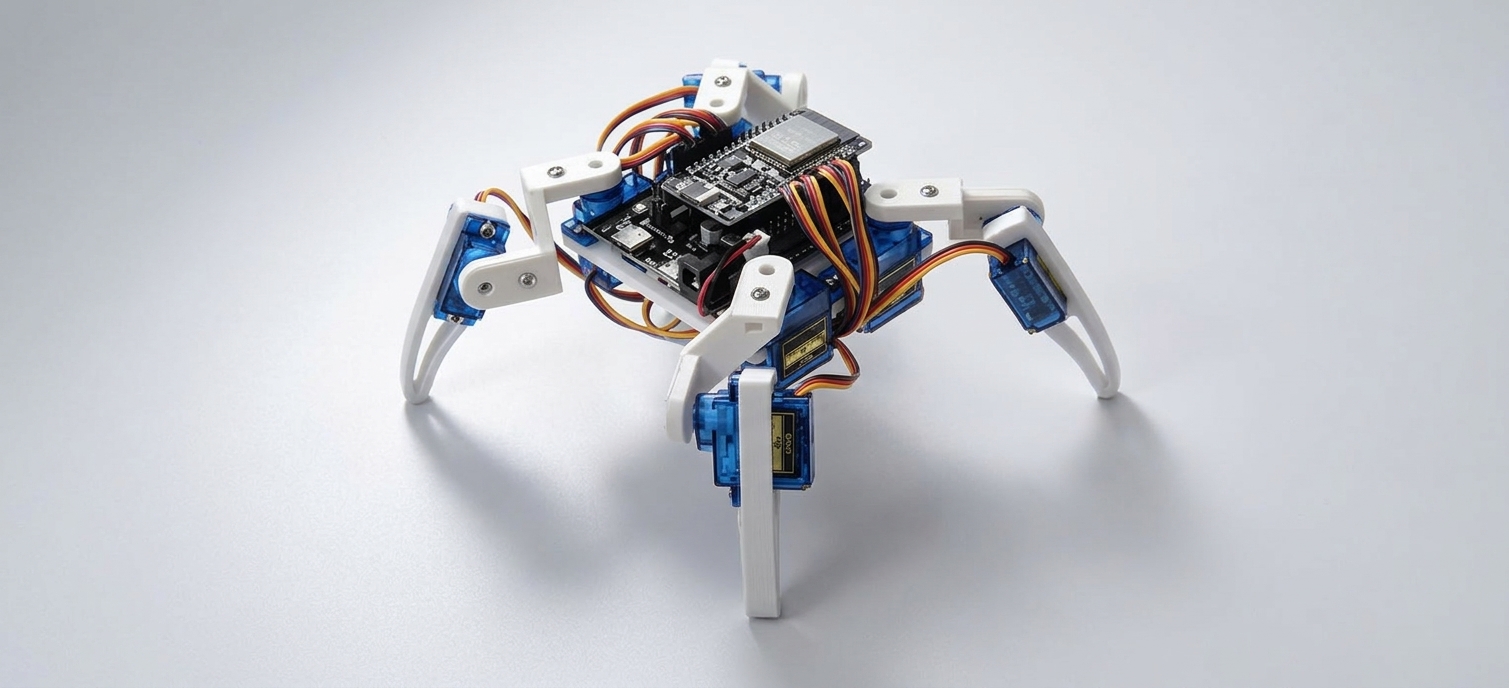
Obstacle Traversal & Adjustable Gait
Real-time adjustment of standing height, stride length, and swing frequency—experience firsthand how each parameter influences walking posture.
1. Assembly and Flashing Wiring, installing MicroPython, and calibrating the servos to their center positions. | 2. Getting It Moving Read `main.py`, tune the gait, and achieve stable walking. |
3. Wi-Fi Remote Control Connect to the router and open the control page in your browser. | 4. Secondary Development Customizing actions, attaching sensors, and modifying web pages. |
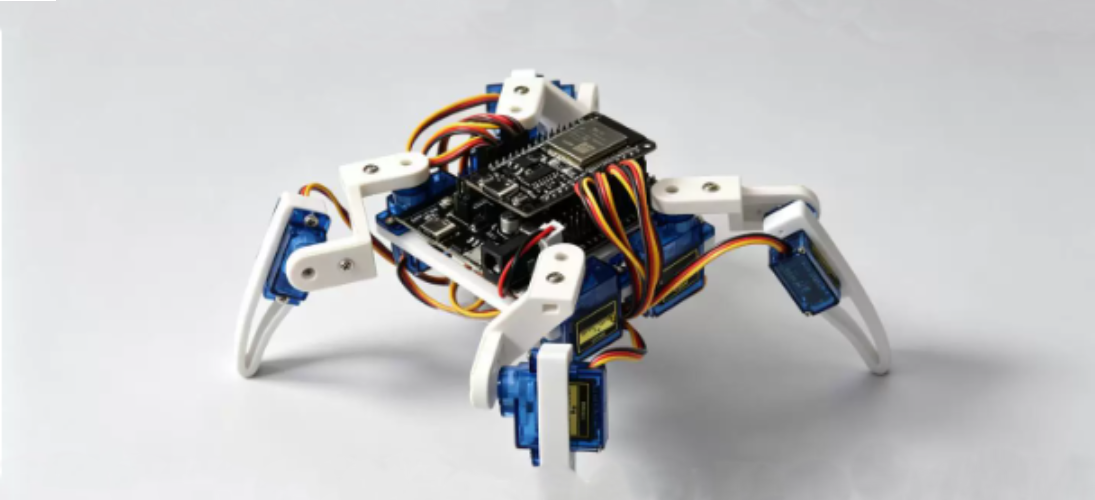
Posture detection and dynamic adjustment
Whether it involves lowering the body, extending upward, or compensating for lateral tilt, every movement is governed by specific parameters with real-time response.
Limitless expansion possibilities
Use the GPIO/I2C interfaces to connect components like ultrasonic sensors, OLED displays, or buzzers; you can also 3D-print custom leg designs.
Product parameters
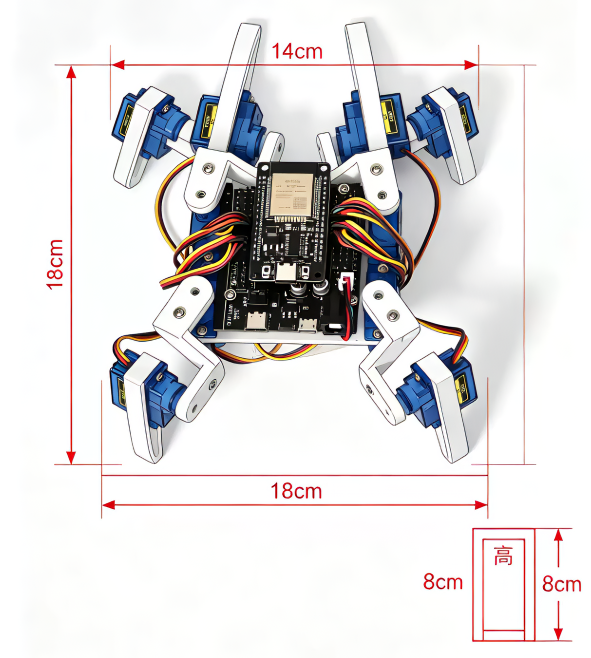
It is slightly larger than a palm-sized robot dog.
Once fully assembled, the robot measures approximately 18 × 14 × 8 cm. Its structure is more robust, the servo motors offer higher torque, and the structural components are larger and easier to assemble.
Packing List
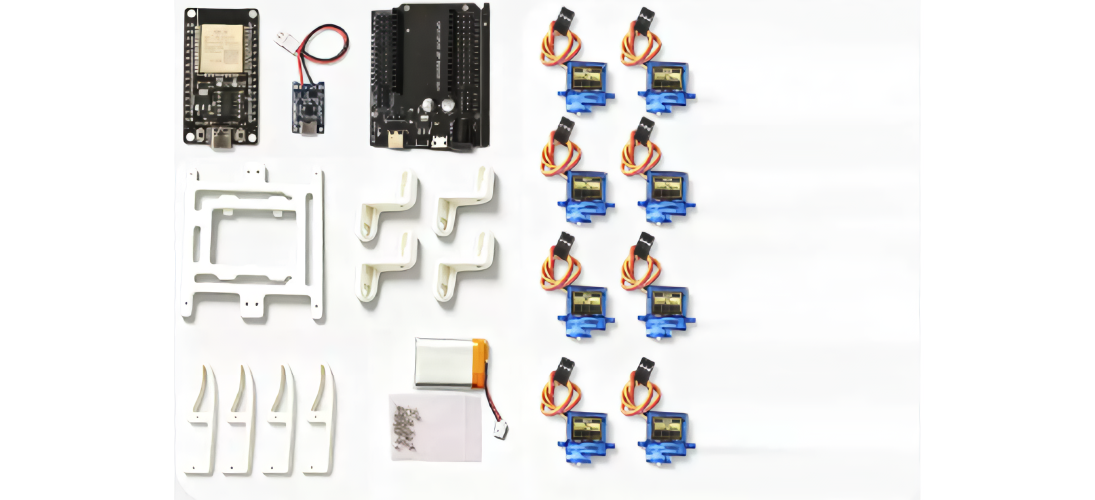
ESP32 microcontroller | ×1 | Servo (with wires) | ×8 |
3D-printed parts | ×1 | Expansion/charging board | ×1 bonus |
Battery | ×1 | Screws/source code | Included as a bonus |