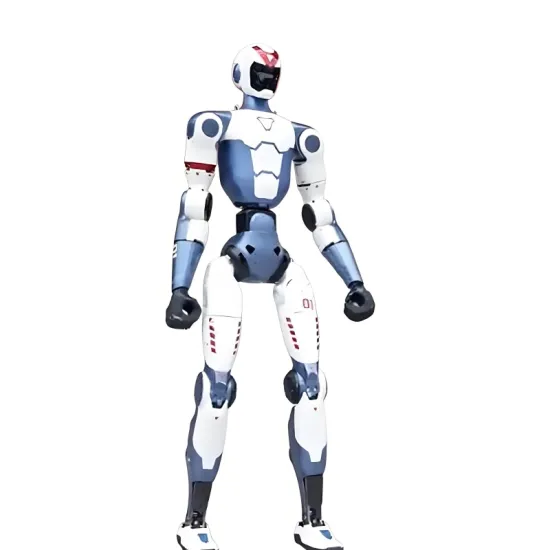


Product Description
Unitree R1 Air New Product
Extremely lightweight and ready to use out of the box
Bringing humanoid robots into daily life
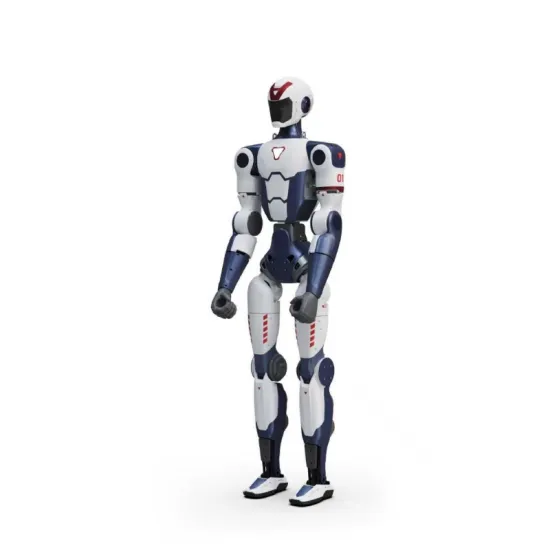
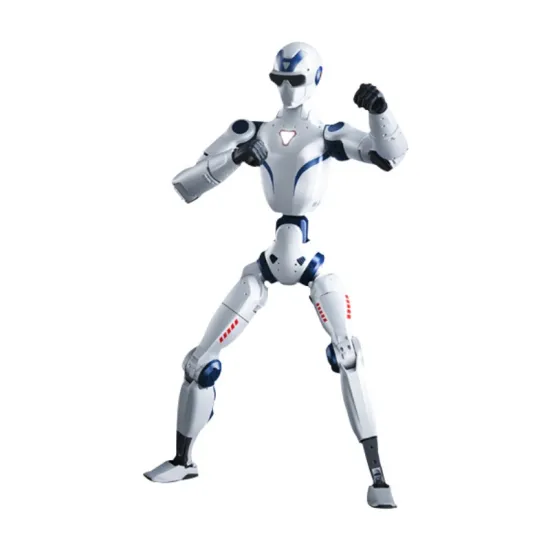
*The picture shows a prototype, and the final appearance details are subject to the actual product
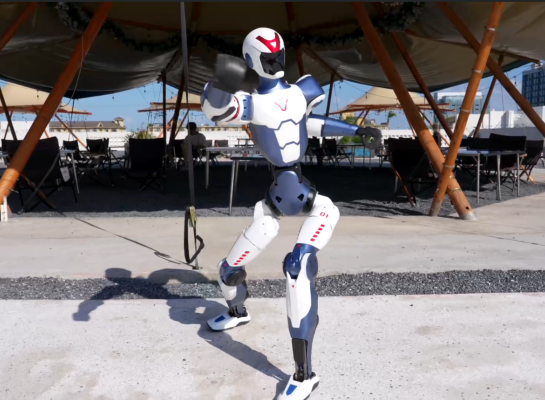
20 degrees of freedom: Rich in actions, suitable for complex scenes
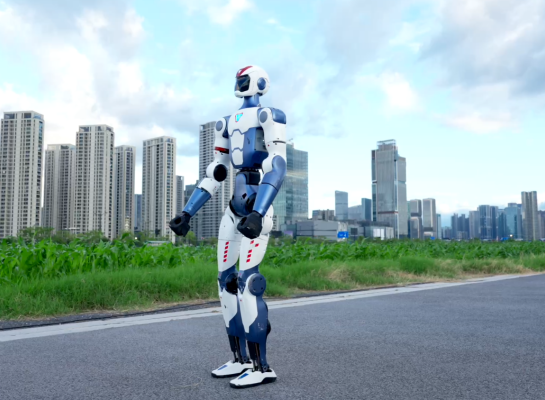
Approximately 123cm 27kg, lightweight configuration, easy maintenance
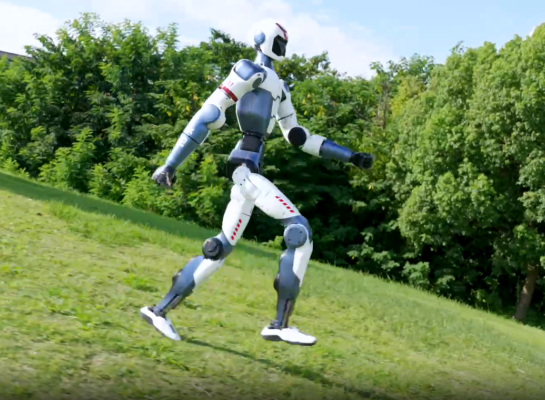
Integrated speech and image, multimodal large model
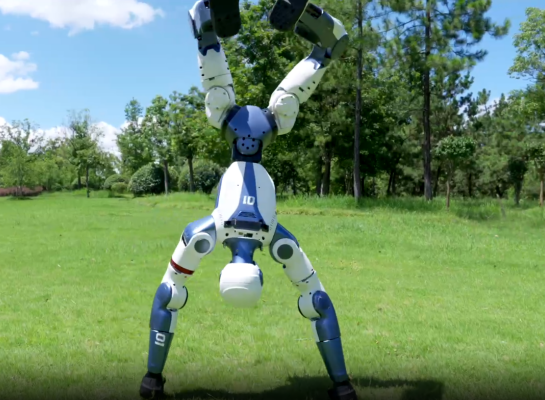
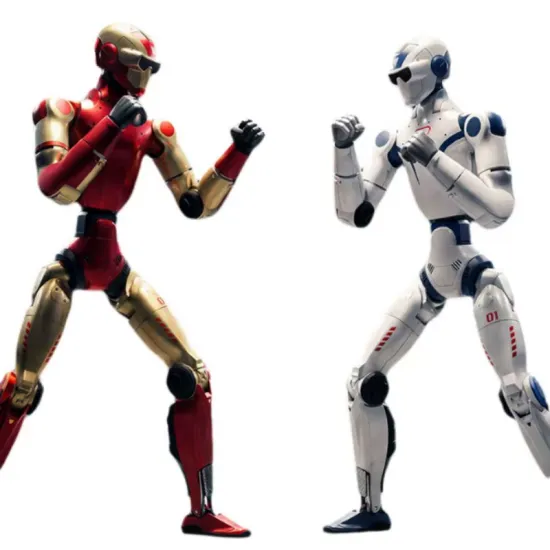
Strong athletic performance, proficient in sports and entertainment
Functional Features
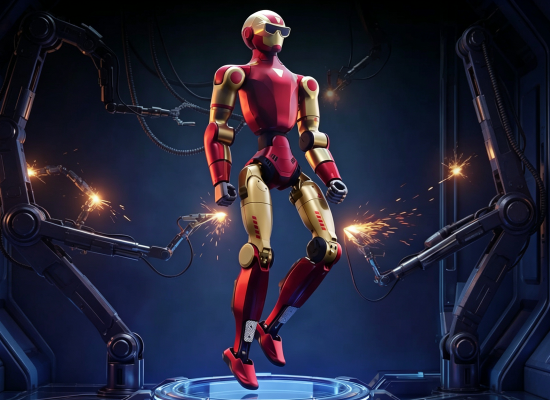
Aesthetic works
Good looking and capable of playing, the focus is immediately on the stage
·Free appearance: Exclusive creative stickers, customizable appearance;
·Minimalist aesthetics: an integrated curved body with a golden ratio, creating a natural sense of the future.
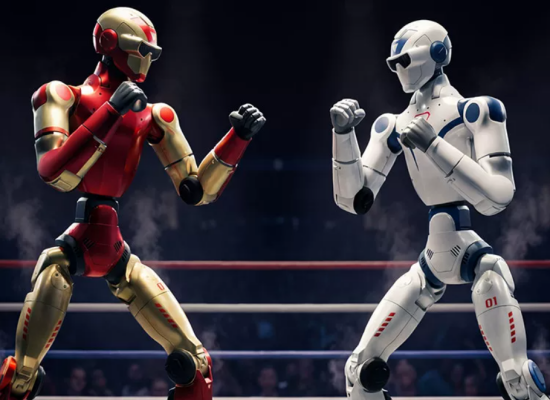
High degree of freedom
Reshaping the Sports Strength of Humanoid Robots
Equipped with 20-26 high degree of freedom joints throughout the body, complemented by a dual degree of freedom design for the head, the perception is more sensitive and the expression is more vivid.
It can move smoothly in complex scenes, achieve interactive interaction, run quickly, dance dynamically, perform kung fu, and more.
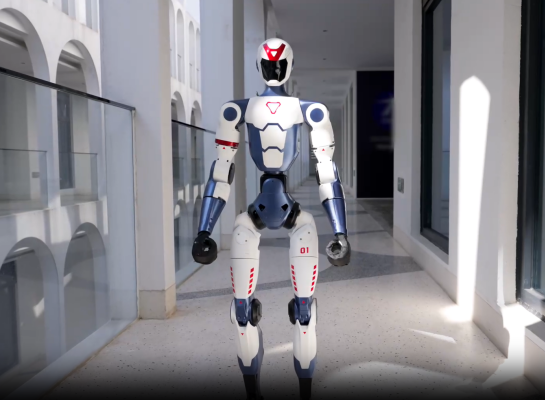
Main parameters of Unitree R1 Air
Computing module: 8 cores+GPU
Camera Module: Humanoid Monocular Camera
Microphone array: 4 arrays
Quick disassembly battery: quick replacement
Speaker: Stereo dual speakers (3Wx2)
Single arm degree of freedom:4
Unitree R1 New Product
Extremely lightweight and ready to use out of the box
Bringing humanoid robots into daily life
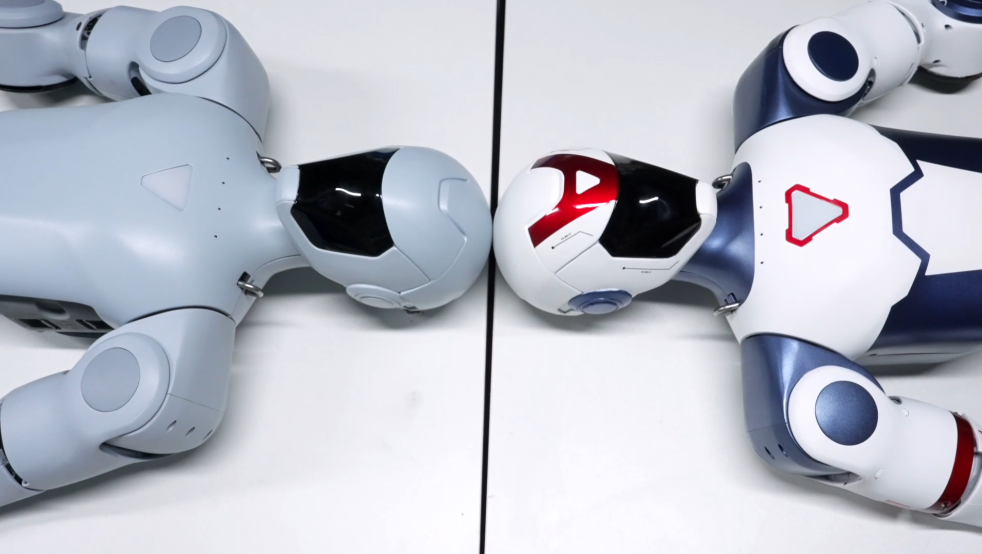
Parameter | Value |
Vision Compute Module | 10 TOPS |
Camera Module | Humanoid binocular camera |
Compute Module | 8-core + GPU |
Quick-Swap Battery | Quick replacement |
Microphone Array | 4-array |
Speaker | Stereo dual speakers (3W×2) |
DOF per Arm | 5 |
Waist DOF | 2 |
Product parameters
Model | R1 AIR | R1 | R1 EDU | |
Mechanical Dimensions | H×W×D (standing) | 1230x357x190mm | 1230x357x190mm | 1230x357x190mm |
Total Weight | ~27kg | ~29kg | ~29kg | |
DOF (Joint Motors) | 20 | 26 | 26-40 | |
DOF per Leg | 6 | 6 | 6 | |
DOF per Arm | 4 | 5 | 5 | |
Waist DOF | / | 2 | 2 | |
Head DOF | / | 2 | 2 | |
Dexterous Hand | / | / | Optional | |
Joint Output Bearing | Cross-roller + double-row ball bearing | Cross-roller + double-row ball bearing | Cross-roller + double-row ball bearing | |
Joint Motor | Low-inertia high-speed inner-rotor PMSM (faster response & better heat dissipation) | Low-inertia high-speed inner-rotor PMSM (faster response & better heat dissipation) | Low-inertia high-speed inner-rotor PMSM (faster response & better heat dissipation) | |
Max Arm Payload [1] | ~2kg | ~2kg | ~2kg | |
Shin + Thigh Length | 600 | 600 | 600 | |
Forearm + Upper Arm Length | 420 | 420 | 420 | |
Joint Motion Range | Knee: -10°~+139° Hip: Y:±157° P: -168°~+146° R: -60°~+100° | Knee: Y:±150°, R:±30° Hip: Y:±157° P: -168°~+146° R: -60°~+100° | Waist: Y:±150°, R:±30° Knee: -10°~+139° Hip: Y:±157° P: -168°~+146° R: -60°~+100° | |
Electrical | Cable Routing | Hollow + internal routing | Hollow + internal routing | Hollow + internal routing |
Joint Encoder | Dual + single encoder | Dual + single encoder | Dual + single encoder | |
Cooling System | Local air cooling | Local air cooling | Local air cooling | |
Power Supply | Lithium battery | Lithium battery | Lithium battery | |
Base Computing | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | |
Microphone | 4-array | 4-array | 4-array | |
Speaker | Yes | Yes | Yes | |
WiFi 6, Bluetooth 5.2 | Yes | Yes | Yes | |
Camera Module | Monocular camera | Binocular camera | Binocular camera | |
High-Compute Module | / | / | Optional NVIDIA Jetson Orin (40-100 TOPS) | |
Accessories | Smart Battery (Quick-Swap) | Yes | Yes | Yes |
Charger | Yes | Yes | Yes | |
Handheld Remote Controller | Yes | Yes | Yes | |
Others | Battery Life | ~1h | ~1h | ~1h |
Smart OTA Upgrade | Yes | Yes | Yes | |
Secondary Development [2] | / | / | Yes | |
Warranty [3] | 6 months | 8 months | 12 months | |
Notes:
[1] The max arm payload varies significantly with different arm extension postures.
[2] For detailed features, please refer to the secondary development manual.
[3] For more detailed warranty terms, please refer to the product warranty manual.
[4] The above parameters may vary with different application scenarios and model configurations; please refer to the actual product.
[5] Humanoid robots have complex structures and extremely powerful drive. Please keep a safe distance from the robot and use it with caution.
[6] Product appearance may be upgraded or adjusted in the future; please refer to the actual product at that time.
[7] Some example features on this page are still under development and testing, and will be released to users gradually.
[8] The industry is still in its early exploration stage globally. Individual users should fully understand the limitations of humanoid robots before purchasing.
[9] This product is a civil-use robot. Please do not modify or use the robot in a dangerous way.
[10]Please learn more about product-related terms and policies, and comply with local laws and regulations.