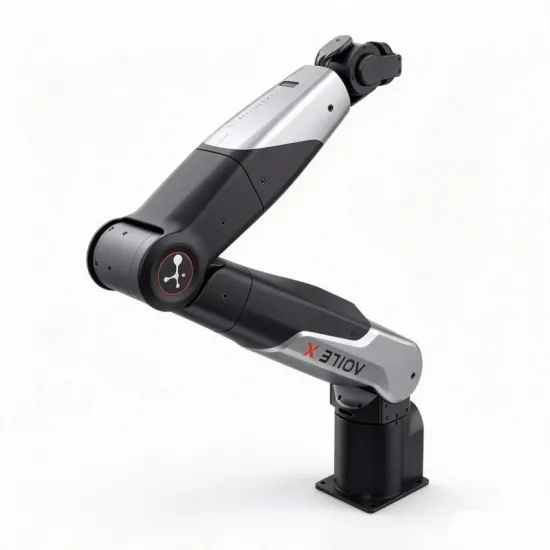
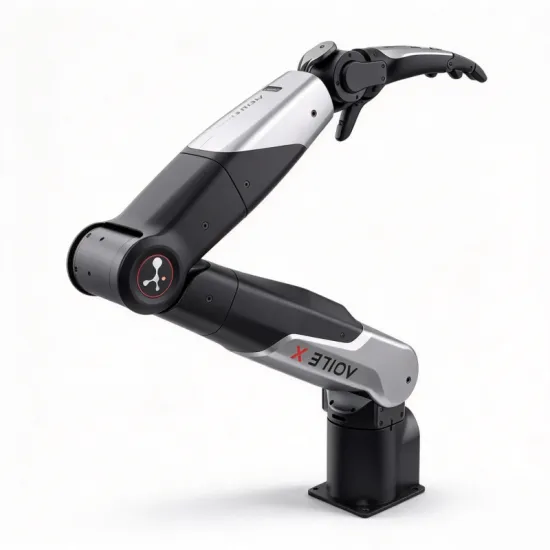


Product Description
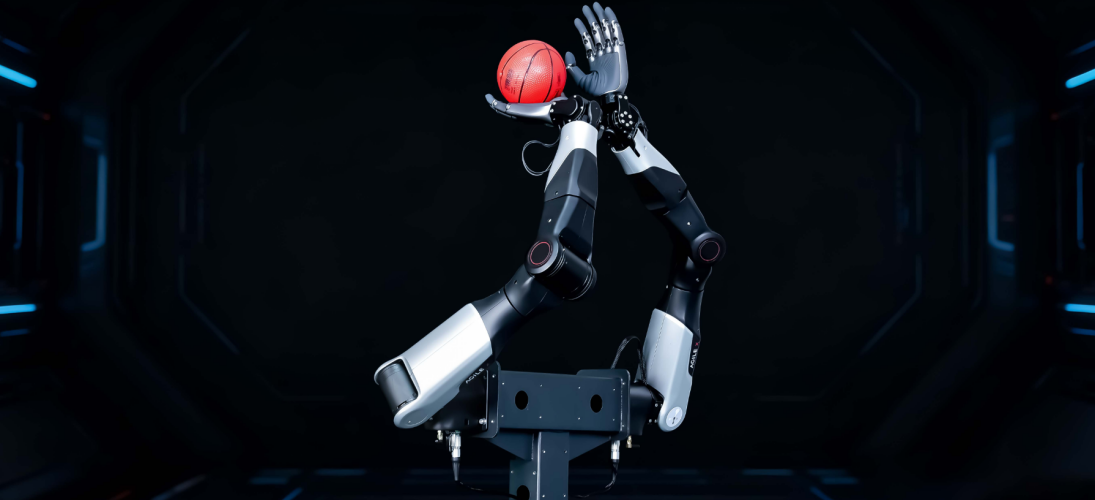
Product Highlights
To provide a more humanoid and flexible mobile operation core for embodied intelligence, humanoid robot research, and complex task scenarios.
Functional Features
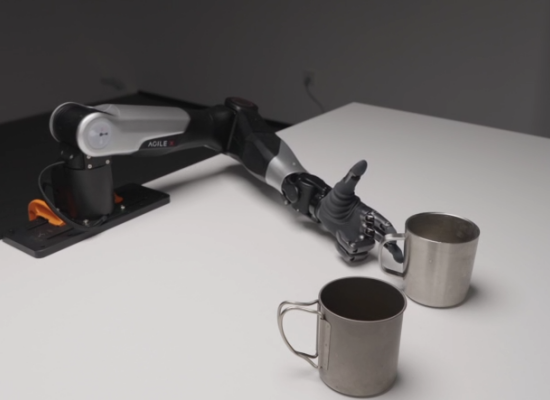
Redundant degree of freedom design
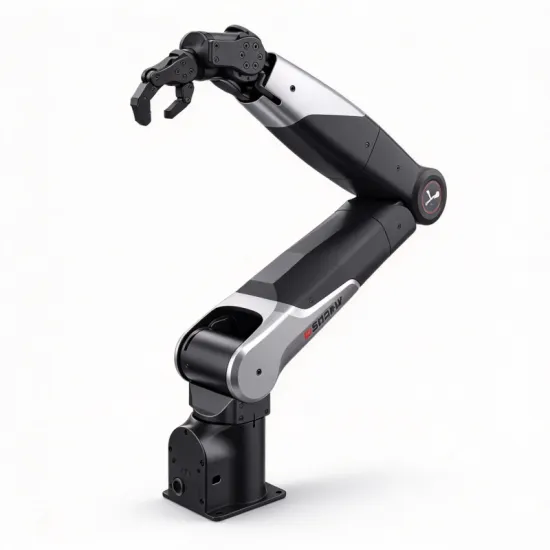
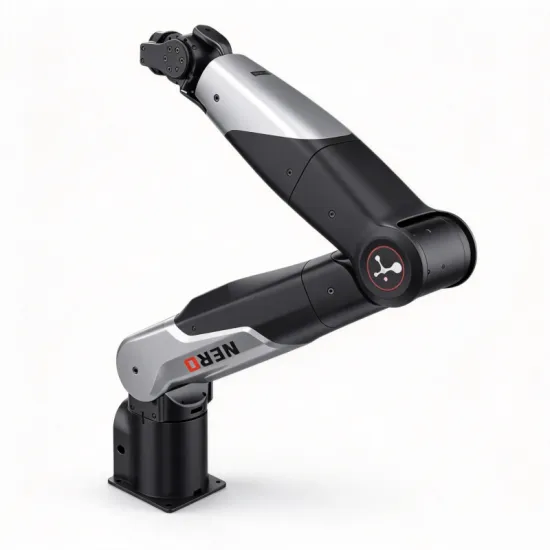
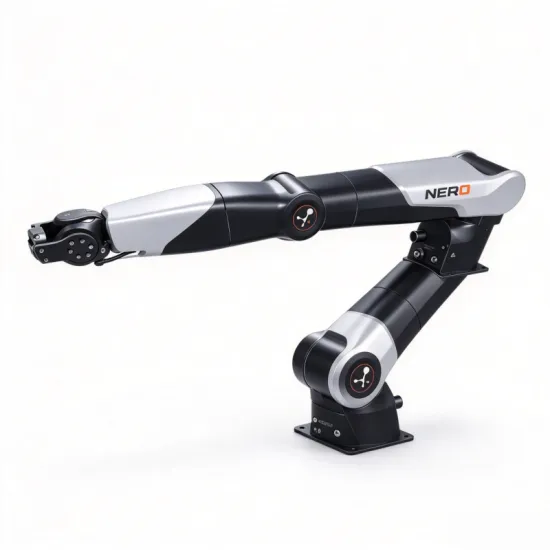
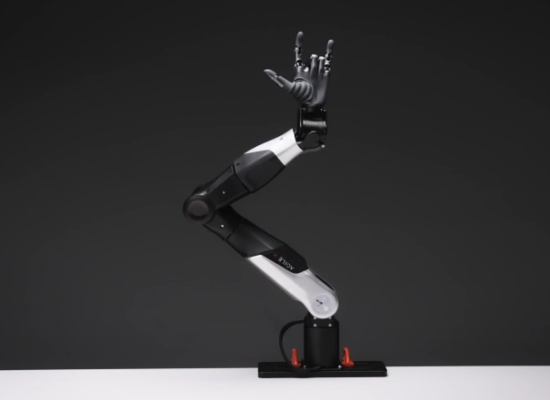
NERO adopts a humanoid seven axis redundant configuration, which not only replicates the motion characteristics of human arms, but also achieves a more natural and humanoid motion performance through redundant degrees of freedom, providing an ideal solution for embodied intelligence research and humanoid robot upper limbs.
Lightweight, portable, and easy to deploy
With a self weight of only 4.8kg, it can be easily lifted with one hand, and the end load can reach 3kg, supporting typical sensor modules;
Equipped with a G-clip and desktop holder, supporting multiple installation methods including tabletop, side mounted, and inverted installation
Adapt to the full range of Songling mobile chassis, easily build an integrated "mobile+collaborative" embodied platform
Open architecture, rapid secondary development
Communication protocol: Supports CAN, TCP, HTTP
Software ecosystem: Provides Python SDK, fully compatible with ROS1 and ROS2
Control mode: supports drag and drop teaching, offline trajectory planning, API programming, and upper computer control
Accurate and reliable, safe and intelligent
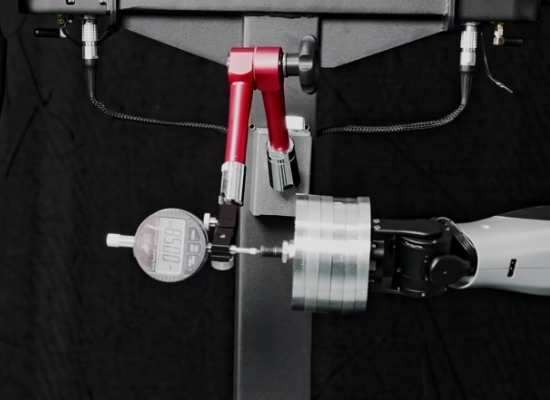
The repeated positioning accuracy reaches ± 0.1 mm, meeting the requirements of precision operation
Built in collision protection ensures safe human-machine collaboration;
Comprehensive power consumption ≤ 60 W, peak power consumption ≤ 150 W
Application
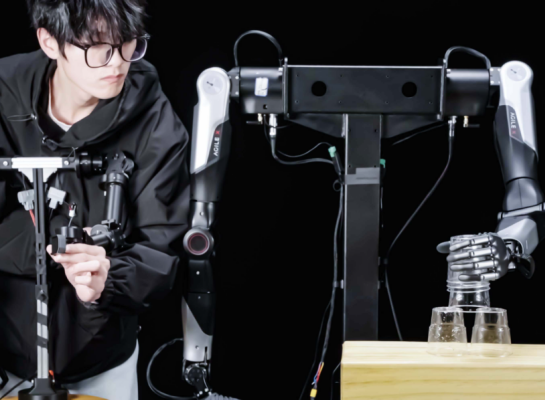
Embodied remote control
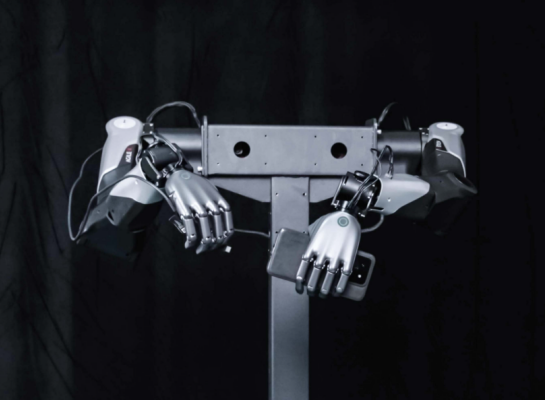
Humanoid upper limb
Dimensional Drawin
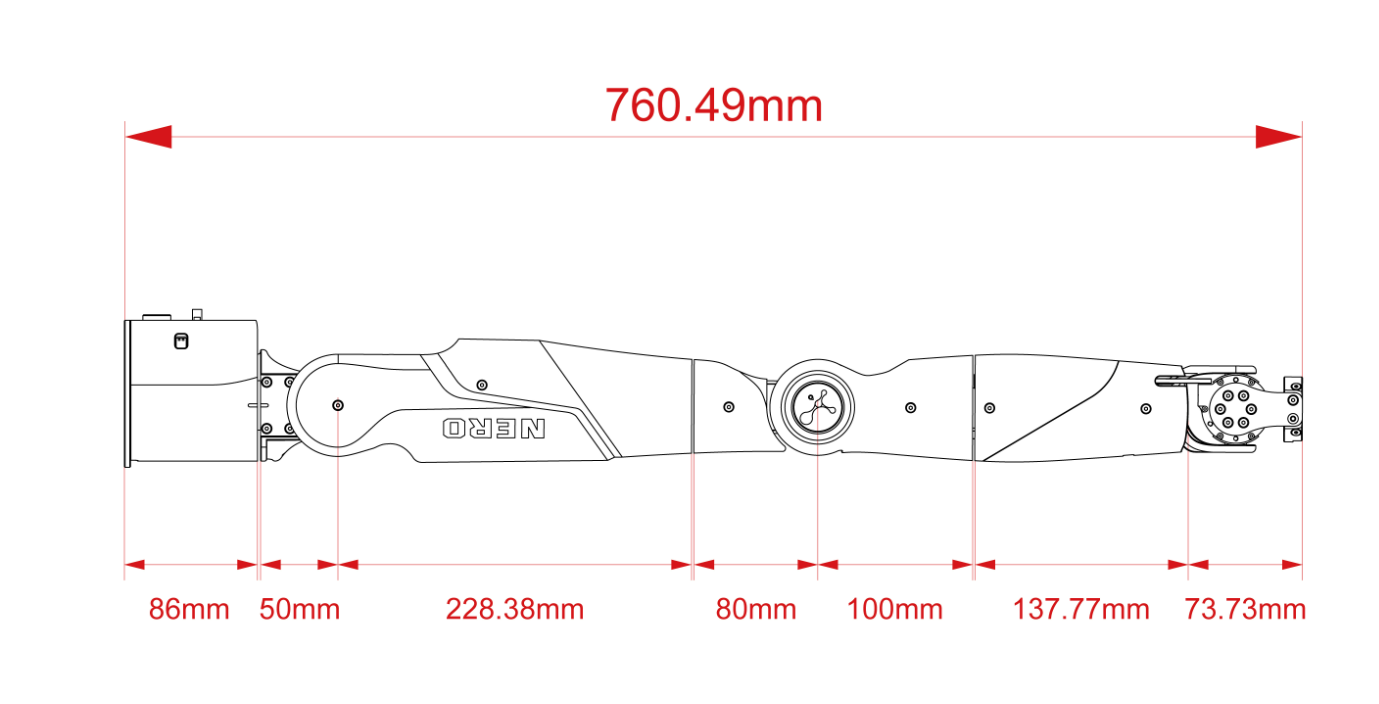
Product parameters
Parameter | Value |
Degrees of freedom | 7 |
Controller | Integrated industrial PC |
Working radius | 580 mm |
Weight | 4.8 kg |
Supply voltage | DC24V |
Payload | 3 kg |
Noise | < 60 dB |
Communication | CAN, HTTP, TCP |
Repeatability | ±0.1 mm |
Material | Aluminum alloy frame, plastic housing |
Mounting | Tabletop, side, inverted mounting |
Base dimension | 70mm*70mm*M5*4 |
Control modes | Drag teaching / offline trajectory / API / host PC |
External interfaces | Power ×1, CAN ×1, Ethernet ×1 |
Power consumption | Max. ≤150 W; typical ≤60 W |
Operating environment | Temp. 0-50 ℃, humidity 25%-85%, non-condensing |
Max. joint speed | J1–J3: 180°/s; J4–J7: 225°/s |
Joint motion range | J1:-157°~157° J2:-15°~190° J3:-160°~160° J4:-60°~125° |
Note: The above data are test results of AgileX under controlled test environments. Results may | |