

Product Description
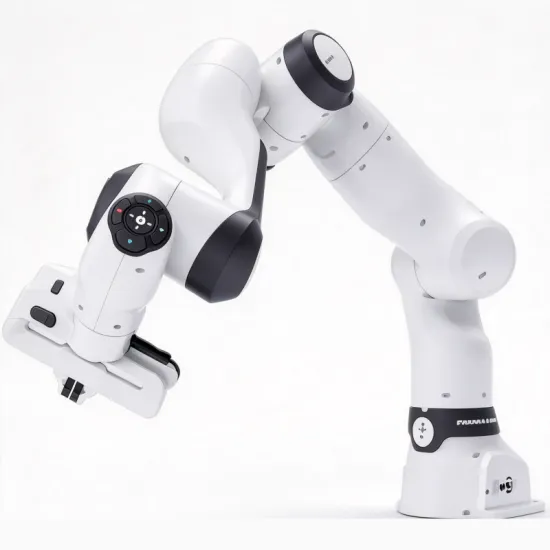
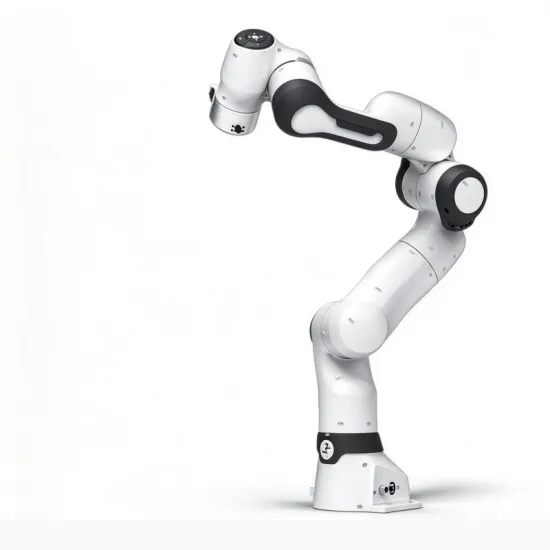
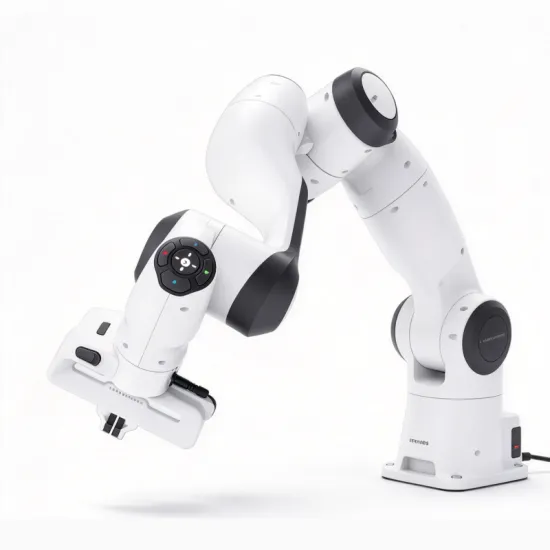
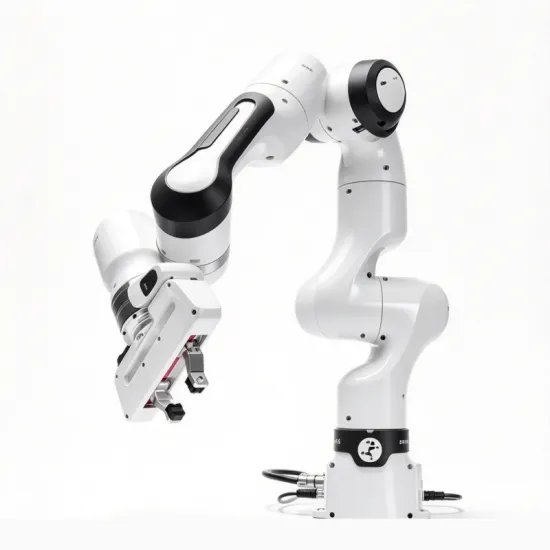
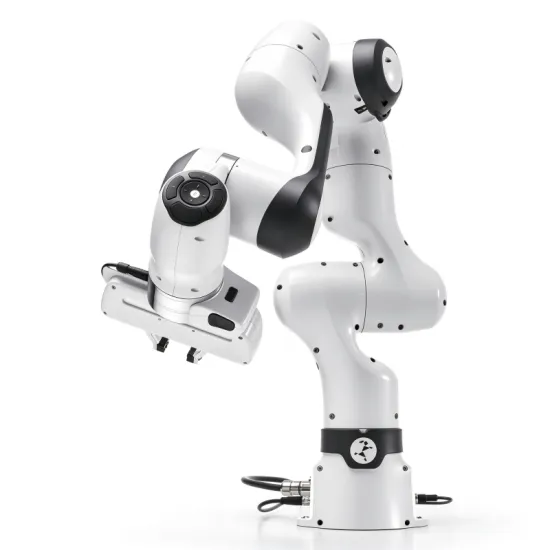
Franka Research 3
Precise force control technology
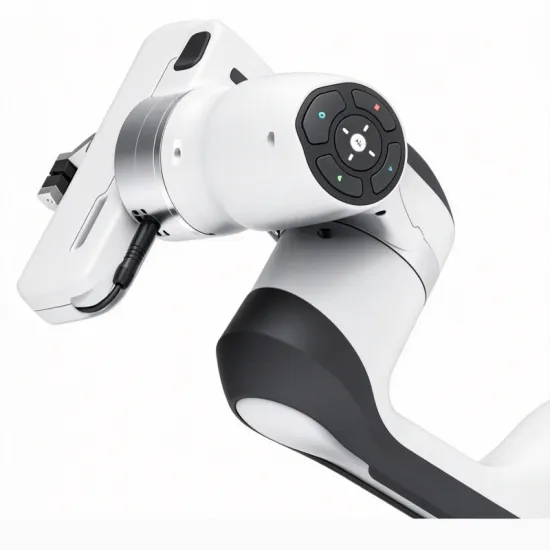
World-leading hand-guiding technology
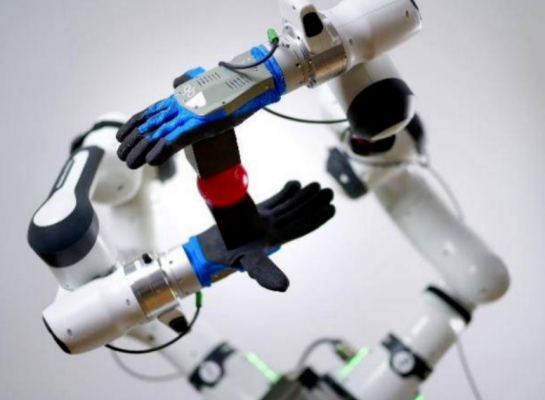
A flexible, sensitive and intelligent lightweight 7-axis robot
Supports ROS, MoveIt, MATLAB, Simulink;
open low-level C++ interfaces - a stable platform for secondary development
BRAND INTRODUCTION
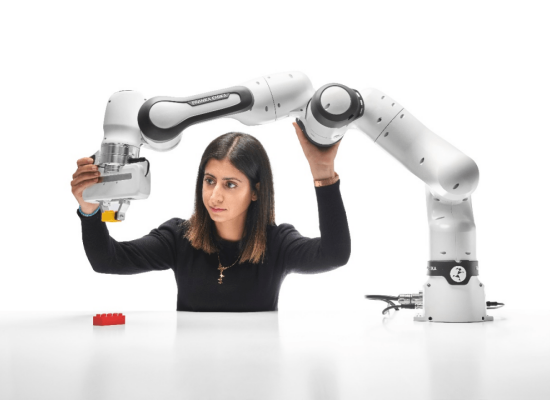
Franka Research 3 is the reference world-class,
force sensitive robotsystem that empowers researchers with easy-to-use robot features aswell as with low-level access to robot's control and learningcapabilities.
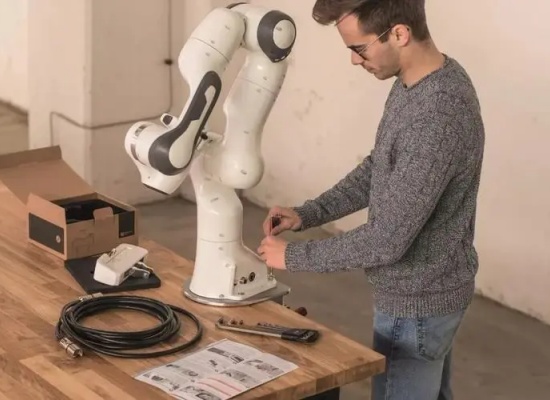
The Franka Emika robot system is an ideal choice for our research on reactive and robust manipulation in open environments.
It is also well suited for collaborative manipulation tasks with humans.
A new era of robot applications demands a new generation of robots - Franka Emika is laying a solid foundation for the new challenges of real-world robot applications.
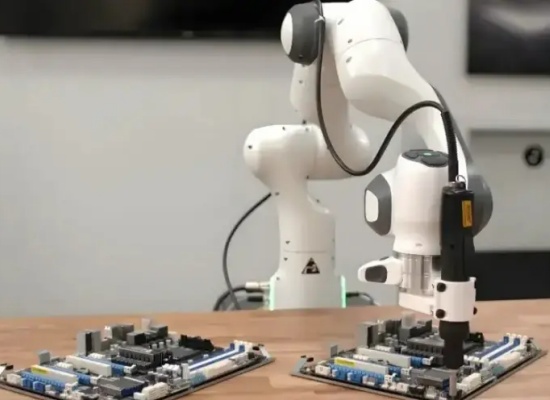
FOUR MAJOR CHARACTERISTICS
Torque sensors distributed across all 7 axes
Installation and maintenance completed in no time
Flowchart-based modular programming
Maximized return on market investment
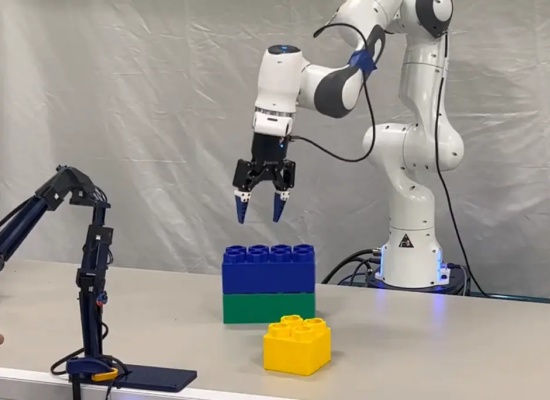
Technical Support
DESK: Its ease of use and minimal programming time make Desk a suitable interface for rapid prototyping, simple human-robot interaction research and demonstrations.
RIDE: It enables researchers to fully integrate the Franka Emika system into experimental setups and leverage its integrated high-performance controller. It is also an excellent tool for teaching introductory robotics.
FCI: FCI bypasses the robot's internal control, allowing researchers to run their own control algorithms at 1 kHz on an external real-time PC. It is the ideal interface for exploring low-level planning and control schemes.
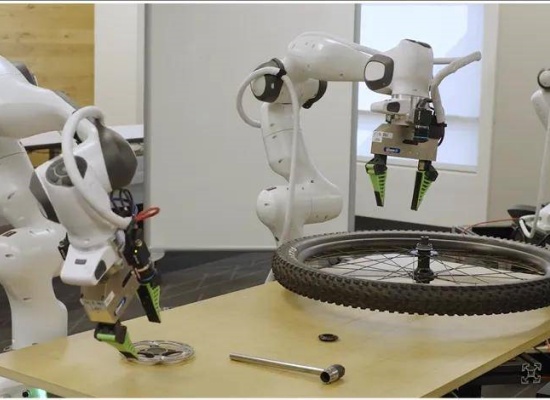
ADVANTAGE
The force-sensitive and agile Arm features 7 DOF with torque sensors at each joint, industrial-grade repeatability of +/-0.1 mm, and negligible path deviation even at high speeds.
The Franka Research 3 robot system includes the Arm and its control.
It provides a payload of 3 kg, a reach of 855 mm and a workspace coverage of 94.5%.
Q: What safety issues should be noted when using a Franka robot?
1. During operation, the operator must not leave the site, so that unexpected situations can be handled promptly and greater losses can be avoided.
2. While the robot is working, operators should check the robot cables to prevent them from winding around the robot; do not place accessories, tools or other items in the control cabinet.
Q: What safety issues should be noted when using a Franka robot?
3. When a workpiece is held by pneumatic grippers, electromagnetic or similar mechanisms, use a fail-safe system to ensure the workpiece is not ejected if the driving force is suddenly cut off.
4. When the robot stops, do not assume it has finished its work - it may be waiting for an input signal to continue moving.
Product parameters
Parameter | Value / Description |
Arm | |
Degrees of freedom | 7 |
Payload | 3 kg |
Maximum reach | 855 mm |
Force/torque sensing | Link-side torque sensor in all 7 axes |
Joint position limits | A1: -166/166°; A2: -105/105°; A3: -166/166°; A4: -176/-7°; A5: -165/165°; A6: 25/265°; A7: -175/175° |
Joint torque limits | A1–A4: ±87 Nm; A5–A7: ±12 Nm |
End-effector mechanical interface | DIN ISO 9409-1-A50 |
Installation position | Upright |
Weight | ~17.8 kg |
Protection rating | IP40 |
Ambient temperature | +5 °C to +45 °C |
Air humidity | 20%–80%, non-condensing |
Interfaces | Ethernet (TCP/IP) for programming and management via Desk; safety-rated input for external enabling device; safety-rated input for emergency stop; 2 configurable safety-rated inputs (for emergency stop devices, safeguards or other protective devices, OSSD devices connectable via external OSSD converter); control connector; end-effector connector |
Control | |
Controller size (19") | 355 × 483 × 89 mm (D × W × H) |
Supply voltage | 100–240 VAC |
Mains frequency | 50–60 Hz |
Power consumption | ~80 W |
Active power factor correction (PFC) | Yes |
Weight | ~7 kg |
Protection rating | IP20 |
Ambient temperature | +5 °C to +45 °C |
Air humidity | 20%–80%, non-condensing |
Permitted mounting orientation | Horizontal |
Interfaces | Ethernet (TCP/IP) with 1 kHz Franka Control Interface (FCI); IEC 60320 C14 power connector (V-Lock); arm connector |
Performance – Motion | |
Joint velocity limits | A1–A4: 150°/s; A5–A7: 301°/s (A6: 239°/s in FCI mode) |
Cartesian velocity limits | Up to 2 m/s end-effector (TCP) speed |
Pose repeatability | <±0.1 mm (ISO 9283) |
Performance – Interaction | |
Guiding force | ~2.5 N |
Adjustable translational stiffness | 10–3000 N/m |
Adjustable rotational stiffness | 1–300 Nm/rad |
Monitored signals | Joint position, velocity, torque; Cartesian pose, force |
Add-ons | |
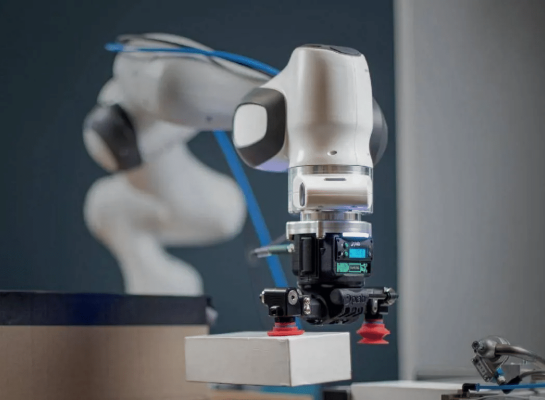
Fully integrated end effectors | 2-finger gripper; vacuum gripper |
Fieldbuses | Modbus/TCP; OPC UA |