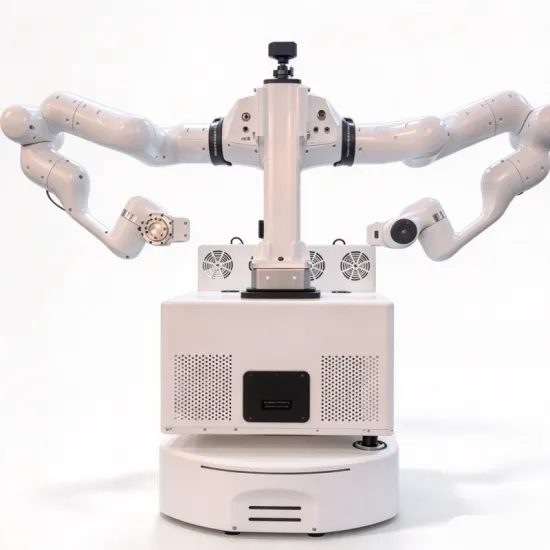
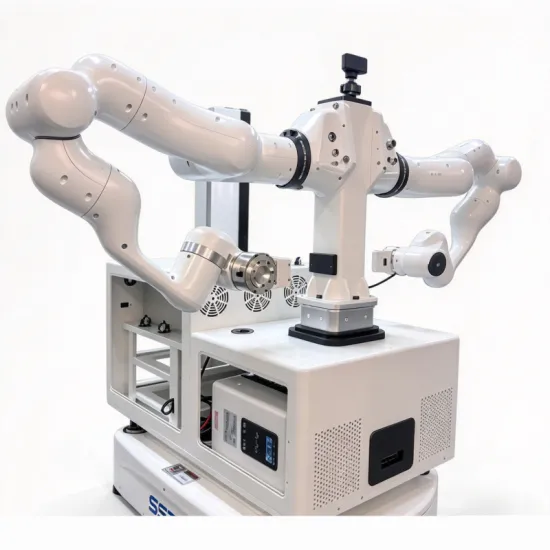


Product Description
FRANKA RESEARCH 3
The reference platform for global AI and robotics research
Franka Research 3 is a world-class force-sensitive robot system that provides researchers with easy-to-use robot features as well as low-level access to robot control and learning capabilities.
Functional Features
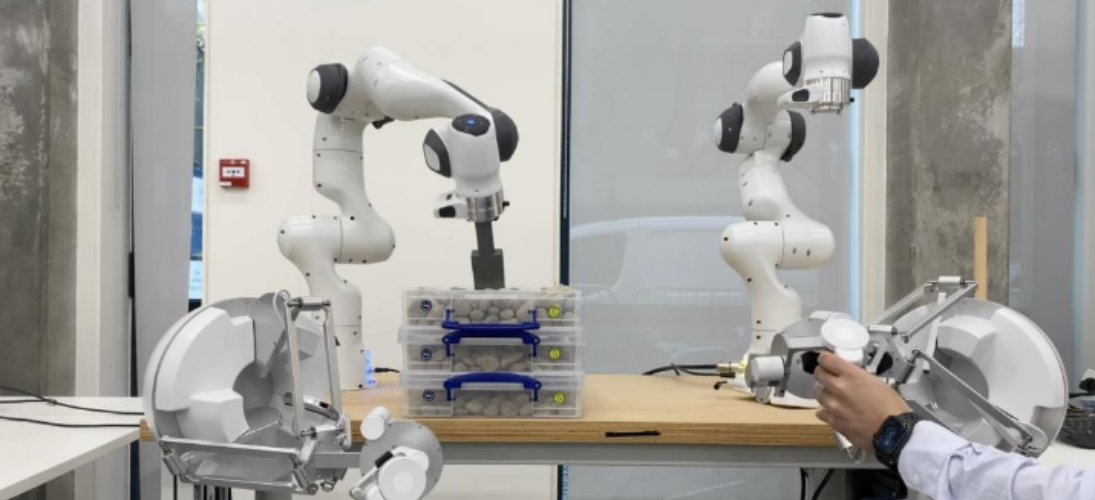
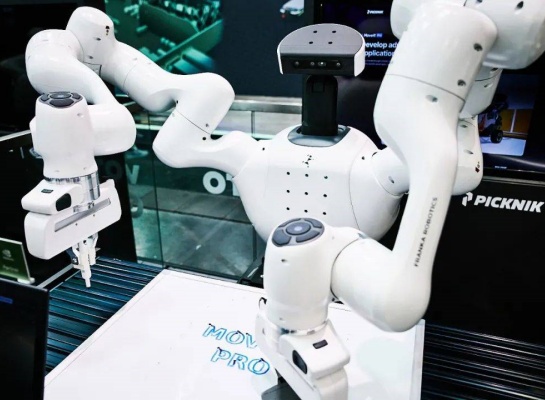
The Franka Research 3 robot system includes the Arm and its control.
The Arm features 7 degrees of freedom with torque sensors at each joint, making it force-sensitive and agile.
It achieves industrial-grade pose repeatability of +/-0.1 mm, with negligible path deviation even at high speeds.
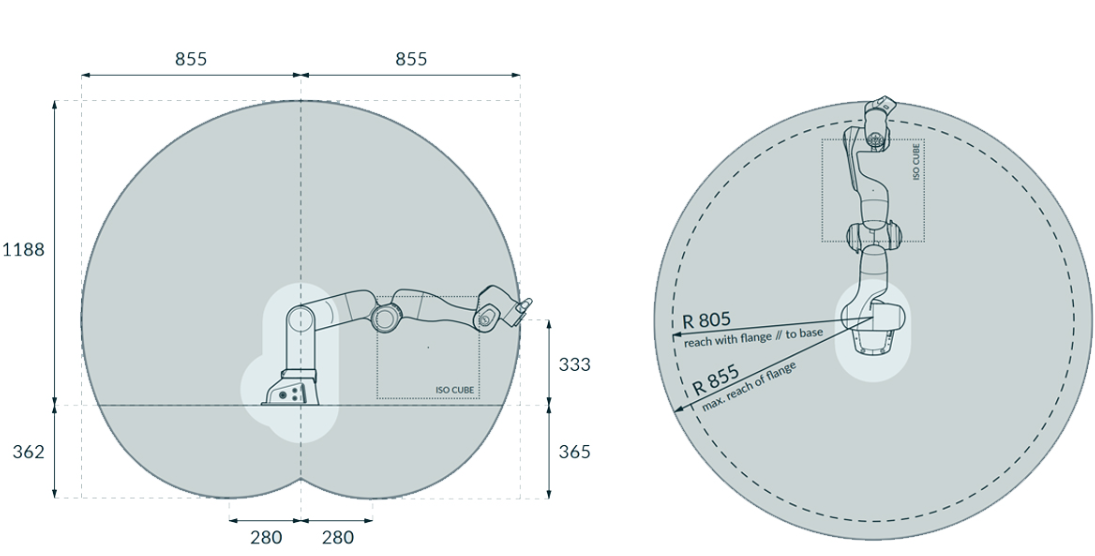
It provides a payload of 3 kg, a reach of 855 mm and a workspace coverage of 94.5%.
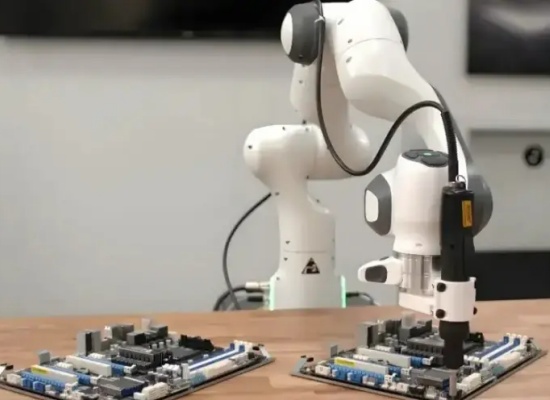
FCI (Franka Control Interface)
FCI is an ideal interface for exploring low-level programming and control schemes.
It provides the robot's current state and supports direct torque control at 1 kHz.
Built on the C++ interface libfranka, it also integrates with the most popular ecosystems ROS, ROS 2 and MATLAB & Simulink.
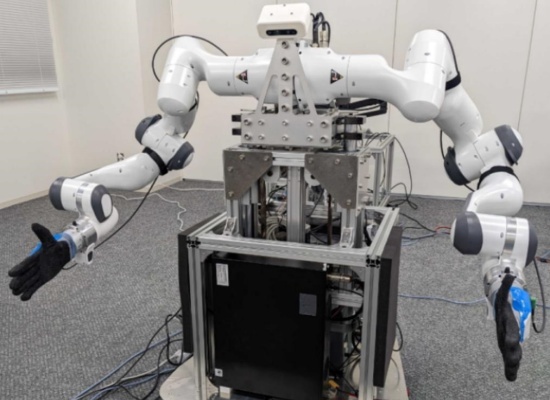
DESK
Desk is a browser based user interface that provides quick robot control options.
On Desk, users can create task behavior sequences, experiment settings, simple human-computer interaction, and quickly create complete tasks by dragging and dropping applications.
It is very suitable for rapid prototyping development in robot research and demonstration.
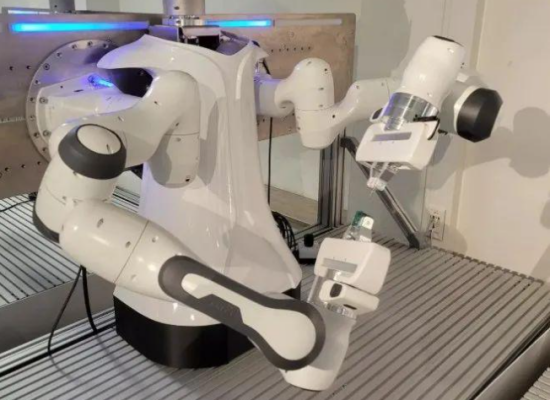
Watchman
Watchman is a browser-based user interface that simplifies complex safety settings, ensuring the safety of the laboratory and its personnel.
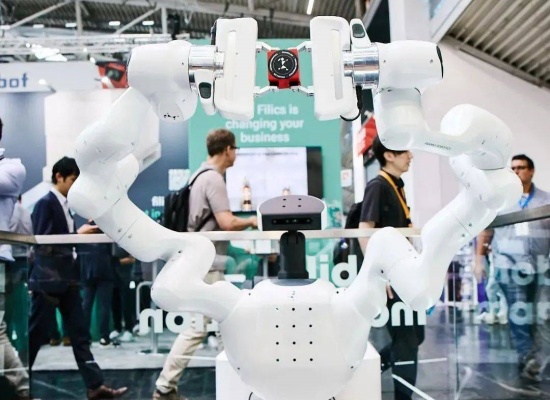
Resources and Community
An open and global research ecosystem that accelerates research outcomes and academic publications through a powerful robot platform.
Franka Research 3 is a reference platform for consolidating existing research, sharing breakthrough findings, collaborating on projects, reproducing research and promoting publications within the community.
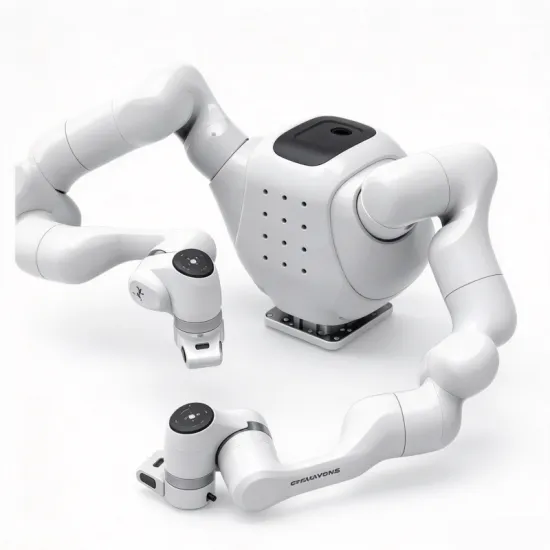
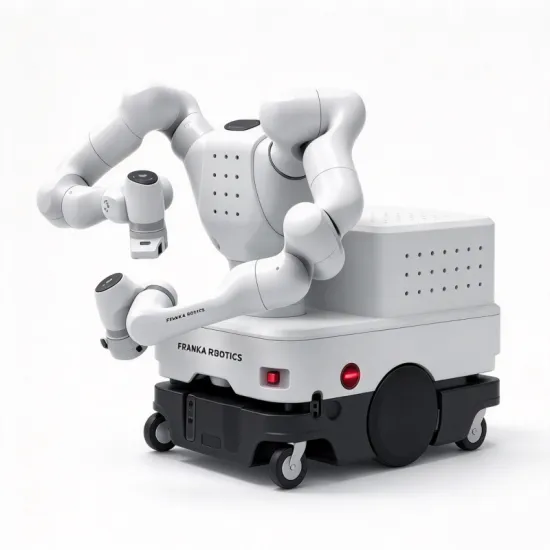
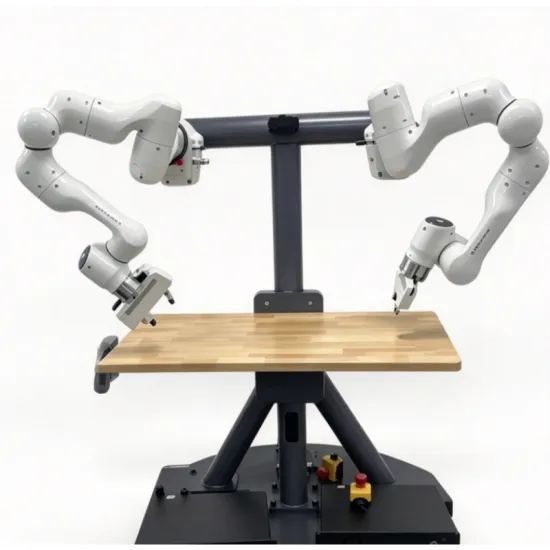
Product Display
End effectors and additional software
Franka Hand
A2 fixture, replaceable clamp head, fully integrated with Franka Research3 software, plug and play.
Application package for FR3
Selected applications and modular components can be combined into App Workflow to quickly build robot behavior prototypes.
RIDE
A development interface used for writing custom applications, connecting third-party hardware, and external resources. It is an ideal tool for customizing and expanding system functions.
Dimensional Drawin
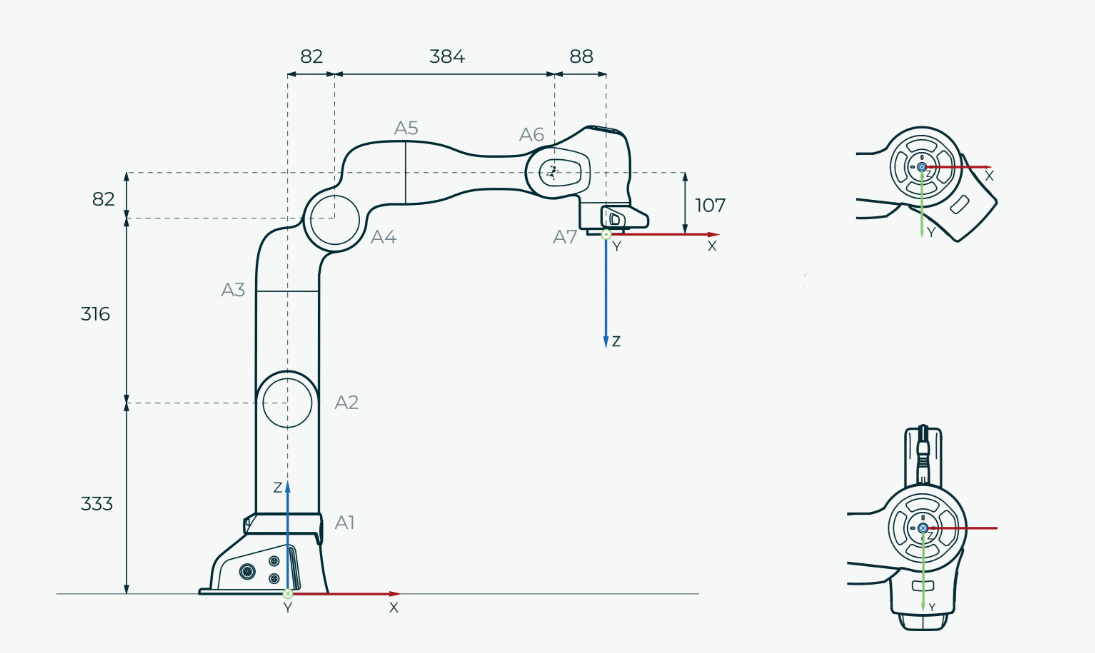
(Left) Axis name and connecting rod distance [mm]
(Top right) 7th axis alignment (without end effector)
(Bottom right) 7th axis alignment (with Franka Hand)
Product parameters
Parameter | Value / Description |
Arm | |
Degrees of freedom | 7 |
Payload | 3 kg |
Maximum reach | 855 mm |
Force/torque sensing | Link-side torque sensor in all 7 axes |
Joint position limits | A1, A3: -166/166°; A2: -105/105°; A4: -176/-7°; A5: -165/165°; A6: 25/265°; A7: -175/175° |
Mounting flange | DIN ISO 9409-1-A50 |
Installation position | Upright |
Weight | ~17.8 kg |
Protection rating | IP40 |
Ambient temperature | +5 °C to +45 °C |
Air humidity | 20-80%, non-condensing |
Interfaces | Ethernet (TCP/IP) for intuitive visual programming with Desk; safety-rated input for external enabling device; 2 configurable safety-rated inputs for emergency stop devices, safeguards or other protective devices (OSSD devices connectable via external OSSD converter); hardware prepared for 2x DI & 2x DO (24V, isolated, EN 61131-2 type 3 characteristics, 100 Hz sampling rate); control connector; end-effector connector |
User interfaces at the Arm's Pilot Grip | Integrated safety-rated guiding enabling switch; guiding button; guiding mode selector |
User interfaces at the Arm's Pilot Disc | Status light; Pilot mode selector; arrow keys, teach, confirm, delete |
Control | |
Controller size (19") | 355 × 483 × 89 mm (L × W × H) |
Supply voltage | 100-240 VAC |
Mains frequency | 50-60 Hz |
Power consumption | ~80 W |
Active power factor correction (PFC) | Yes |
Weight | ~7 kg |
Protection rating | IP20 |
Ambient temperature | +5 °C to +45 °C |
Air humidity | 20-80%, non-condensing |
Permitted mounting orientation | Horizontal |
Interfaces | Ethernet (TCP/IP) for internet and/or shop-floor connection; power connector IEC 60320 C14 (V-Lock); arm connector |
Exclusive Research Interface | |
Research interface | 1 kHz Franka Control Interface (FCI) |
Performance - Motion | |
Joint velocity limits | A1-A4: 150°/s; A5-A7: 301°/s (A6: 239°/s in FCI mode) |
Cartesian velocity limits | Up to 2 m/s end-effector speed |
Pose repeatability | <±0.1 mm (ISO 9283) |
Performance - Interaction | |
Guiding force | ~2.5 N |
Adjustable translational stiffness | 10-3000 N/m |
Adjustable rotational stiffness | 1-300 Nm/rad |
Monitored signals | Joint position, velocity, torque; Cartesian position, force |
Add-ons | |
Fully integrated end effectors | 2-finger gripper; vacuum gripper |
Fieldbuses | Modbus/TCP; OPC UA |