

Product Description
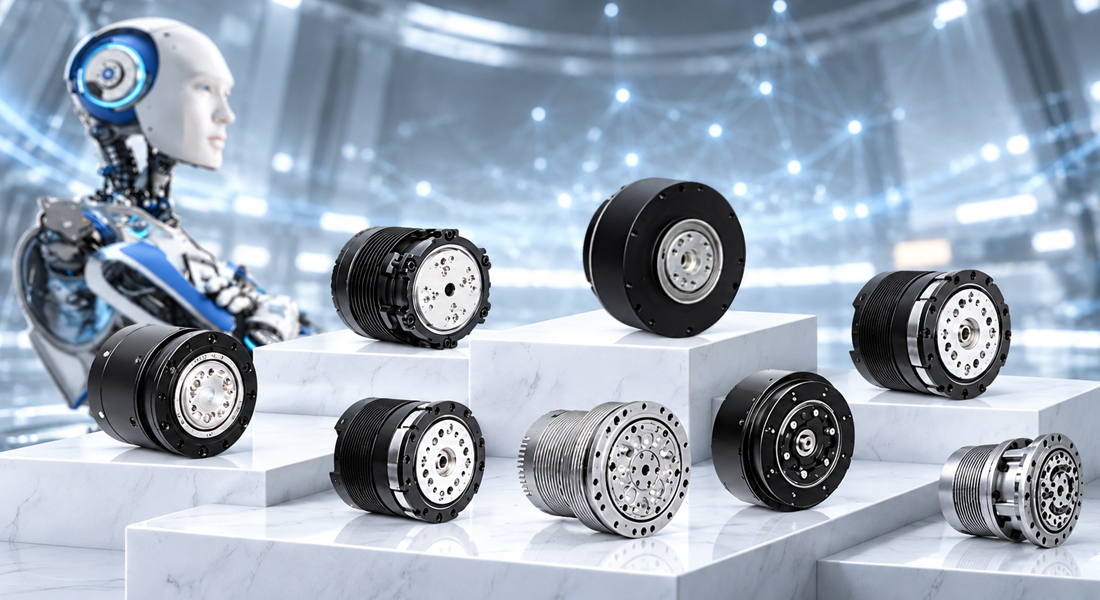
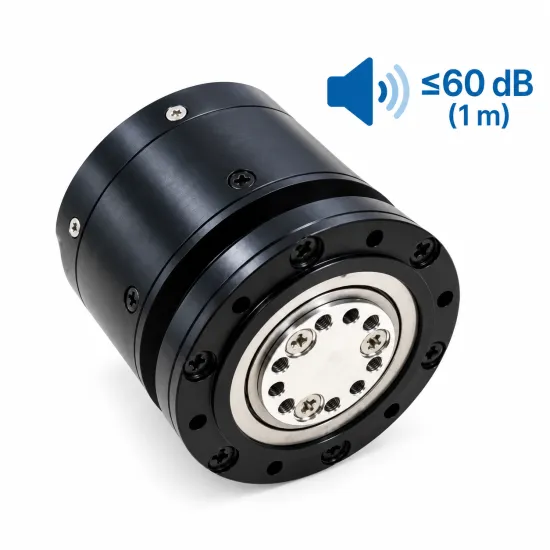
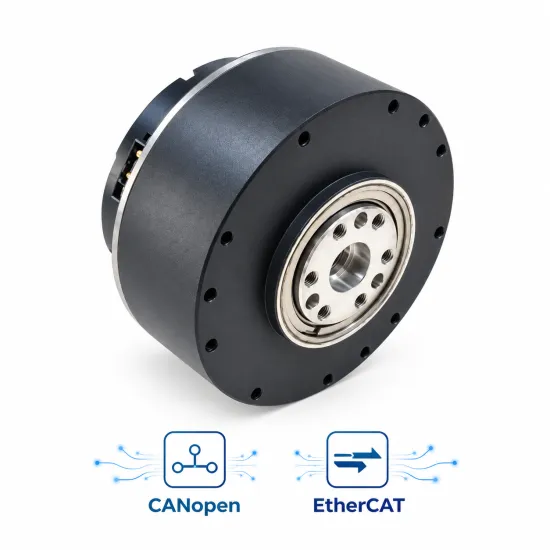
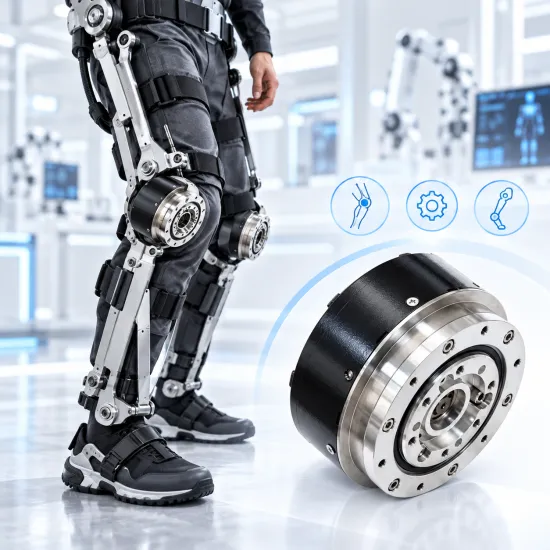
The planetary joint actuator is a core transmission component designed for embodied intelligence and humanoid robots. Featuring an integrated design that combines drive, transmission, and control, it balances precise motion control with a compact and lightweight structure, meeting the requirements of robotic joints for flexible movement, rapid response, and space-efficient integration.
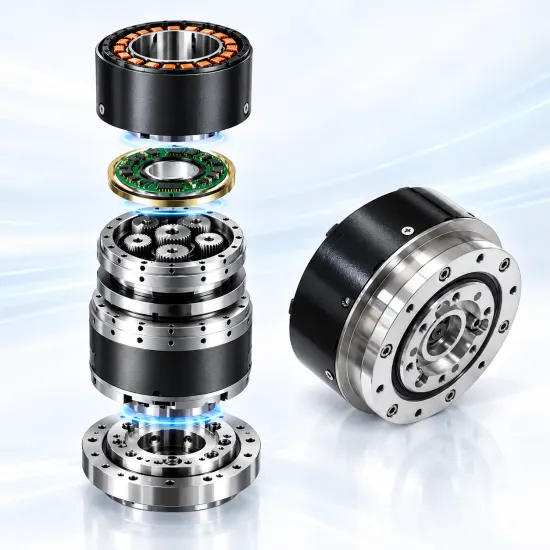
The actuator adopts an optimized quasi-direct-drive planetary transmission topology and integrates a frameless motor with a high-precision encoder. Combined with precision gear manufacturing and oil-free or low-oil lubrication technologies, it enhances transmission performance, operational reliability, and service life.
Product parameters
HPA4536
|
HPA5817
|
HPA8025-088
|
HPA8025-140
|
HPA8008
|
HPA9314NW
|
HPA10225
|
HPA11336
| |
Ratio i | 36 | 17 | 25 | 25 | 8 | 14 | 25 | 36 |
Service life (h) | ≥20000 | ≥20000 | ≥20000 | ≥20000 | ≥20000 | ≥20000 | ≥20000 | ≥20000 |
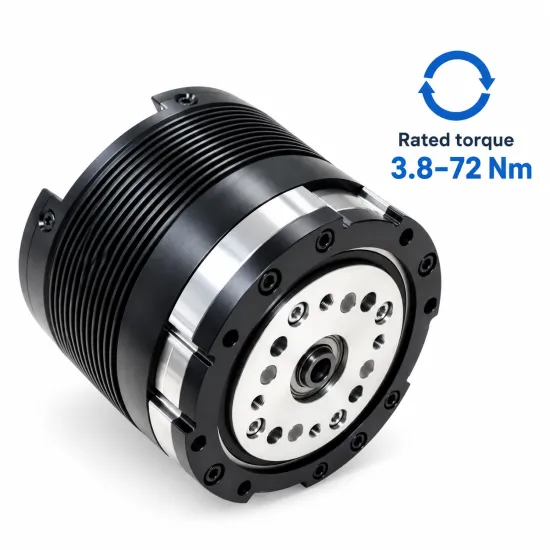
Rated torque (N·m) | 3.8 | 30 | 80 | 93 | 10 | 60 | 75 | 72 |
Maximum torque ((N·m) | 7.6 | 60 | 160 | 186 | 20 | 120 | 300 | 300 |
Max. radial load (N) | 1490 | 2050 | 5100 | 5100 | 1500 | 5100 | 2810 | 3050 |
Max. axial load (N) | 1490 | 2050 | 5100 | 5100 | 200 | 5800 | 2810 | 3050 |
Rated voltage (V) | DC48 | DC48 | DC48 | DC48 | DC36 | DC48 | DC48 | DC48 |
Protection grade | IP54 | IP54 | IP54 | IP54 | IP54 | IP54 | IP54 | IP54 |
Return clearance (arcmin) | 15 | 15 | 15 | 15 | 20 | 20 | 15 | 15 |
Noise (dB) | ≤60 (1m) | ≤60 (1m) | ≤60 (1m) | ≤60 (1m) | ≤65 (1m) | ≤60 (1m) | ≤60 (1m) | ≤60 (1m) |
Recommended input speed (rpm) | 1500 | 1000 | 1500 | 1000 | 1000 | 1000 | 3000 | 4500 |
Maximum input speed (rpm) | 3000 | 3000 | 3000 | 3000 | 3000 | 3000 | 4100 | 5900 |
Environment temperature (℃) | -20~45 | -20~45 | -20~45 | -20~45 | -20~45 | -20~45 | -20~45 | -20~45 |
Weight (g) | 230 | 460 | 1030 | 1100 | 416 | 600 | 2200 | 2300 |
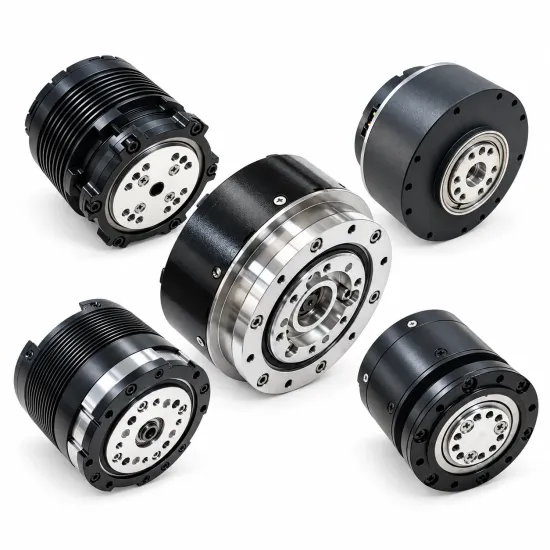
Product Display
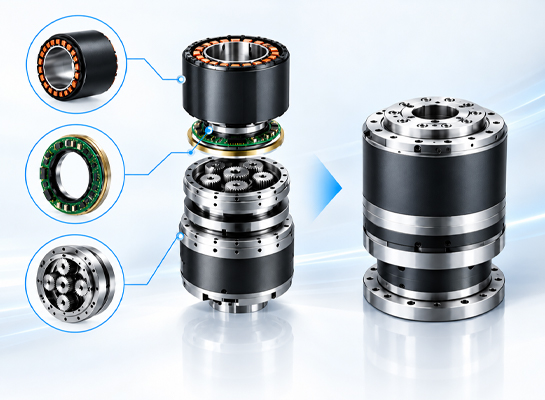
Integrated Design
The actuator integrates the frameless motor, high-precision encoder, and planetary transmission system into a unified design. This helps reduce the overall size and weight of the system while simplifying joint construction and system integration.
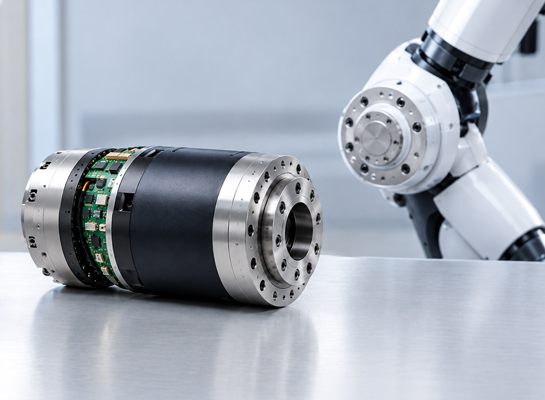
High-Precision Motion Control
Equipped with a high-precision encoder and precision planetary transmission system, the actuator enables accurate control of joint position, speed, and motion. It improves joint flexibility, control precision, and response speed.
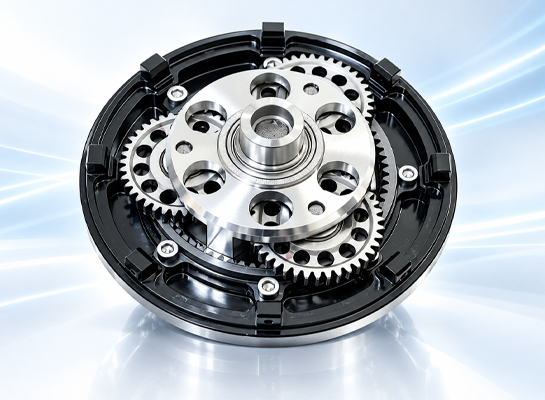
Lightweight Structure and High Torque Density
The actuator adopts an optimized quasi-direct-drive planetary transmission topology. Through structural optimization and the use of high-strength materials, it reduces weight and volume while increasing torque density to meet the requirements of robotic joints for lightweight construction and power output.
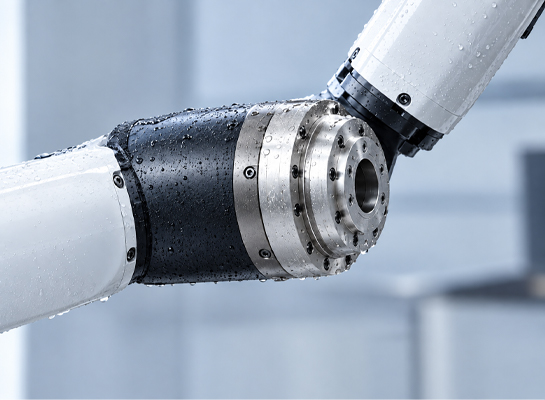
Precision Manufacturing and Long Service Life
The gears are manufactured using low-carbon alloy structural steel sourced from a leading steel mill, combined with carburizing, quenching, and precision machining processes. The external gear accuracy is within Chinese National Standard Grade 5. Nano-coating technology enables oil-free or low-oil lubrication, supporting long service life and maintenance-free operation.
Application Cases
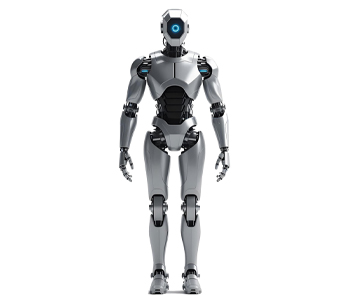
Humanoid Robots
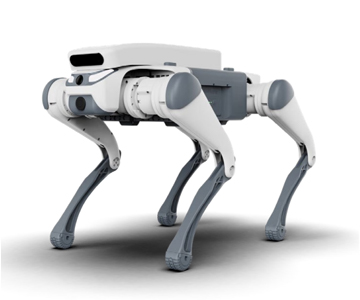
Quadruped Robots
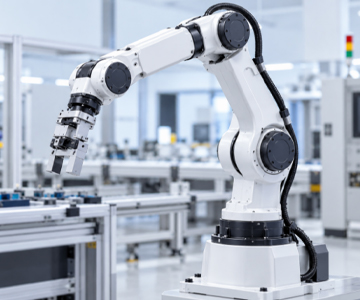
Robotic Arms