

Product Description
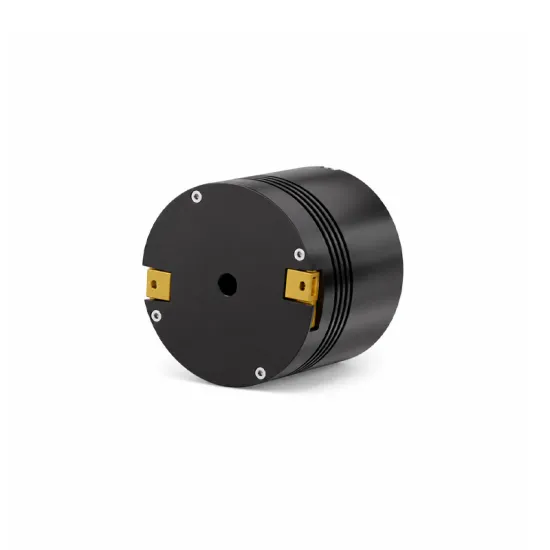
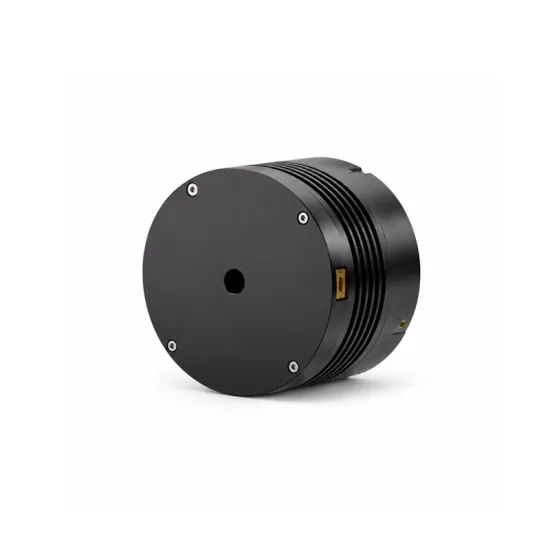
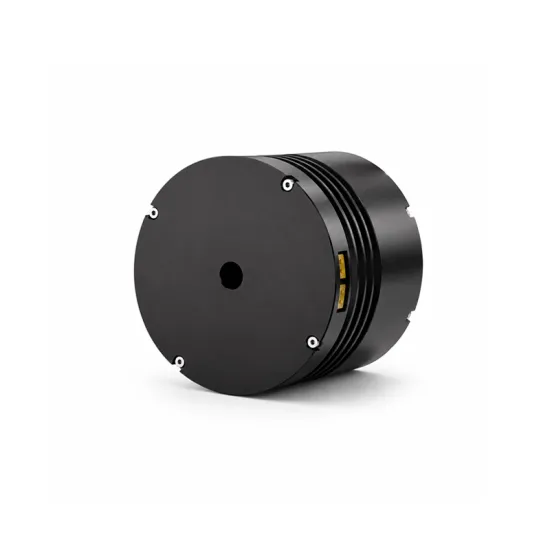
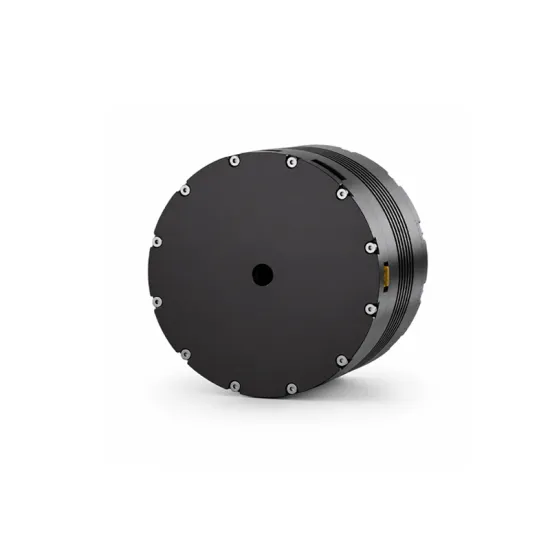
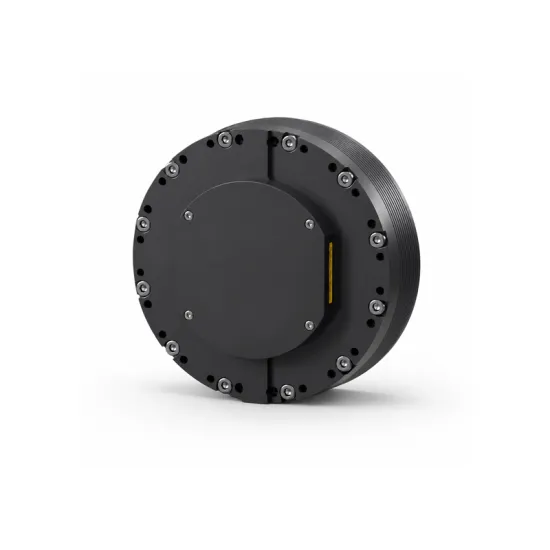
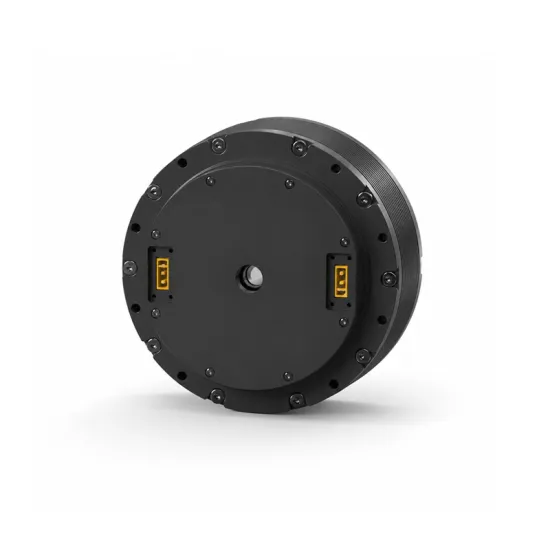
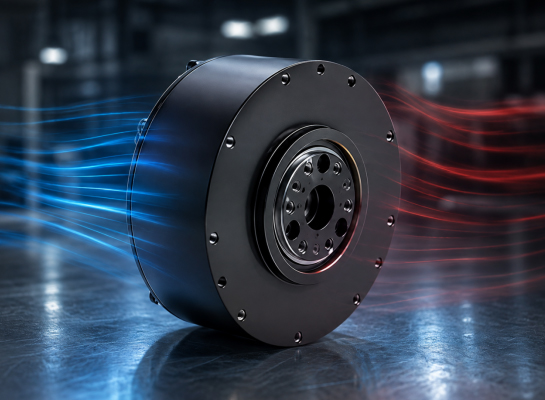
Planetary joint actuator is designed for humanoid robots, quadruped robots, collaborative robots, and other robotic systems. The motor, gearbox, dual encoders, and drive are highly integrated to reduce external connections and simplify joint design. Multiple torque, reduction ratio, and size options are available for different robotic joint requirements. Low backdrivability supports responsive motion and force control in dynamic robotic applications.
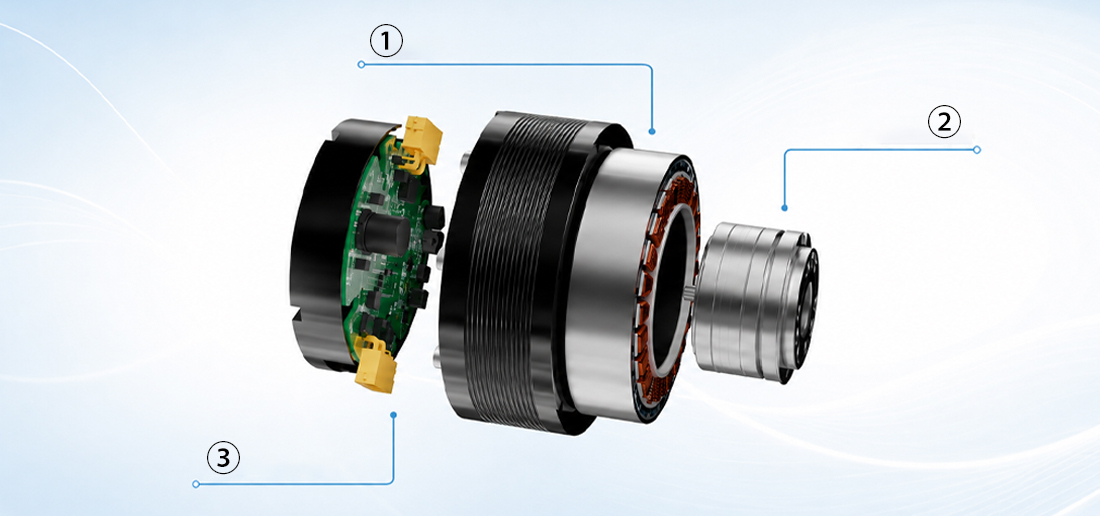
①Frameless Motor ②Gearbox (Planetary Gearbox) ③Drive + Dual Encoders
Product parameters
Specification | G1236-C1 | G2025-C1 | G3018-C1 | G5012-C1 | G10024-C1 | G0608-C1 | G0108-C1 | |
Performance Parameters | Reduction Ratio | 36 | 25 | 18 | 12 | 24 | 7.75 | 7.9 |
Rated Voltage(V) | 48 | 48 | 48 | 48 | 48 | 48 | 24 | |
Rated Current(A) | 6 | 9 | 12 | 24 | 37 | 7 | 2 | |
Rated Speed(RPM) | 78 | 131 | 142 | 130 | 102 | 360 | 50 | |
Rated Torque(Nm) | 12 | 20 | 30 | 50 | 100 | 6 | 0.6 | |
Peak Speed(RPM) | 85 | 135 | 150 | 150 | 150 | 410 | 100 | |
Peak Torque(Nm) | 36 | 60 | 94 | 150 | 360 | 17 | 1.8 | |
Encoder | Dual Encoder(17bit/17bit) | |||||||
Dimensions
| Weight(kg) | 0.38 | 0.6 | 0.83 | 1.4 | 2.2 | 0.4 | 0.19 |
Dimensions (Outer Diameter × Length)(mm) | Φ56*60 | Φ88*59.5 | Φ105*47.5 | Φ124*61.5 | Φ124*85 | 78.5*45.5 | Φ43*32.5 | |
Communication Method | Ethercat/can | |||||||
Product Display
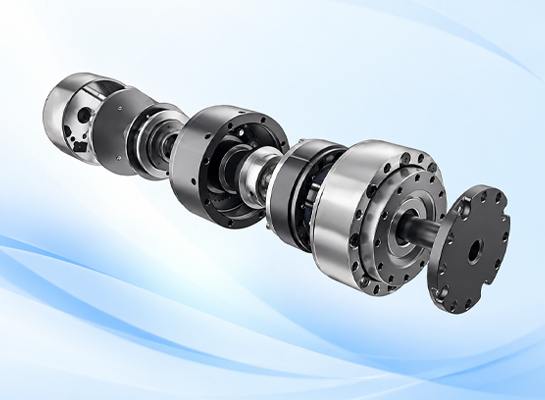
Highly Integrated Design
Planetary joint actuator integrates the motor, gearbox, dual encoders, and drive into a compact unit, reducing external connections and installation space while simplifying robotic joint integration.
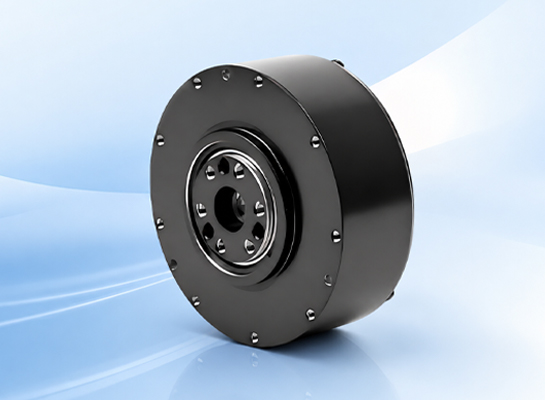
Low Backdrivability for Force Control
Planetary joint actuator features low backdrivability through optimized transmission design, making it suitable for force control, dynamic motion, and human-robot interaction applications.
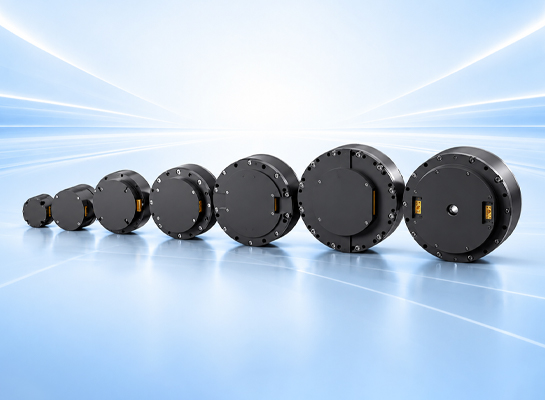
Multiple Torque and Size Options
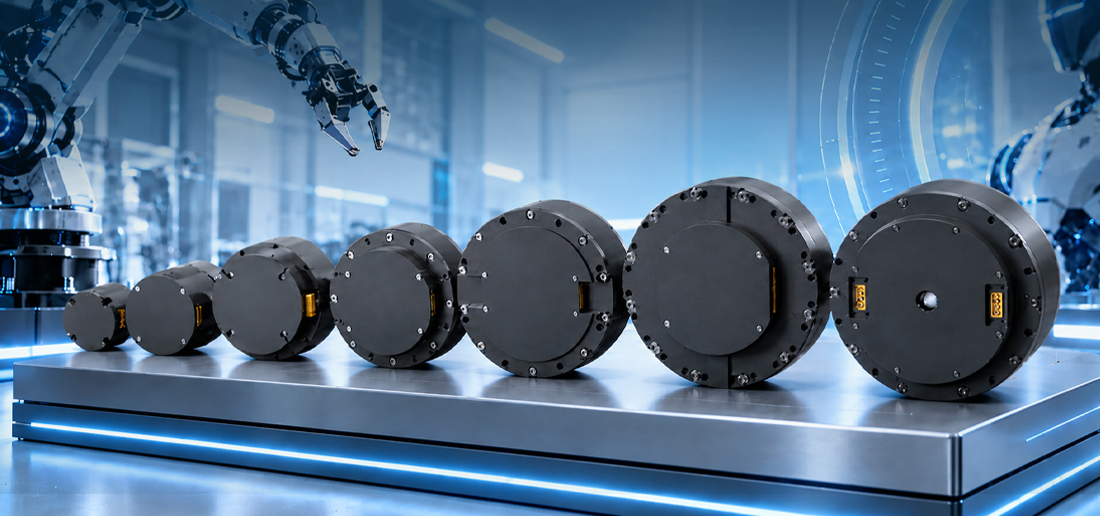
Planetary joint actuator offers multiple size, reduction ratio, and torque configurations, with rated torque from 0.6 to 100 N·m and peak torque from 1.8 to 360 N·m for different robotic joint requirements.
Low-Temperature and Efficient Operation
Planetary joint actuator adopts low-loss drive technology, optimized thermal management, and optimized motor magnetic circuit design to reduce drive losses. Drive losses are reduced by more than 40% and temperature rise by 10%, helping reduce thermal load during continuous operation and improve the operating stability of robotic joints.
Application Cases
Humanoid Robots
Medical Collaborative Robotic Arms
Quadruped Robots