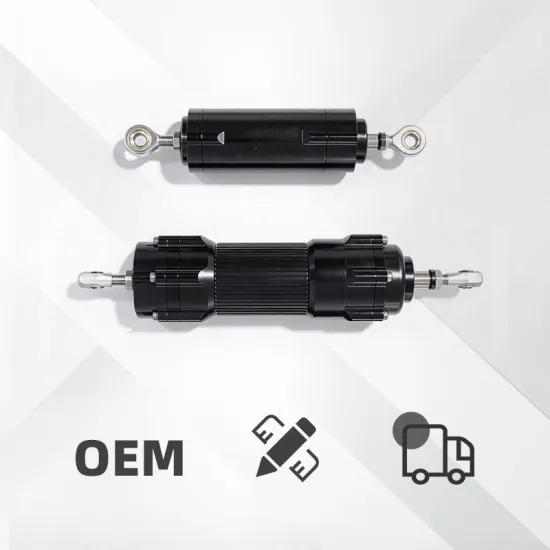
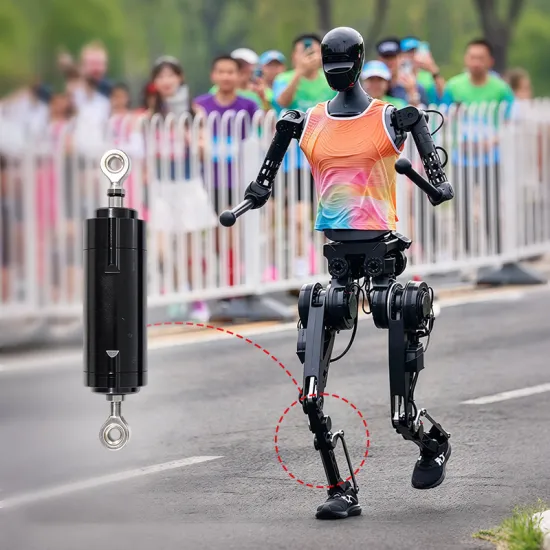


Product Description
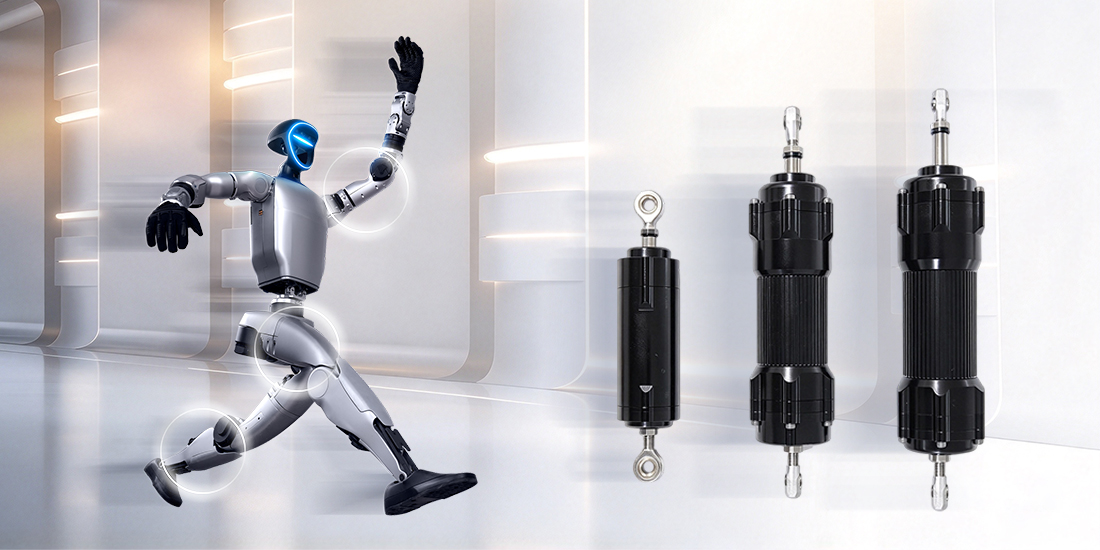
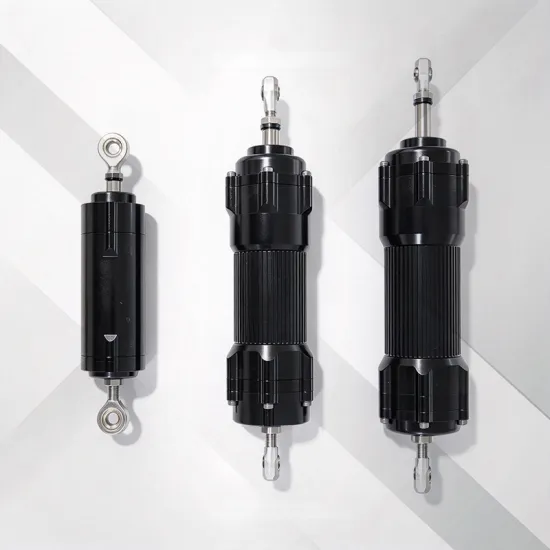
The servo linear joint module is driven by a motor. The power generated by the drive unit is transmitted to the joint through a planetary roller screw to achieve the intended motion. Meanwhile, sensors monitor the joint's motion status in real time and feed the information back to the control system to ensure accurate joint movement.
The module is designed for humanoid robots and other applications. A variety of thrust specifications are available, and dimensions can be customized according to actual requirements.
Product parameters
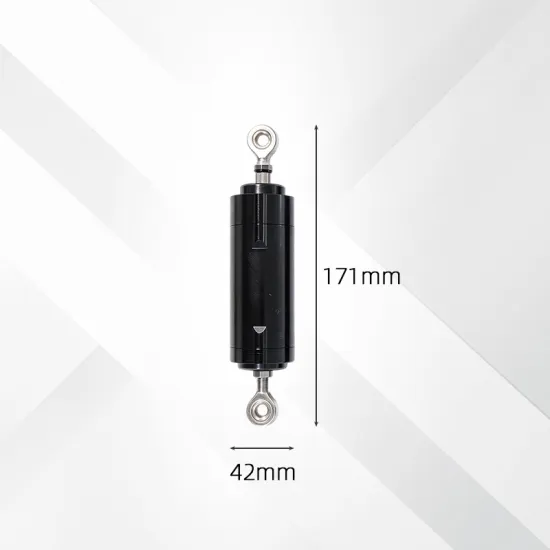
Maximum thrust | Maximum speed | Itinerary | C1Size | D1Size | Rated voltage | Leads | Hoiding brakes | Customized |
500N | 200mm/s | 50mm | 42mm | 171mm | DC48V+10% | 3mm | Not included | Specifications are for reference only. Dimensions are customizable, subject to the mutually confirmed drawing.
|
4000N | 300mm/s | 90mm | 52mm | 238mm | DC48V+10% | 3mm | Not included | |
8000N | 300mm/s | 90mm | 62mm | 262mm | DC48V+10% | 3mm | Not included | |
13000N | 300mm/s | 90mm | 77mm | 320mm | DC48V+10% | 3mm | Not included |
Product Display
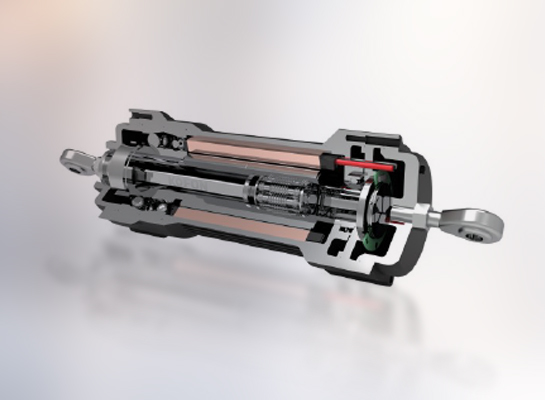
Integrated Design
Combining a planetary roller screw with a high-performance motor, the module features an integrated design developed for humanoid robot applications. It supports extensive customization, facilitates system integration and assembly, and helps shorten the development cycle of humanoid robot products.
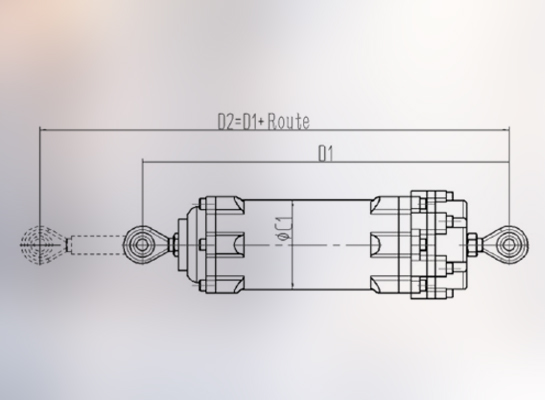
Efficient Linear Motion
Using planetary roller screw drive technology, the module precisely converts the rotary motion of the servo motor into linear motion, achieving micron-level positioning accuracy and making it ideal for high-precision repetitive positioning applications.
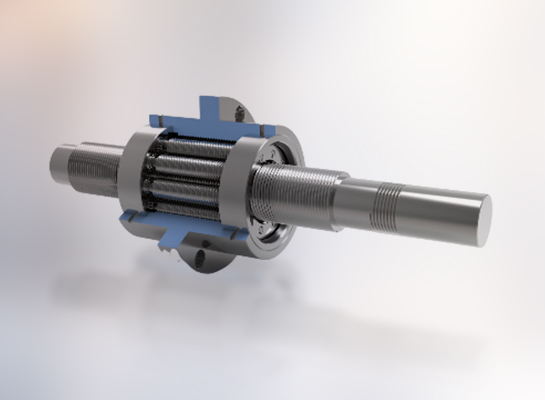
High-Precision Positioning and Dynamic Control
Designed for high-precision positioning, the module provides a dynamic motion control solution for humanoid robots. Servo actuation and real-time motion feedback support the motion response and position control requirements of robotic joints.
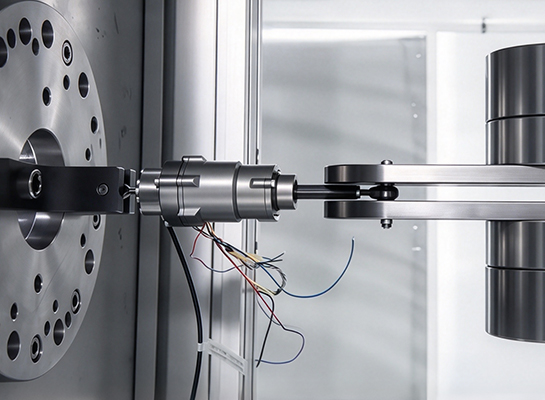
Multiple Communication Protocols and Flexible Customization
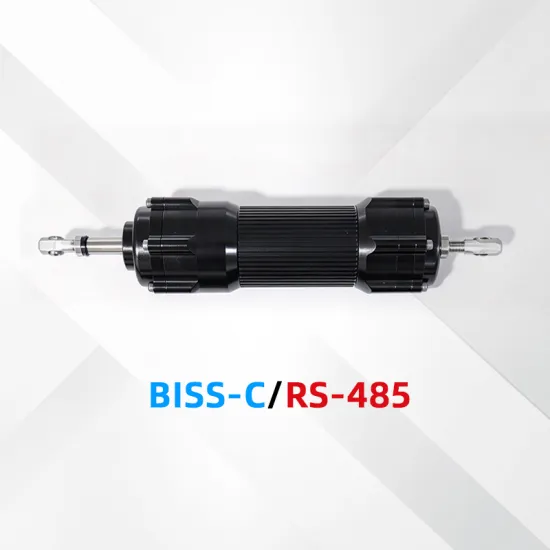
Supporting BiSS-C and RS-485 communication protocols, the module facilitates integration with control systems. Dimensions and related configurations can be customized according to application requirements, making it suitable for robots and automation equipment with different space constraints and motion requirements.
Application Cases
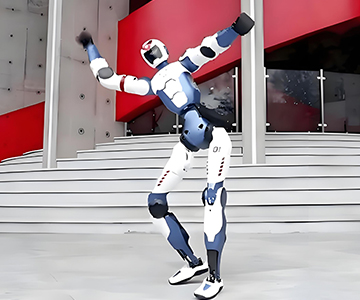
Humanoid Robots
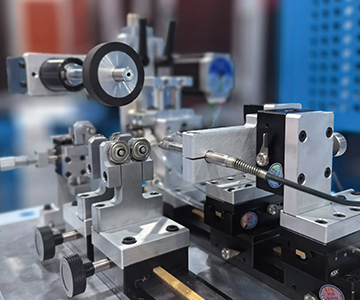
Industrial Automation Equipment
Precision Positioning and Inspection Equipment