


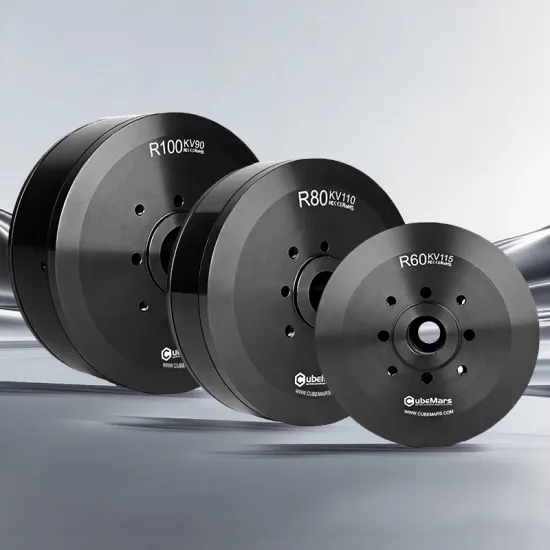


Product Description
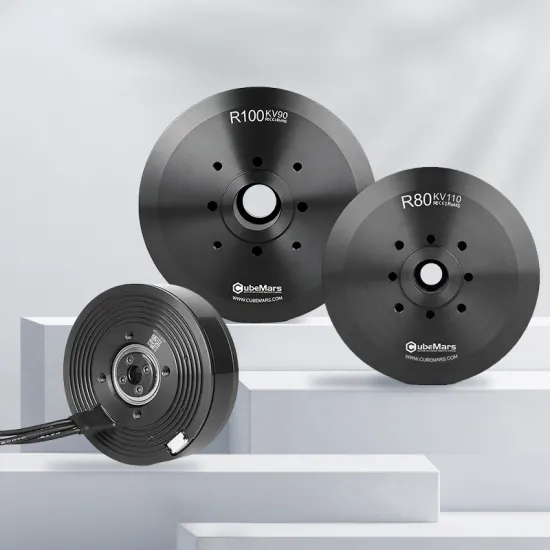
The peak torque of the R series covers 2.3Nm to 11Nm and supports 48V voltage. The built-in Hall sensor enables high-precision contactless position feedback. The advanced heat dissipation structure and plug-and-play wiring design help the automated equipment achieve efficient, reliable and flexible power output.
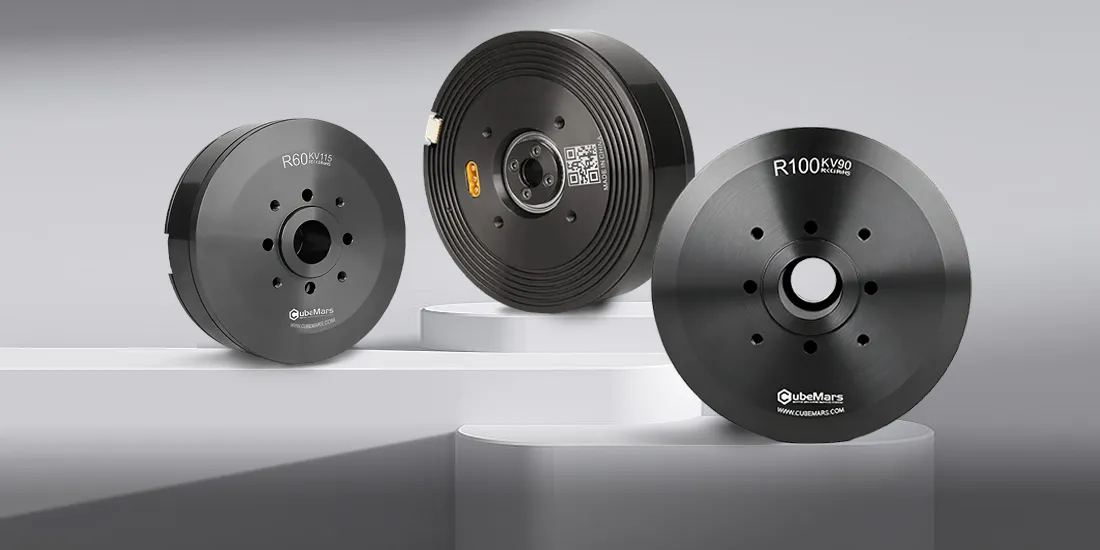
Low cogging torque, low moment of inertia Multiple postures, smooth operation
Electrical angle accuracy is ±10°.
Built-in Hall effect sensors
ensure continuous improvement.
Round-the-clock electromagnetic calculations.
Just for you, your discerning eye.
Whether walking, jumping, running, or anything else, smooth operation is guaranteed!
Functional Features
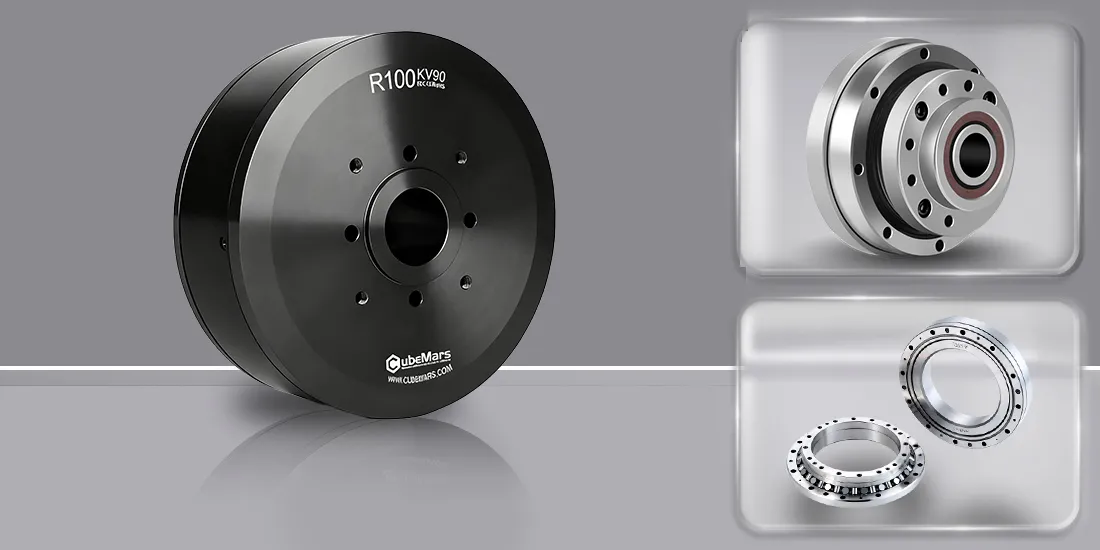
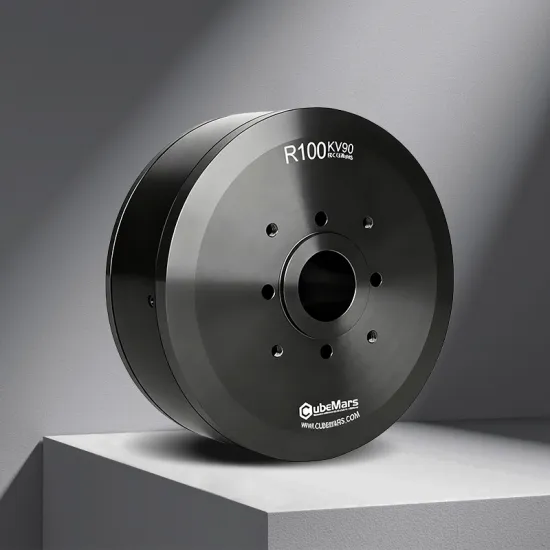
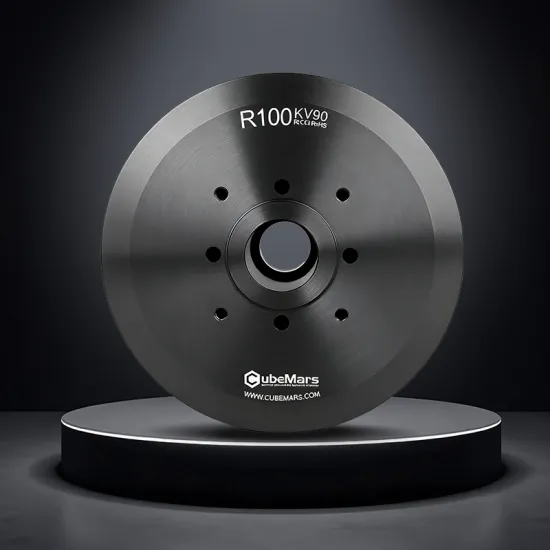
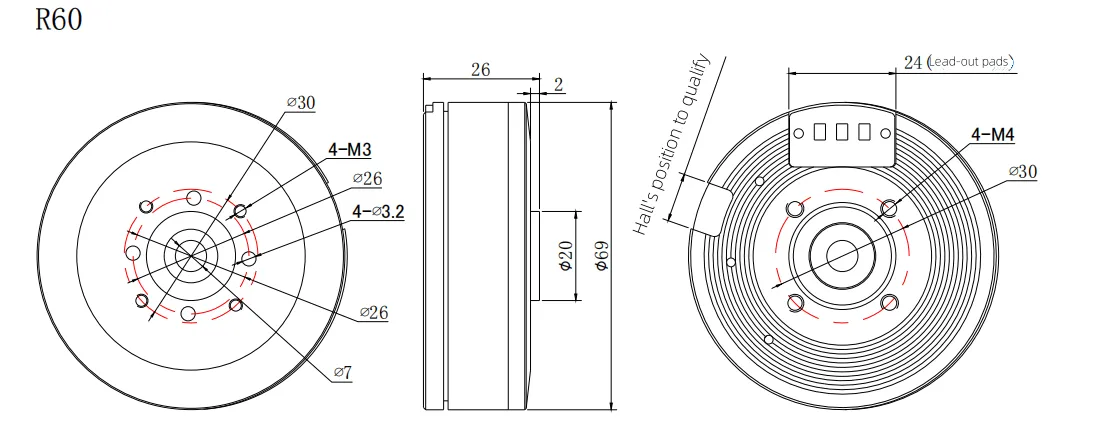
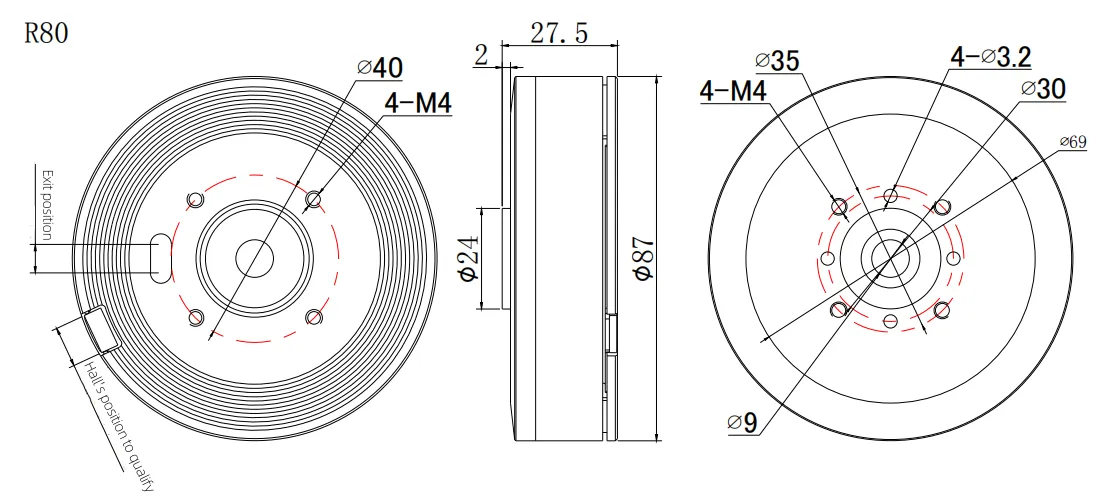
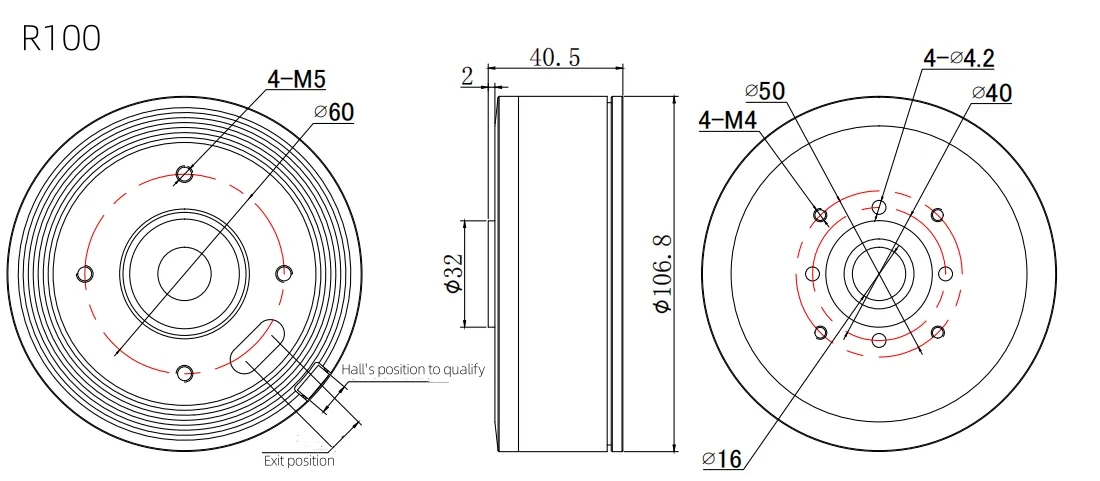
The motor's rotor end cap features multiple mounting holes
to meet diverse customer requirements.
Customers can directly match the corresponding harmonic reducer
or mount other types of reducers via flanges to meet higher torque requirements.
Special heat dissipation design
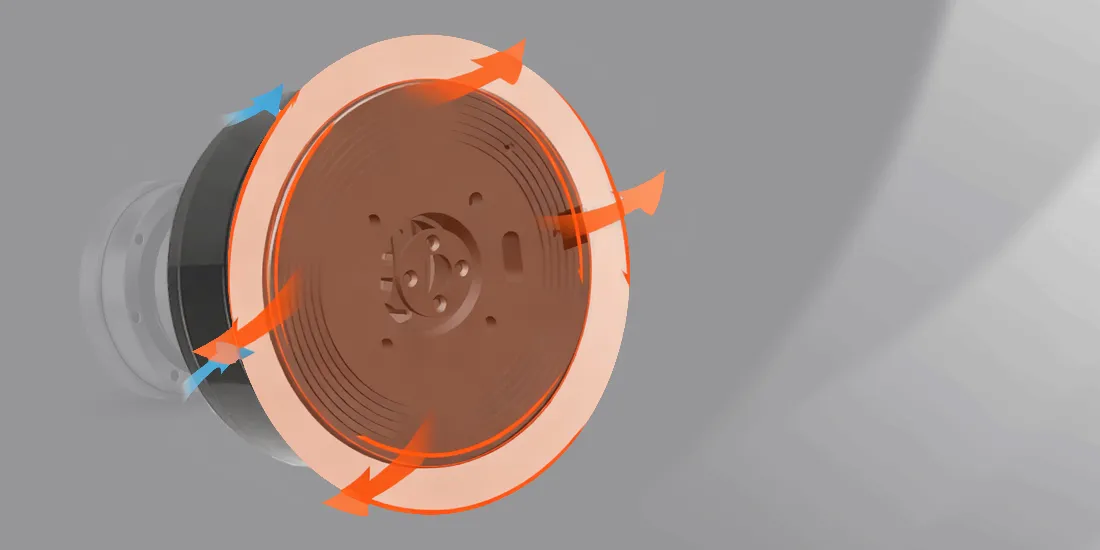
Special heat dissipation design
ensures worry-free operation.
Ultra-thin stator end cover +
high thermal conductivity silicone pad.
While reducing the overall installation height,
it also achieves heat dissipation.
Interface
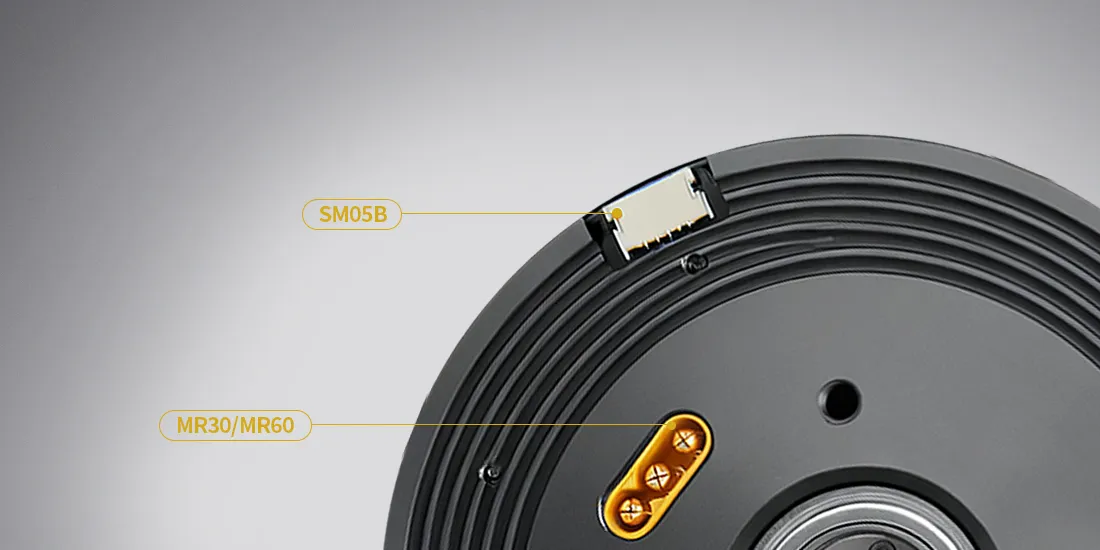
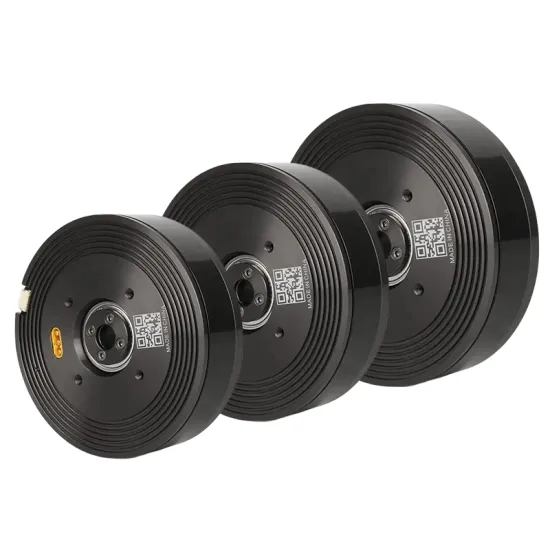
The outlet plug design eliminates the need
for redundant cables and simplifies installation.
Product parameters
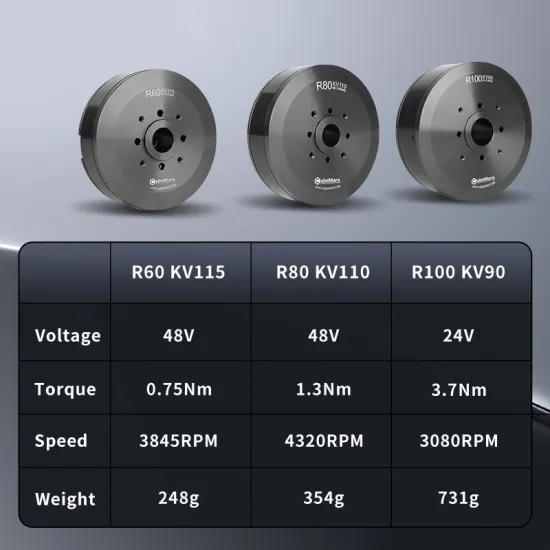
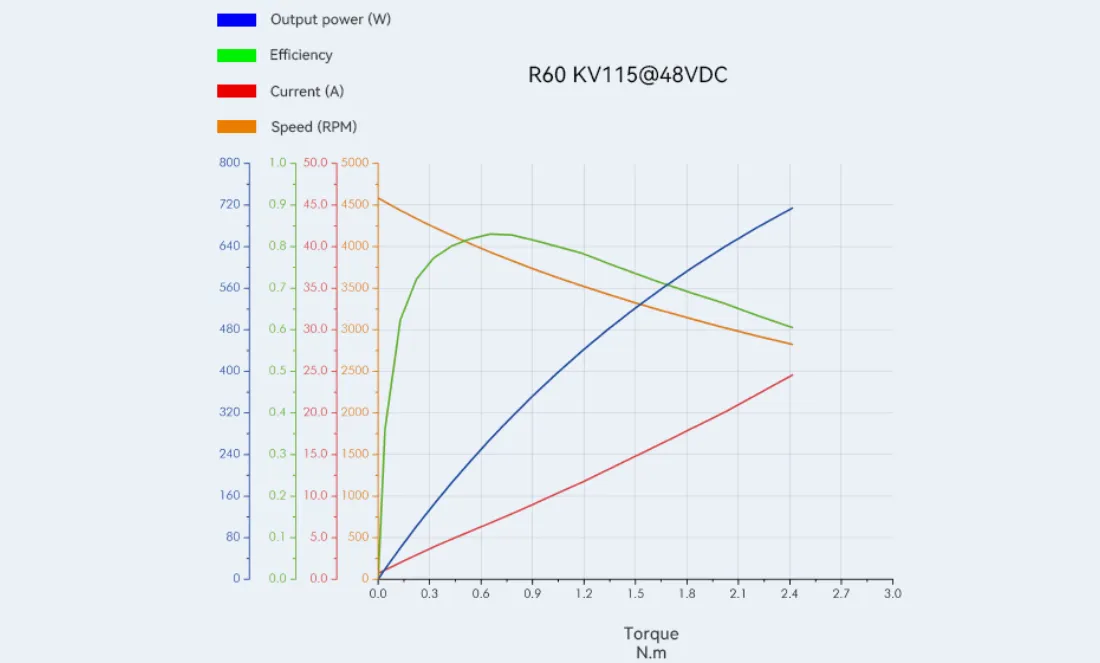
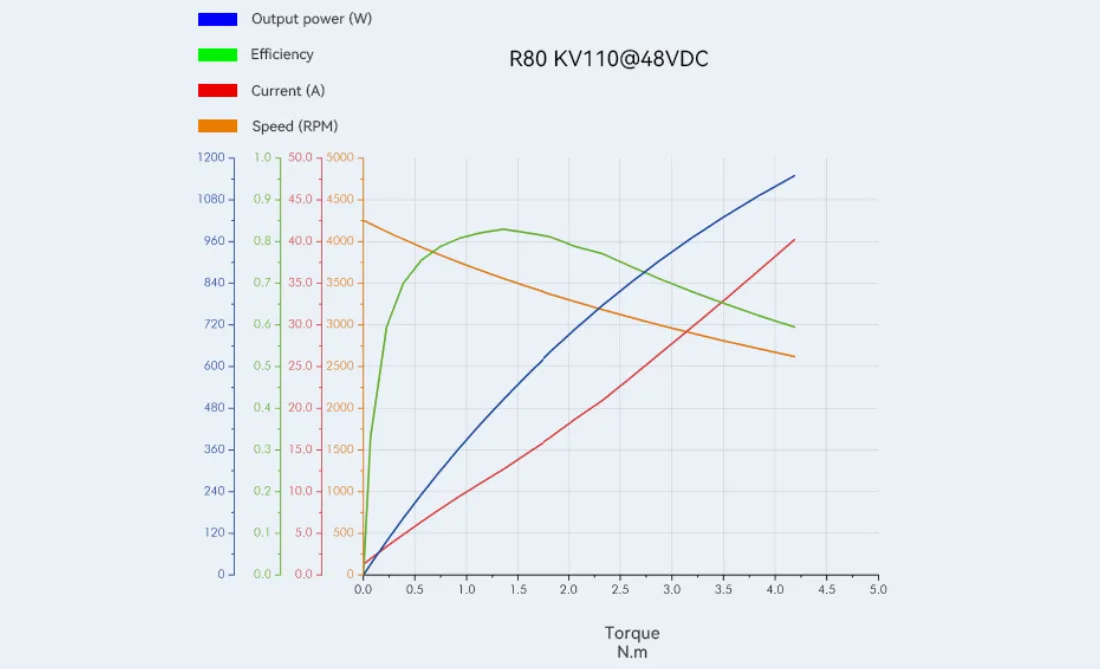
Model | R60 | R80 | R100 |
Application | Exoskeleton | Exoskeleton | Exoskeleton |
Driving way | FOC | FOC | FOC |
Operation ambient temperature | -20℃~50°℃ | -20°C~50°℃ | -20°C~50°℃ |
Winding type | star | delta | delta |
Insulation class | H | H | H |
Insulation High-voltage | 500V 5mA/2s | 1000V 5mA/2s | 1000V 5mA/2s |
Insulation resistance | 500V10MQ | 1000V10MQ | 1000V10MQ |
Phase | 3 | 3 | 3 |
Pole pairs | 14 | 21 | 21 |
Rated voltage (V) | 48 | 48 | 48 |
No-load speed (rpm) | 4656 | 4320 | 3740 |
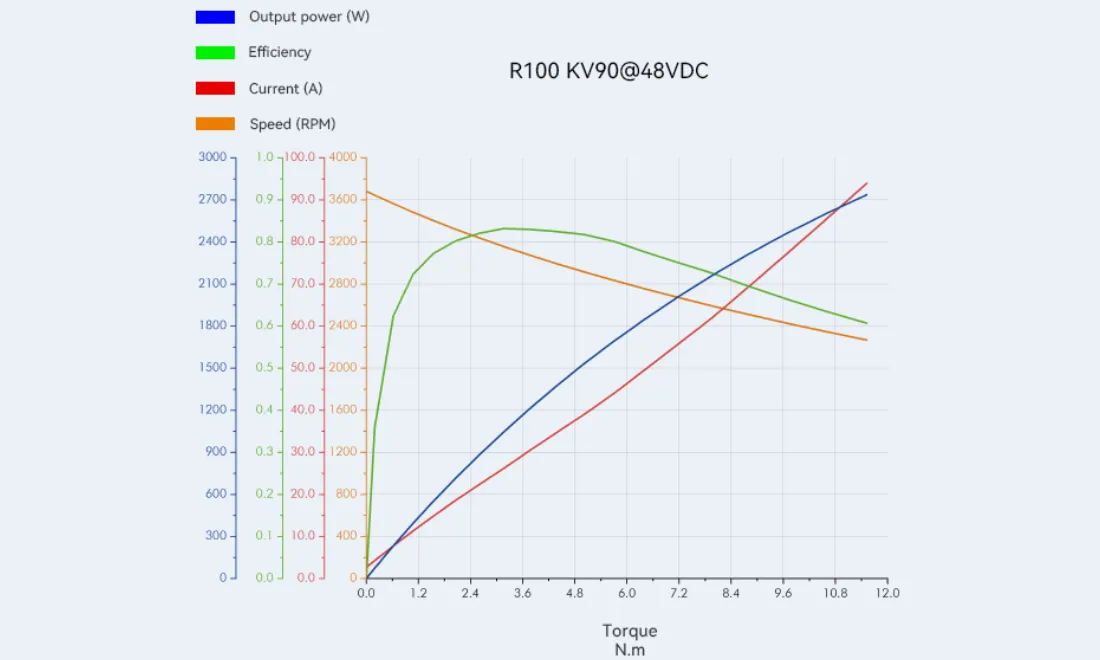
Rated torque (Nm) | 0.75 | 1.3 | 3.7 |
Rated speed (rpm) | 3845 | 3580 | 3080 |
Rated current (ADC) | 7.6 | 12.3 | 30.1 |
Peak torque (Nm) | 2.3 | 4 | 11 |
Peak current (ADC) | 23.2 | 38.6 | 90.5 |
Kv (rpm/V) | 97 | 90 | 78 |
Kt (Nm/A) | 0.098 | 0.107 | 0.123 |
Ke (V/krpm) | 9.82 | 10.58 | 12.21 |
Phase to Phase resistance (mQ) | 235 | 125 | 51 |
Phase to Phase inductance (uH) | 183 | 87 | 33 |
Inertia (gcm²) | 363.74 | 759.98 | 2505.4 |
Km (Nm/-W) | 0.2022 | 0.3026 | 0.5447 |
Mechanical time constant (ms) | 0.89 | 0.83 | 0.84 |
Electrical time constant (ms) | 0.78 | 0.7 | 0.65 |
Weight (g) | 248 | 354 | 731 |
Maximum torque weight ratio (Nm/kg) | 9.3 | 11.3 | 16.4 |
Correspondence | Hu-U Hv-V Hw-W | Hu-U Hv-V Hw-W | Hu-U Hv-V Hw-W |
Application
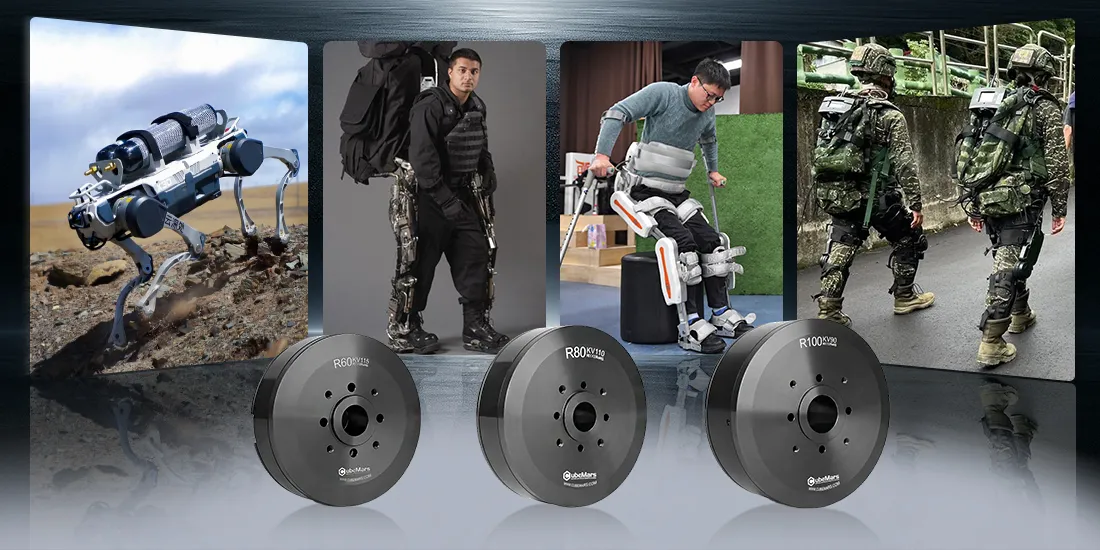
The R series meets diverse installation requirements and supports heavy-load legged robots and exoskeleton robots.
Note
1. It is strictly prohibited to disassemble the motor privately.
2. None of the interfaces support hot plugging. You need to plug in the wires first and then power on, and control the signal at the same time
The ground wire of the number needs to be connected.
3. During high-speed operation, the motor is not allowed to suddenly stall.
4. Do not use under overvoltage.
5. Monitor the motor temperature in a timely manner and reduce the power or increase heat dissipation to make
The motor operates within a reasonable temperature range.
6. Before loading the equipment, it is recommended to use the upper computer for debugging under the same working conditions first.
7. Update the firmware in a timely manner to achieve better motor performance;


