Avatar Intelligent Equipment Co., Ltd.
  • Integrated Planetary Roller Screw Linear Actuator With Force Sensor Motor Encoder for Humanoid Robot R&D High Thrust Lig
  • Integrated Planetary Roller Screw Linear Actuator With Force Sensor Motor Encoder for Humanoid Robot R&D High Thrust Lig
  • Integrated Planetary Roller Screw Linear Actuator With Force Sensor Motor Encoder for Humanoid Robot R&D High Thrust Lig
  • Integrated Planetary Roller Screw Linear Actuator With Force Sensor Motor Encoder for Humanoid Robot R&D High Thrust Lig
  • Integrated Planetary Roller Screw Linear Actuator With Force Sensor Motor Encoder for Humanoid Robot R&D High Thrust Lig
  • Integrated Planetary Roller Screw Linear Actuator With Force Sensor Motor Encoder for Humanoid Robot R&D High Thrust Lig
  • Integrated Planetary Roller Screw Linear Actuator With Force Sensor Motor Encoder for Humanoid Robot R&D High Thrust Lig
  • Integrated Planetary Roller Screw Linear Actuator With Force Sensor Motor Encoder for Humanoid Robot R&D High Thrust Lig
  • Integrated Planetary Roller Screw Linear Actuator With Force Sensor Motor Encoder for Humanoid Robot R&D High Thrust Lig
  • Integrated Planetary Roller Screw Linear Actuator With Force Sensor Motor Encoder for Humanoid Robot R&D High Thrust Lig
  • Integrated Planetary Roller Screw Linear Actuator With Force Sensor Motor Encoder for Humanoid Robot R&D High Thrust Lig
  • Integrated Planetary Roller Screw Linear Actuator With Force Sensor Motor Encoder for Humanoid Robot R&D High Thrust Lig

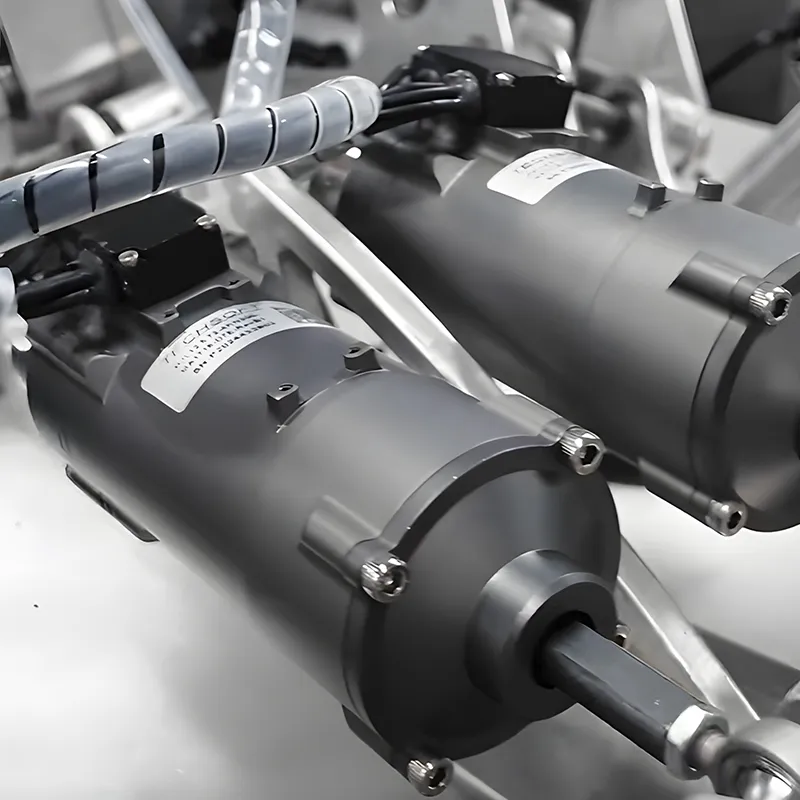
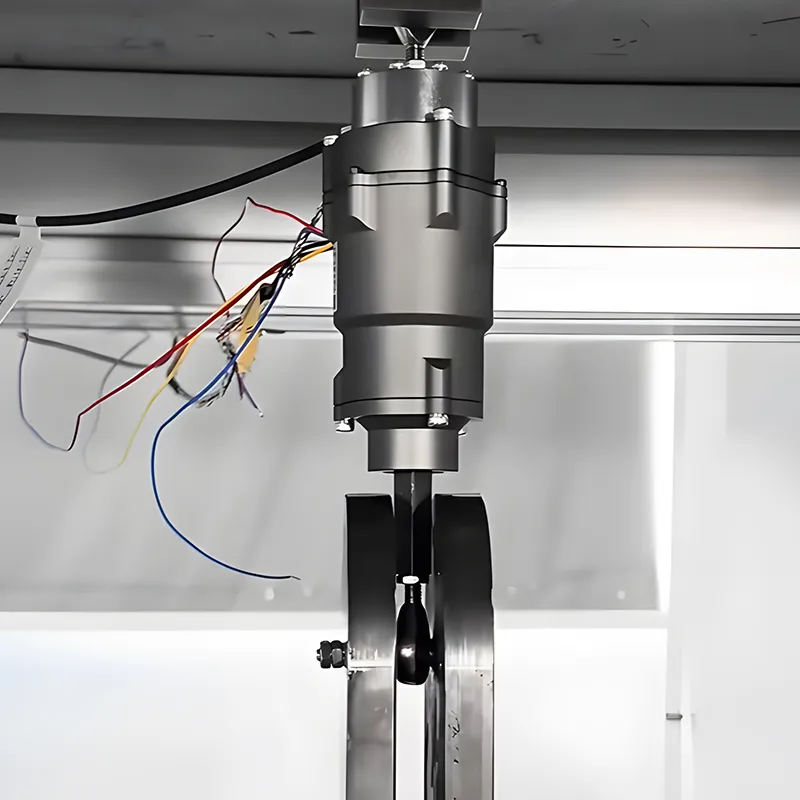
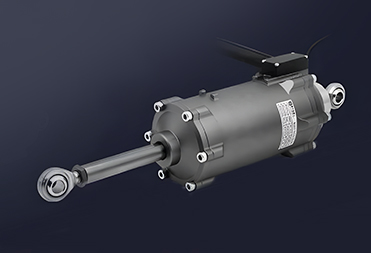
Integrated Planetary Roller Screw Linear Actuator With Force Sensor Motor Encoder for Humanoid Robot R&D High Thrust Lig

A high-performance humanoid robot solution that can meet the needs of different scenarios.

  • place of origin :China
  • production capacity :500/month
  • weight (kg) :0.5
  • brand name :Avatar
  • power(w) :192W

USD 1000-2000

contact shop

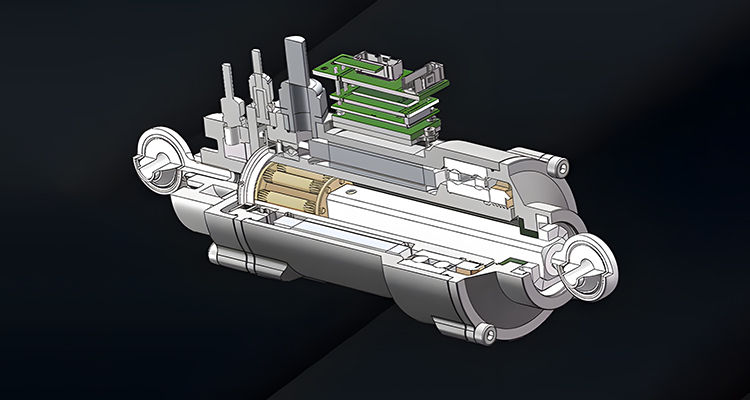
Product Description

HJL08
Maximum thrust
600N
Maximum speed
300mm/s
Maximum travel
38mm
Weight
0.5kg
Force sensor
tension and pressure sensor


HJL12
Maximum thrust
4000N
Maximum speed
120mm/s 300mm/s
Maximum travel
72mm
Weight
1.3kg
Force sensor
tension and pressure sensor


HJL15
Maximum thrust
8000N
Maximum speed
120mm/s 400mm/s
Maximum travel
96mm
Weight
2.8kg
Force sensor
tension and pressure sensor


Product Size


Product parameters

Project
Unit
HJL08
HJL12
HJL15
mechanical parameters
Ball screw type

Reverse planetary roller ball screw
Lead
mm
3.6
2/5
2/6.5
Maximum Thrust
N
600
4000
8000
Maximum speed
mm/s
300
120/300
120/400
Maximum travel
mm
38
72
96
Maximum diameter
mm
49
62
86
Maximum length
mm
139.9
226.9
286.6
Joint weight
kg
0.5
1.3
2.8


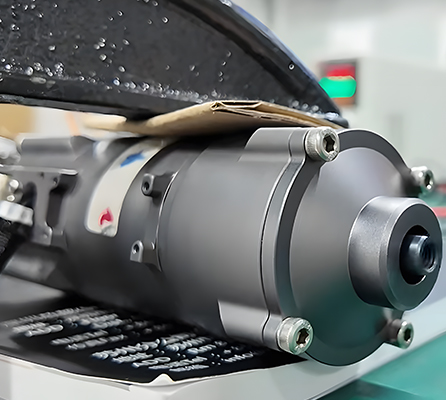
Product Display


Torque density: a core indicator of performance and lightweighting

The quality of the joint module directly affects the weight distribution, inertial load, and energy consumption of the entire machine.
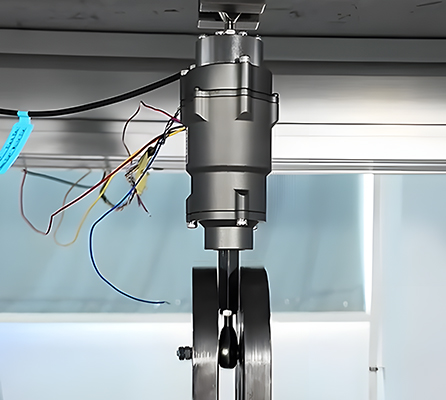


Position and torque control accuracy: the cornerstone of motion accuracy

The position accuracy and torque control accuracy of joint modules are prerequisites for achieving precise, smooth, and coordinated motion of humanoid robots.
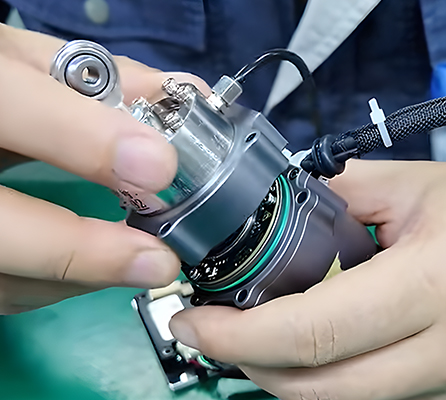


Dynamic response and overload capability: key to dealing with complex environments

Dynamic response refers to the ability of joint modules to quickly follow changes in control instructions, typically measured by bandwidth and step response time.


Product Application

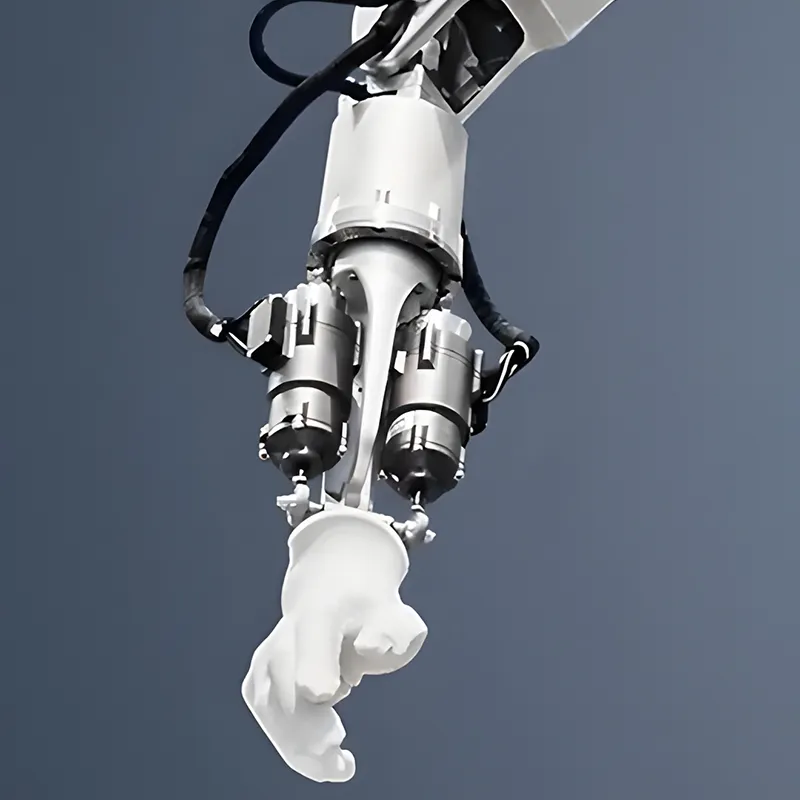
A high-performance humanoid robot solution that can meet the needs of different scenarios.
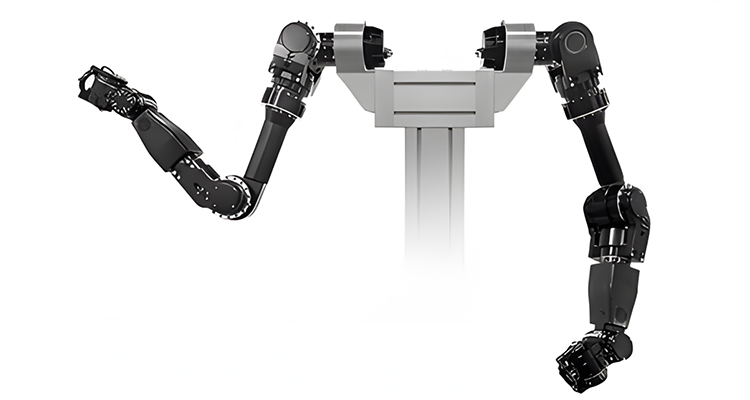
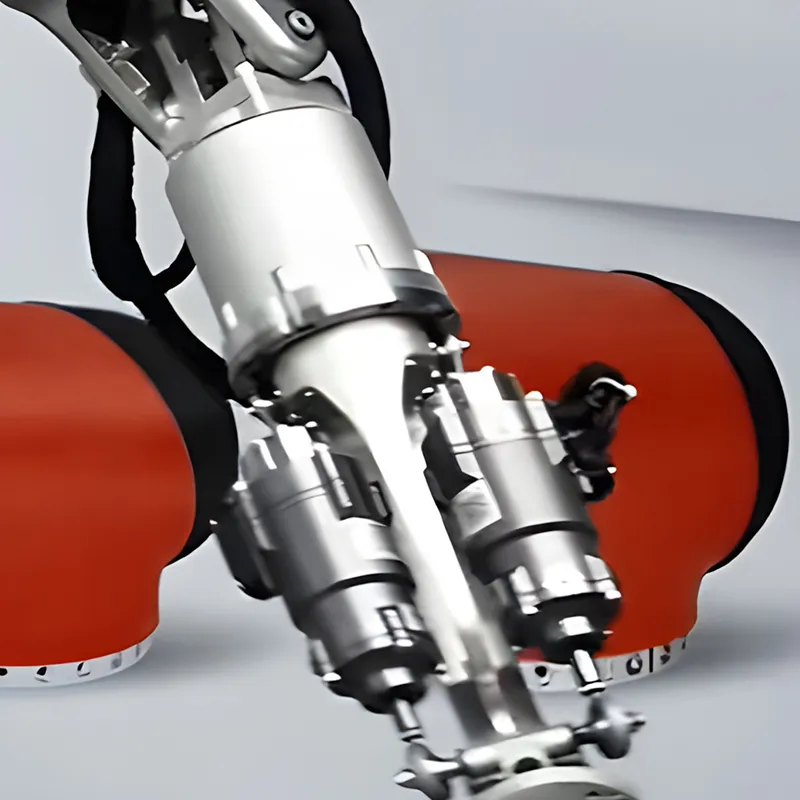
Lightweight humanoid robot arm
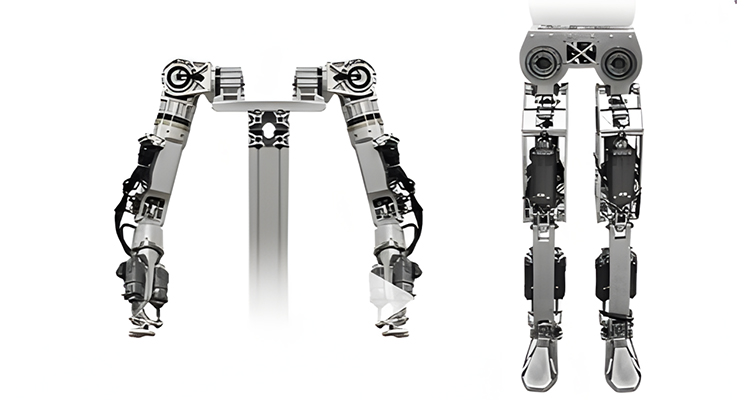
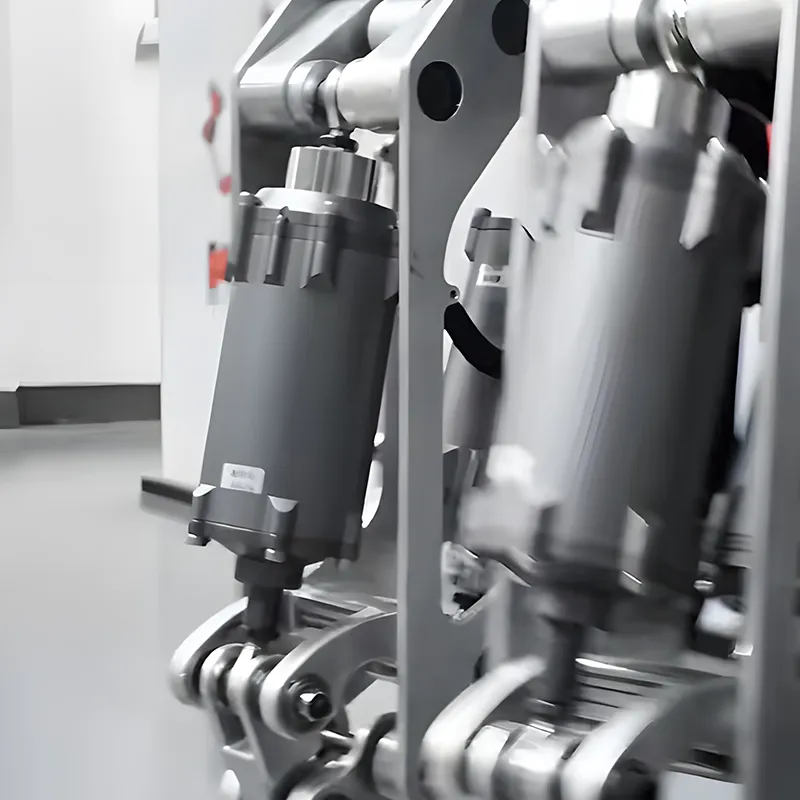
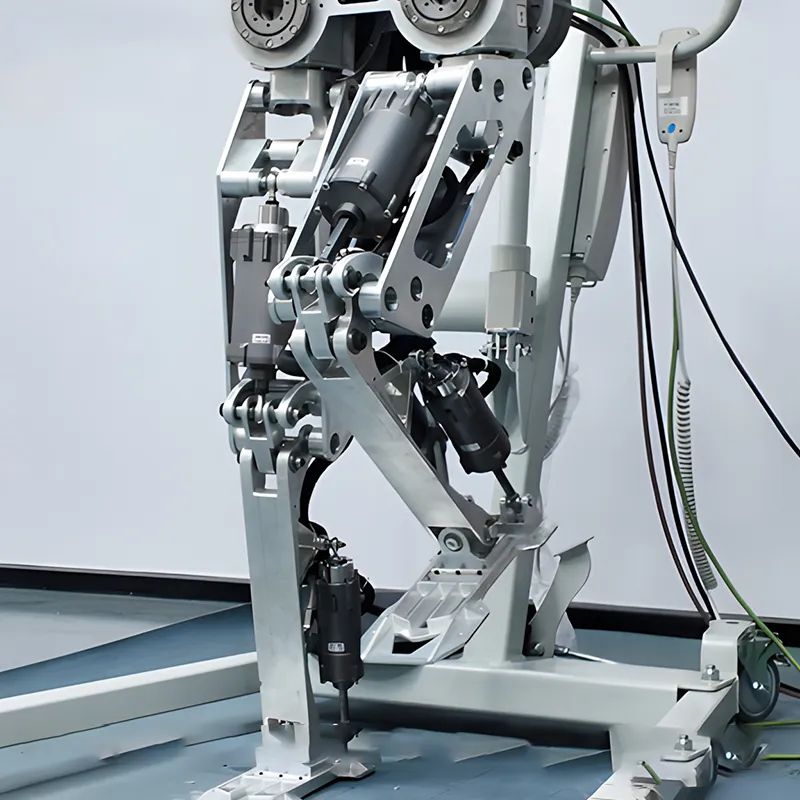
Humanoid robots assembled with linear joint modules
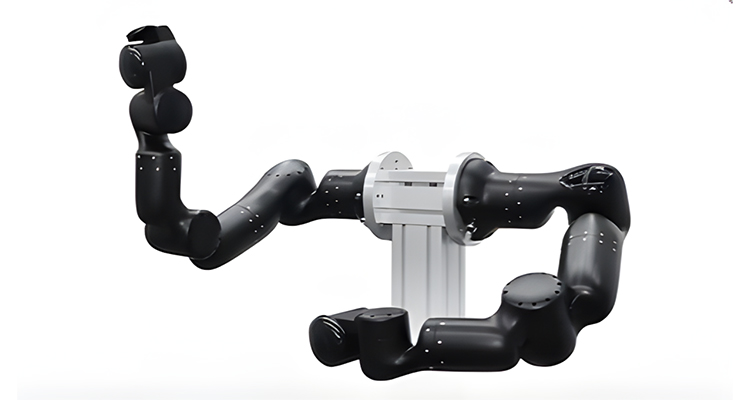
Humanoid robot arm with joint force control

Company Introduction

Avatar Intelligent Equipment Co.,Ltd. specializes in the R&D and supply of robotic prod-ucts and mobile solutions for robot platforms. Its core product line covers various robot application related products such as wall finishing robots, cleaning robots, grippers, and robotic arms. The company has built an integrated service system from R&D, quality inspection,production to sales and after sales service, providing customers with reliable intelligent equipment support through independent technical strength.
Service

Q1. who are we? 

A:We are based in Henan, China, start from 2012,sell to South America(40.00%),Southeast Asia(30.00%),Eastern

Europe(20.00%),Western Europe(5.00%),Domestic Market(5.00%). There are total about 11-50 people in our office. 


Q2. how can we guarantee quality? 

A: Always a pre-production sample before mass production; Always final Inspection before shipment.


Q3.what can you buy from us?

A: Robot Application and parts products.


Q4. what services can we provide?

A: Accepted Delivery Terms: FOB,EXW;Accepted Payment Currency:USD; Accepted Payment Type: T/T,Western Union; Language Spoken:English,Chinese .


Q5. How does your factory do the quality control? 

A: There is system to control the quantity from IQC to production process to OQC.


Supplier Information

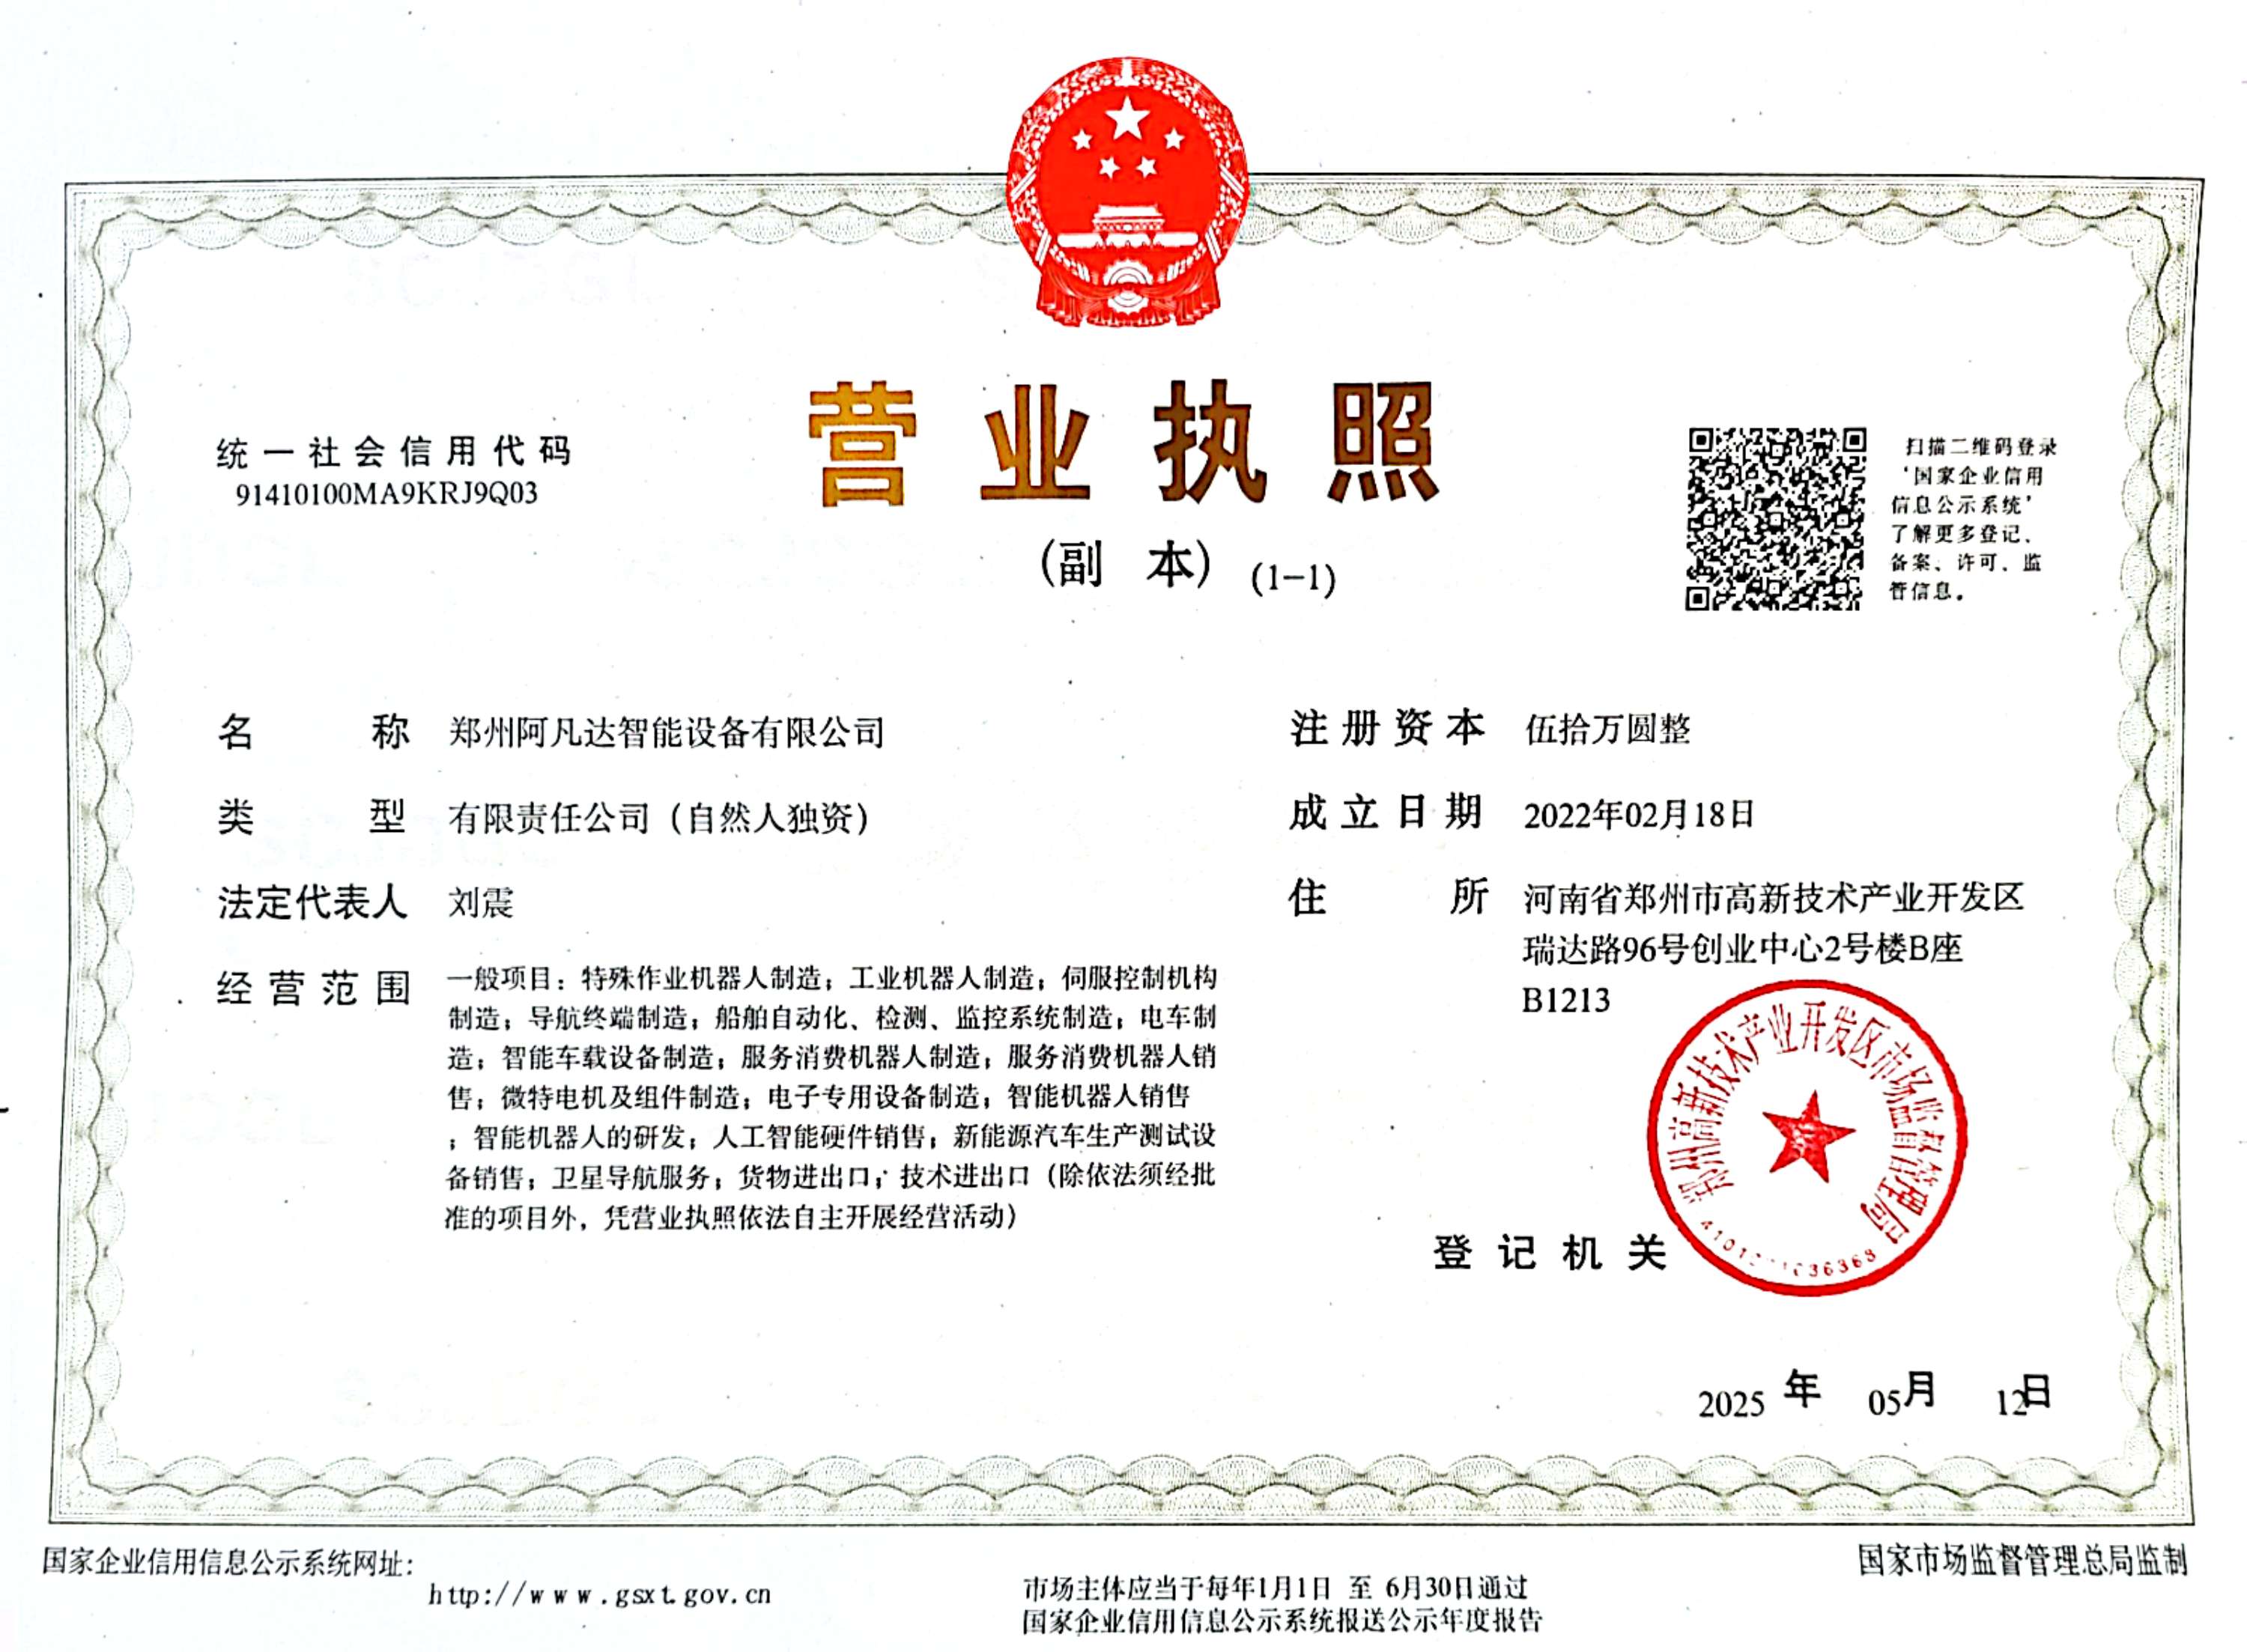
Company:Avatar Intelligent Equipment Co., Ltd.

Tax Id:91410100MA9KRJ9Q03

Email:[email protected]

Tel:+8615238528875

Recommended products

Miniature Planetary Roller Screw for Robotic Hand Dexterous Finger Actuator High Precision Linear Motion

Compact Roller Screw Assembly for Multi Finger Robot Hands and Precision Motion Control

collect:0

Industrial Automation Servo Linear Actuator High Precision Electric Cylinder for Robot Arm Gripper System

Micro Linear Servo Actuator delivers high precision and high power density to achieve accurate servo control at any position throughout the travel range.

collect:0

BLA Micro Servo Electric Cylinder Coreless Brushless Motor Planetary Roller Screw FOC Four Closed Loop High Precision La

The BLA series micro servo electric cylinder adopts a hollow cup brushless motor and planetary roller screw inside. The drive control system includes FOC control algorithm

collect:0

High Precision Mini Servo Linear Actuator Electric Cylinder for Robotic Gripper Industrial Automation System

Compact integrated linear servo actuator built with coreless motor, planetary reducer, sensor, precision screw and closed-loop control.

collect:0