

Product Description
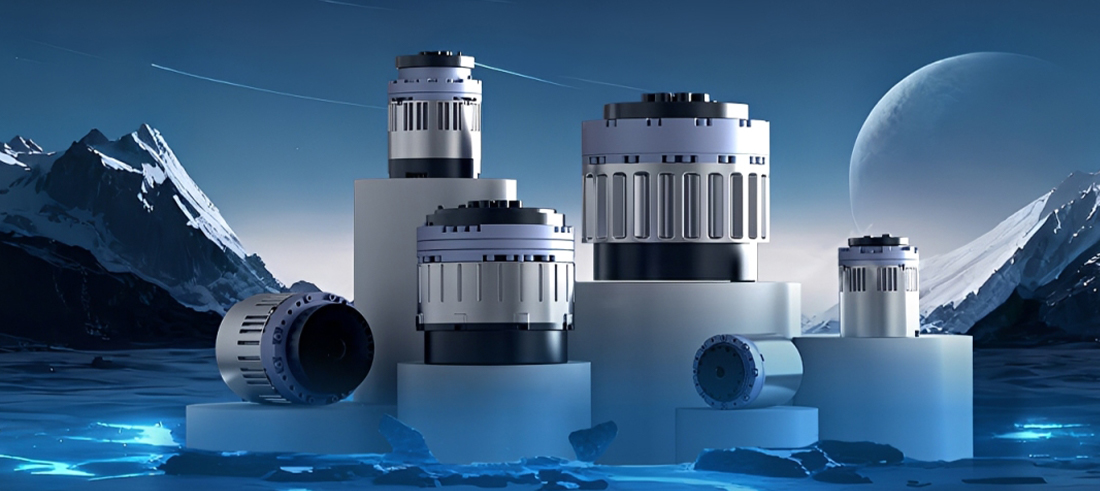
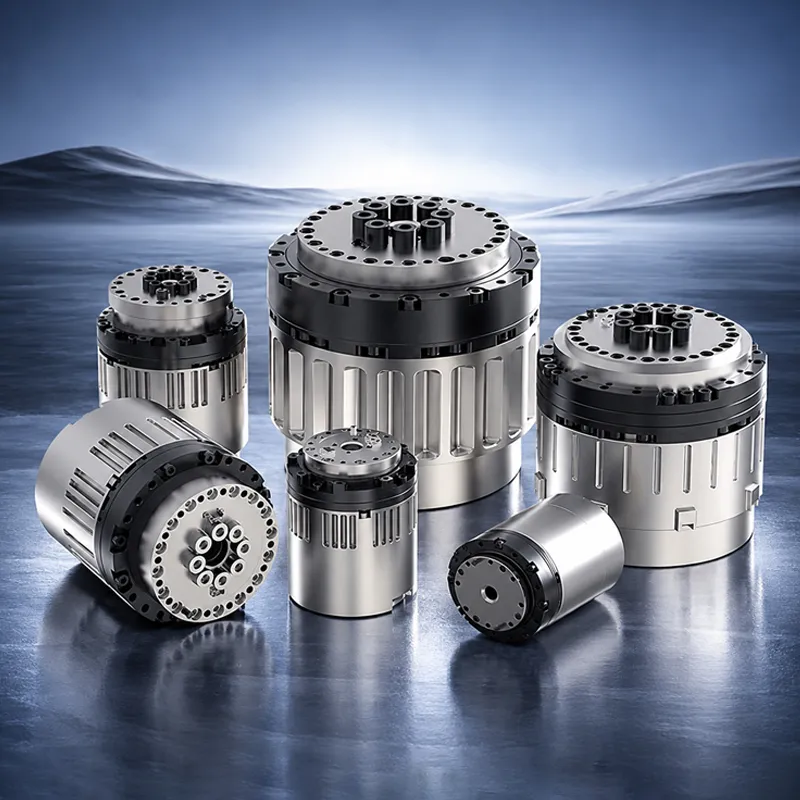
The HSA Series joints feature an ultra-lightweight, compact design with highly integrated mechanical and electrical interfaces. The lightest joint weighs only 450 g, enabling quick assembly without additional redundant components. Each joint incorporates a high-precision torque sensor, enabling fine force sensing and control with a resolution of less than 0.05 Nm, along with millisecond-level response to dynamic load changes. The force-control closed-loop update frequency reaches a stable 1 kHz.
The HSA Series delivers powerful performance, with torque density of up to 48 Nm/kg and motor speeds of up to 6,000 rpm, providing a solid hardware foundation for various robotic platforms.
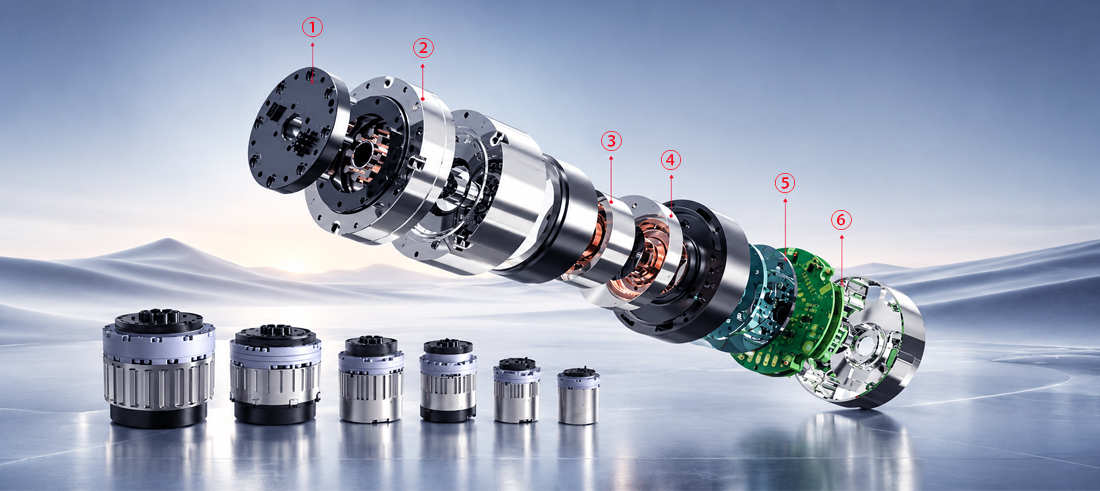
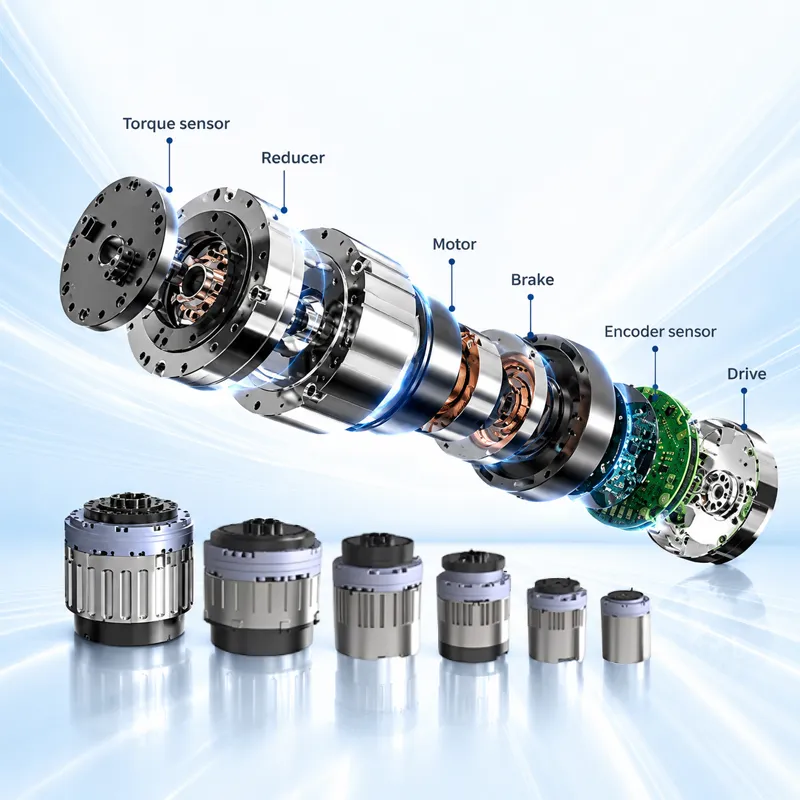
①Torque sensor ②Reducer ③Motor ④Brake ⑤Encoder sensor ⑥Drive
Product parameters
HSA-11 | HSA-14 | HSA-17 | HSA-20 | HSA-25 | HSA-32 | |
Motor Type | Inner-Rotor Frameless Torque Motor | |||||
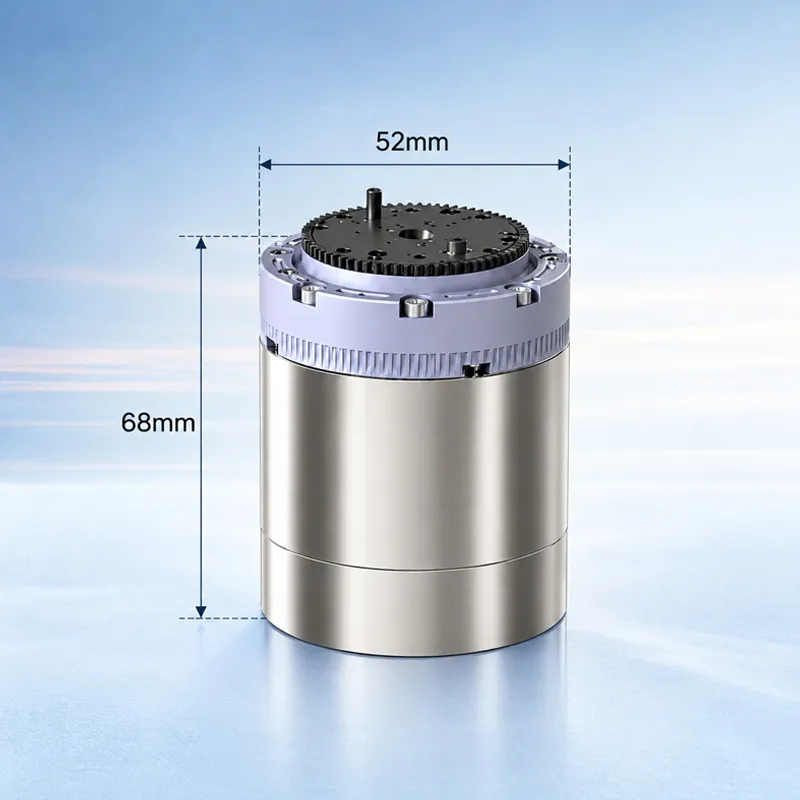
Dimensions (Diameter/Length) (mm) | 52/68 | 60/74 | 72/98 | 82/107 | 110/115 | 142/135 |
Hollow Bore Diameter (mm) | 6 | 9 | 10 | 13 | 15 | 21 |
Weight (With/Without Brake) (g) | 450(without)* | 600(with) | 1100(with) | 1700(with) | 2950(with) | 6000(with) |
Operating Voltage (V) | 48 | 48 | 48 | 48 | 48 | 48 |
Rated Joint Power (W) | 40 | 120 | 160 | 250 | 600 | 950 |
Gear Ratio | 100 | 100 | 100 | 120 | 100 | 120 |
Rated Speed (rpm) | 30 | 30 | 30 | 30 | 30 | 20 |
Torque Density (Nm/kg) | 19.8 | 12.8 | 46.4 | 37.6 | 47.5 | 46.8 |
Maximum Permissible Average Load Torque (Nm) | 8.9 | 7.7/14* | 51 | 64 | 140 | 281 |
Peak Torque (Nm) | 11 | 19 | 70 | 113 | 204 | 459 |
Rated Torque of Torque Sensor (Nm) | 12 | 25 | 70 | 110 | 210 | 480 |
Torque Sensor Resolution (Nm) | ≤0.0.5 | ≤0.0.5 | ≤0.0.5 | ≤0.0.5 | ≤0.0.5 | ≤0.0.5 |
Torque Sensor Limit Torque (Nm) | 36 | 75 | 210 | 330 | 630 | 1440 |
Force-Control Closed-Loop Bandwidth | 100Hz | |||||
Impedance Control Frequency | 1kHz | |||||
Force-Control Sampling Frequency | 32kHz | |||||
Encoder Resolution (bit) | 18 | |||||
Encoder Type | Dual Absolute Encoders | |||||
Communication Interface | EtherCAT | |||||
Product Display
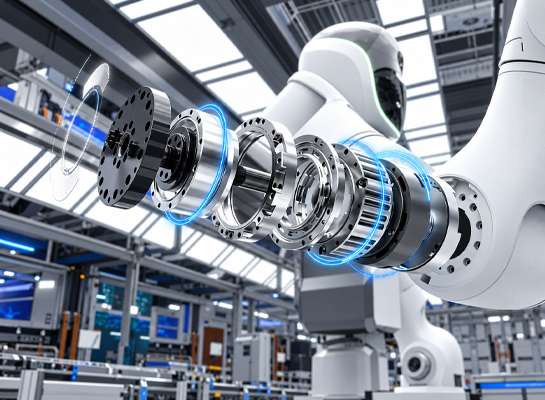
Lightweight and Highly Integrated
● Highly integrated design with a compact structure and reduced weight.
● Single-plane encoder layout, with a minimum joint weight of just 450 g.
● 10% larger hollow bore than comparable products in the industry, saving 20% of installation space and significantly reducing the equipment's load burden.
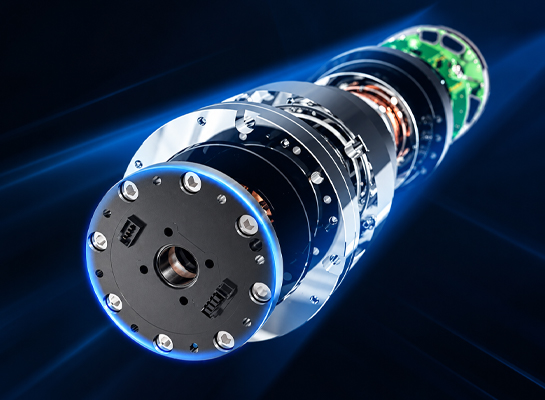
High-Precision Force Control with Fast Response
● Microgram-level force sensing and control, with torque sensor resolution of ≤ 0.05 N·m.
● High-performance frameless torque motor with a maximum speed of 6,000 rpm.
● 32 kHz high-frequency force-control sampling and a control frequency of > 8 kHz for precise capture of dynamic force changes.
● Force-control closed-loop bandwidth of 100 Hz.
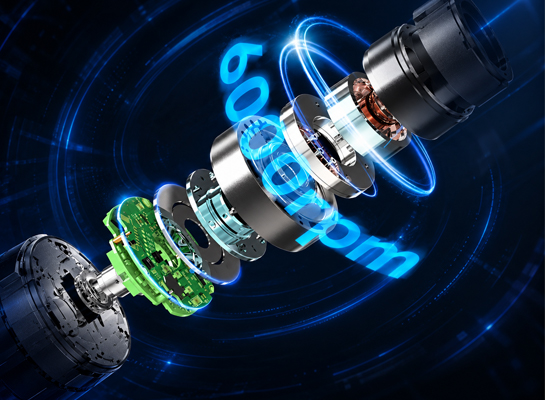
High Torque Density, Powerful and Reliable Performance
● Equipped with a high-performance frameless torque motor to maximize core performance.
● High-precision harmonic reducer, delivering torque density of up to 48 N·m/kg and peak torque of 459 N·m.
● 300% F.S. overload capacity, an electromagnetic holding brake, a wide operating temperature range of 0°C–50°C, and dual absolute encoders for redundancy, ensuring stable operation under demanding conditions.
Versatile and Easy Integration
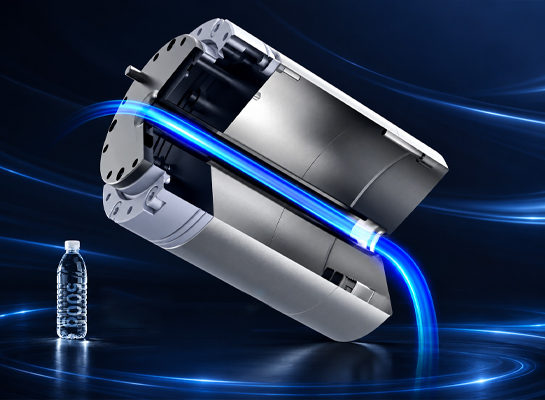
● Hollow bore diameters ranging from 6 to 21 mm.
● Supports EtherCAT communication (cycle time: 1 + 0.1 ms), enabling plug-and-play integration with a wide range of equipment.
Application Cases
Medical and Elderly Care
3C Electronics
Commercial and Educational Applications