

Product Description
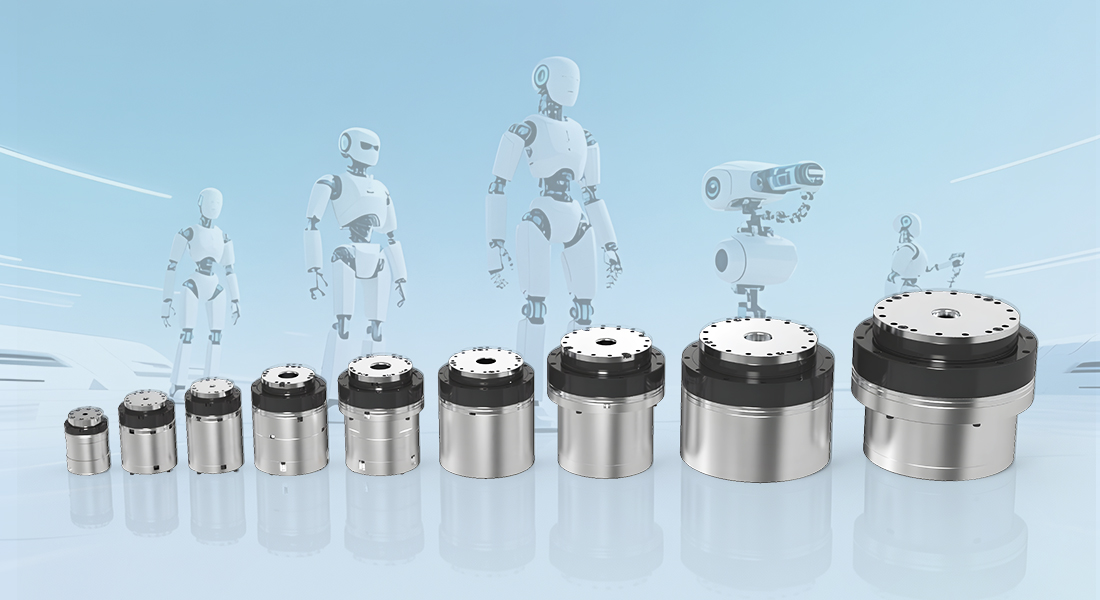
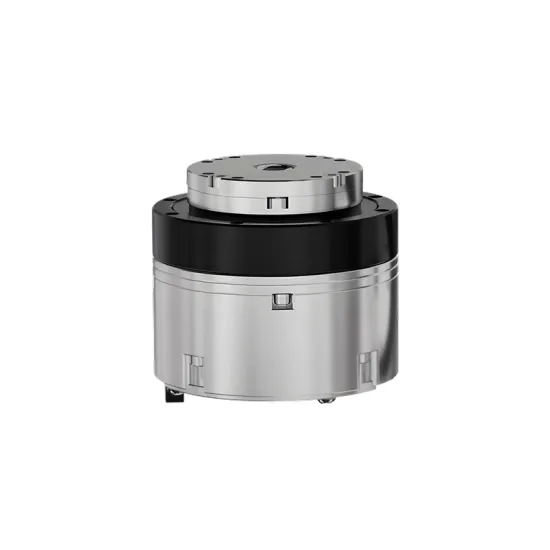
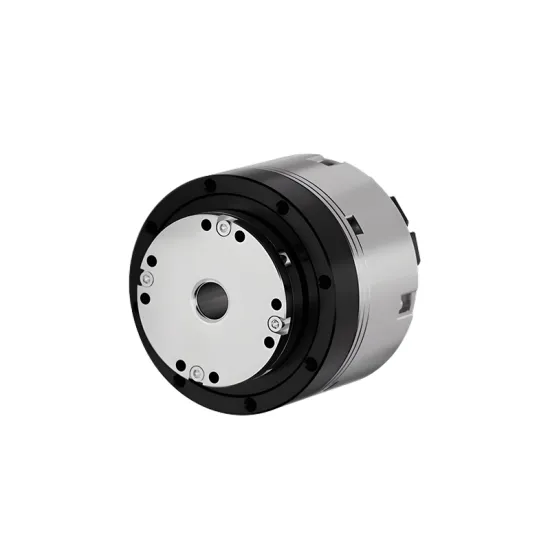
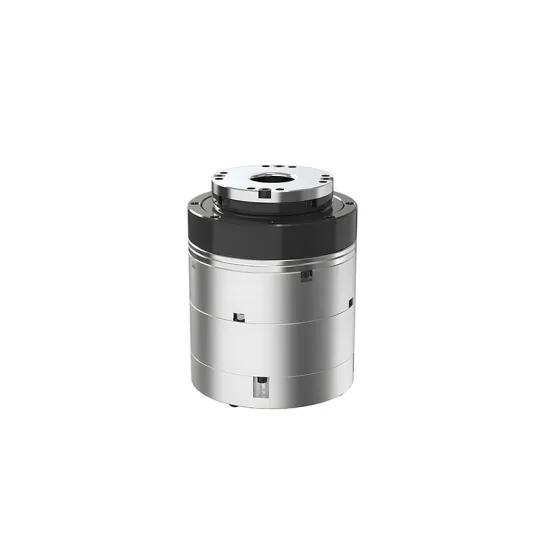
Harmonic joint actuators integrate the drive, dual hollow encoders, frameless motor, harmonic reducer, sensors, and other technologies into a highly integrated design. Core components are independently developed, incorporating key technologies such as high torque density, high-precision dual hollow encoders, high-precision torque control, and highly reliable load identification. The actuators offer a lightweight, modular, cost-effective, and high-performance product portfolio, providing one-stop solutions that simplify robot development and make automation equipment easier to use.
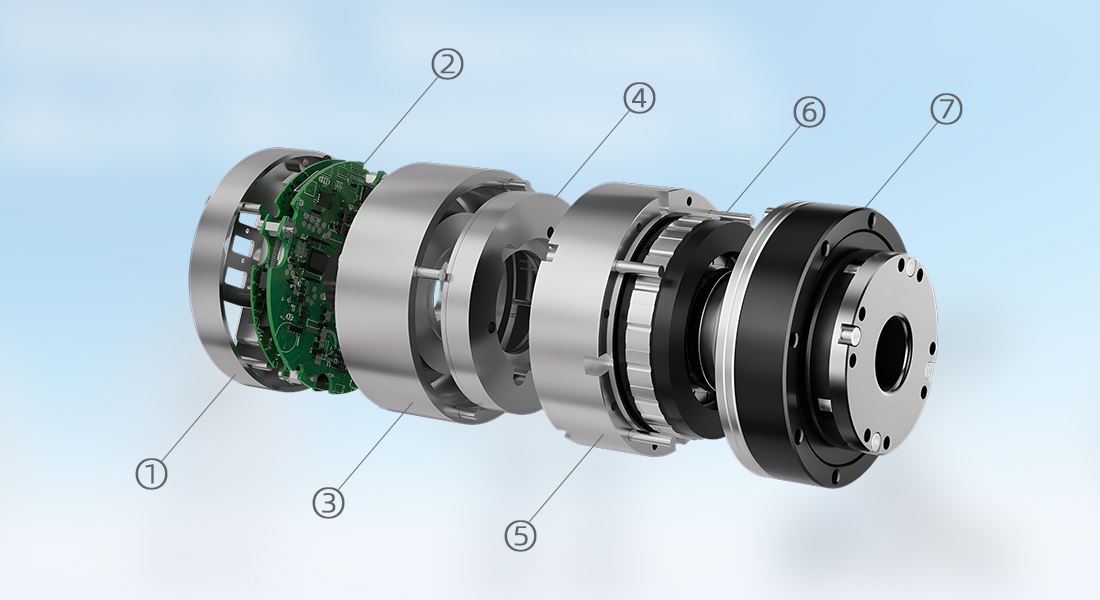
①Drive Cover ②Drive + Dual Hollow Encoders ③Brake Cover ④Brake ⑤Housing ⑥Frameless Motor ⑦Reducer
Product parameters
Specification | G4008 | G5211 | G5211 | G7014 | G7014 | G8017 | G8017 | G9020 | G9020 | G11025 | G11025 | G14232 | G17040 |
Performance Parameters | |||||||||||||
Rated Voltage / V | 24 | 48 | 48 | 48 | 48 | 48 | 48 | 48 | 48 | 48 | 48 | 48 | 48 |
Rated Current / A | 0.64 | 3.5 | 3.5 | 2.55 | 2.55 | 6.3 | 6.3 | 10 | 10 | 13.5 | 13.5 | 22 | 25 |
Rated Power / W | 15 | 63 | 63 | 100 | 100 | 189 | 189 | 300 | 300 | 650 | 650 | 1000 | 1200 |
Rated Speed / rpm | 40 | 30 | 30 | 30 | 30 | 30 | 30 | 30 | 30 | 30 | 30 | 25 | 20 |
Peak Speed / rpm | 55 | 60 | 60 | 40 | 40 | 40 | 40 | 40 | 40 | 40 | 40 | 30 | 30 |
Rated Torque / Nm | 2.4 | 5 | 5 | 9.6 | 9.6 | 30 | 30 | 50 | 50 | 84 | 84 | 169 | 363 |
Maximum Allowable Torque for Average Load / Nm | 3.3 | 8.9 | 8.9 | 13.5 | 13.5 | 49 | 49 | 61 | 61 | 133 | 133 | 267 | 557 |
Peak Torque / Nm | 9 | 25 | 25 | 66 | 66 | 134 | 134 | 182 | 182 | 351 | 351 | 848 | 1458 |
Reducer Parameters | |||||||||||||
Reducer Ratio | 101 | 101 | 101 | 101 | 101 | 101 | 101 | 101 | 101 | 101 | 101 | 101 | 121 |
Moment of Inertia 10⁻⁴ kg·m² | 0.27 | 0.09 | 0.1 | 0.19 | 0.19 | 0.28 | 0.28 | 0.83 | 0.83 | 2.07 | 2.07 | 3.82 | 9.07 |
Dimensions | |||||||||||||
Dimensions/mm | Φ40 × 55.6 | Φ52 × 59.9 | Φ52 × 71.4 | Φ70 × 61 | Φ70 × 71.6 | Φ80 × 68.5 | Φ80 ×77.2 | Φ90 ×72 | Φ90 ×83 | Φ110 ×79 | Φ110 ×89.9 | Φ142 ×118.5 | Φ170 ×142 |
Hollow Bore Diameter/mm | 7 | 7 | 7 | 10 | 10 | 12 | 12 | 18 | 18 | 18 | 18 | 18 | 18 |
Weight / g | 165 | 400 | 430 | 850 | 920 | 1020 | 1180 | 1500 | 1750 | 3200 | 3200 | 6100 | 8500 |
Brake | No | No | Yes | No | Yes | No | Yes | No | Yes | No | No | Yes | Yes |
Communication Method | Ethercat/can | ||||||||||||
Product Display
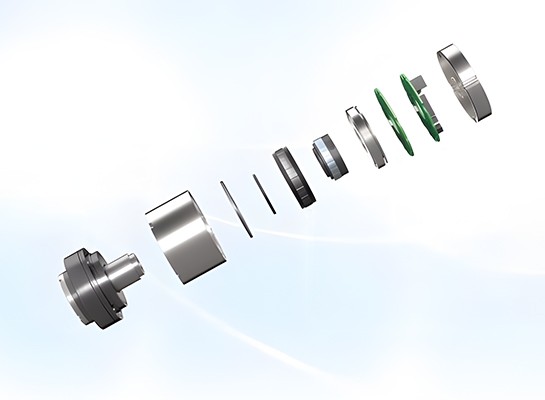
Highly Integrated Design
The actuator integrates the drive, dual hollow encoders, frameless motor, harmonic reducer, and sensors into a single unit. By combining power, transmission, feedback, and control functions, it reduces external connections and simplifies robot joint design and installation.
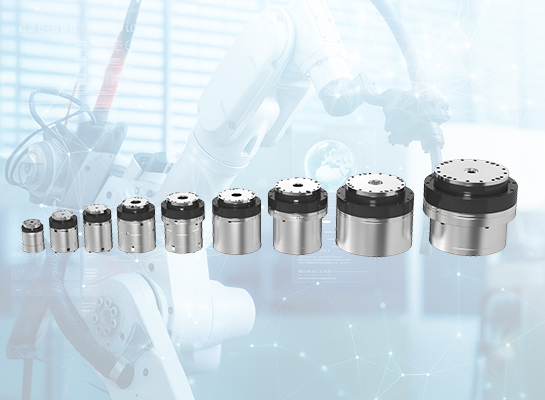
High Torque Density in a Compact Design
The compact integration of the frameless motor and harmonic reducer provides high output torque within limited installation space. The actuator balances lightweight design and power performance for robotic systems with strict size and weight requirements.
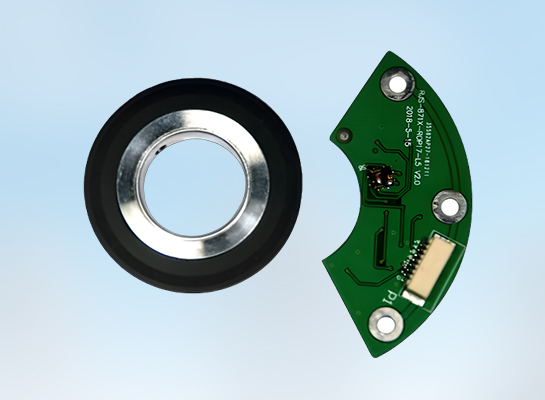
High-Precision Dual Hollow Encoders
The dual hollow encoder design provides joint position feedback and motion-state detection, supporting precise motion control and responsive joint operation. The hollow structure also provides additional space for cable routing and mechanical integration.
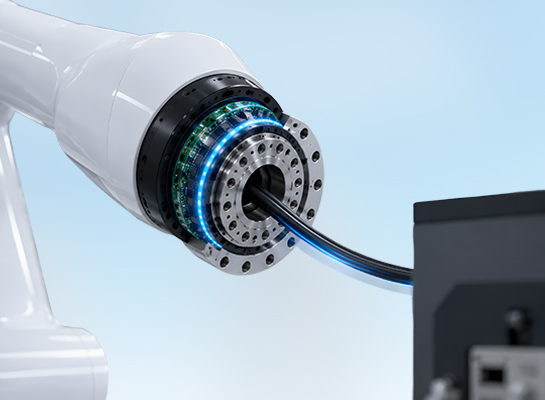
High-Precision Torque Control
With high-precision torque control and reliable load inertia identification, the actuator enables refined control of joint output conditions, helping improve motion stability and dynamic response in robotic applications such as collaborative and humanoid robots.
Application Cases
Humanoid Robots
6-Axis Collaborative Robot Arms
Quadruped Robots