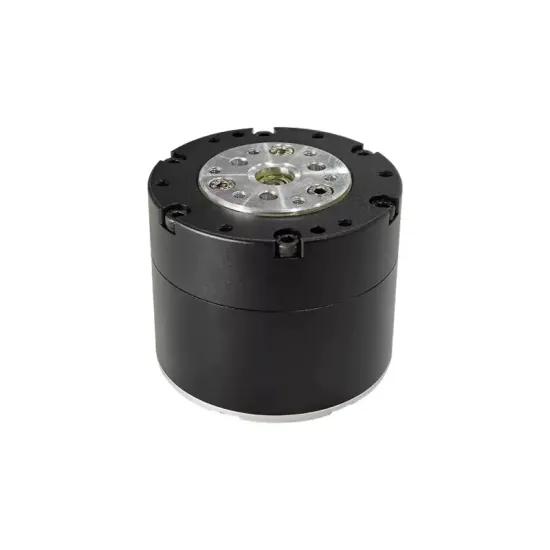
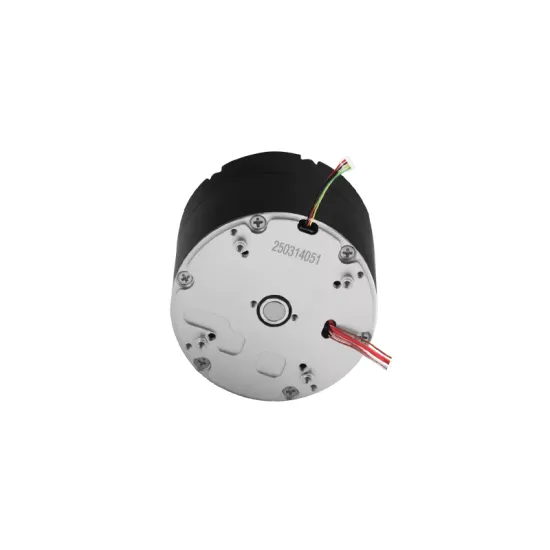
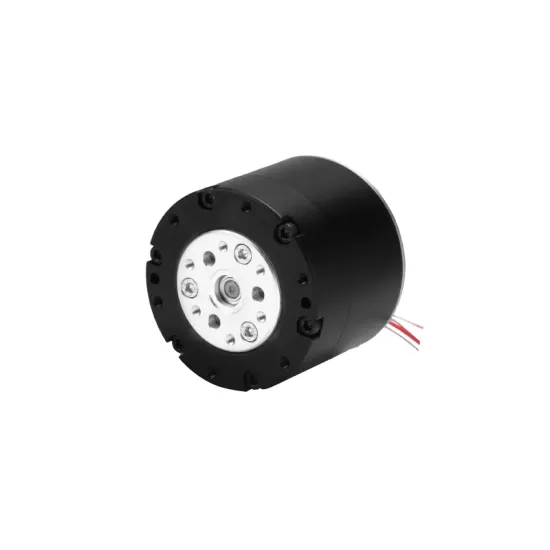
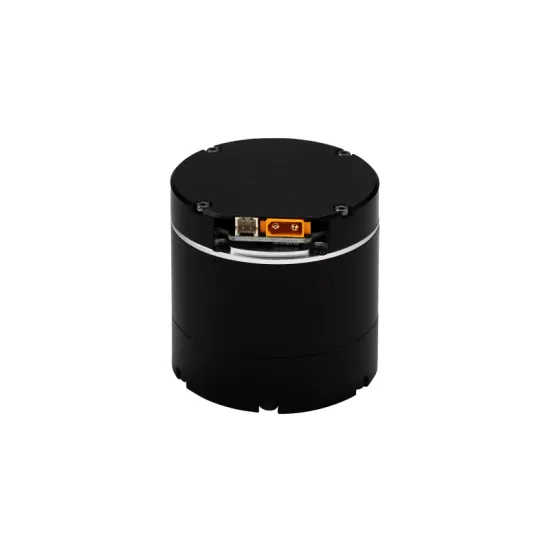
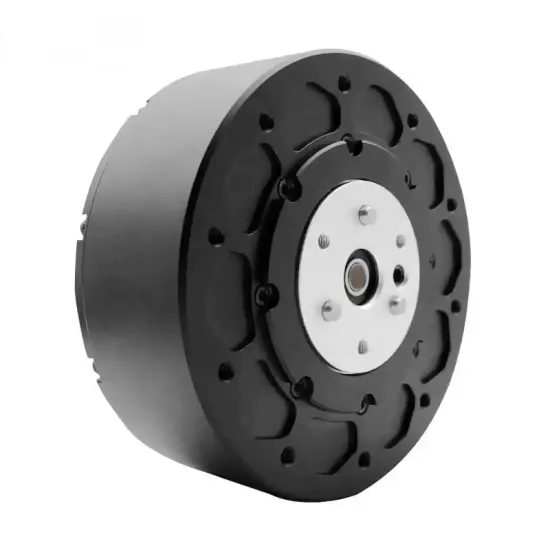


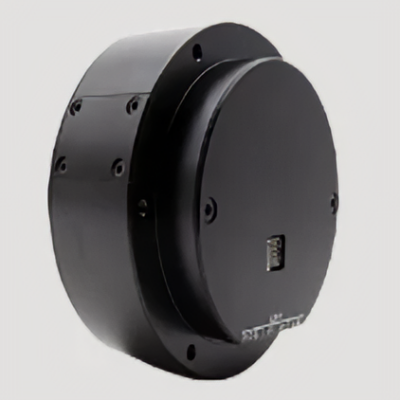
Small servo gear motor
18-bit single-turn absolute encoder / Zero-point setting requires only a single calibration / High power, high torque, and high precision
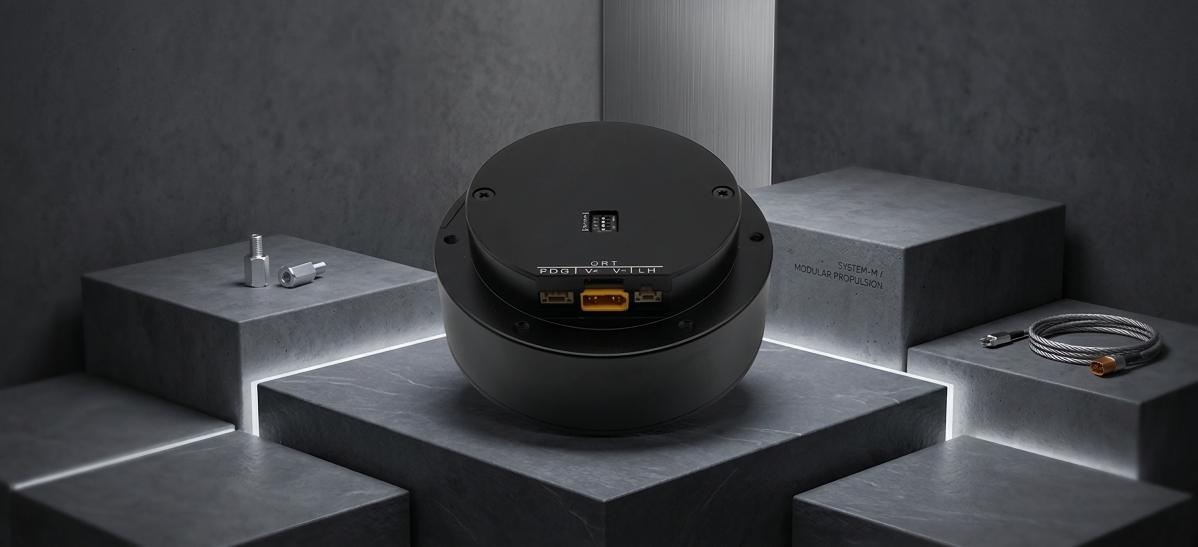
Ultra-high standard product design
Integrated electric drive
High Power, High Torque, High Precision
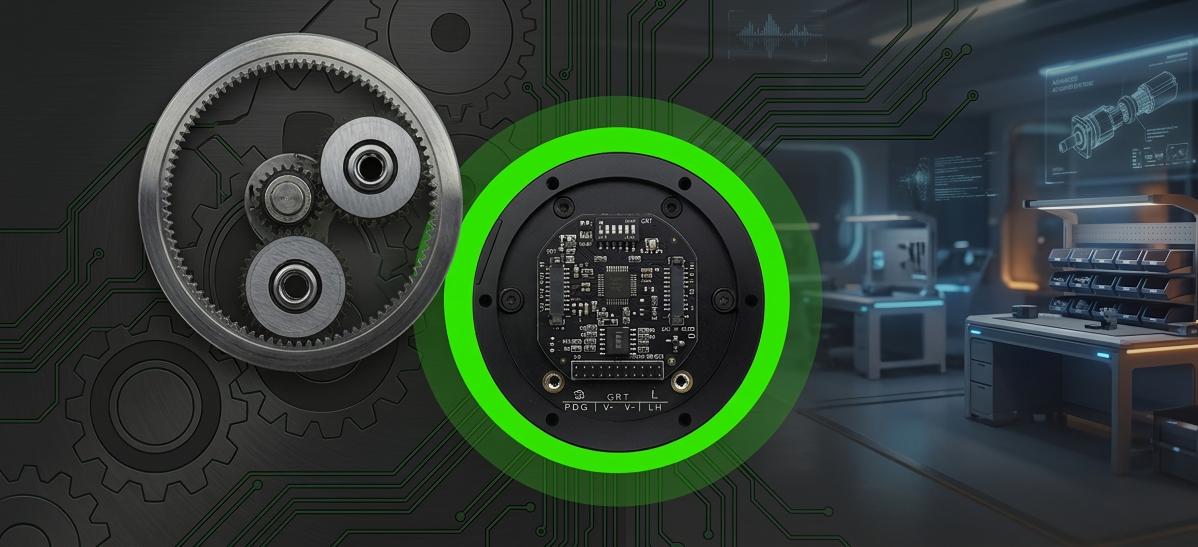
High-power brushless motor |
High-precision planetary gearbox |
High-performance FOC drive |
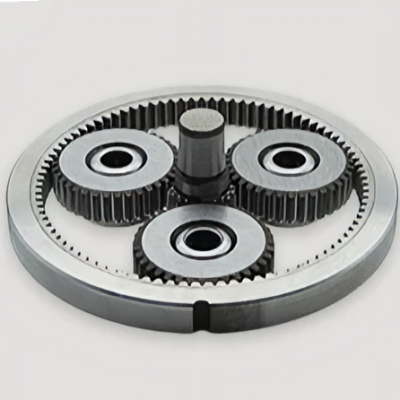
High-precision planetary gearbox
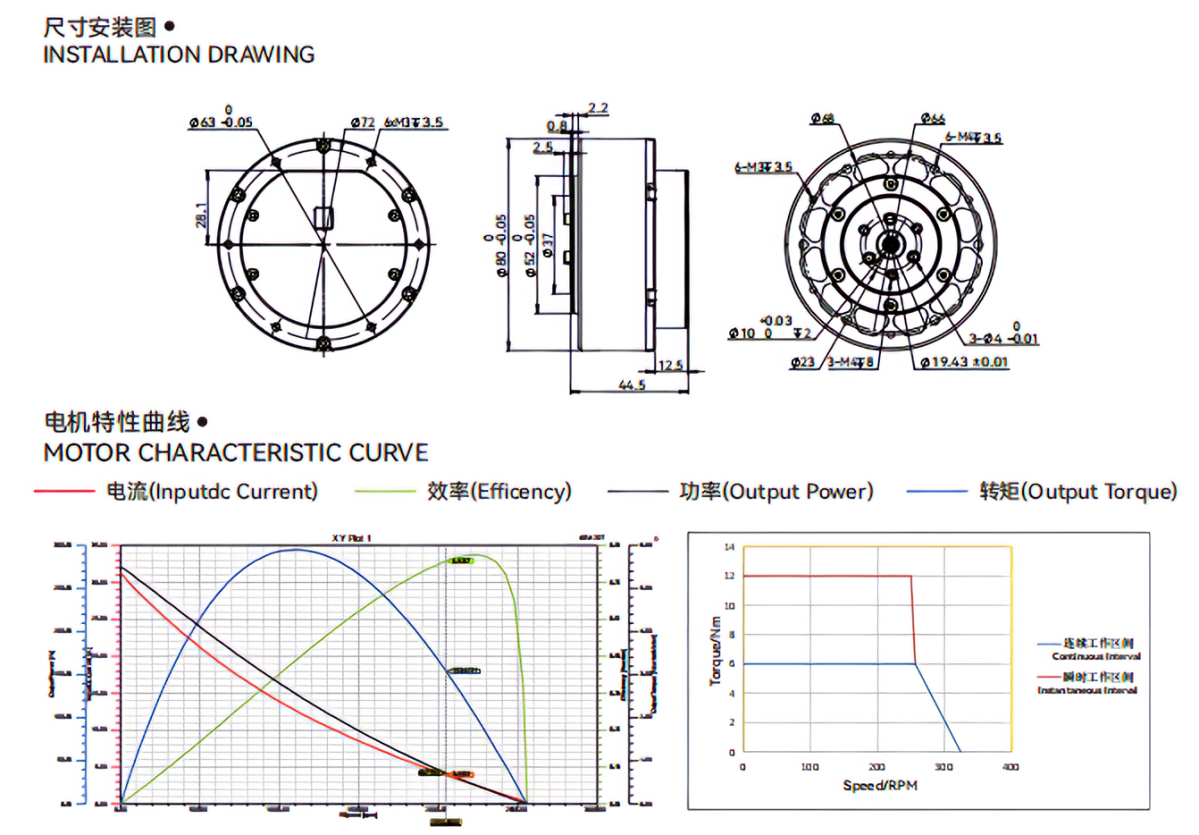
Reduction gear backlash: 6 arc-minutes reduction ratio: 1:8
Overall dimensions: | Φ80x44.5 |
| Rated torque: | 6N.m |
| Peak torque | 16N.m |
Application Scenarios
Legged robots |
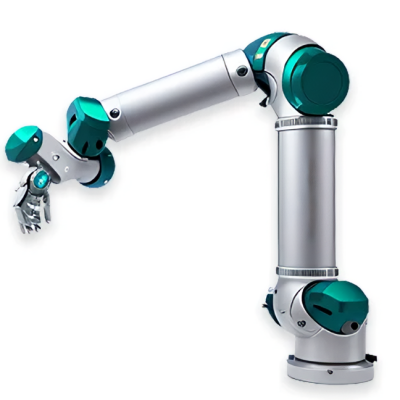
Industrial robots |
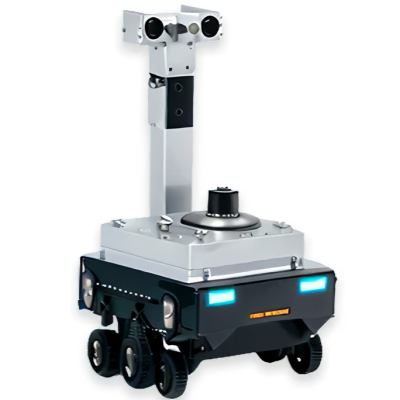
Inspection robot vehicle |
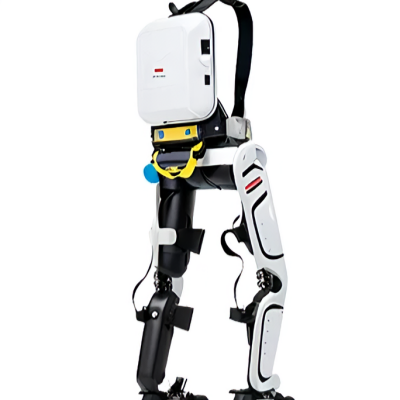
Medical robots |
Product Specifications
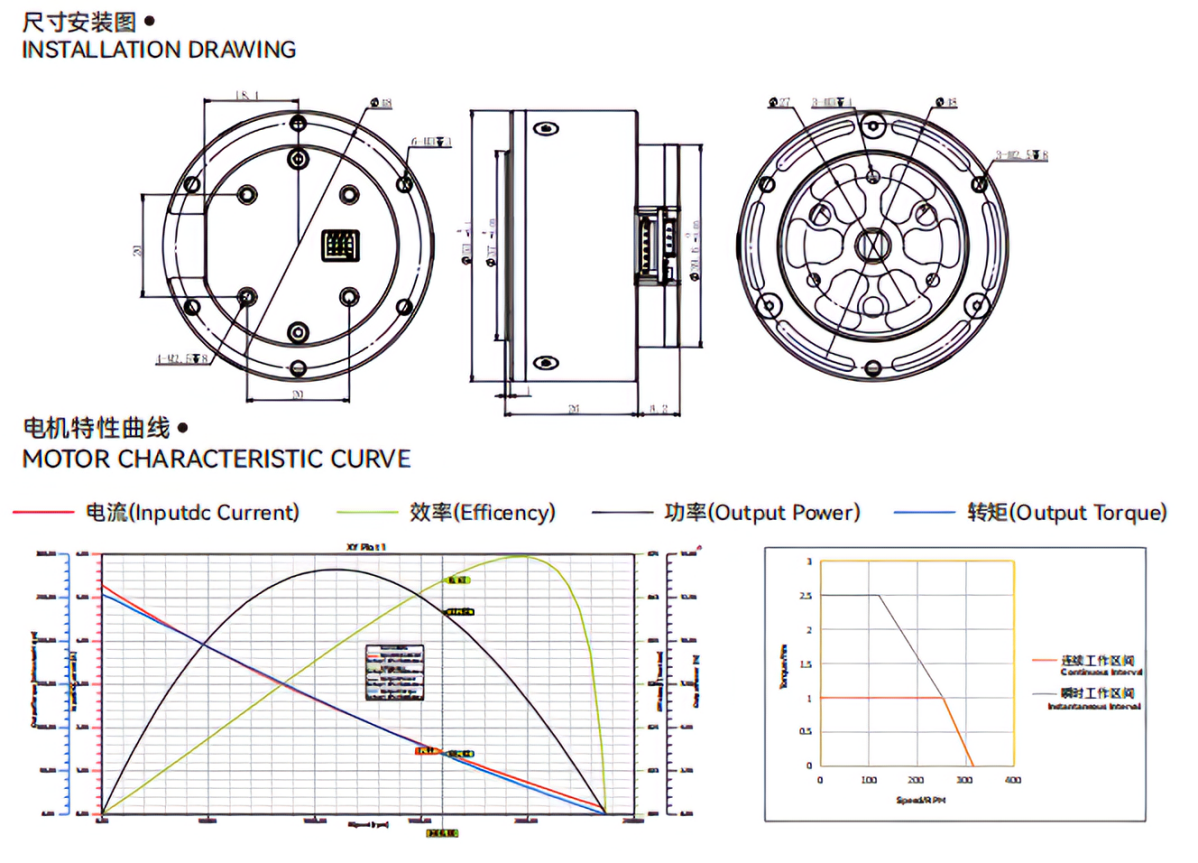
Item Name | T5001-10 |
Rated Voltage (V) | 24 |
Max Speed (rpm) | 316 |
Rated Torque (N.m) | 1 |
Rated Speed (rpm) | 253 |
Rated Current (A) | 1.6 |
Max Power (W) | 14 |
Max Torque (N.m) | 2.5 |
Speed Constant (rpm/V) | 105 |
Torque Constant (N.m/A ) | 0.06 |
Turns | 25 |
Winding Type | Y |
Line Resistance (Ω) | 1.4 |
Phase Inductance (mH) | 0.5 |
Motor Poles | 28 |
Rotor Inertia (gcm²) | 140 |
Motor Temperature | YES |
Reducer Type | PG4210 |
Gear Ratio | 1:10 |
Backlash (arcmin) | ≤10 |
Bearing Rated Load (N) | 1000 |
Motor Weight (g) | 155 |
Recommand Drive | DF40V2 |
Drive Input Voltage (V) | 7.4~32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps)/CAN:2KHz(1Mbps) |
Encoder | 18bit Magnetic Encoder |
Baudrate(RS485)(bps) | 9600、19200、57600、115200、230400、406800、1M、2M |
Baudrate(CAN)(bps) | 100K、125K、250K、500K、1M |
Control Mode | Torque Loop(24KHz) /Speed Loop(8KHz) /Position Loop(4KHz) |
Acceleration Curve | (Trapeziod acceleration) |
Item Name | TS5001-10 |
Rated Voltage (V) | 24 |
Max Speed (rpm) | 320 |
Rated Torque (N.m) | 1 |
Rated Speed (rpm) | 255 |
Rated Current (A) | 1.8 |
Max Power (W) | 65 |
Max Torque (N.m) | 2.5 |
Speed Constant (rpm/V) | 106.3 |
Torque Constant (N.m/A ) | 0.06 |
Turns | 28 |
Winding Type | Y |
Line Resistance (Ω) | 1.4 |
Phase Inductance (mH) | 0.5 |
Motor Poles | 26 |
Rotor Inertia (gcm²) | 140 |
Motor Temperature | -29C-100℃ |
Reducer Type | PG4210 |
Gear Ratio | 1:10 |
Backlash (arcmin) | ≤10 |
Bearing Rated Load (N) | 1000 |
Motor Weight (g) | 183 |
Recommand Drive | DF40 |
Drive Input Voltage (V) | 7.4~32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps)/CAN:2KHz(1Mbps) |
Encoder | 18bit(motor)+14bit(reducer) Magnetic Encoder |
Baudrate(RS485)(bps) | 9600、19200、57600、115200、230400、406800、1M、2M |
Baudrate(CAN)(bps) | 100K、125K、250K、500K、1M |
Control Mode | Torque Loop(24KHz)/Speed Loop(8KHz) /Position Loop(4KHz) |
Acceleration Curve | (Trapeziod acceleration) |
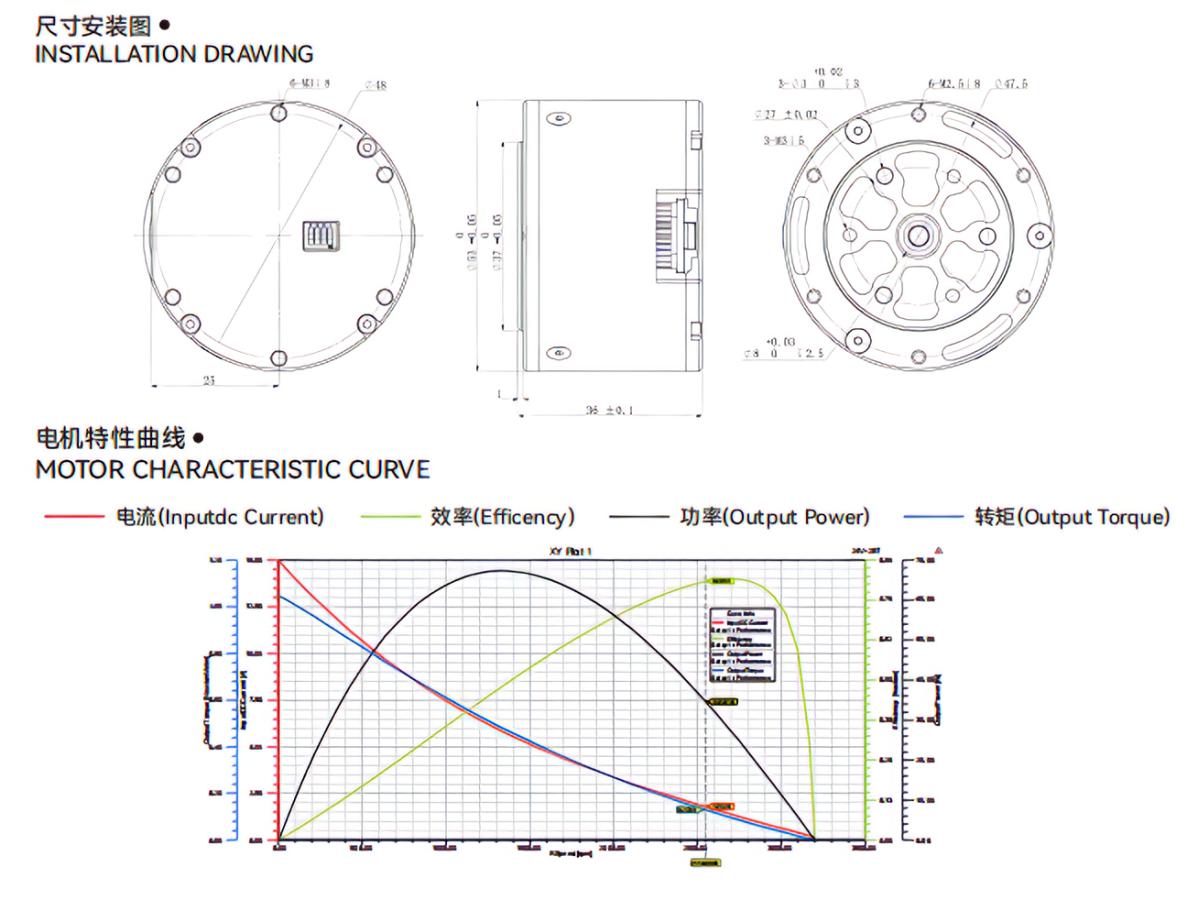
Item Name | TS5003-10 |
Rated Voltage (V) | 24 |
Max Speed (rpm) | 320 |
Rated Torque (N.m) | 3 |
Rated Speed (rpm) | 260 |
Rated Current (A) | 3.5 |
Max Power (W) | 140 |
Max Torque (N.m) | 4.5 |
Speed Constant (rpm/V) | 108.3 |
Torque Constant (N.m/A ) | 0.07 |
Turns | 14 |
Winding Type | Y |
Line Resistance (Ω) | 604 |
Phase Inductance (mH) | 0.28 |
Motor Poles | 26 |
Rotor Inertia (gcm²) | 202 |
Motor Temperature | YES |
Reducer Type | PG4210 |
Gear Ratio | 1:10 |
Backlash (arcmin) | ≤8 |
Bearing Rated Load (N) | 1000 |
Motor Weight (g) | 250 |
Recommand Drive | DG40 |
Drive Input Voltage (V) | 7.4-32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps)/CAN:2KHz(1Mbps) |
Encoder | 18bit(motor)+14bit(reducer) Magnetic Encoder |
Baudrate(RS485)(bps) | 9600、19200、57600、115200、230400、406800、1M、2M |
Baudrate(CAN)(bps) | 100K,125K,250K,500K,1M |
Control Mode | Torque Loop(24KHz) /Speed Loop(8KHz) /Position Loop(4KHz) |
Acceleration Curve | (Trapeziod acceleration) |
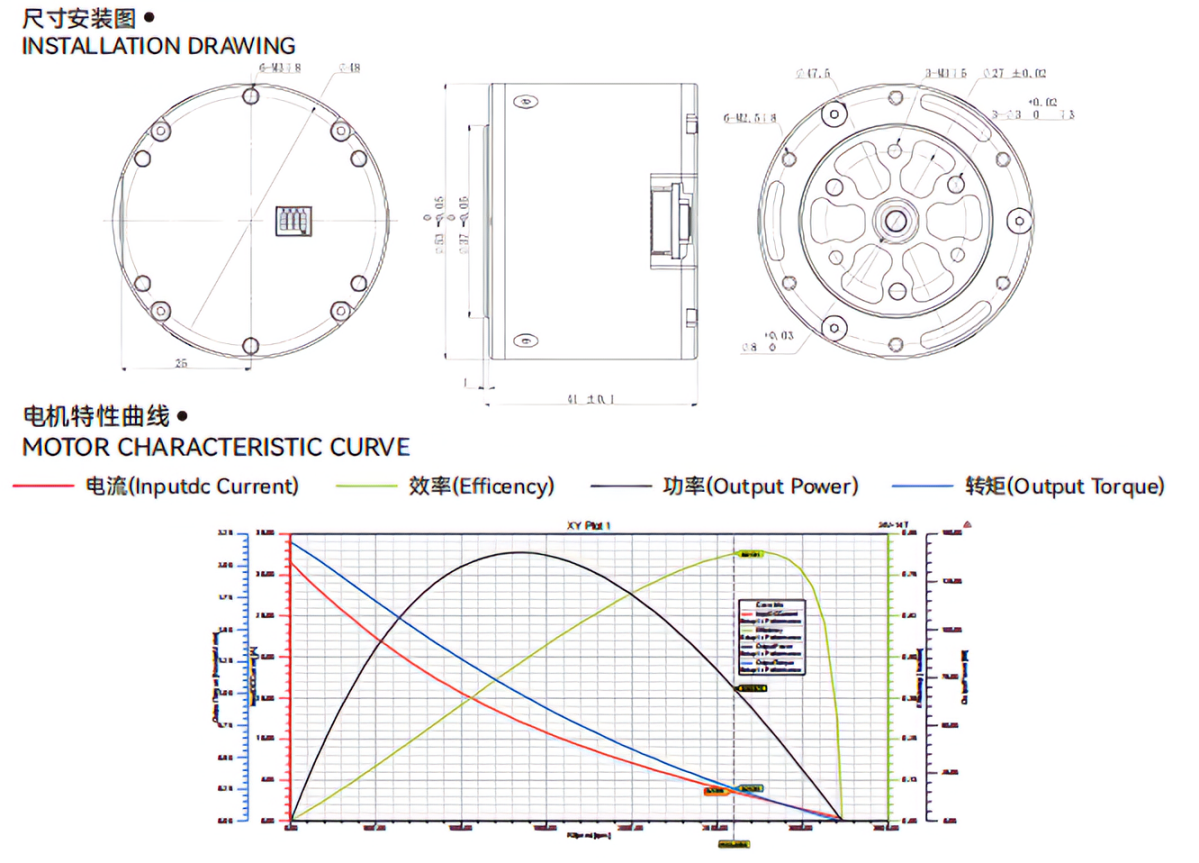
Item Name | TS5003-10B |
Rated Voltage (V) | 24 |
Max Speed (rpm) | 320 |
Rated Torque (N.m) | 3 |
Rated Speed (rpm) | 260 |
Rated Current (A) | 3.5 |
Max Power (W) | 140 |
Max Torque (N.m) | 4.5 |
Speed Constant (rpm/V) | 108.3 |
Torque Constant (N.m/A ) | 0.07 |
Turns | 14 |
Winding Type | 0.604 |
Line Resistance (Ω) | Y |
Phase Inductance (mH) | 0.28 |
Motor Poles | 26 |
Rotor Inertia (gcm²) | 202 |
Motor Temperature | YES |
Reducer Type | PG4210 |
Gear Ratio | 1:10 |
Backlash (arcmin) | ≤8 |
Bearing Rated Load (N) | 1000 |
Motor Weight (g) | 392 |
Brake Type | BG4906 |
Braking torque (N.m) | 3.2 |
Starting voltage (V) | 24 |
Maintain voltage (V) | 7 |
Sustained power (W) | 1.4 |
Recommand Drive | DG40 |
Drive Input Voltage (V) | 7.4-32 |
Communication | PS4850rCAN |
Communication Frequency (Hz) | RS485: 500Hz(115200bps)/CAN:2KHz(1Mbps) |
Encoder | 18 bit Magnetic Encoder |
Baudrate(RS485)(bps) | 9600、19200、57600、115200、230400、406800、1M、2M |
Baudrate(CAN)(bps) | 100K、125K、250K、500K、1M |
Control Mode | Torque Loop(24KHz)/Speed Loop(8KHz) /Position Loop(4KHz) |
Acceleration Curve | (Trapeziod acceleration) |
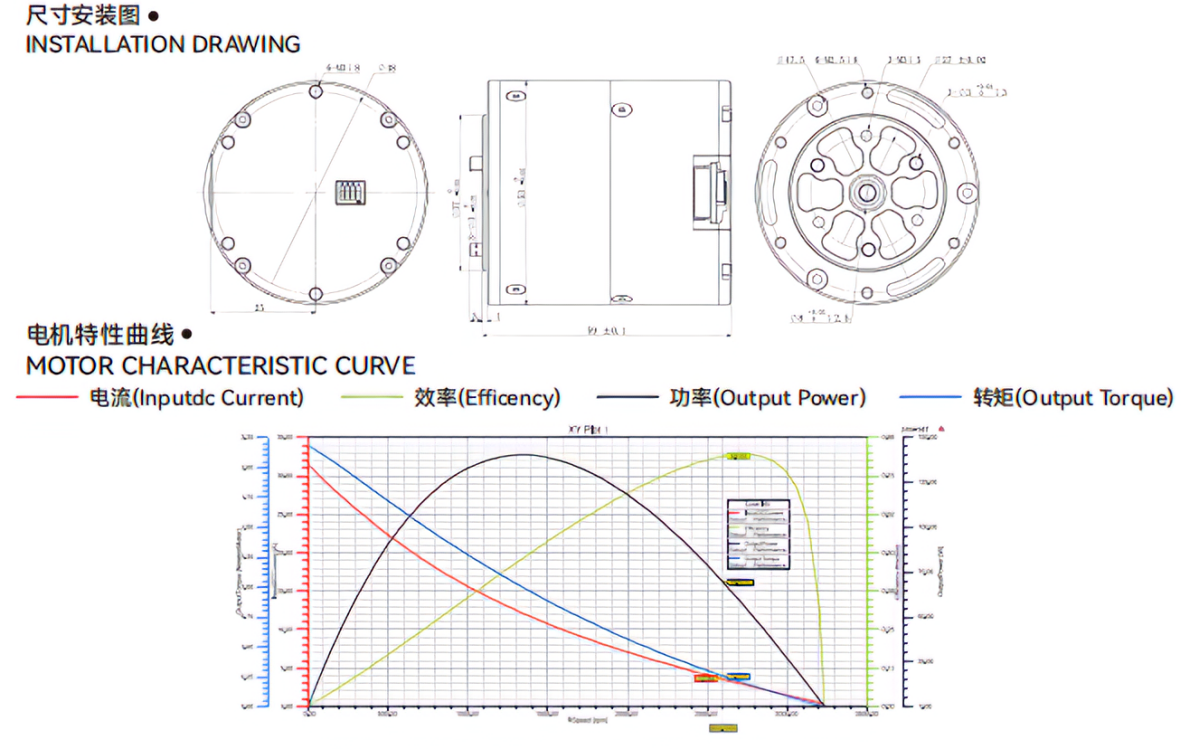
Item Name | TS5009-36 |
Rated Voltage (V) | 24 |
Max Speed (rpm) | 90 |
Rated Torque (N.m) | 9 |
Rated Speed (rpm) | 72 |
Rated Current (A) | 3.5 |
Max Power (W) | 135 |
Max Torque (N.m) | 18 |
Speed Constant (rpm/V) | 3 |
Torque Constant (N.m/A ) | 2.58 |
Turns | 14 |
Winding Type | X |
Line Resistance (Ω) | 0.65 |
Phase Inductance (mH) | 0.25 |
Motor Poles | 28 |
Rotor Inertia (gcm²) | 1 |
Motor Temperature | YES |
Reducer Type | PG5336 |
Gear Ratio | 1:36 |
Backlash (arcmin) | ≤6 |
Bearing Rated Load (N) | 1120 |
Motor Weight (g) | 350 |
Recommand Drive | DG40V3 |
Drive Input Voltage (V) | 12~24 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps)/CAN:2KHz(1Mbps) |
Encoder | 18bit(motor)+14bit(reducer) Magnetic Encoder |
Baudrate(RS485)(bps) | 9600、19200、57600、115200、230400、406800、1M、2M |
Baudrate(CAN)(bps) | 100K,125K,250K,500K,1M |
Control Mode | Torque Loop(24KHz) /Speed Loop(8KHz) /Position Loop(4KHz) |
Acceleration Curve | (Trapeziod acceleration) |
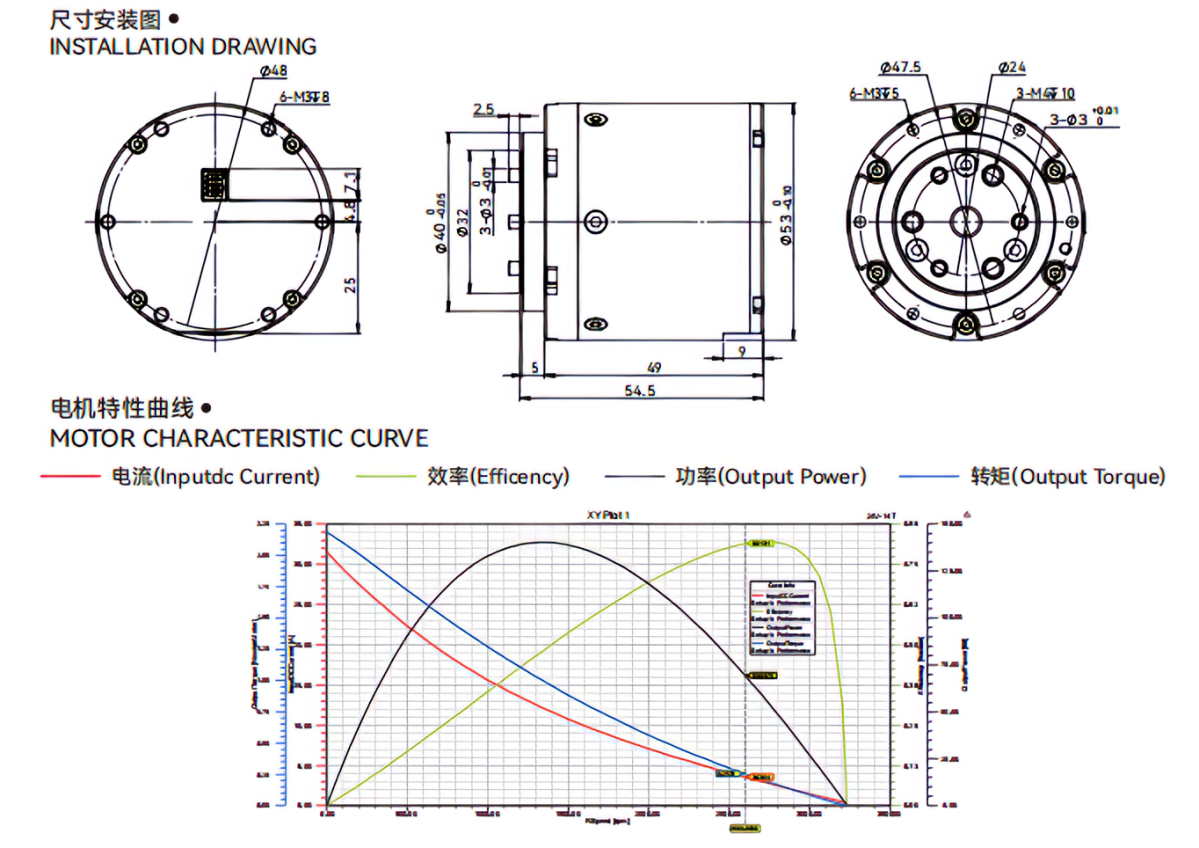
Item Name | TS5009-36B |
Rated Voltage (V) | 24 |
Max Speed (rpm) | 90 |
Rated Torque (N.m) | 9 |
Rated Speed (rpm) | 72 |
Rated Current (A) | 3.5 |
Max Power (W) | 135 |
Max Torque (N.m) | 18 |
Speed Constant (rpm/V) | 3 |
Torque Constant (N.m/A ) | 2.58 |
Turns | 14 |
Winding Type | Y |
Line Resistance (Ω) | 0.65 |
Phase Inductance (mH) | 0.25 |
Motor Poles | 28 |
Rotor Inertia (gcm²) | 158 |
Motor Temperature | YES |
Reducer Type | PG4210 |
Gear Ratio | 1:36 |
Backlash (arcmin) | ≤6 |
Bearing Rated Load (N) | 1120 |
Motor Weight (g) | 542.5 |
Brake Type | BG4906 |
Braking torque (N.m) | 0.6 |
Starting voltage (V) | 24 |
Maintain voltage (V) | 7 |
Sustained power (W) | 1.4 |
Recommand Drive | DG40 |
Drive Input Voltage (V) | 12~24 |
Communication | RS485OrCAN |
Communication Frequency (Hz) | RS485:500Hz(115200bps)/CAN:2KHz(1Mbps) |
Encoder | 18bit(motor)+14bit(reducer)MagneticEncoder |
Baudrate(RS485)(bps) | 9600、19200、57600、115200、230400、406800、1M、2M |
Baudrate(CAN)(bps) | 100K、125K、250K、500K、1M |
Control Mode | TorqueLoop(24KHz)/SpeedLoop(8KHz)/PositionLoop(4KHz) |
Acceleration Curve | Trapeziod acceleration) |
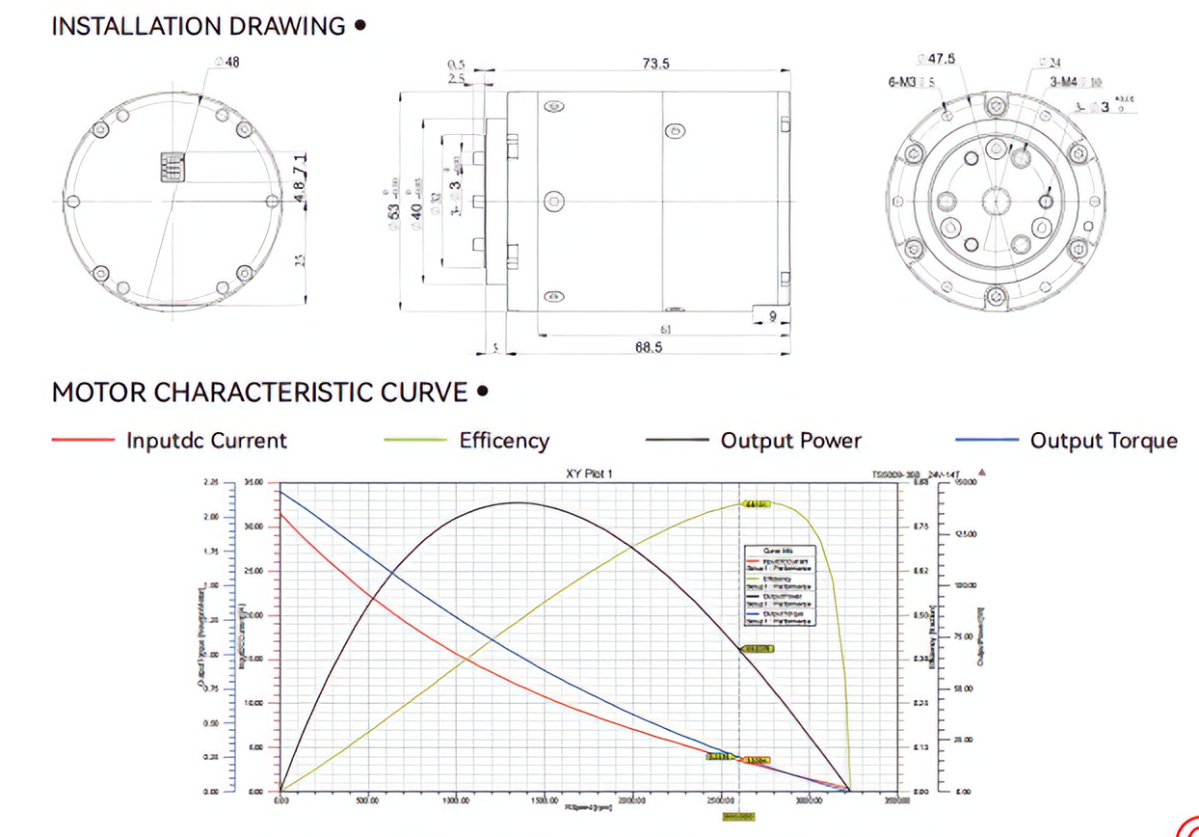
Item Name | TS6004-10 |
Rated Voltage (V) | 24 |
Max Speed (rpm) | 320 |
Rated Torque (N.m) | 4 |
Rated Speed (rpm) | 235 |
Rated Current (A) | 4.4 |
Max Power (W) | 160 |
Max Torque (N.m) | 7 |
Speed Constant (rpm/V) | 97.9 |
Torque Constant (N.m/A ) | 0.1 |
Turns | 13 |
Winding Type | Y |
Line Resistance (Ω) | 0.466 |
Phase Inductance (mH) | 0.26 |
Motor Poles | 28 |
Rotor Inertia (gcm²) | 850 |
Motor Temperature | YES |
Reducer Type | PG5110 |
Gear Ratio | 1:10 |
Backlash (arcmin) | ≤8 |
Bearing Rated Load (N) | 100 |
Motor Weight (g) | 420 |
Recommand Drive | DG50 |
Drive Input Voltage (V) | 7.4-32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps)/CAN:2KHz(1Mbps) |
Encoder | 18bit(motor)+14bit(reducerMagneticEncoder |
Baudrate(RS485)(bps) | 9600、19200、57600、115200、230400、406800、1M、2M |
Baudrate(CAN)(bps) | 100K、125K、250K、500K、1M |
Control Mode | Torque Loop(24KHz) /Speed Loop(8KHz)/Position Loop(4KHz) |
Acceleration Curve | (Trapeziod acceleration) |
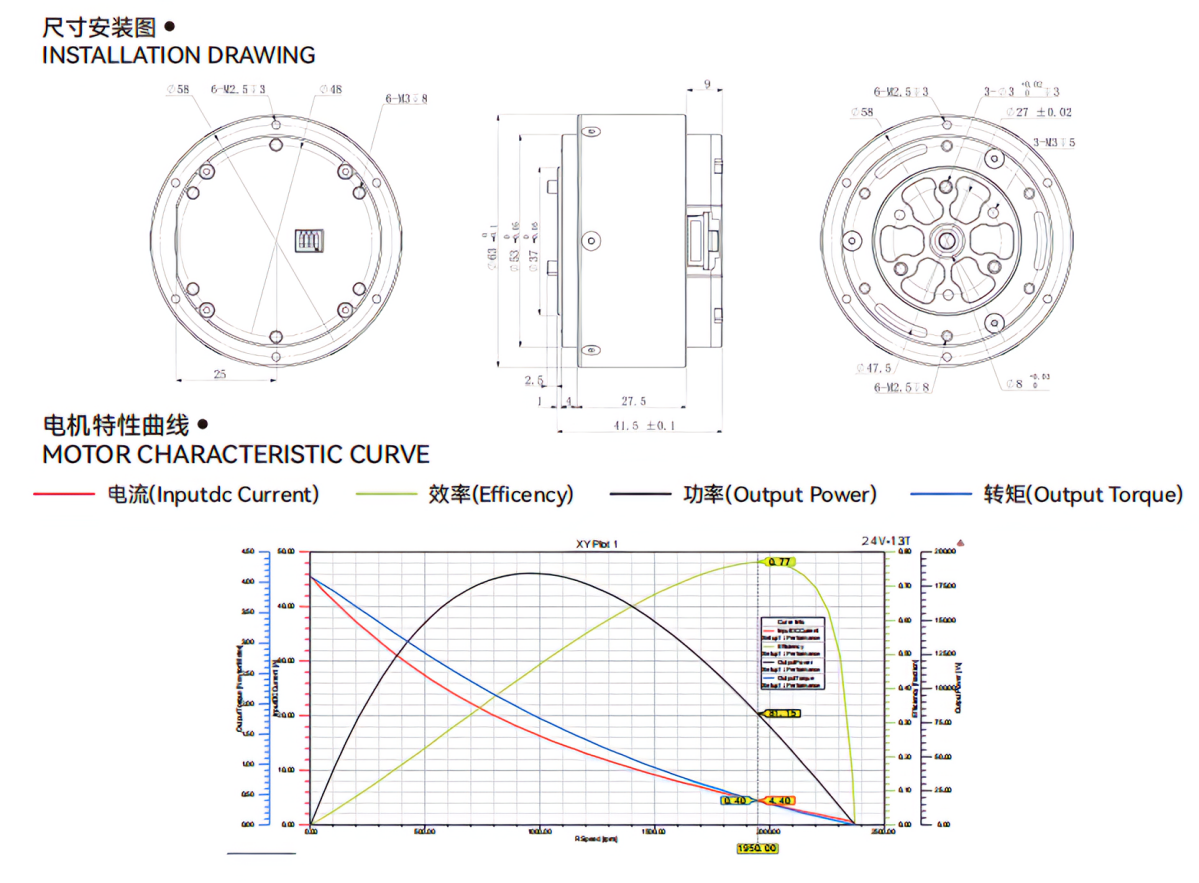
Item Name | TS6013-36 |
Rated Voltage (V) | 24 |
Max Speed (rpm) | 74 |
Rated Torque (N.m) | 13 |
Rated Speed (rpm) | 54 |
Rated Current (A) | 4.4 |
Max Power (W) | 160 |
Max Torque (N.m) | 25 |
Speed Constant (rpm/V) | 22.5 |
Torque Constant (N.m/A ) | 0.3 |
Turns | 13 |
Winding Type | Y |
Line Resistance (Ω) | 0.466 |
Phase Inductance (mH) | 0.26 |
Motor Poles | 28 |
Rotor Inertia (gcm²) | 850 |
Motor Temperature | YES |
Reducer Type | PG5110 |
Gear Ratio | 1:36 |
Backlash (arcmin) | $12 |
Bearing Rated Load (N) | 1050 |
Motor Weight (g) | 460 |
Recommand Drive | DG50v1 |
Drive Input Voltage (V) | 7.4-32 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps)/CAN:2KHz(1Mbps) |
Encoder | 18bit Magnetic Encoder |
Baudrate(RS485)(bps) | 9600、19200、57600、115200、230400、406800、1M、2M |
Baudrate(CAN)(bps) | 100K、125K、250K、500K、1M |
Control Mode | Torque Loop(32KHz)/Speed Loop(8KHz) /Position Loop(4KHz) |
Acceleration Curve | (Trapeziod acceleration) |
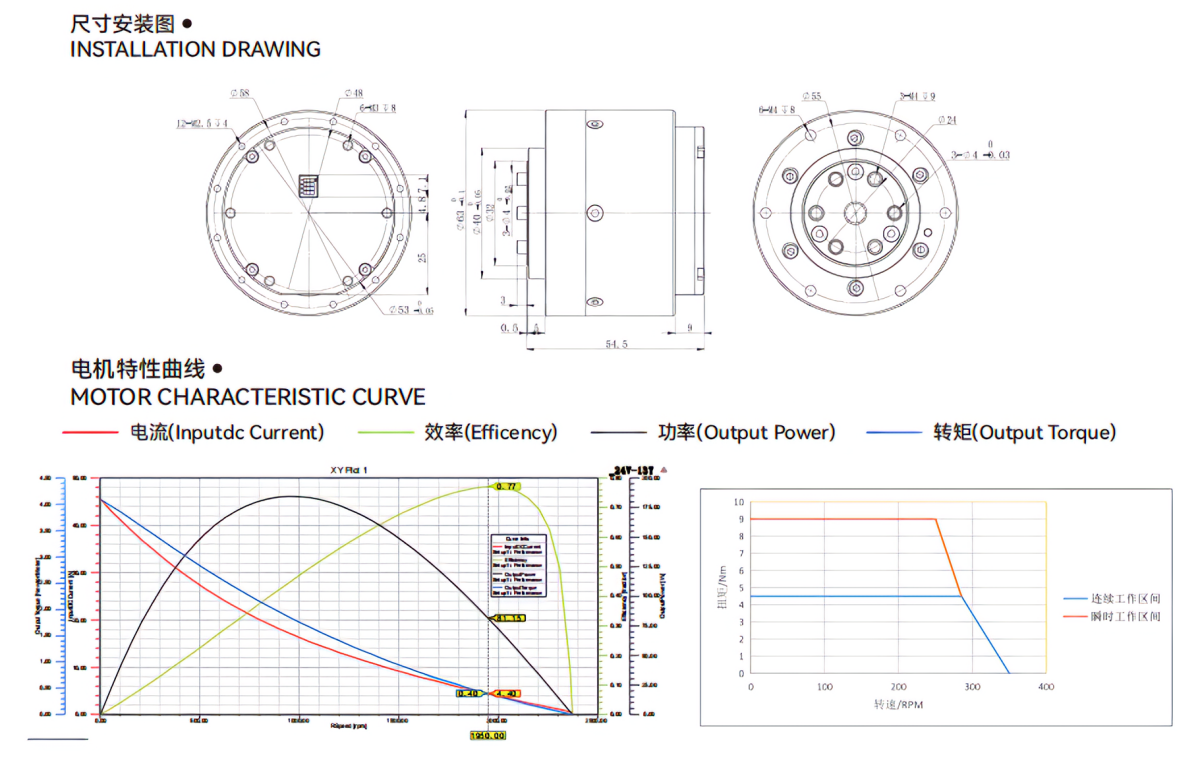
Item Name | TS7005-6 |
Rated Voltage (V) | 24 48 |
Max Speed (rpm) | 251 505 |
Rated Torque (N.m) | 5 5 |
Rated Speed (rpm) | 170 391 |
Rated Current (A) | 5.5 5.3 |
Max Power (W) | 120 400 |
Max Torque (N.m) | 10 10 |
Speed Constant (rpm/V) | 62.9 62.9 |
Torque Constant (N.m/A ) | 0.16 0.16 |
Turns | 20 20 |
Winding Type | Y Y |
Line Resistance (Ω) | 0.56 0.56 |
Phase Inductance (mH) | 0.57 0.57 |
Motor Poles | 28 28 |
Rotor Inertia (gcm²) | 805 805 |
Motor Temperature | YES YES |
Reducer Type | PG4106 |
Gear Ratio | 1:06 |
Backlash (arcmin) | ≤6 |
Bearing Rated Load (N) | 900 |
Motor Weight (g) | 343 |
Recommand Drive | DG60v2/DG60Ev2 |
Drive Input Voltage (V) | 12~60 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps)/CAN:2KHz(1Mbps) |
Encoder | 8bit Magnetic Encoder /18bit(motor+14bit(educerMagneticEnoder |
Baudrate(RS485)(bps) | 9600、19200、57600、115200、230400、406800、1M、2M |
Baudrate(CAN)(bps) | 100K、125K、250K、500K、1M |
Control Mode | Torque Loop(32KHz)/Speed Loop(8KHz) /Position Loop(4KHz) |
Acceleration Curve | (Trapeziod acceleration) |
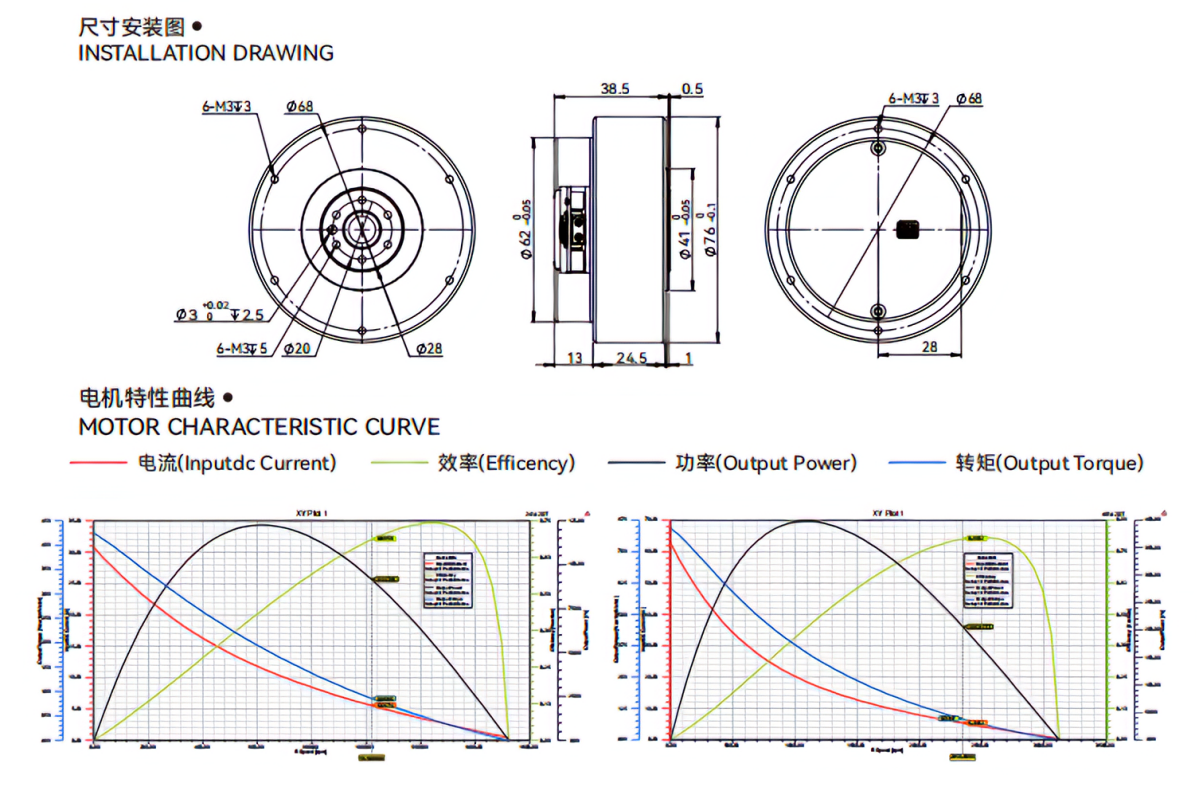
Item Name | TS7006-8 |
Rated Voltage (V) | 48 |
Max Speed (rpm) | 310 |
Rated Torque (N.m) | 6 |
Rated Speed (rpm) | 256 |
Rated Current (A) | 3.5 |
Max Power (W) | 294 |
Max Torque (N.m) | 16 |
Speed Constant (rpm/V) | 42.7 |
Torque Constant (N.m/A ) | 1.09 |
Turns | 20 |
Winding Type | Y |
Line Resistance (Ω) | 1.3 |
Phase Inductance (mH) | 0.55 |
Motor Poles | 28 |
Rotor Inertia (gcm²) | 930 |
Motor Temperature | YES |
Reducer Type | PG4108 |
Gear Ratio | 1:8 |
Backlash (arcmin) | ≤6 |
Bearing Rated Load (N) | 906 |
Motor Weight (g) | 430 |
Recommand Drive | DG60v2/DG60Ev2 |
Drive Input Voltage (V) | 12~60 |
Communication | RS485 Or CAN |
Communication Frequency (Hz) | RS485:500Hz (115200bps)/CAN:2KHz(1Mbps) |
Encoder | 8bit Magnetic Encoder /18bit(motor+14bit(educerMagneticEnoder |
Baudrate(RS485)(bps) | 9600、19200、57600、115200、230400、406800、1M、2M |
Baudrate(CAN)(bps) | 100K、125K、250K、500K、1M |
Control Mode | Torque Loop(32KHz)/Speed Loop(8KHz) /Position Loop(4KHz) |
Acceleration Curve | (Trapeziod acceleration) |
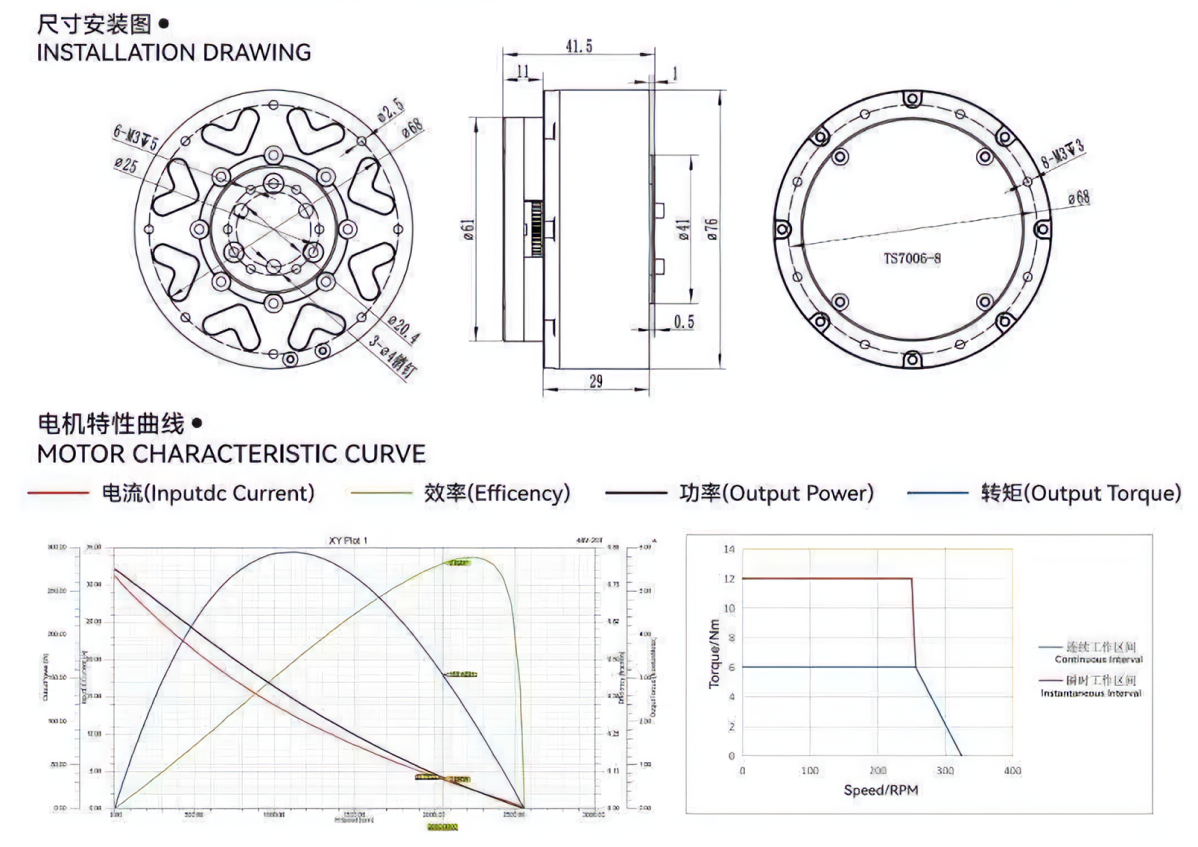
Item Name | TS8006-8 |
Rated Voltage (V) | 48 |
Max Speed (rpm) | 310 |
Rated Torque (N.m) | 6 |
Rated Speed (rpm) | 256 |
Rated Current (A) | 3.5 |
Max Power (W) | 294 |
Max Torque (N.m) | 16 |
Speed Constant (rpm/V) | 42.7 |
Torque Constant (N.m/A ) | 1.09 |
Turns | 20 |
Winding Type | Y |
Line Resistance (Ω) | 1.3 |
Phase Inductance (mH) | 0.55 |
Motor Poles | 28 |
Rotor Inertia (gcm²) | 930 |
Motor Temperature | YES |
Reducer Type | PG4108 |
Gear Ratio | 1:08 |
Backlash (arcmin) | ≤6 |
Bearing Rated Load (N) | 906 |
Motor Weight (g) | 430 |
Recommand Drive | DG60v2/ DG60Ev2 |
Drive Input Voltage (V) | 12~60 |
Communication | RS485 Or CAN |
Communication frequency | RS485: 500Hz (115200bps)/CAN:2KHz(1Mbps) |
Encoder resolution | 18bit Magnetic Encoder 18bit(motor) +14bit(reducer) Magnetic Encoder |
Baudrate(RS485)(bps) | 9600、19200、57600、115200、230400、406800、1M、2M |
Baudrate(CAN)(bps) | 100K、125K、250K、500K、1M |
Control Mode | Torque Loop(32KHz) /Speed Loop(8KHz) /Position Loop(4KHz) |
Acceleration Curve | (Trapeziod acceleration) |