




BLACjourney
Miniature servo electric cylinder
Product Introduction
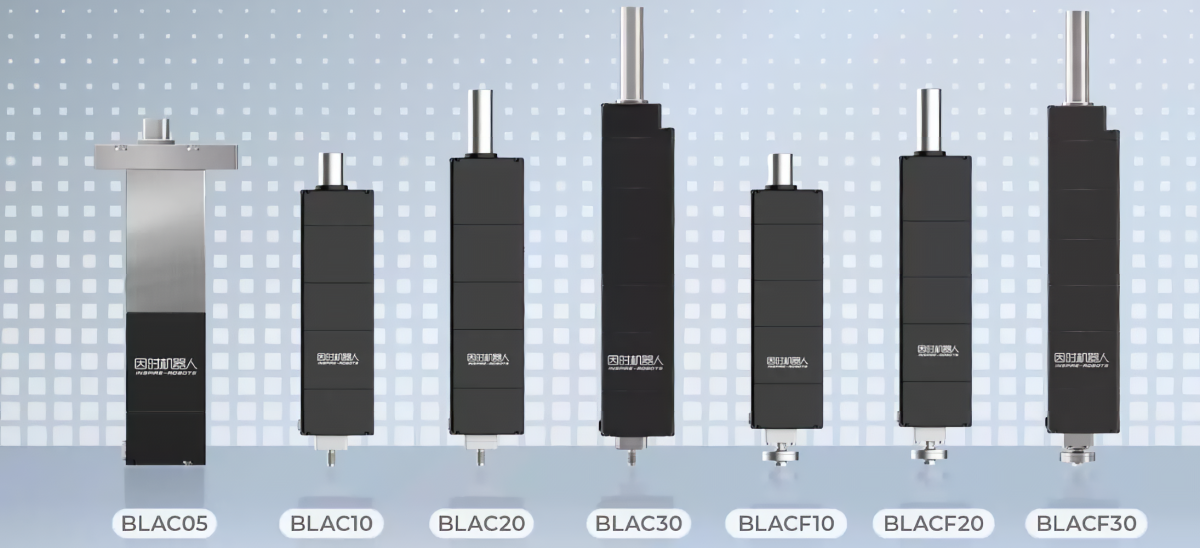
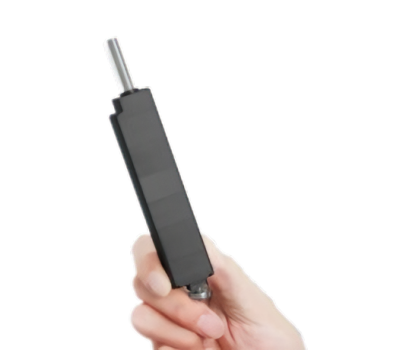
A micro servo electric cylinder—also known as an integrated linear actuator—is a compact, all-in-one linear servo system that serves as a core motion component for precision electromechanical equipment such as robots, industrial machinery, and medical devices. It integrates a coreless motor, precision gear reducer, lead screw drive mechanism, sensors, and a closed-loop control system. Characterized by its compact size, high precision, and high power density, it enables precise servo control at any position within its travel range. It features a built-in absolute position sensor, ensuring that position data is retained after power loss and eliminating the need for a homing procedure.
Core Advantages
| ●Compact size ●High precision ●Force control ●High power density ●Integration of drive and control |
|
Product Specifications
BLAC05
Standard Parameters
journey | weight | Operating voltage | Repeat positioning accuracy | Operating temperature | Quiescent current | Peak current | IP Rating |
5mm | 160g | DC12V±10% | ±0.02mm | -10°C~+60°℃ | 55mA | 1.4A | IP40 |
Other parameters
Maximum push-pull force | Stall push-pull force | Maximum self-locking force | No-load speed | Full-load speed | No-load current | Communication interface | Electric motor |
250N | 300N | 150N | 2.4mm/s | 2mm/s | 200mA | RS485 | Coreless Brushless DC Motor |
BLAC10
Standard Parameters
journey | weight | Operating voltage | Repeat positioning accuracy | Operating temperature | Quiescent current | Peak current | IP Rating |
10mm | 92g | DC12V±10% | ±0.01mm | -10°C~+60°℃ | 55mA | 2A | IP40 |
Other parameters
Maximum push-pull force | Stall push-pull force | Maximum self-locking force | No-load speed | Full-load speed | No-load current | Communication interface | Electric motor |
120N | 150N | 40N | 32mm/s | 16mm/s | 600mA | RS485 | Coreless Brushless DC Motor |
BLAC20
Standard Parameters
journey | weight | Operating voltage | Repeat positioning accuracy | Operating temperature | Quiescent current | Peak current | IP Rating |
20mm | 99g | DC12V±10% | ±0.01mm | -10°C~+60°℃ | 55mA | 2A | IP40 |
Other parameters
Maximum push-pull force | Stall push-pull force | Maximum self-locking force | No-load speed | Full-load speed | No-load current | Communication interface | Electric motor |
120N | 150N | 40N | 32mm/s | 16mm/s | 600mA | RS485 | Coreless Brushless DC Motor |
BLAC30
Standard Parameters
journey | weight | Operating voltage | Repeat positioning accuracy | Operating temperature | Quiescent current | Peak current | IP Rating |
30mm | 113g | DC12V±10% | ±0.01mm | -10°C~+60°℃ | 55mA | 2A | IP40 |
Other parameters
Maximum push-pull force | Stall push-pull force | Maximum self-locking force | No-load speed | Full-load speed | No-load current | Communication interface | Electric motor |
120N | 150N | 40N | 32mm/s | 16mm/s | 600mA | RS485 | Coreless Brushless DC Motor |
BLACF10
Standard Parameters
journey | weight | Operating voltage | Repeat positioning accuracy | Operating temperature | Quiescent current | Peak current | Force sensor detection range | Force sensor resolution | IP Rating |
10mm | 97g | DC12V±10% | ±0.01mm | -10°℃C~+60°C | 65mA | 2A | -200N~+200N | 1N | IP40 |
Other parameters
Maximum push-pull force | Stall push-pull force | Maximum self-locking force | No-load speed | Full-load speed | No-load current | Communication interface | Electric motor |
120N | 150N | 40N | 32mm/s | 16mm/s | 600mA | RS485 | Coreless Brushless DC Motor |
BLACF20
Standard Parameters
journey | weight | Operating voltage | Repeat positioning accuracy | Operating temperature | Quiescent current | Peak current | Force sensor detection range | Force sensor resolution | IP Rating |
20mm | 104g | DC12V±10% | ±0.01mm | -10°℃C~+60°C | 65mA | 2A | -200N~+200N | 1N | IP40 |
Other parameters
Maximum push-pull force | Stall push-pull force | Maximum self-locking force | No-load speed | Full-load speed | No-load current | Communication interface | Electric motor |
120N | 150N | 40N | 32mm/s | 16mm/s | 600mA | RS485 | Coreless Brushless DC Motor |
BLACF30
Standard Parameters
journey | weight | Operating voltage | Repeat positioning accuracy | Operating temperature | Quiescent current | Peak current | Force sensor detection range | Force sensor resolution | IP Rating |
30mm | 120g | DC12V±10% | ±0.01mm | -10°℃C~+60°C | 65mA | 2A | -200N~+200N | 1N | IP40 |
Other parameters
Maximum push-pull force | Stall push-pull force | Maximum self-locking force | No-load speed | Full-load speed | No-load current | Communication interface | Electric motor |
120N | 150N | 40N | 32mm/s | 16mm/s | 600mA | RS485 | Coreless Brushless DC Motor |
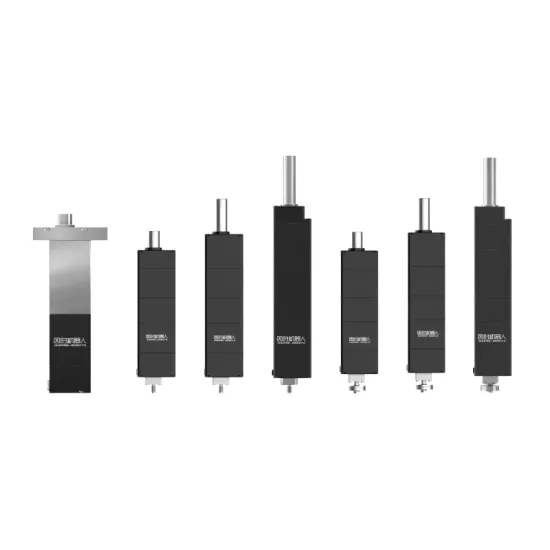
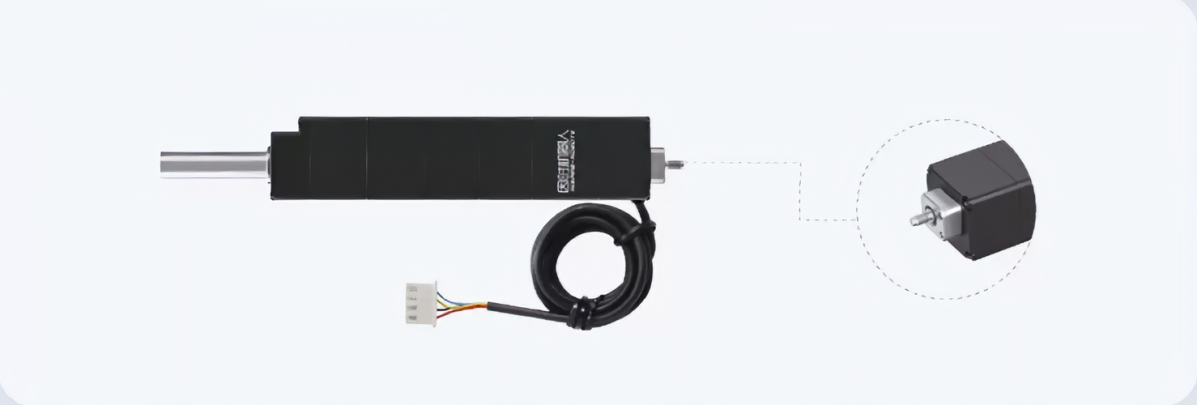
Photo of the actual product
BLAC05
[Flange Connection]
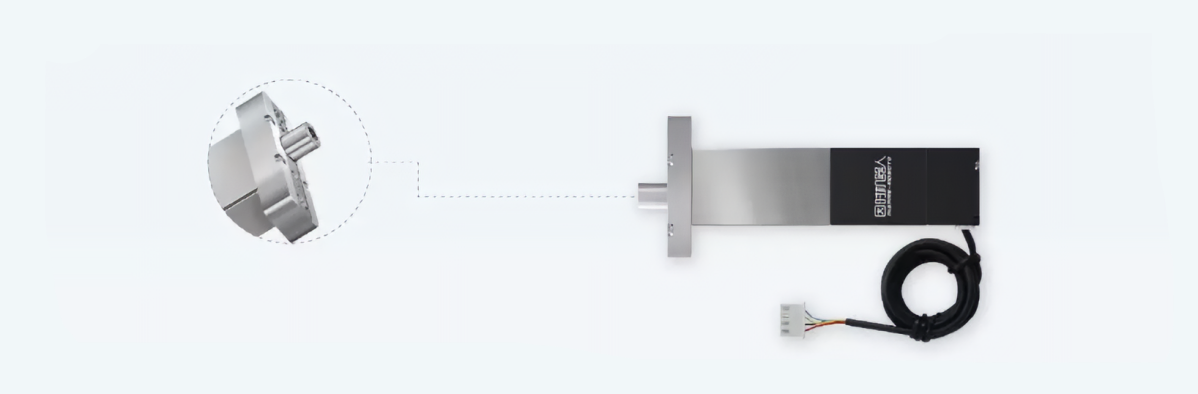
BLAC10
[Octagonal Port]
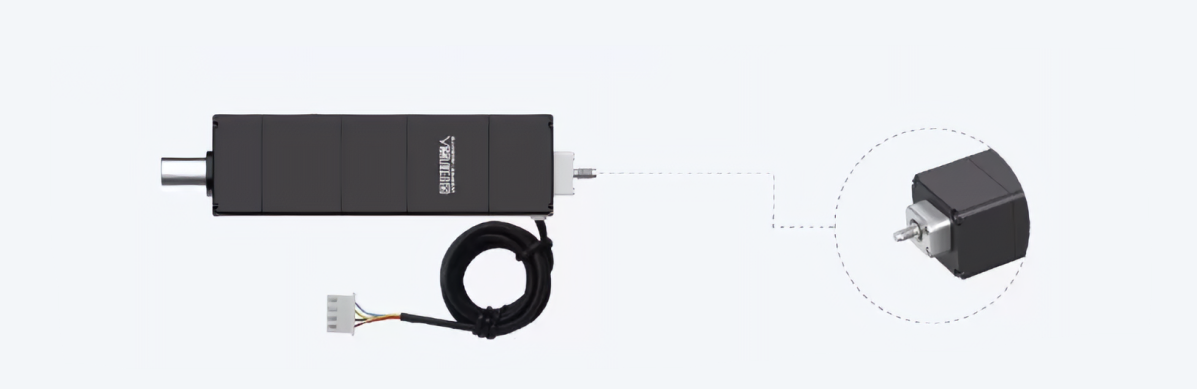
BLAC20
[Octagonal Port]
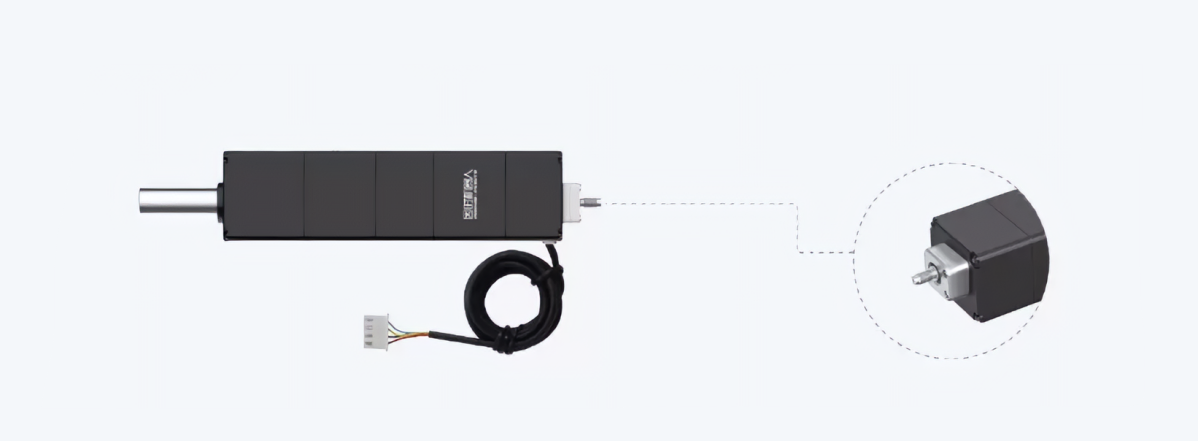
BLAC30
[Octagonal Port]
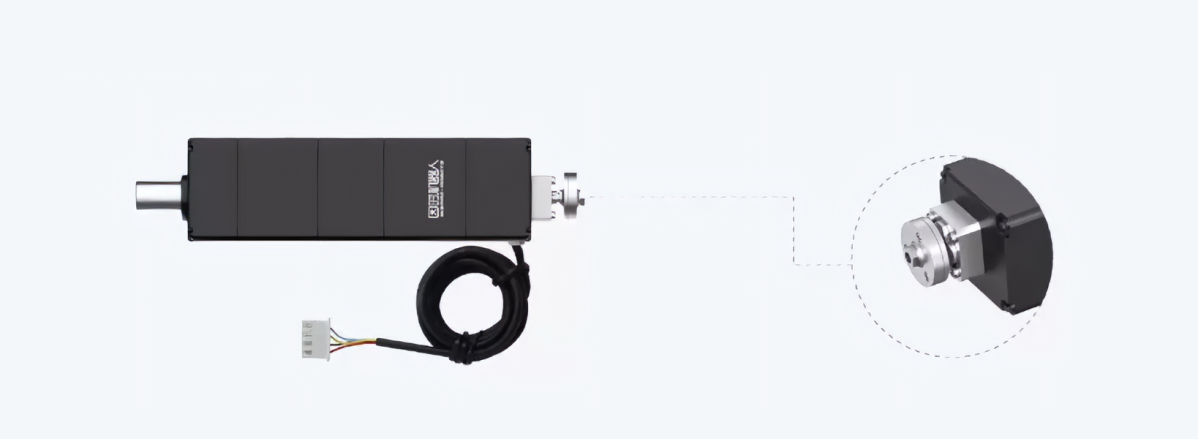
BLACF10
[Spherical Plain Bearing Interface]
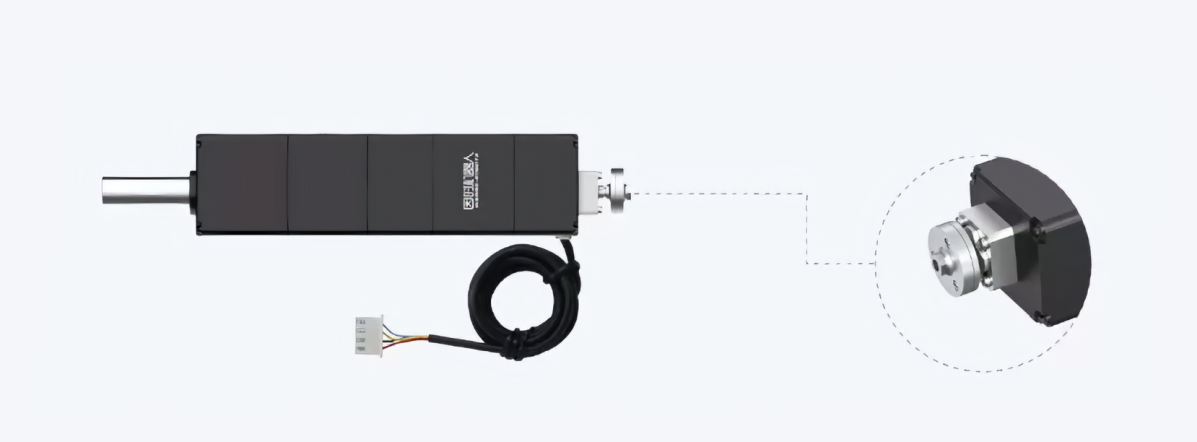
BLACF20
[Spherical Plain Bearing Interface]
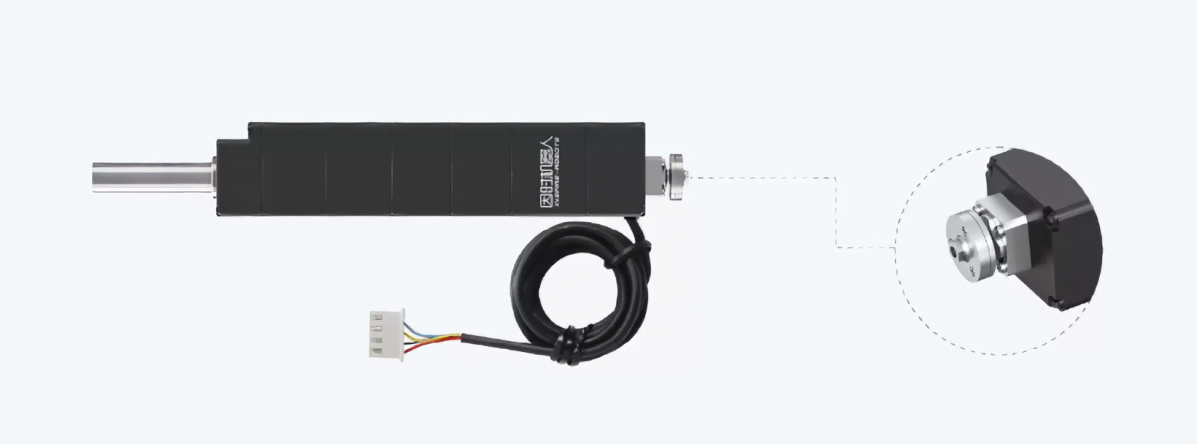
BLACF30
[Spherical Plain Bearing Interface]
Dimensional Drawing
BLAC05
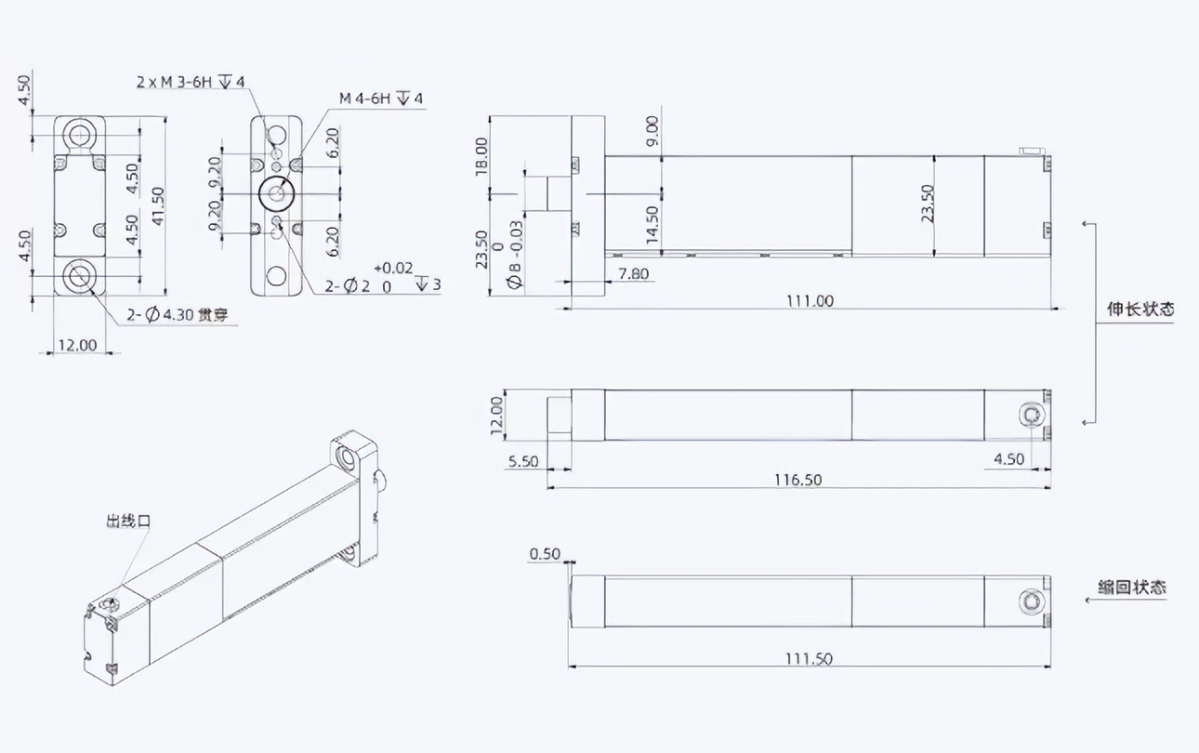
| Cable size/mm | |
diameter | 3 |
| length | 400 |
BLAC10
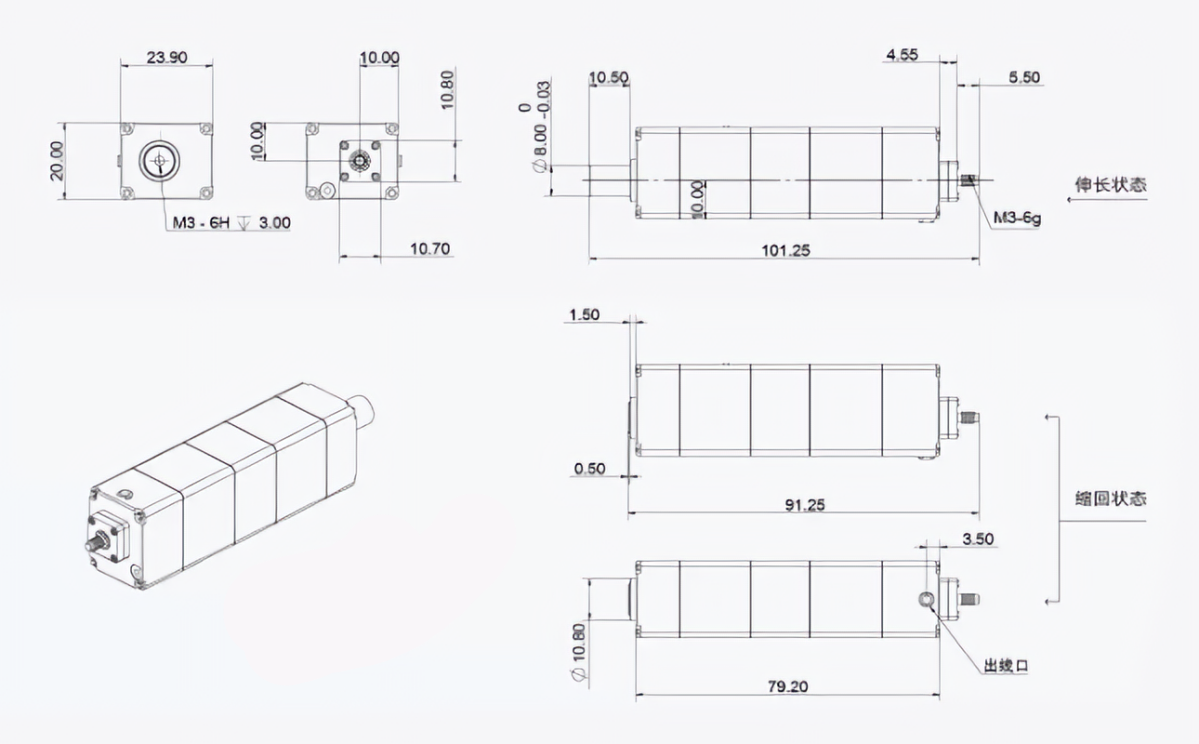
| Cable size/mm | |
diameter | 2.3 |
| length | 200 |
BLAC20
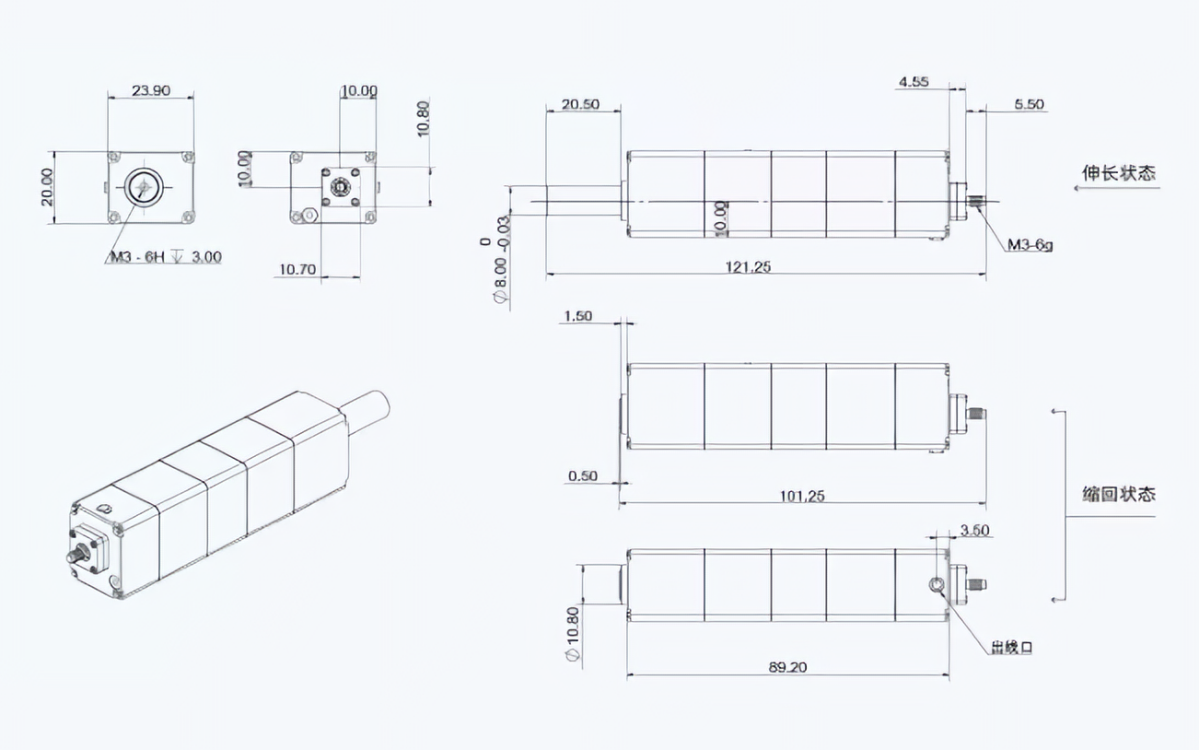
| Cable size/mm | |
diameter | 2.3 |
| length | 200 |
BLAC30
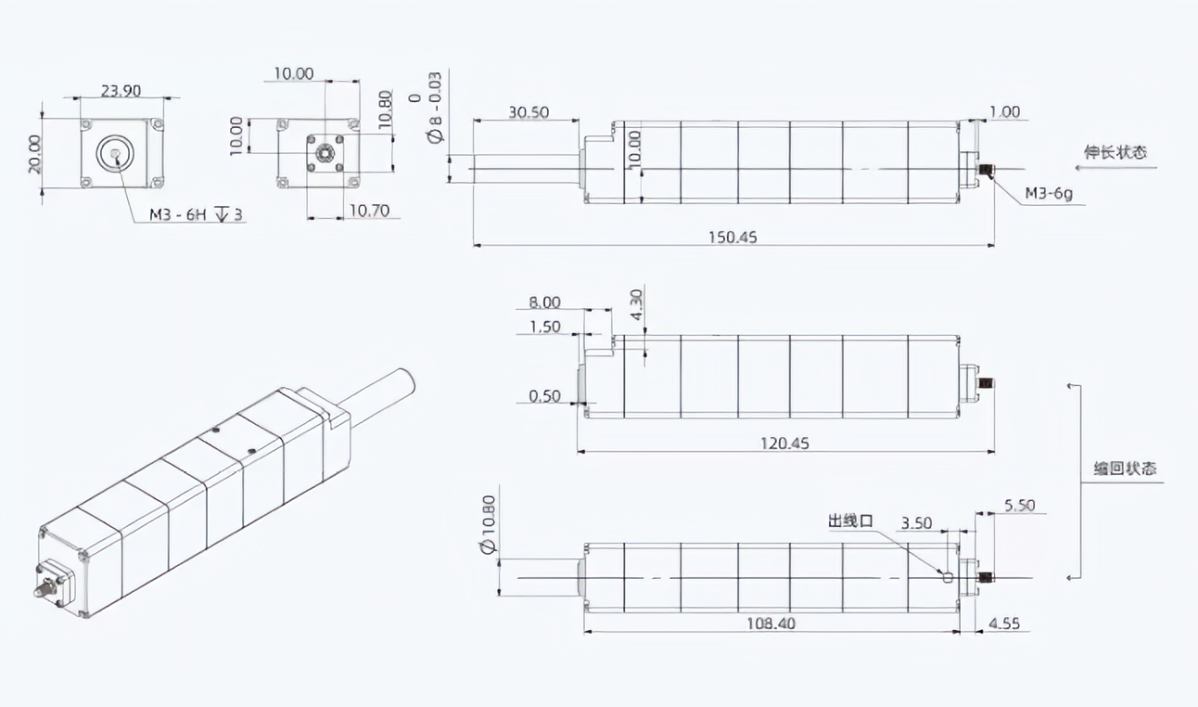
| Cable size/mm | |
diameter | 2.3 |
| length | 200 |
BLACF10
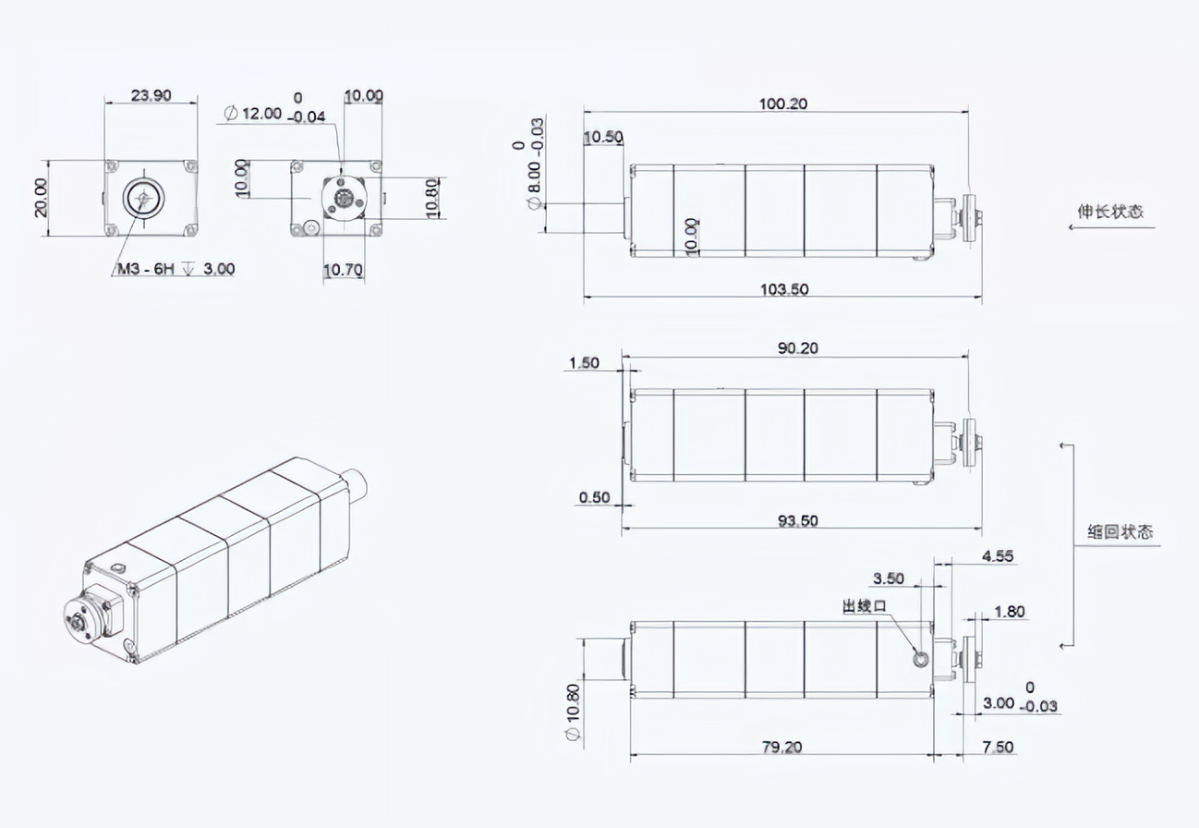
| Cable size/mm | |
diameter | 2.3 |
| length | 400 |
BLACF20
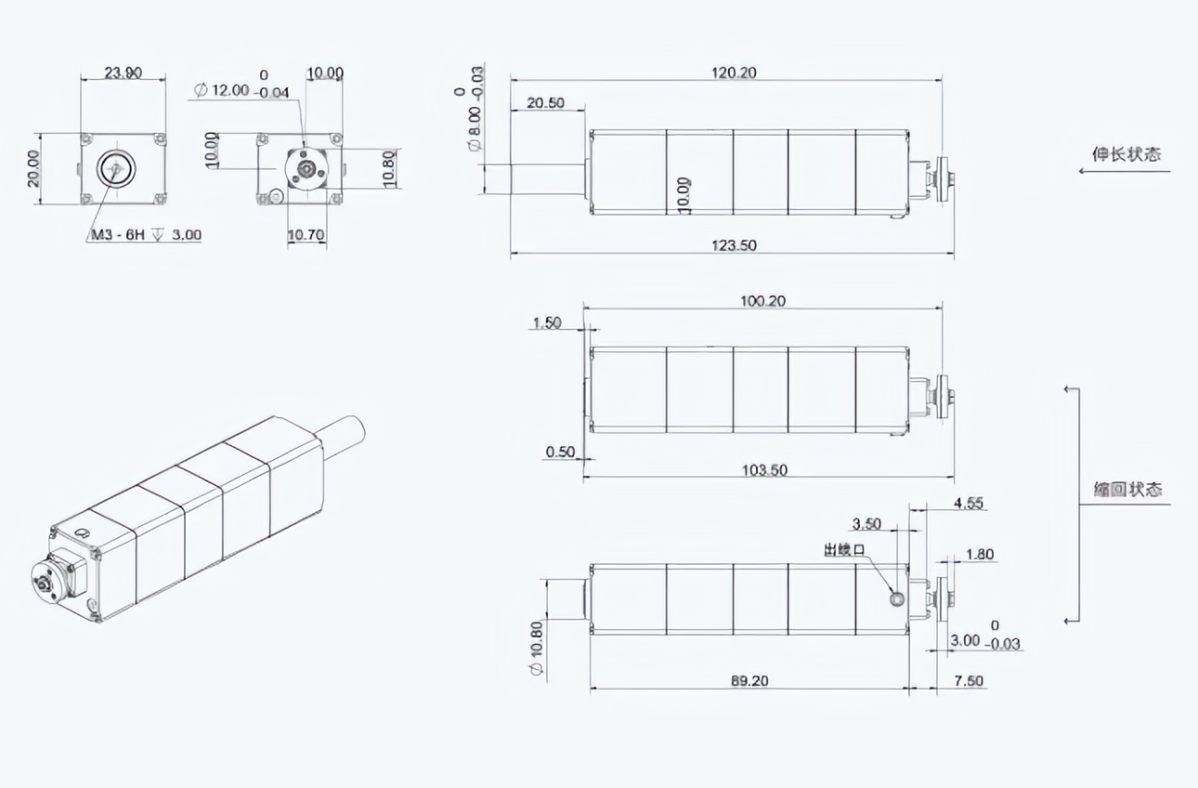
| Cable size/mm | |
diameter | 2.3 |
| length | 400 |
BLACF30
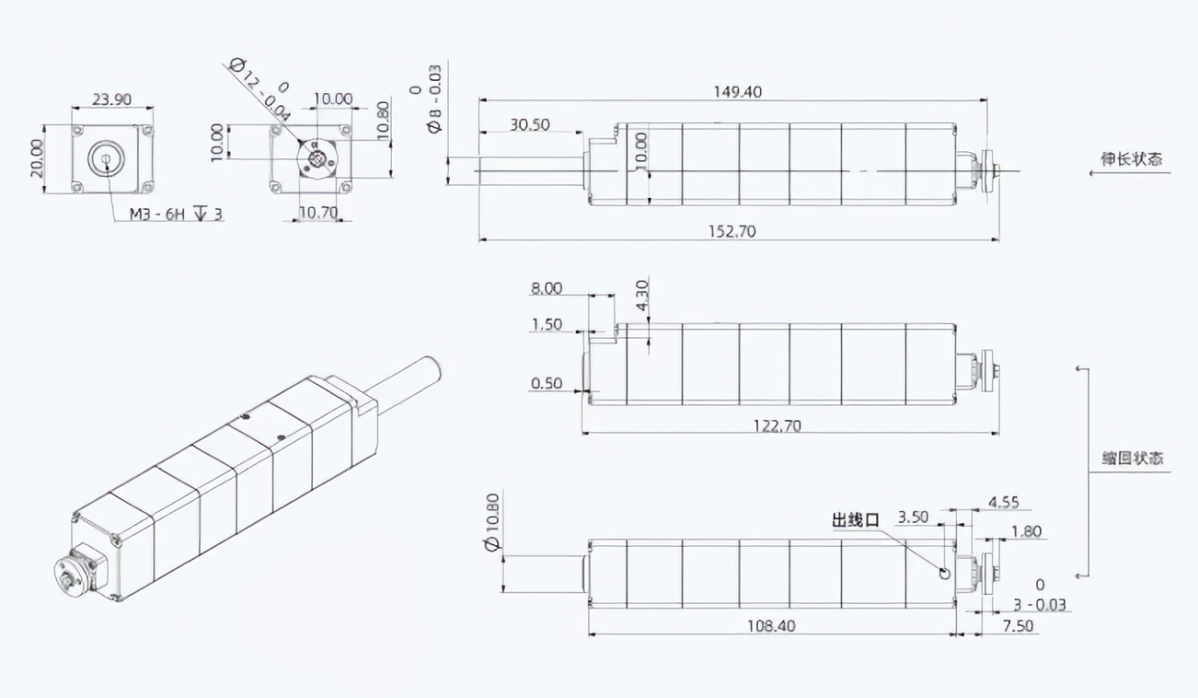
| Cable size/mm | |
diameter | 2.3 |
| length | 400 |
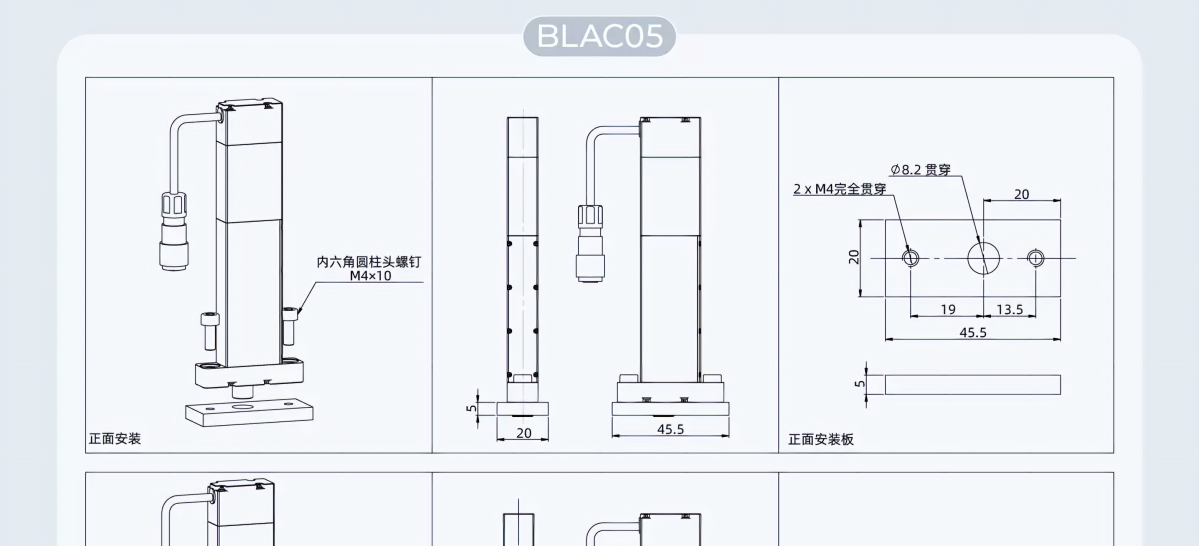
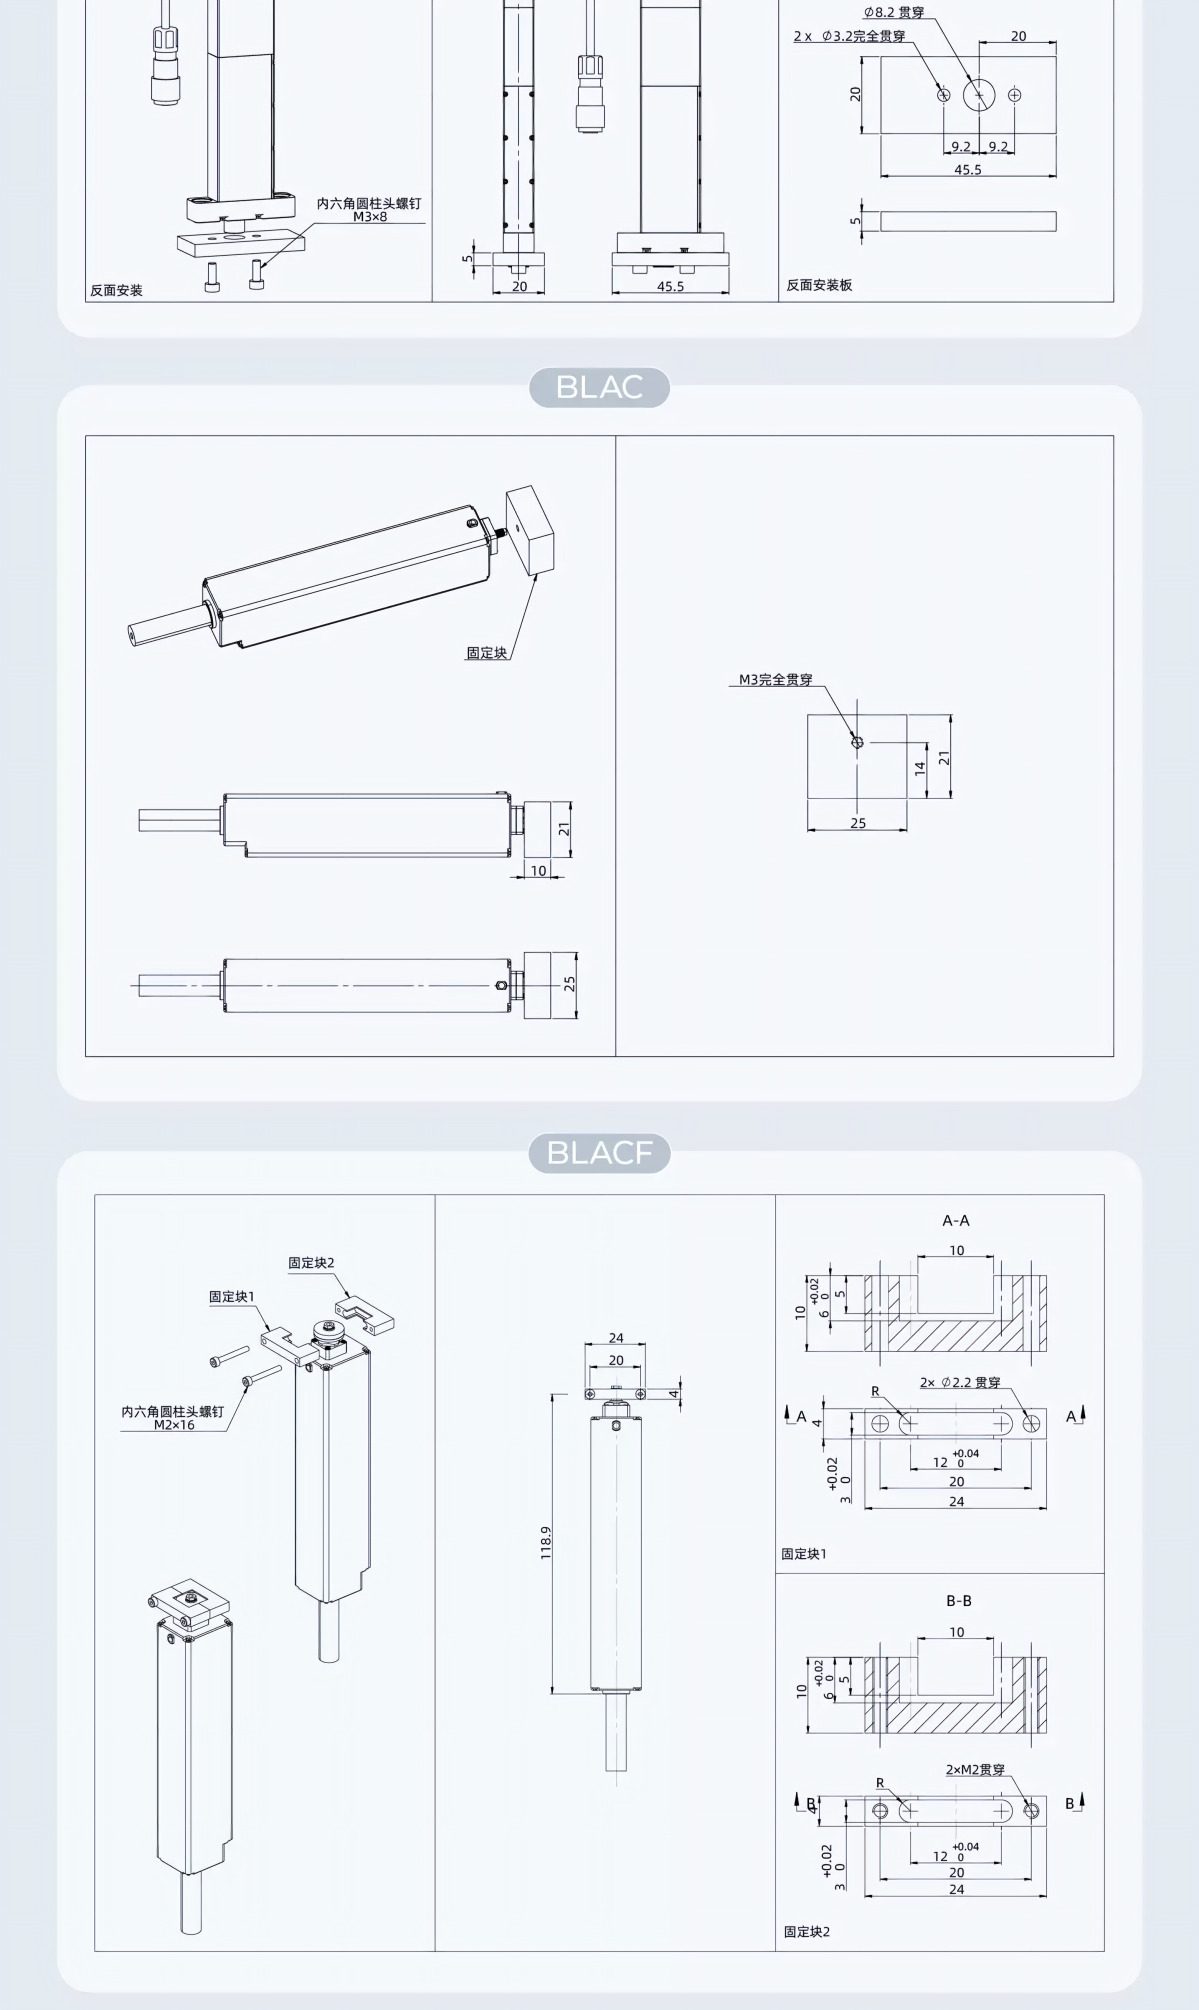
Installation Method
Application Areas
| robot | Biomedicine |
Humanoid robot | Minimally invasive surgical instruments |
Biomimetic robots | Medical aesthetic devices |
Surgical robot | IVD (In Vitro Diagnostic) Equipment |
Teleoperated robot | Rehabilitation Equipment/Exoskeletons |
| Dexterous hand | Biological Laboratory Automation |
| Industrial automation | Aerospace |
New Energy Equipment | UAV / Drone |
3C Electronic Equipment | Manned aircraft |
Semiconductor equipment | |
Optical equipment | |
Automotive automation equipment | Educational Research |
3D Printing | |
| Other precision instruments and meters |


