

Product Description
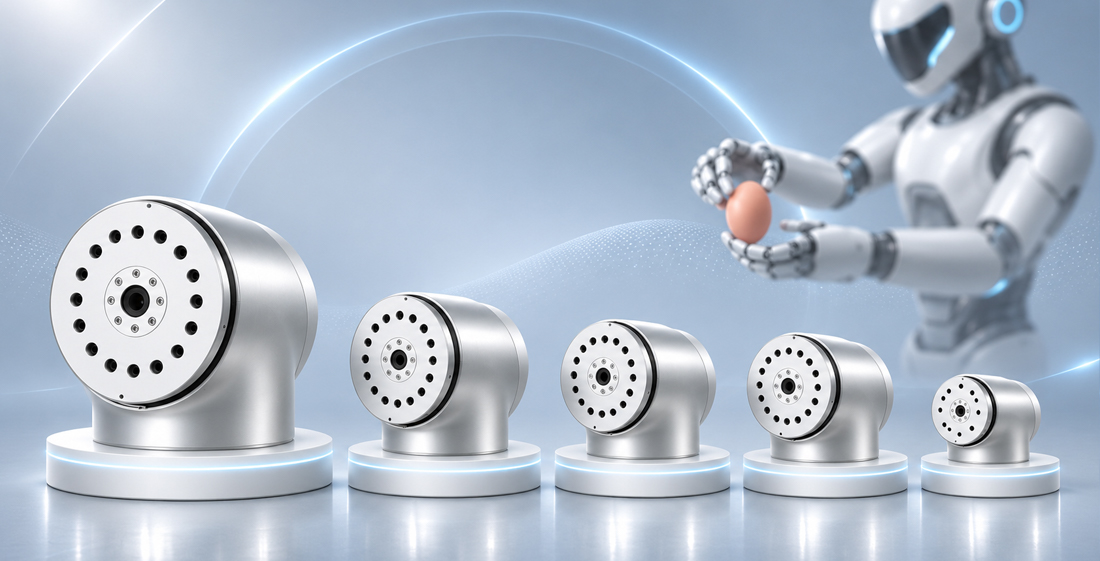
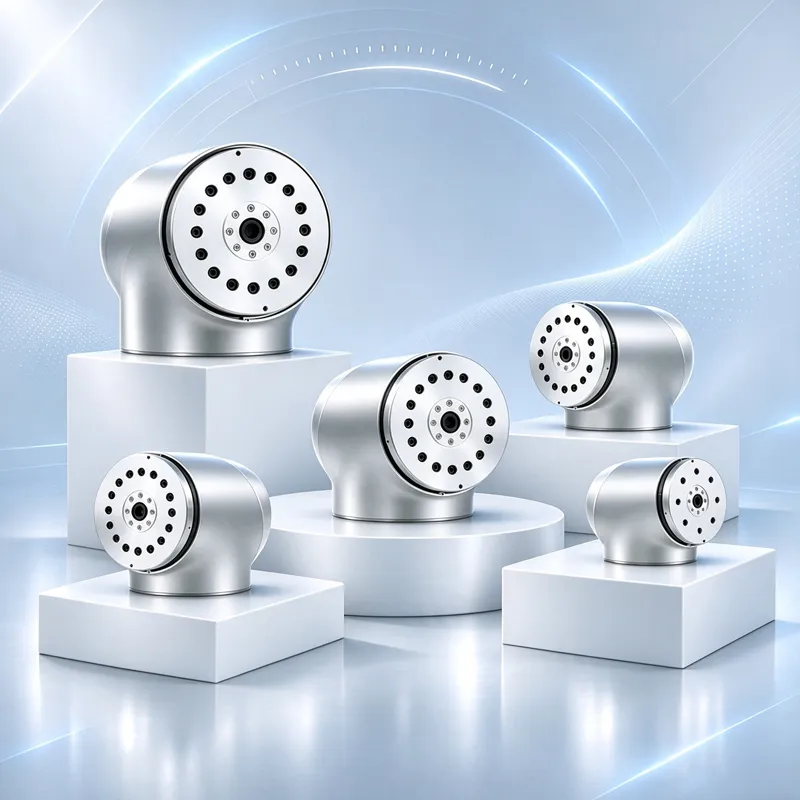
The RJM Series joint modules are a new generation of independently developed high-performance robot joints, featuring compact size, high torque, and high precision. They can be flexibly configured into collaborative robots with 3 to 7 axes in different configurations.
High-performance integrated robot joints feature built-in dual absolute encoders and high-precision full closed-loop control. Equipped with hollow-shaft frameless torque motors, they deliver powerful performance and meet the motion control requirements of humanoid robot joints.
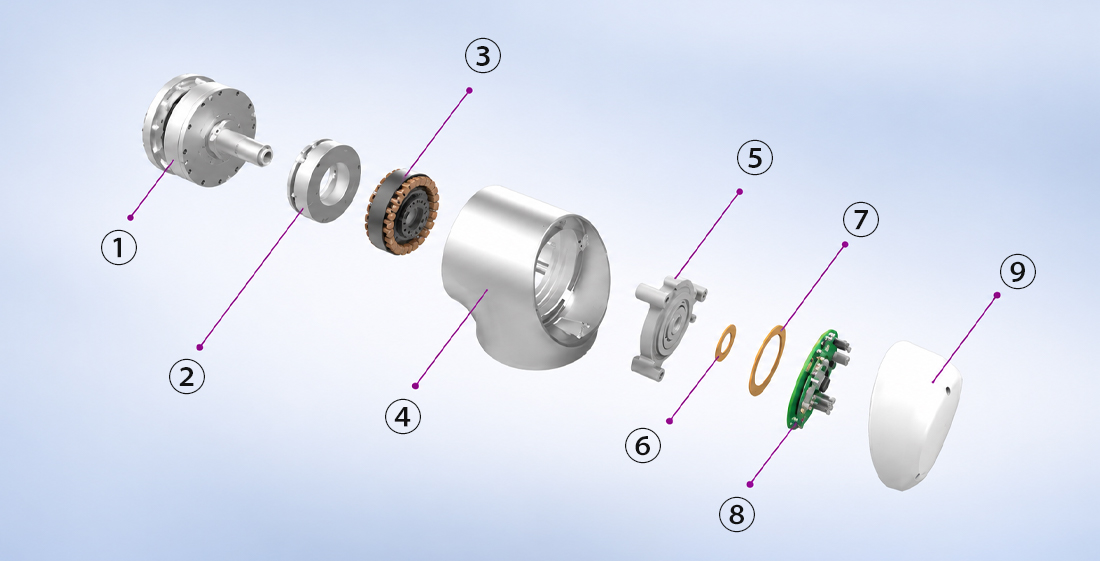
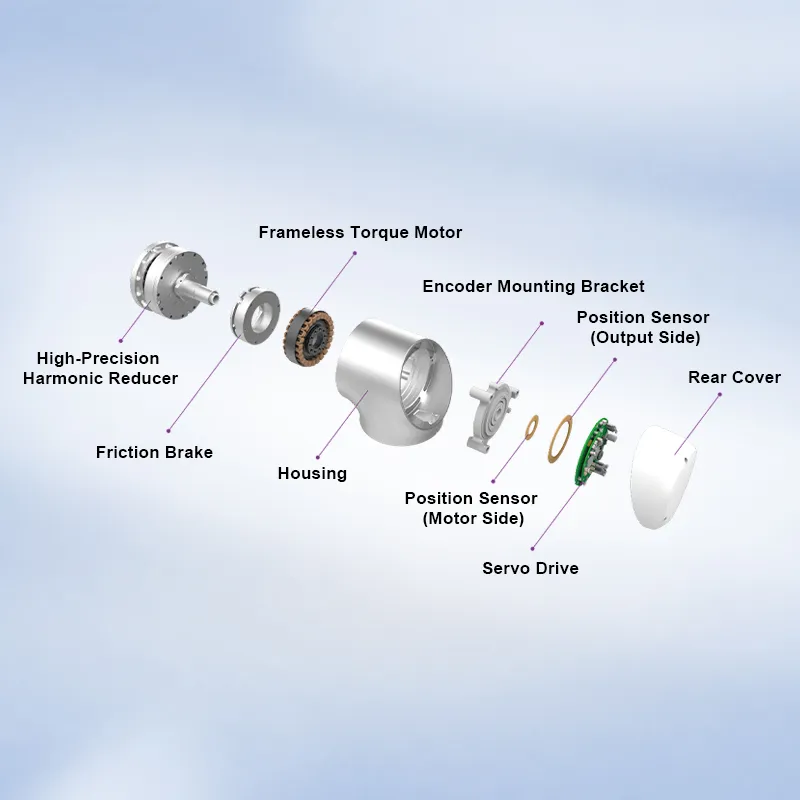
①High-Precision Harmonic Reducer ②Friction Brake ③Frameless Torque Motor ④Housing ⑤Encoder Mounting Bracket ⑥Position Sensor (Motor Side) ⑦Position Sensor (Output Side) ⑧Servo Drive ⑨Rear Cover
Product parameters
Model Specifications | RJM-14-100-A000 | RJM-14-100-A000 | RJM-20-100-A000 | RJM-25-100-A000 | RJM-32-100-A000 | |
Input | Supply Voltage | 48Vdc(±10%) | ||||
Maximum Input Current | 3.5A | 6.0A | 9.0A | 16.5A | 30.0A | |
Continuous Input Current | 1.6A | 4.5A | 5.5A | 11.5A | 20.0A | |
Output | Rated Speed | 35Rev/min | 27Rev/min | 26Rev/min | 26Rev/min | 16Rev/min |
Maximum Speed | 41Rev/min | 32Rev/min | 30Rev/min | 30Rev/min | 27Rev/min | |
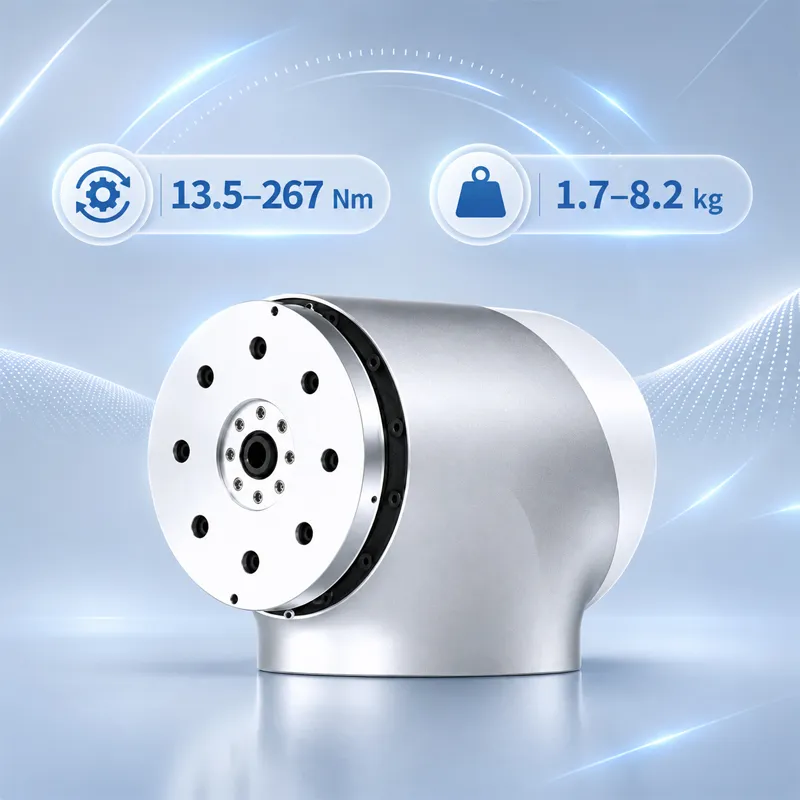
Average Load Torque | 13.5Nm | 48.5Nm | 61Nm | 133Nm | 267Nm | |
Start/Stop Peak Torque | 29Nm | 66Nm | 102Nm | 194Nm | 411Nm | |
Output Torque at Maximum Speed | 13.5Nm | 36.0Nm | 61.0Nm | 81.0Nm | 180.0Nm | |
Performance | Maximum Rotation Angle | ±360° | ±360° | ±360° | ±360° | ±360° |
Output-Side Encoder Resolution | 19bit | 19bit | 19bit | 19bit | 19bit | |
Motor-Side Encoder Resolution | 20bit | 20bit | 20bit | 20bit | 20bit | |
Accuracy | 0.1° | 0.1° | 0.1° | 0.1° | 0.1° | |
Repeatability | 0.001° | 0.001° | 0.001° | 0.001° | 0.001° | |
Hollow Bore Diameter | 9mm | 9mm | 11mm | 13mm | 15mm | |
Weight | 1.7kg | 2.4kg | 2.9kg | 4.7kg | 8.2kg | |
EtherCAT Communication | Minimum Communication Cycle | 250 μs | ||||
Application Profile | IEC 61800-7 Profile Type 1 (CiA402), CoE (CANopen over EtherCAT) | |||||
Communication Objects | PDO (Process Data Object), SDO (Service Data Object) | |||||
Synchronization Type | SYNC0 Event Synchronization, Free Run (PP mode only) | |||||
Operating Modes | Profile Position Mode (PP);Homing Mode (HM);Cyclic Synchronous Position Mode (CSP);Cyclic Synchronous Velocity Mode (CSV);Cyclic Synchronous Torque Mode (CST) | |||||
Debugging Interface | RS485 | |||||
Braking Method | Electromagnetic Friction Brake | |||||
Operating Environment | Operating Temperature | 0°C–45°C (No Derating); 45°C–55°C (Derated) | ||||
Operating Relative Humidity | 10%–95% RH (Non-condensing) | |||||
Storage Temperature | -40~70℃ | |||||
Storage Relative Humidity | 10%–95% RH (Non-condensing) | |||||
Protection Rating | IP54 | |||||
Product Display
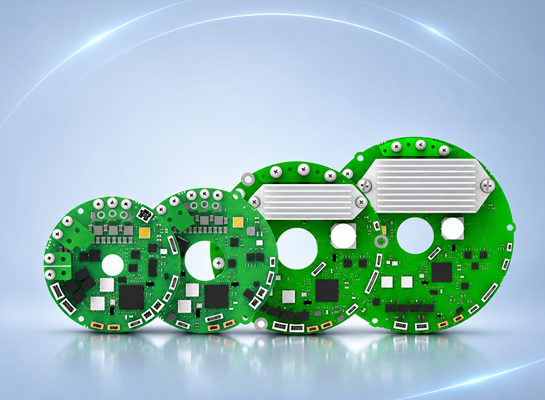
Dual Absolute Encoders for High-Precision Full Closed-Loop Control
●20-bit absolute encoder on the motor side / 19-bit absolute encoder on the output side
●Repeatability of up to 0.001°
●Supports full closed-loop control to eliminate errors caused by wear
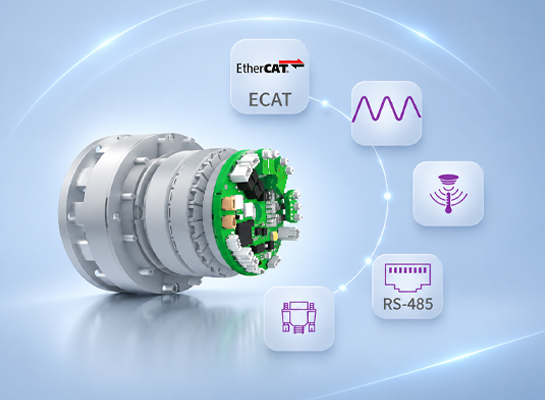
Flexible and Open Design, Supporting Multiple Configurations
● Supports the EtherCAT protocol
●Provides access to position-loop, speed-loop, and current-loop data, supporting real-time adjustment of control parameters
● Supports multiple configurations, including collaborative robots and 2–7-axis modular combinations
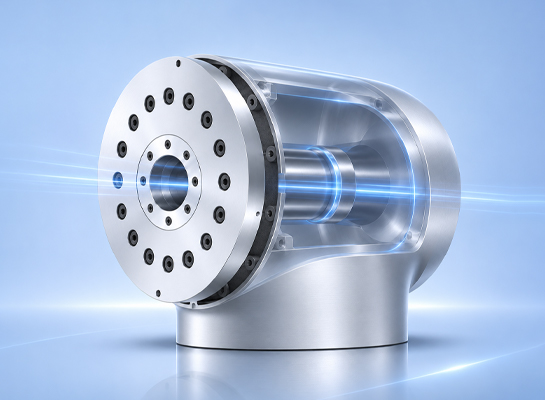
Quick Installation, Convenient Wiring, and Easy Commissioning
●Highly integrated, compact, and refined design enables quick installation and removal
●Hollow-shaft cable routing and compact structure facilitate serial connection of multiple joints
●Advanced one-click tuning and dual-domain tuning functions significantly improve commissioning efficiency
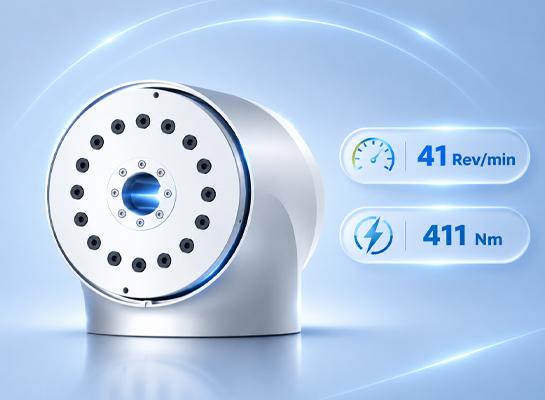
Hollow-Shaft Frameless Torque Motor for Powerful Performance
●High speed (41 rev/min) and high torque (411 Nm)
●Low torque ripple and fast dynamic response
●Integrated electromagnetic holding brake solution for enhanced safety and reliability
Application Cases
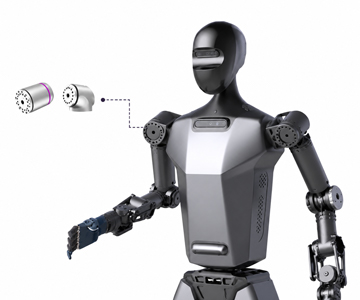
Humanoid Robots
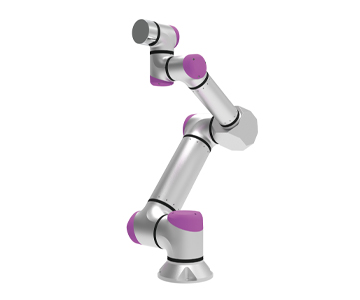
Collaborative Robots
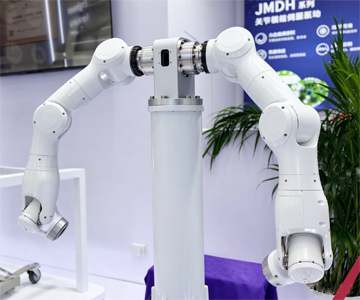
Robotic Arms